Under-Vehicle Inspection System
ProductOverview
Under-vehicle inspection systems (UVIS) are stationary scanning stations deployed at high-security vehicle checkpoints. They use line-scan cameras positioned below-grade to capture detailed images of a vehicle's undercarriage as it slowly passes overhead. The collected images are analyzed in real-time for concealed contraband, explosives, tampering, or foreign attachments. License plate optical character recognition (OCR) tags each scan with the vehicle's identity, linking it to a threat database.
Typical deployment locations:
- Embassy or consulate entrance checkpoints
- Military base perimeters
- High-value facility parking gates
- Border crossing cargo inspection stations
- Presidential or dignitary protective details
A modern UVIS can scan a sedan in 1–2 seconds and flag suspicious anomalies (bulges, loose components, fresh welds, detached markers) with 95%+ accuracy, freeing security personnel to focus on highest-risk vehicles rather than performing manual mirror inspections.
Optical & Detection Principles
Line-Scan Image Acquisition
The core of UVIS technology is the line-scan camera, a specialized sensor fundamentally different from standard area-scan cameras. Instead of capturing a 2D rectangular image, a line-scan sensor captures one horizontal line of pixels (typically 8192 pixels × 1) at a time. As a vehicle moves slowly past the camera, successive lines are stitched together in software to form a 2D image of the entire undercarriage.
Key advantages:
- No motion blur: At vehicle speed 0.5 m/s, exposure time is <1 ms per line; motion blur is negligible.
- Lossless vertical resolution: Unlike area cameras that trade vertical pixels for scan speed, line-scan maintains full resolution at high frame rates (70 kHz line rate).
- Image continuity: Even if vehicle speed varies, the collected image is reconstructed based on actual distances traveled (using odometer or triggered line count), not time-based assumptions.
The LED ring light, synchronized to the camera's line rate, fires a brief high-intensity pulse for each line. The light is diffused via fiber optic bundles to create uniform illumination without harsh shadows.
Threat Detection Analysis
Raw undercarriage images contain millions of pixels. Detection is accomplished via a combination of:
Computer vision algorithms: Edge detection, blob analysis, and texture classification identify sudden changes in topology (welds, cavities, protrusions). A fresh weld appears as a bright linear feature distinct from surrounding rust or coating.
Depth analysis: By repositioning the LED light ring or using multiple LEDs at different angles, the system estimates height variations. A foreign object protruding 10 mm below the chassis baseline triggers an alert.
Threat signature matching: The system stores known explosive device profiles (IED pressure cooker, C-4 brick shapes, detonator wiring) and scans images for similar features. Real-world IED dimensions are well-characterized (~200 mm × 100 mm typical for pressure-cooker variants).
Behavioral flags: Tampering signatures, cut suspension components, rewelded brackets, loose fasteners, appear visually distinct from OEM factory welds.
False positives arise from:
- Manufacturer variation (some sedans ship with exposed plastic clips; others have bare metal).
- Seasonal corrosion or mud buildup.
- Legitimate aftermarket components (skid plates, undertrays).
Operator override is essential: all alerts are presented to a trained analyst with the original image and threat assessment confidence score; human judgment determines final clearance.
License Plate OCR Integration
Simultaneous to undercarriage imaging, the dedicated LPR camera captures the vehicle's front or rear license plate. The high-speed xenon flash illuminates the plate; a global-shutter CMOS camera freezes the image free of motion blur. Proprietary OCR software reads plate characters (letters, numbers, state code) with ~97% accuracy on first-pass.
The OCR result is immediately queried against the threat database:
- Green (clear): Vehicle matches approved fleet, no historical flags → barrier lowers, vehicle proceeds.
- Yellow (caution): Vehicle matches watchlist but reason is administrative (expired inspection, traffic violation) → operator reviews undercarriage scan, makes final call.
- Red (alert): Vehicle matches stolen vehicle registry, active warrant, or known threat profile → automatic hold, law enforcement notified.
System Architecture & Installation
Pit Layout
A typical installation excavates a shallow pit:
- Width: 3000 mm (accommodates most vehicles, including SUVs).
- Depth: 300–400 mm below final grade (camera sits ~600 mm below road surface).
- Length: 2000 mm (allows camera field-of-view to capture full undercarriage length).
The aluminum road plate, mounted flush with surrounding asphalt or concrete, supports vehicle weight. Underneath, a steel pit frame houses the camera module, LED lighting, and drainage systems.
Drainage is critical: the pit must not pool water (which corrodes electronics and obscures images). Stainless grates at pit corners direct stormwater to sub-grade sumps and perimeter drains.
Electrical Infrastructure
Power distribution comes from a site main breaker:
- Line voltage: 480 VAC three-phase (typical for secure facilities) or 208 VAC single-phase.
- UPS backup: A sealed lead-acid UPS provides 30-minute hold-up at half-load, ensuring that during a power outage, the operator can safely retract any raised barriers and shut down cleanly.
The 24 VDC power distribution module derives low-voltage supplies for cameras, LEDs, and control electronics. All solenoid controls use 24 VDC for safety (low-voltage circuits are inherently safer in failure modes).
Network & Data
Image streams flow via:
- Fiber optic cable (for long runs >50 m): The line-scan camera outputs data at ~200 MB/s; fiber carries this bandwidth without EMI susceptibility that copper Gigabit Ethernet experiences near high-power equipment.
- Gigabit Ethernet: LPR camera and workstation communicate via shielded Cat6A cable with surge protection at both ends.
All data (images, license plates, threat assessments, timestamps) is logged to the local PostgreSQL database. Modern systems also push records to cloud servers for trend analysis and inter-agency threat correlation.
Operational Workflow
Vehicle Approach & Lane Control
As a vehicle approaches the inspection zone:
- Traffic signal (red light) signals the driver to stop several meters before the pit.
- Inductive loop or pressure mat detects the vehicle's presence.
- Operator begins system initialization: moves camera to focus position, primes LED flash.
Scanning Process
- Operator presses "SCAN" button or system auto-triggers.
- Line-scan camera begins capturing lines at 70 kHz.
- Vehicle rolls forward slowly (0.2–0.5 m/s).
- Real-time threat detection software flags any anomalies; alert overlays appear on operator monitor.
- Scan completes when rear bumper clears the pit; total acquisition time <2 seconds.
Analysis & Clearance
- Operator reviews flagged regions in high-resolution zoom views.
- LPR system has already OCR'd the license plate; database lookup returns vehicle history.
- Operator makes clearance decision:
- Clear: Barrier lowers (if any), green light signals vehicle to proceed.
- Secondary search: Vehicle directed to pull-aside bay for physical inspection.
- Hold & alert: Law enforcement called for suspected threat.
Operator decision time: 10–30 seconds per vehicle (bottleneck in high-throughput scenarios).
Threat Detection Sensitivity & False Negatives
UVIS effectiveness depends on several factors:
Detection Challenges
- Vehicle cleanliness: A heavily mud-caked undercarriage obscures visual details. Automated pre-wash systems (common at airports) improve image quality.
- Exotic attachments: A thin magnetic device (rare-earth magnet array, <10 mm profile) can escape detection if positioned in a shadow or beneath thick corrosion.
- Operator fatigue: After scanning 200+ vehicles in a shift, human attention wanes. Studies show false-negative rates increase 5–8% in hour 4–6 of operation.
Mitigation Strategies
- Supplemental IR or UV imaging: Near-IR reflectance (850 nm) can reveal fresh materials (epoxy, primer) distinct from aged surfaces. Ultra-violet excitation can fluoresce explosive residues in early stages of preparation.
- Multi-angle illumination: Repositioning LEDs to side-lighting angles casts shadows that reveal fine topographical features that head-on lighting misses.
- Machine learning refinement: Modern systems use deep learning (CNN classifiers) trained on thousands of labeled undercarriage images; these models outperform hand-crafted vision algorithms by ~5–10% accuracy.
Maintenance & Calibration
Preventive Maintenance
Weekly:
- Visual inspection of pit floor for debris or standing water.
- Test LED brightness (measure lux at camera focal plane; should stay above 40,000 lux).
- Verify camera line focus by capturing a test image of a ruled grid pattern placed in pit.
Monthly:
- Clean fiber optic bundle end faces with lens paper and isopropyl alcohol.
- Recalibrate LPR camera flash timing (adjust pulse delay relative to camera frame exposure).
- Run OCR accuracy test on printed license plates; acceptable pass rate >95%.
Quarterly:
- Full system performance test: scan test vehicle with known contraband simulant; verify detection.
- Drain pit sump and inspect for corrosion or water intrusion at electrical penetrations.
- Update threat detection software signatures (cloud patches downloaded automatically).
Annually:
- Recalibrate camera to roadway height (subsettlement can shift pit ~10 mm over a year).
- Replace LED ring light (typical service life 3–5 years; brightness drops >20% before end-of-life).
- Full backup and archive of database; test restore procedures.
Component Lifespan
| Component | Service Life | Notes |
|---|---|---|
| Line-scan camera sensor | 5–7 years | Radiation hardness optional for sites >1M scans/year |
| LED ring light | 3–5 years | Brightness degradation limits detection ability |
| Fiber optic bundle | 7–10 years | Physical abuse (crushing under vehicle) primary failure mode |
| Database server (SSD) | 5–7 years | Write-endurance limited; recommend SSD replacement mid-life |
| Xenon flash tube (LPR) | 2–3 years | Capacitor degradation limits flash brightness |
Standards & Regulatory
- ISO/IEC 19794-4: Biometric data interchange formats; specifies how facial/vehicle images are tagged and transmitted (relevant for international border deployments).
- ASTM E2252: Standard guide for detection of concealed explosive devices via visual inspection.
- European Union Directive 2013/40/EU: Network and information security standards for critical infrastructure.
- NFPA 921: Guide for fire and explosion investigations (evidence preservation requirements if explosives are detected).
Performance Metrics & Benchmarks
- Scan time: 1–2 seconds per vehicle.
- Throughput (with operator review): 30–60 vehicles/hour depending on alert rate.
- Detection sensitivity: 95–98% for devices >50 mm in largest dimension.
- False positive rate: 1–3% (operator training level dependent).
- Mean time between failures (MTBF): 8,000–12,000 operating hours.
- Downtime recovery: <1 hour for replacement of hot-swappable modules (camera, LED light, power supply).
Economics
A complete UVIS installation (pit excavation, camera assembly, workstation, database, operator training) costs $250,000–400,000. Operating costs (staffing, maintenance, electricity) run $50,000–80,000/year. Assuming a 10-year system life, total cost of ownership reaches ~$750,000–1.2M. For high-threat facilities (embassies, military bases), the cost per incident prevented easily justifies the investment.
Under-Vehicle Inspection System parts and their functions
7 top-level parts · 38 parts in total · full bill of materials below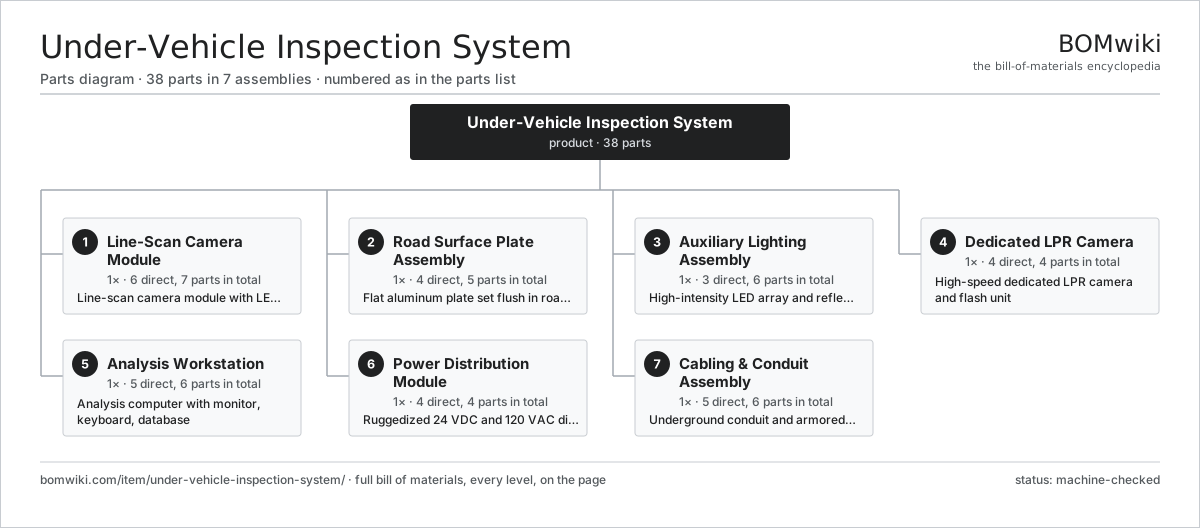
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Line-Scan Camera Module 6 parts | 1× | Line-scan camera module with LED ring lighting |
| 2 | Road Surface Plate Assembly 4 parts | 1× | Flat aluminum plate set flush in roadway surface |
| 3 | Auxiliary Lighting Assembly 3 parts | 1× | High-intensity LED array and reflectors |
| 4 | Dedicated LPR Camera 4 parts | 1× | High-speed dedicated LPR camera and flash unit |
| 5 | Analysis Workstation 5 parts | 1× | Analysis computer with monitor, keyboard, database |
| 6 | Power Distribution Module 4 parts | 1× | Ruggedized 24 VDC and 120 VAC distribution |
| 7 | Cabling & Conduit Assembly 5 parts | 1× | Underground conduit and armored cable from pit to surface cabinet |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Under-Vehicle Inspection System
7 top-level lines · 38 rows shown · 38 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Line-Scan Camera Module 6 parts | under-vehicle-inspection-system-camera-assembly | 1× | 1 | 7 | assembly |
| 1.1 | Line-Scan Sensor | under-vehicle-inspection-system-linescan-sensor | 1× | 1 | · | part |
| 1.2 | Fixed Focal Lens Assembly | under-vehicle-inspection-system-lens-module | 1× | 1 | · | part |
| 1.3 | High-Intensity LED Ring Light | under-vehicle-inspection-system-led-ring-light | 1× | 1 | · | part |
| 1.4 | Fiber Optic Diffuser | under-vehicle-inspection-system-fiber-optic-bundle | 1× | 1 | · | part |
| 1.5 | Mechanical Shutter Blade | under-vehicle-inspection-system-shutter-blade | 2× | 2 | · | part |
| 1.6 | Camera Housing Bracket | under-vehicle-inspection-system-housing-bracket | 1× | 1 | · | part |
| 2 | Road Surface Plate Assembly 4 parts | under-vehicle-inspection-system-road-plate | 1× | 1 | 5 | assembly |
| 2.1 | Flush-Mount Aluminum Plate | under-vehicle-inspection-system-aluminum-plate | 1× | 1 | · | part |
| 2.2 | Pit Support Frame | under-vehicle-inspection-system-pit-frame | 1× | 1 | · | part |
| 2.3 | Pit Drainage Grate | under-vehicle-inspection-system-drainage-grate | 2× | 2 | · | part |
| 2.4 | Pit Perimeter Seal | under-vehicle-inspection-system-pit-sealing-gasket | 1× | 1 | · | part |
| 3 | Auxiliary Lighting Assembly 3 parts | under-vehicle-inspection-system-lighting-unit | 1× | 1 | 6 | assembly |
| 3.1 | Linear LED Strip Light | under-vehicle-inspection-system-led-strip-light | 4× | 4 | · | part |
| 3.2 | Circular Polarizing Filter | under-vehicle-inspection-system-polarizing-filter | 1× | 1 | · | part |
| 3.3 | Near-IR LED Array (850 nm) | under-vehicle-inspection-system-infrared-led-array | 1× | 1 | · | part |
| 4 | Dedicated LPR Camera 4 parts | under-vehicle-inspection-system-license-plate-reader | 1× | 1 | 4 | assembly |
| 4.1 | LPR CMOS Camera | under-vehicle-inspection-system-lpr-camera | 1× | 1 | · | part |
| 4.2 | Xenon Flash Unit | under-vehicle-inspection-system-lpr-flash-strobe | 1× | 1 | · | part |
| 4.3 | Motorized Zoom Lens | under-vehicle-inspection-system-lpr-lens | 1× | 1 | · | part |
| 4.4 | Optical Filter Stack | under-vehicle-inspection-system-lpr-filter-ring | 1× | 1 | · | part |
| 5 | Analysis Workstation 5 parts | under-vehicle-inspection-system-workstation | 1× | 1 | 6 | assembly |
| 5.1 | Fanless Industrial PC | under-vehicle-inspection-system-industrial-pc | 1× | 1 | · | part |
| 5.2 | Touchscreen LCD Monitor | under-vehicle-inspection-system-dual-monitor | 2× | 2 | · | part |
| 5.3 | Sealed Input Devices | under-vehicle-inspection-system-keyboard-mouse | 1× | 1 | · | part |
| 5.4 | Vehicle Database | under-vehicle-inspection-system-database-server | 1× | 1 | · | part |
| 5.5 | OCR & Detection Software | under-vehicle-inspection-system-software-license | 1× | 1 | · | part |
| 6 | Power Distribution Module 4 parts | under-vehicle-inspection-system-power-supply-unit | 1× | 1 | 4 | assembly |
| 6.1 | AC Power Inlet & Disconnect | under-vehicle-inspection-system-ac-power-inlet | 1× | 1 | · | part |
| 6.2 | 24 VDC Power Supply | under-vehicle-inspection-system-dc-power-supply | 1× | 1 | · | part |
| 6.3 | UPS Battery Backup | under-vehicle-inspection-system-uninterruptible-power-supply | 1× | 1 | · | part |
| 6.4 | Electrical Distribution Panel | under-vehicle-inspection-system-distribution-panel | 1× | 1 | · | part |
| 7 | Cabling & Conduit Assembly 5 parts | under-vehicle-inspection-system-cable-conduit-kit | 1× | 1 | 6 | assembly |
| 7.1 | Flexible Armored Conduit | under-vehicle-inspection-system-armored-conduit | 1× | 1 | · | part |
| 7.2 | Multi-Mode Fiber Cable | under-vehicle-inspection-system-fiber-optic-cable | 1× | 1 | · | part |
| 7.3 | Shielded 24 VDC Power Cable | under-vehicle-inspection-system-power-cable | 1× | 1 | · | part |
| 7.4 | Cat6A Outdoor Ethernet | under-vehicle-inspection-system-ethernet-cable | 1× | 1 | · | part |
| 7.5 | Stainless Steel Splice Box | under-vehicle-inspection-system-cable-junction-box | 2× | 2 | · | part |
Something wrong in this list? Report a problem with this BOM.
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $200–$100M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| smithsdetection.com ↗ | London, GB | Security screening | made to order | 24–52 wks |
|
🇺🇸Leidos
leidos.com ↗
|
Reston, US | Security & screening | made to order | 24–52 wks |
|
🇺🇸Rapiscan
rapiscansystems.com ↗
|
Torrance, US | X-ray screening | made to order | 24–52 wks |
|
🇫🇷Thales
thalesgroup.com ↗
|
Paris, FR | Defense electronics | made to order | 24–52 wks |
| baesystems.com ↗ | London, GB | Defense | made to order | 24–52 wks |
1,787-word article