Photo Finish Camera
ProductOverview
A photo finish camera is a specialized imaging system used in competitive athletics to resolve extremely close race finishes. While human timekeepers can determine winners to the nearest 0.1 second, elite sprints often feature simultaneous finishes to within 1–10 milliseconds. A photo finish camera captures a continuous line-scan image perpendicular to the finish line, recording which runner's torso crosses the line first at microsecond precision.
The system comprises a high-speed line-scan sensor, precision timing synchronization (typically GPS-disciplined), real-time frame capture, and GPU-accelerated edge detection software that automatically ranks finishers by comparing their leading edges. Photo finish is now standard in Olympic Games, World Championships, and professional track meets.
How it works
Line-Scan Imaging
Unlike conventional cameras that capture full 2D frames, the sensor assembly uses a linear array (4096 pixels) that scans a 1D slice perpendicular to the finish line at extremely high speed. The CMOS line-scan sensor reads pixels at 8 kHz, meaning it captures a complete horizontal "slice" across the finish line every 125 microseconds.
Each slice is spatially precise: the lens assembly projects the finish line onto the 4096-pixel array, giving a spatial resolution of approximately 1 mm per pixel (depending on focal length and finish-line width). Temporally, the 8 kHz line rate means that a runner's crossing is recorded with 125 μs precision in time.
As the race event unfolds (30–100 seconds), thousands of sequential line scans are captured, building a 2D image showing the finish line over time. The vertical axis (built up from sequential lines) represents elapsed time, and the horizontal axis represents position across the finish line.
Timing Synchronization
The critical challenge is synchronizing the camera's line-scan readout with an accurate global time reference. The timer sync module receives a 1 PPS (pulse per second) signal from a GPS receiver. This GPS timing is accurate to within 100 nanoseconds, allowing multiple cameras and timing systems at a venue to share a common time reference.
A disciplined oscillator is locked to the GPS 1 PPS signal, producing a stable 25 MHz clock that drives the trigger unit. This clock generates precise line-start pulses that trigger each line-scan readout. The microcontroller in the trigger unit also timestamps each line with GPS-synchronized time (e.g., 14:35:42.003847 UTC).
Image Capture and Processing
The capture station uses a high-speed PCIe frame grabber to pull raw pixel data from the sensor at 32 MB/s (for 8-bit capture of 4096 × 1 lines at 8 kHz). The data is written directly to the NVMe SSD for real-time archival. This approach guarantees no frames are lost even during peak activity (multiple simultaneous finishes).
After the race (or in real-time), the processing unit analyzes the finish image using GPU-accelerated algorithms:
- Edge Detection: A CUDA-capable GPU scans each column (runner position) to find the leading edge (torso) of each participant's image.
- Time Assignment: For each runner's leading edge pixel, the GPU reads the timestamp from the corresponding line.
- Ranking: Runners are ranked by comparing the time at which their edge crossed the finish line (within milliseconds).
- Manual Review: Officials review the image on a high-resolution display, confirming the automatic ranking and making appeals decisions if needed.
Lens and Exposure Control
The lens module uses a variable 6–25 mm focal length lens or a fixed 8 mm, mounted with a precision kinematic bracket for X/Y/Z adjustment. The lens is positioned perpendicular to the finish line at approximately 3–5 meters away, viewing a 10–20 meter wide section that includes the finish line and approach zone.
A motorized iris aperture (f/1.4–f/16) allows the operator to control exposure without adjusting shutter speed (the line-scan sensor has no conventional shutter). A rotating filter turret can hold neutral-density or polarizer filters to manage bright outdoor sunlight or glare off the track surface.
Multi-Camera Synchronization
For larger events (relays, team sports), multiple photo-finish cameras can be installed at different positions (finish line, 100 m mark, etc.). Each camera is synchronized to the same GPS 1 PPS reference via the timing distribution amplifier. This allows cross-event timing validation (e.g., confirming that a relay baton exchange occurred legally by comparing hand-off camera images across multiple angles).
Installation and Setup
A photo finish system is typically installed 5–10 meters before the actual finish line, mounted on a stable support (tripod or gantry). The camera is positioned at roughly 1.5–2 meters height, perpendicular to the expected path of runners. The lens is focused on the finish line with sharpness verified using a target card at race-start distance.
The capture station (computer with frame grabber and SSD) is placed in a weatherproof enclosure near the camera, or inside an adjacent timing booth. Power requirements are modest (500 W peak), running from standard 110/240 VAC mains.
GPS antenna is mounted on the roof of the timing booth or on the camera gantry, with a clear sky view (unobstructed 10+ degrees above horizon). Once GPS lock is achieved, the timing offset between the camera's local clock and GPS is recorded, allowing time-synchronization even if GPS signal is temporarily lost during the event.
Pre-Race Verification
Before competition, the timing system undergoes a verification procedure:
- A test runner sprints past the camera at known speed, and the finish image is checked for focus sharpness and adequate exposure.
- Timing accuracy is verified by recording a manual sync pulse (e.g., a strobe flash at known GPS time) and confirming the camera's timestamp matches within 1 μs.
- Storage capacity is checked (1–2 TB is sufficient for 1–2 hours of continuous capture).
- GPU software is tested with a replay of a previous race to confirm edge-detection accuracy.
Post-Race Analysis
After the race, the finish image is available within seconds. Race officials review the image, checking:
- Are leading edges clearly visible and distinct?
- Are timestamps accurate and properly recorded?
- Are the rankings consistent with photo edge positions?
If there are objections from runners (e.g., apparent false touch-screen or pacing error), officials can zoom, pan, and measure pixel positions with sub-millimeter precision, resolving disputed finishes. The complete image archive is retained for appeals processes, typically 30 days post-event.
Modern meets also project the finish image on large venue screens for spectators, showing the dramatic photo-finish ranking in near-real-time.
Photo Finish Camera parts and their functions
6 top-level parts · 40 parts in total · full bill of materials below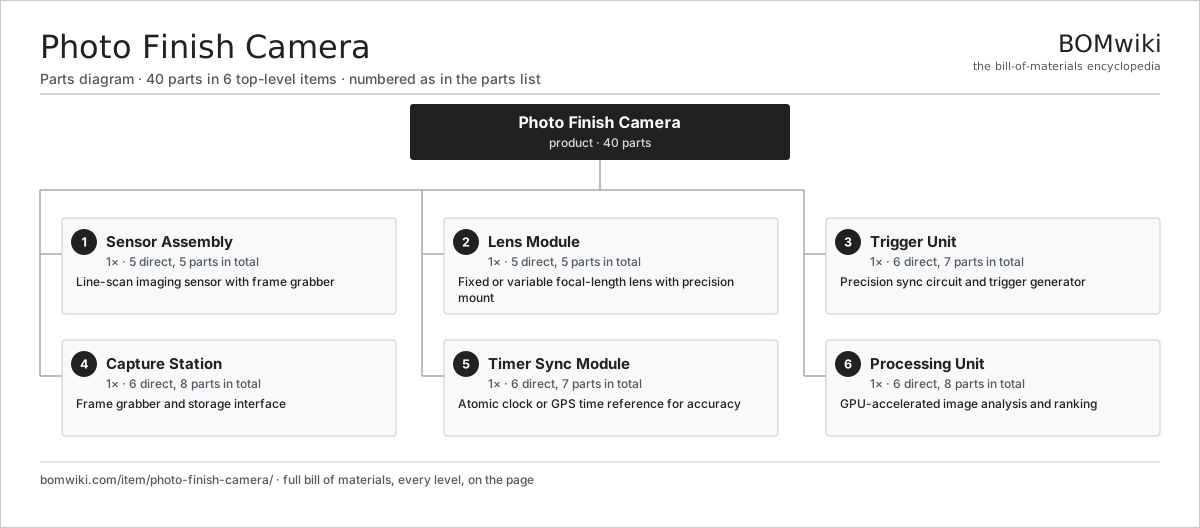
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Sensor Assembly 5 parts | 1× | Line-scan imaging sensor with frame grabber |
| 2 | Lens Module 5 parts | 1× | Fixed or variable focal-length lens with precision mount |
| 3 | Trigger Unit 6 parts | 1× | Precision sync circuit and trigger generator |
| 4 | Capture Station 6 parts | 1× | Frame grabber and storage interface |
| 5 | Timer Sync Module 6 parts | 1× | Atomic clock or GPS time reference for accuracy |
| 6 | Processing Unit 6 parts | 1× | GPU-accelerated image analysis and ranking |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Photo Finish Camera
6 top-level lines · 40 rows shown · 40 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Sensor Assembly 5 parts | photo-finish-camera-sensor-assembly | 1× | 1 | 5 | assembly |
| 1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 1.2 | Sensor Amplifier | photo-finish-camera-sensor-amplifier | 1× | 1 | · | part |
| 1.3 | Frame Grabber | photo-finish-camera-frame-grabber | 1× | 1 | · | part |
| 1.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Lens Module 5 parts | photo-finish-camera-lens-module | 1× | 1 | 5 | assembly |
| 2.1 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 2.2 | Aperture | photo-finish-camera-aperture | 1× | 1 | · | part |
| 2.3 | Filter Mount | photo-finish-camera-filter-mount | 1× | 1 | · | part |
| 2.4 | Lens Bracket | photo-finish-camera-lens-bracket | 1× | 1 | · | part |
| 2.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 3 | Trigger Unit 6 parts | photo-finish-camera-trigger-unit | 1× | 1 | 7 | assembly |
| 3.1 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.2 | Precision Oscillator | photo-finish-camera-precision-oscillator | 1× | 1 | · | part |
| 3.3 | Relay | relay | 1× | 1 | · | part |
| 3.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.5 | Connector | connector | 2× | 2 | · | part |
| 3.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 4 | Capture Station 6 parts | photo-finish-camera-capture-station | 1× | 1 | 8 | assembly |
| 4.1 | Frame Grabber | photo-finish-camera-frame-grabber | 1× | 1 | · | part |
| 4.2 | SSD Storage | photo-finish-camera-ssd-storage | 1× | 1 | · | part |
| 4.3 | Processing CPU | photo-finish-camera-processing-cpu | 1× | 1 | · | part |
| 4.4 | Power Supply | power-supply | 1× | 1 | · | part |
| 4.5 | Connector | connector | 3× | 3 | · | part |
| 4.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 5 | Timer Sync Module 6 parts | photo-finish-camera-timer-sync | 1× | 1 | 7 | assembly |
| 5.1 | GPS Receiver | photo-finish-camera-gps-receiver | 1× | 1 | · | part |
| 5.2 | Reference Oscillator | photo-finish-camera-reference-oscillator | 1× | 1 | · | part |
| 5.3 | Distribution Amplifier | photo-finish-camera-distribution-amplifier | 1× | 1 | · | part |
| 5.4 | Connector | connector | 2× | 2 | · | part |
| 5.5 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 6 | Processing Unit 6 parts | photo-finish-camera-processing-unit | 1× | 1 | 8 | assembly |
| 6.1 | Processing CPU | photo-finish-camera-processing-cpu | 1× | 1 | · | part |
| 6.2 | GPU Accelerator | photo-finish-camera-gpu-accelerator | 1× | 1 | · | part |
| 6.3 | SSD Storage | photo-finish-camera-ssd-storage | 1× | 1 | · | part |
| 6.4 | Power Supply | power-supply | 1× | 1 | · | part |
| 6.5 | Connector | connector | 3× | 3 | · | part |
| 6.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Smart Parcel Locker
278 parts · shares 3 with this page
 Video Intercom System
110 parts · shares 3 with this page
 Video Doorbell
231 parts · shares 2 with this page
 Mantrap Interlock Portal
82 parts · shares 2 with this page
 Electronic Key Cabinet
92 parts · shares 1 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $50–$10k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| assaabloy.com ↗ | Stockholm, SE | Locks & access | 1,000 units | 8–12 wks |
|
🇺🇸Allegion
allegion.com ↗
|
Dublin, US | Security products (Schlage) | 1,000 units | 8–12 wks |
| dormakaba.com ↗ | Rümlang, CH | Access & door systems | 1,000 units | 8–12 wks |
| honeywell.com ↗ | Charlotte, US | Building & safety tech | 1,000 units | 8–12 wks |
| hikvision.com ↗ | Hangzhou, CN | Surveillance & security | 1,000 units | 8–12 wks |
1,182-word article