Robotic Welding Cell
ProductOverview
A robotic welding cell automates the high-skill, high-cost task of precision joint fabrication. The six-axis articulated arm positions a welding torch with millimeter accuracy and absolute repeatability. The powered positioner rotates and tilts the workpiece to present joints at optimal angles for penetration and travel. Multi-pass, multi-feature welds that take a human welder 4–8 hours run unattended in 20–40 minutes.
Robots offer:
- Repeatability: Every part identical, no weld quality variation between shifts or operators.
- Cycle time: Faster torch travel (no hand tremor), minimal repositioning dwell.
- Labor: One technician monitors 2–4 cells, vs. one welder per manual station.
- Consistency: Arc voltage feedback and wire feed synchronization maintain bead profile across all parts.
Modern collaborative cells include integrated safety systems (light curtains and safe-rated relays) allowing operators to work alongside the robot at reduced speed during setup.
How it works
Programming and Teaching: The technician connects the teach pendant to the controller and moves the robot through each weld path using the joystick. At each point, they press "Record" to store XYZ position and orientation (Rx, Ry, Rz). Recorded points form a continuous path; the controller interpolates between them.
The program also specifies arc parameters: start current, ramp rate, wire feed speed, shielding gas, and travel speed. The technician tests the first part manually while the arc voltage sensor confirms stable arc voltage. Fine adjustments (current ±5 A, travel speed ±50 mm/min) are made via teach pendant without re-programming.
Workpiece Loading: An operator clamps the part into the positioner and closes the interlocked safety gate. The system checks that all light curtains are clear, then the robot and positioner initialize.
Joint Positioning: The master controller commands the robot arm to move to the first weld start point. The positioner simultaneously tilts and rotates to present the joint at a flat or downhand angle (easiest for consistent penetration). Both reach their target positions within 2–5 seconds.
Arc Initiation: The robot briefly touches the torch contact tip to the workpiece (intentional short), creating a pilot arc. The arc voltage feedback confirms arc strike. The wire feeder synchronizes with robot travel speed: as the arm moves at 500 mm/min, wire feed is set to match the planned deposition rate (typically 6–8 m/min wire speed for a 5 mm bead on 6 mm material).
Multi-Pass Welds: For thick sections, the robot executes multiple passes in sequence:
- Root pass (light current, slow travel)
- Fill passes (medium current, normal travel)
- Cap pass (high current, faster travel to smooth surface)
The positioner may rotate the part between passes to reposition the next seam horizontally. All motion is programmed; the robot never makes judgment calls.
Thermal and Arc Control: The constant-voltage power source monitors arc voltage and adjusts wire feed speed in real time. If an edge or surface change narrows the gap, voltage drops slightly; the controller bumps wire feed to push more metal, restoring voltage. This closed-loop regulation maintains bead width and height across all surface conditions.
Finish and Unload: The robot retracts, the positioner returns to neutral position, and the gate unlocks. The operator removes the part, inspects for voids or cold joints (rare if properly programmed), and clamps the next part.
Joint Preparation and Fixturing
Robot cells tolerate slightly looser fit-ups than manual welding. Because the torch path is absolute (not following the joint by sight), a gap of 1–3 mm is acceptable; the robot bridges it automatically. But gaps exceeding 5 mm produce incomplete fusion at the root.
Standard practice: grinding and jigging to within ±2 mm runout at the weld centerline. The positioner clamps must hold the part rigidly, any deflection during the weld introduces arc length variation and defects.
Multi-Axis Coordination
The six robot joints work in concert. To move the torch tip to a precise 3D point with a specific orientation, the controller solves inverse kinematics: given XYZ coordinates and Rx/Ry/Rz angles, calculate the six joint angles needed to reach that pose.
The solver accounts for joint limits (e.g., Axis 2 shoulder cannot exceed 120 degrees), singularities (poses where the arm locks), and collision avoidance with the positioner and cell frame.
Teach-repeat accuracy (±0.03 mm) means the torch returns to any recorded point identically every cycle, ensuring consistent bead shape and no missed fusions.
Safe Collaborative Operation
Modern cells include safety features:
- Light Curtain: Infrared scanner spanning the cell entrance. If a person breaks the beam, the robot soft-stops (controlled deceleration) within 500 ms.
- Gate Interlock: Solenoid lock on the access gate. Robot motion is inhibited when the gate is open. This prevents the robot from reaching maximum speed while someone is inside.
- E-Stop: Red mushroom button triggering hardwired Category 0 stop (immediate power removal to all servo drives). Stops within 50 ms.
- Warning Beacon: LED light flashing whenever the cell is active, alerting nearby operators.
These systems allow the operator to step inside the cell during a pause or fault condition without risk of a moving robot collision.
Programming and Maintenance
Off-Line Programming: Many shops use CAD and simulation software (FANUC ROBOGUIDE, ABB RobotStudio) to program welds without accessing the robot. G-code or proprietary format is generated and downloaded to the controller. This is faster than manual teaching for large product families.
Program Editing: If a part dimension changes slightly (e.g., wall thickness ±0.5 mm), the welder adjusts current or travel speed via teach pendant and re-runs one test part. Positional data rarely needs change.
Consumable Replacement: The contact tip and nozzle wear like any torch. Replacement is tool-free (quick-change coupler); swapping takes under 1 minute. Expected life 50–100 hours at routine duty.
Servo Calibration: The servo drives for each joint should be checked quarterly. A dial indicator check at the torch tip (moving the arm in a circle and measuring runout) confirms that joint encoders are accurate. Drift exceeding 0.5 mm indicates a bearing wear or encoder issue requiring service.
Wire Feed Tension: The feeder motor pressure should be adjusted so the rubber wheel grips the wire without crushing it. Too light: wire skips. Too heavy: aluminum wire kinks. Annual pressure plate check prevents slippage.
Automation Economics
A robot cell costs 200,000–500,000 USD fully installed. The payback depends on volume:
- High volume (>10,000 units/year): Payback in 1–2 years. Cost per weld = 0.50 USD (electricity + consumables).
- Medium volume (1000–10,000/year): Payback 3–5 years. Cell cost amortizes into unit price.
- Low volume (<1000/year): Marginal or negative ROI unless weld quality defects are severe.
Most job shops use manual stations for jobs under 100 parts and program robotic cells only when the design is locked and volume justifies programming effort.
Troubleshooting
Poor weld penetration: Low current (increase setpoint), slow travel speed (increase mm/min), or wire feed not synchronized to travel (adjust wire speed ratio).
Spatter: Wet or contaminated wire, or positioner vibration during weld (tighten clamps). Clean the contact tip if spatter deposits bridge the gap.
Arc won't start: Dirty workpiece (wire-brush or grind the joint), bad ground clamp (clean contact area), or torch nozzle clogged with spatter (clean or replace).
Position repeatability drift: Servo encoder noise (shield the cable bundle in drag chain better) or joint mechanical wear (bearing preload needs reset after 5+ years of duty).
Safety relay fault: Light curtain alignment drifted (re-aim sensors), or gate position switch stuck (clean contacts). These are hardwired safety interlocks; they must pass full diagnostics before the robot is permitted to move.
Robotic Welding Cell parts and their functions
8 top-level parts · 49 parts in total · full bill of materials below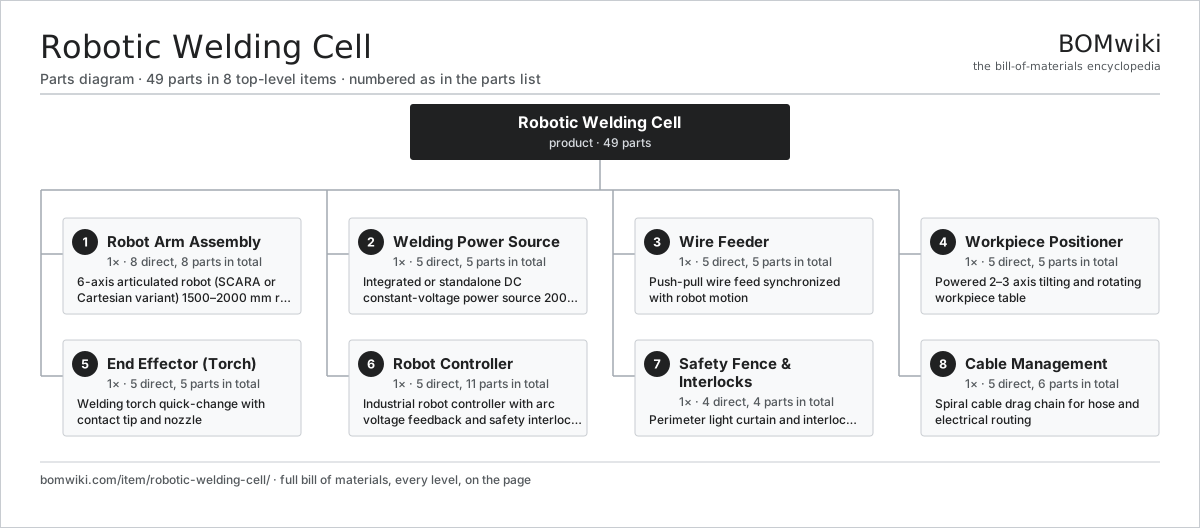
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Robot Arm Assembly 8 parts | 1× | 6-axis articulated robot (SCARA or Cartesian variant) 1500–2000 mm reach |
| 2 | Welding Power Source 5 parts | 1× | Integrated or standalone DC constant-voltage power source 200–400 A |
| 3 | Wire Feeder 5 parts | 1× | Push-pull wire feed synchronized with robot motion |
| 4 | Workpiece Positioner 5 parts | 1× | Powered 2–3 axis tilting and rotating workpiece table |
| 5 | End Effector (Torch) 5 parts | 1× | Welding torch quick-change with contact tip and nozzle |
| 6 | Robot Controller 5 parts | 1× | Industrial robot controller with arc voltage feedback and safety interlocks |
| 7 | Safety Fence & Interlocks 4 parts | 1× | Perimeter light curtain and interlocked gate for personnel protection |
| 8 | Cable Management 5 parts | 1× | Spiral cable drag chain for hose and electrical routing |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Welding Cell
8 top-level lines · 50 rows shown · 49 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Robot Arm Assembly 8 parts | robotic-welding-cell-robot-arm | 1× | 1 | 8 | assembly |
| 1.1 | Base Pedestal | robotic-welding-cell-base-pedestal | 1× | 1 | · | part |
| 1.2 | Axis 1 (Waist) | robotic-welding-cell-axis-1-joint | 1× | 1 | · | part |
| 1.3 | Axis 2 (Shoulder) | robotic-welding-cell-axis-2-joint | 1× | 1 | · | part |
| 1.4 | Axis 3 (Elbow) | robotic-welding-cell-axis-3-joint | 1× | 1 | · | part |
| 1.5 | Axis 4 (Wrist Rotation) | robotic-welding-cell-axis-4-joint | 1× | 1 | · | part |
| 1.6 | Axis 5 (Wrist Pitch) | robotic-welding-cell-axis-5-joint | 1× | 1 | · | part |
| 1.7 | Axis 6 (Wrist Roll) | robotic-welding-cell-axis-6-joint | 1× | 1 | · | part |
| 1.8 | Tool Flange | robotic-welding-cell-tool-flange | 1× | 1 | · | part |
| 2 | Welding Power Source 5 parts | robotic-welding-cell-welding-power | 1× | 1 | 5 | assembly |
| 2.1 | Power Transformer | robotic-welding-cell-power-transformer | 1× | 1 | · | part |
| 2.2 | Rectifier Module | robotic-welding-cell-rectifier | 1× | 1 | · | part |
| 2.3 | Output Reactor | robotic-welding-cell-output-reactor | 1× | 1 | · | part |
| 2.4 | Cooling Unit | robotic-welding-cell-cooling-unit | 1× | 1 | · | part |
| 2.5 | Arc Feedback Sensor | robotic-welding-cell-arc-feedback | 1× | 1 | · | part |
| 3 | Wire Feeder 5 parts | robotic-welding-cell-wire-feeder | 1× | 1 | 5 | assembly |
| 3.1 | Feeder Motor | robotic-welding-cell-feeder-motor | 1× | 1 | · | part |
| 3.2 | Feeder Drive Wheel | robotic-welding-cell-feeder-drive-wheel | 1× | 1 | · | part |
| 3.3 | Feeder Spool Brake | robotic-welding-cell-feeder-spool-brake | 1× | 1 | · | part |
| 3.4 | Wire Conduit | robotic-welding-cell-wire-conduit | 1× | 1 | · | part |
| 3.5 | Tension Arm | robotic-welding-cell-tension-arm | 1× | 1 | · | part |
| 4 | Workpiece Positioner 5 parts | robotic-welding-cell-positioner | 1× | 1 | 5 | assembly |
| 4.1 | Positioner Base | robotic-welding-cell-positioner-base | 1× | 1 | · | part |
| 4.2 | Positioner Tilt Axis | robotic-welding-cell-positioner-tilt-axis | 1× | 1 | · | part |
| 4.3 | Positioner Rotation Axis | robotic-welding-cell-positioner-rotate-axis | 1× | 1 | · | part |
| 4.4 | Positioner Table Plate | robotic-welding-cell-positioner-table-plate | 1× | 1 | · | part |
| 4.5 | Positioner Control | robotic-welding-cell-positioner-control | 1× | 1 | · | part |
| 5 | End Effector (Torch) 5 parts | robotic-welding-cell-end-effector | 1× | 1 | 5 | assembly |
| 5.1 | Torch Body | robotic-welding-cell-torch-body | 1× | 1 | · | part |
| 5.2 | Contact Tip | robotic-welding-cell-contact-tip | 1× | 1 | · | part |
| 5.3 | Gas Nozzle | robotic-welding-cell-nozzle | 1× | 1 | · | part |
| 5.4 | Torch Liner | robotic-welding-cell-torch-liner | 1× | 1 | · | part |
| 5.5 | Connector | connector | 1× | 1 | · | part |
| 6 | Robot Controller 5 parts | robotic-welding-cell-controller | 1× | 1 | 11 | assembly |
| 6.1 | Master Controller | robotic-welding-cell-master-controller | 1× | 1 | · | part |
| 6.2 | Servo Drives | robotic-welding-cell-servo-drives | 6× | 6 | · | part |
| 6.3 | Teach Pendant | robotic-welding-cell-pendant | 1× | 1 | · | part |
| 6.4 | Safety Relay | robotic-welding-cell-safety-relay | 2× | 2 | · | part |
| 6.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 7 | Safety Fence & Interlocks 4 parts | robotic-welding-cell-safety-fence | 1× | 1 | 4 | assembly |
| 7.1 | Light Curtain | robotic-welding-cell-light-curtain | 1× | 1 | · | part |
| 7.2 | Gate Interlock | robotic-welding-cell-gate-interlock | 1× | 1 | · | part |
| 7.3 | E-Stop Button | robotic-welding-cell-e-stop-button | 1× | 1 | · | part |
| 7.4 | Warning Light | robotic-welding-cell-warning-light | 1× | 1 | · | part |
| 8 | Cable Management 5 parts | robotic-welding-cell-cable-management | 1× | 1 | 6 | assembly |
| 8.1 | Drag Chain | robotic-welding-cell-drag-chain | 1× | 1 | · | part |
| 8.2 | Welding Cable | robotic-welding-cell-welding-cable | 1× | 1 | · | part |
| 8.3 | Gas Hose | robotic-welding-cell-gas-hose | 1× | 1 | · | part |
| 8.4 | Control Cable | robotic-welding-cell-control-cable | 1× | 1 | · | part |
| 8.5 | Connector | connector | 2× | 2 | · | part |
Something wrong in this list? Report a problem with this BOM.
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $10k–$1M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇩🇪DMG MORI
dmgmori.com ↗
|
Bielefeld, DE | Machine tools | 5 units | 12–20 wks |
|
🇯🇵Mazak
mazak.com ↗
|
Oguchi, JP | Machine tools | 5 units | 12–20 wks |
| haascnc.com ↗ | Oxnard, US | CNC machine tools | 5 units | 12–20 wks |
|
🇯🇵Okuma
okuma.com ↗
|
Niwa, JP | Machine tools | 5 units | 12–20 wks |
|
🇩🇪Trumpf
trumpf.com ↗
|
Ditzingen, DE | Laser & sheet-metal machines | 5 units | 12–20 wks |
1,449-word article