UV Disinfection Robot
ProductOverview
The UV disinfection robot is a recent innovation in hospital infection control, particularly adopted since the COVID-19 pandemic. Unlike manual disinfection with chemical wipes, labor-intensive, inconsistent, and time-consuming, the UV robot autonomously navigates a patient room, emitting germicidal UV-C light (254 nm) that destroys bacterial and viral nucleic acid. A single robot deployment can disinfect an ICU room between patient admissions in 15–20 minutes, achieving >99.9% pathogen reduction on exposed surfaces with no chemical residue and minimal labor.
Deployment is rapid: hospitals place a robot at bedside, activate a scheduled disinfection cycle via mobile app or remote, and the robot maps the room, positions itself optimally, and operates unattended. When the cycle completes, the robot returns to its docking station for charging and maintenance. Early-adopter hospitals report reduced nosocomial infection rates, improved operational efficiency, and high staff satisfaction.
How it Works
The nurse or environmental services staff positions the mobile chassis in the room to be disinfected. Via the remote control interface, she initiates a disinfection cycle. The main controller activates the navigation system, which uses the lidar scanner to sweep a 360° view of the room, detecting walls, furniture, and obstacles.
The navigation processor runs a simultaneous localization and mapping (SLAM) algorithm, building a 2D occupancy grid of the room's geometry and calculating collision-free paths. The robot then autonomously drives forward, sweeping the lidar as it moves, updating its map in real time.
The UV lamp array, typically four 36 W low-pressure mercury lamps or equivalent LED modules, remains off during navigation. The safety sensors, including the motion detector and bump sensor, continuously monitor for human occupancy or obstacles. If motion is detected, the controller immediately halts and disables the lamps.
Once the robot has planned a disinfection path covering the entire room, it initiates the germicidal phase. The ballast energizes the UV lamps, which emit 254 nm radiation at peak emission. The parabolic reflector directs this light downward and to the sides, creating a cone of germicidal intensity. As the robot slowly traverses the room (typically at 0.3–0.5 m/s), surfaces are exposed to cumulative UV dose calculated to exceed lethal thresholds for bacteria (typically 5–10 mJ/cm²) and enveloped viruses like SARS-CoV-2 (10–20 mJ/cm²).
The robot follows a predefined path (calculated during mapping) ensuring even coverage. High-touch surfaces, doorknobs, bed rails, monitor screens, that would be missed in manual wiping are directly illuminated. After traversing the room, the robot returns to its docking station, aligns with the charging bay via visual or magnetic guidance, and parks for automatic charging and status logging.
Safety
Multiple safety mechanisms prevent accidental UV exposure to staff. The passive infrared motion detector sweeps the room continuously; if any human is present, the lamps shut off immediately. The contact bumper surrounds the robot's base, stopping forward motion if contact is made with an obstacle. The red emergency stop button on the robot body and the remote control cuts all power instantly.
During operation, a flashing red beacon warns staff that the disinfection cycle is active. Signs are typically placed outside the room door. The robot will not activate the UV lamps until the operator confirms (via remote) that the room is empty.
Efficacy
UV-C at 254 nm causes thymine dimers in microbial DNA and RNA, rendering them non-functional. The UV lamps produce 100–150 W total output, delivering surface doses of 30–100 mJ/cm² at typical disinfection distances (0.5–2 m), far exceeding lethal thresholds for most hospital pathogens. SARS-CoV-2 (enveloped RNA virus) is susceptible to ~10–20 mJ/cm²; methicillin-resistant Staphylococcus aureus (MRSA) requires ~5–10 mJ/cm²; Clostridioides difficile spores are more resistant (~30 mJ/cm²) but still killed at typical robot doses.
Published studies (e.g., Pegues et al., Infection Control & Hospital Epidemiology) show a single 15-minute robot disinfection cycle reduces viable pathogens on high-touch surfaces by >99.9% and reduces post-patient contamination-related infections by 10–20% compared to standard chemical cleaning alone.
Limitations
UV-C does not penetrate opaque materials. Pathogens hidden in biofilm under mattresses or inside equipment crevices are not directly exposed. Some hospitals combine UV robot deployment with hydrogen peroxide vapor (HPV) disinfection systems for maximum efficacy on high-risk pathogens or during outbreak response.
Additionally, the robot requires a fully enclosed room with doors closed. Open-plan ICUs with curtain dividers cannot be effectively disinfected by a single robot. Multi-room disinfection requires multiple robots or sequential room-by-room deployment.
Finally, the UV lamps degrade over time, typically requiring replacement every 8,000–10,000 operating hours. The docking station provides a maintenance tray for safe lamp cartridge replacement without direct operator UV exposure.
Integration with Infection Prevention
Most modern robots integrate with hospital WiFi and cloud backends. The scheduling app allows the infection prevention or environmental services department to queue disinfection cycles for rooms post-discharge. Over time, the system logs cumulative disinfection history per room, supporting compliance audits and outbreak investigations. Some integration platforms automatically trigger a robot deployment when a patient with a contact-precaution pathogen (e.g., VRE, MRSA) is discharged.
UV Disinfection Robot parts and their functions
8 top-level parts · 60 parts in total · full bill of materials below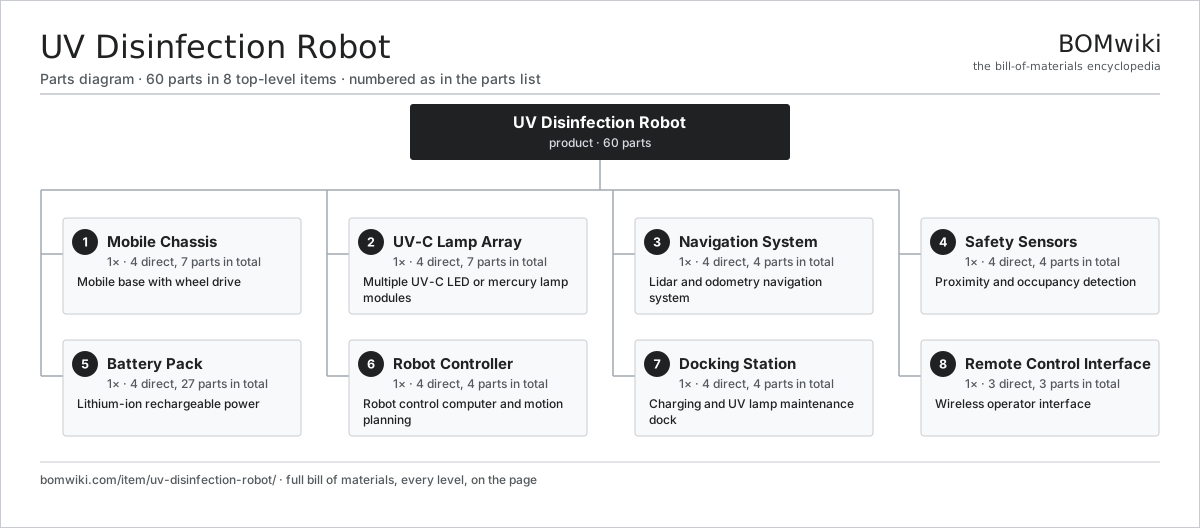
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Mobile Chassis 4 parts | 1× | Mobile base with wheel drive |
| 2 | UV-C Lamp Array 4 parts | 1× | Multiple UV-C LED or mercury lamp modules |
| 3 | Navigation System 4 parts | 1× | Lidar and odometry navigation system |
| 4 | Safety Sensors 4 parts | 1× | Proximity and occupancy detection |
| 5 | Battery Pack 4 parts | 1× | Lithium-ion rechargeable power |
| 6 | Robot Controller 4 parts | 1× | Robot control computer and motion planning |
| 7 | Docking Station 4 parts | 1× | Charging and UV lamp maintenance dock |
| 8 | Remote Control Interface 3 parts | 1× | Wireless operator interface |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for UV Disinfection Robot
8 top-level lines · 39 rows shown · 60 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Mobile Chassis 4 parts | uv-disinfection-robot-chassis | 1× | 1 | 7 | assembly |
| 1.1 | Frame Body | uv-disinfection-robot-frame-body | 1× | 1 | · | part |
| 1.2 | Wheel Assembly | uv-disinfection-robot-wheel-assembly | 4× | 4 | · | part |
| 1.3 | Motor Controller | uv-disinfection-robot-motor-controller | 1× | 1 | · | part |
| 1.4 | Suspension | uv-disinfection-robot-suspension | 1× | 1 | · | part |
| 2 | UV-C Lamp Array 4 parts | uv-disinfection-robot-lamp-array | 1× | 1 | 7 | assembly |
| 2.1 | UV Lamp Module | uv-disinfection-robot-lamp-modules | 4× | 4 | · | part |
| 2.2 | Reflector Shield | uv-disinfection-robot-reflector-shield | 1× | 1 | · | part |
| 2.3 | Ballast Supply | uv-disinfection-robot-ballast-supply | 1× | 1 | · | part |
| 2.4 | Safety Shutoff | uv-disinfection-robot-safety-shutoff | 1× | 1 | · | part |
| 3 | Navigation System 4 parts | uv-disinfection-robot-lidar-nav | 1× | 1 | 4 | assembly |
| 3.1 | Lidar Unit | uv-disinfection-robot-lidar-unit | 1× | 1 | · | part |
| 3.2 | IMU Odometry | uv-disinfection-robot-imu-odometry | 1× | 1 | · | part |
| 3.3 | Navigation Processor | uv-disinfection-robot-nav-computer | 1× | 1 | · | part |
| 3.4 | Mapping Firmware | uv-disinfection-robot-mapping-firmware | 1× | 1 | · | part |
| 4 | Safety Sensors 4 parts | uv-disinfection-robot-safety-sensors | 1× | 1 | 4 | assembly |
| 4.1 | Motion Detector | uv-disinfection-robot-motion-detector | 1× | 1 | · | part |
| 4.2 | Bump Sensor | uv-disinfection-robot-bump-sensor | 1× | 1 | · | part |
| 4.3 | Emergency Stop | uv-disinfection-robot-emergency-button | 1× | 1 | · | part |
| 4.4 | Alarm Beacon | uv-disinfection-robot-alarm-light | 1× | 1 | · | part |
| 5 | Battery Pack 4 parts | uv-disinfection-robot-battery-pack | 1× | 1 | 27 | assembly |
| 5.1 | Li-ion Cell, 18650 | li-cell-18650 | 24× | 24 | · | part |
| 5.2 | BMS Board | uv-disinfection-robot-bms-board | 1× | 1 | · | part |
| 5.3 | Charger Module | uv-disinfection-robot-charger-module | 1× | 1 | · | part |
| 5.4 | Voltage Converter | uv-disinfection-robot-voltage-converter | 1× | 1 | · | part |
| 6 | Robot Controller 4 parts | uv-disinfection-robot-controller | 1× | 1 | 4 | assembly |
| 6.1 | Main CPU | uv-disinfection-robot-main-cpu | 1× | 1 | · | part |
| 6.2 | Wireless Radio | uv-disinfection-robot-wireless-radio | 1× | 1 | · | part |
| 6.3 | Relay Board | uv-disinfection-robot-relay-board | 1× | 1 | · | part |
| 6.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 7 | Docking Station 4 parts | uv-disinfection-robot-docking-station | 1× | 1 | 4 | assembly |
| 7.1 | Dock Frame | uv-disinfection-robot-dock-frame | 1× | 1 | · | part |
| 7.2 | Charging Contacts | uv-disinfection-robot-charging-contacts | 1× | 1 | · | part |
| 7.3 | Lamp Tray | uv-disinfection-robot-lamp-maintenance-tray | 1× | 1 | · | part |
| 7.4 | Dock Power | uv-disinfection-robot-power-converter | 1× | 1 | · | part |
| 8 | Remote Control Interface 3 parts | uv-disinfection-robot-remote-control | 1× | 1 | 3 | assembly |
| 8.1 | RC Handset | uv-disinfection-robot-rc-handset | 1× | 1 | · | part |
| 8.2 | Scheduling App | uv-disinfection-robot-scheduling-app | 1× | 1 | · | part |
| 8.3 | Status Display | uv-disinfection-robot-status-display | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Blood Pressure Monitor
173 parts · shares 1 with this page
 Defibrillator
677 parts · shares 1 with this page
 Fetal Doppler
41 parts · shares 1 with this page
 Holter ECG Monitor
55 parts · shares 1 with this page
Infant Scale
66 parts · shares 1 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $500–$3M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| gehealthcare.com ↗ | Chicago, US | Medical imaging & devices | 100 units | 12–20 wks |
| siemens-healthineers.com ↗ | Erlangen, DE | Medical systems | 100 units | 12–20 wks |
|
🇳🇱Philips
philips.com ↗
|
Amsterdam, NL | Health technology | 100 units | 12–20 wks |
| medtronic.com ↗ | Minneapolis, US | Medical devices | 100 units | 12–20 wks |
|
🇨🇳Mindray
mindray.com ↗
|
Shenzhen, CN | Medical devices | 100 units | 12–20 wks |
981-word article