Cartesian Gantry Robot
ProductOverview
A Cartesian gantry robot positions a tool anywhere inside a rectangular box by stacking three linear axes at right angles, one for each coordinate of space. Unlike a jointed arm, every axis moves in a straight line, so the kinematics are trivial: the X, Y, and Z commands map directly to the three motor positions with no trigonometry. That makes the gantry accurate over a large footprint and easy to program, which is why it dominates pick-and-place, machine tending, dispensing, and inspection where the work is laid out on a flat plane or a shallow pallet. The whole machine hangs from an overhead Gantry Frame so the floor underneath stays clear for parts, fixtures, and conveyors.
How it works
The three axes are built from the same parts in different combinations. The long X Linear Axis bridge uses a steel-cord timing belt because belts move fast over a long stroke without a heavy rotating screw; the shorter Y Linear Axis and vertical Z Linear Axis use a Ball Screw, which trades top speed for stiffness and fine resolution. Each axis rides on profiled Linear Guide rails and is driven by an AC AC Servo Motor whose Servo Encoder closes the position loop through a Servo Drive amplifier. The Z axis adds a spring-applied brake so the tool cannot fall when power is cut.
The tool itself bolts to the End-Effector Mount plate, which here carries a pneumatic parallel gripper but accepts any tool with the right bolt pattern. Power, feedback, and air reach the moving carriages through a Cable Carrier energy chain that flexes with the stroke. A Controller Cabinet cabinet houses the motion compute, one servo drive per axis, and field I/O; it interpolates the three axes together to draw straight lines and arcs through the work envelope. An operator jogs the machine and edits programs from the Teach Pendant, a rugged touchscreen with an emergency stop and an enabling switch for safe manual motion.
Cartesian Gantry Robot parts and their functions
8 top-level parts · 1,051 parts in total · full bill of materials below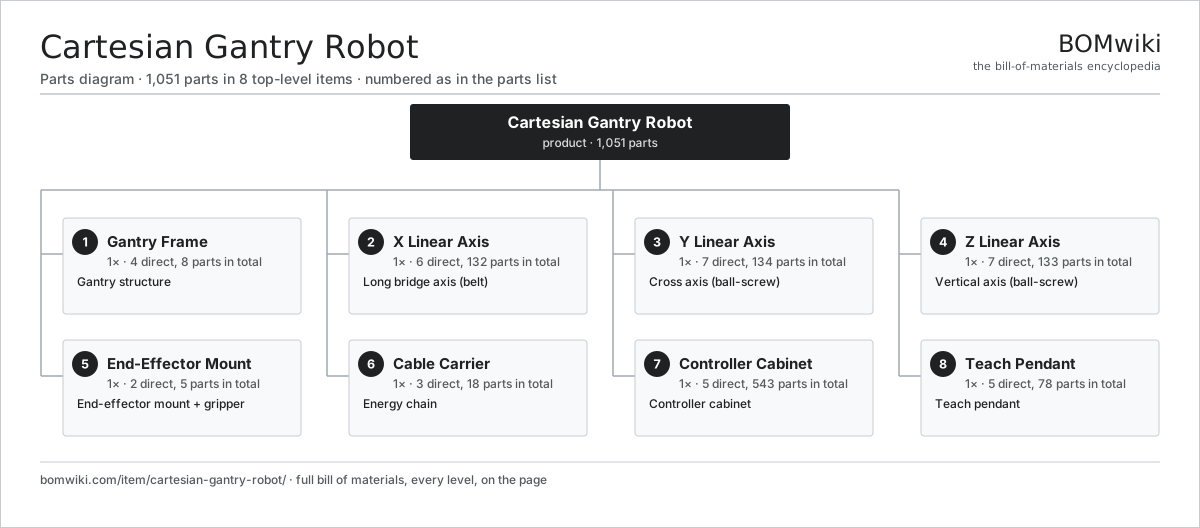
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Gantry Frame 4 parts | 1× | Gantry structure |
| 2 | X Linear Axis 6 parts | 1× | Long bridge axis (belt) |
| 3 | Y Linear Axis 7 parts | 1× | Cross axis (ball-screw) |
| 4 | Z Linear Axis 7 parts | 1× | Vertical axis (ball-screw) |
| 5 | End-Effector Mount 2 parts | 1× | End-effector mount + gripper |
| 6 | Cable Carrier 3 parts | 1× | Energy chain |
| 7 | Controller Cabinet 5 parts | 1× | Controller cabinet |
| 8 | Teach Pendant 5 parts | 1× | Teach pendant |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Cartesian Gantry Robot
8 top-level lines · 113 rows shown · 1,051 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Gantry Frame 4 parts | cartesian-gantry-robot-frame | 1× | 1 | 8 | assembly |
| 1.1 | Support Column | cartesian-gantry-robot-column | 4× | 4 | · | part |
| 1.2 | Bridge Crossbeam | cartesian-gantry-robot-crossbeam | 2× | 2 | · | part |
| 1.3 | Baseplate | cartesian-gantry-robot-baseplate | 1× | 1 | · | part |
| 1.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | X Linear Axis 6 parts | cartesian-gantry-robot-x-axis | 1× | 1 | 132 | assembly |
| 2.1 | Timing-Belt Drive 3 parts | cartesian-gantry-robot-belt-drive | 1× | 1 | 5 | assembly |
| 2.1.1 | Timing Belt | cartesian-gantry-robot-timing-belt | 1× | 1 | · | part |
| 2.1.2 | Drive Pulley | cartesian-gantry-robot-pulley | 2× | 2 | · | part |
| 2.1.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.2 | Linear Guide | cartesian-gantry-robot-linear-guide | 2× | 2 | · | part |
| 2.3 | AC Servo Motor 6 parts | cartesian-gantry-robot-servo-motor | 1× | 1 | 34 | assembly |
| 2.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.3.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 2.3.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 2.3.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 2.3.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.4 | Servo Encoder 3 parts | cartesian-gantry-robot-encoder | 1× | 1 | 4 | assembly |
| 2.4.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 2.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.4.3 | Code Disc | cartesian-gantry-robot-encoder-disc | 1× | 1 | · | part |
| 2.5 | Servo Drive 4 parts | cartesian-gantry-robot-servo-drive | 1× | 1 | 85 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.5.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 2.5.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 2.5.4 | Connector | connector | 3× | 3 | · | part |
| 2.6 | Limit Switch | cartesian-gantry-robot-limit-switch | 2× | 2 | · | part |
| 3 | Y Linear Axis 7 parts | cartesian-gantry-robot-y-axis | 1× | 1 | 134 | assembly |
| 3.1 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 3.2 | Screw Support Bearing 2 parts | cartesian-gantry-robot-screw-support | 2× | 2 | 3 | assembly |
| 3.2.1 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 3.2.2 | Support Block | cartesian-gantry-robot-support-block | 1× | 2 | · | part |
| 3.3 | Linear Guide | cartesian-gantry-robot-linear-guide | 2× | 2 | · | part |
| 3.4 | AC Servo Motor 6 parts | cartesian-gantry-robot-servo-motor | 1× | 1 | 34 | assembly |
| 3.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 3.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 3.4.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 3.4.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 3.4.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 3.4.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.5 | Servo Encoder 3 parts | cartesian-gantry-robot-encoder | 1× | 1 | 4 | assembly |
| 3.5.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 3.5.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.5.3 | Code Disc | cartesian-gantry-robot-encoder-disc | 1× | 1 | · | part |
| 3.6 | Servo Drive 4 parts | cartesian-gantry-robot-servo-drive | 1× | 1 | 85 | assembly |
| 3.6.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.6.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 3.6.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 3.6.4 | Connector | connector | 3× | 3 | · | part |
| 3.7 | Limit Switch | cartesian-gantry-robot-limit-switch | 2× | 2 | · | part |
| 4 | Z Linear Axis 7 parts | cartesian-gantry-robot-z-axis | 1× | 1 | 133 | assembly |
| 4.1 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 4.2 | Screw Support Bearing 2 parts | cartesian-gantry-robot-screw-support | 2× | 2 | 3 | assembly |
| 4.2.1 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 4.2.2 | Support Block | cartesian-gantry-robot-support-block | 1× | 2 | · | part |
| 4.3 | Linear Guide | cartesian-gantry-robot-linear-guide | 2× | 2 | · | part |
| 4.4 | AC Servo Motor 6 parts | cartesian-gantry-robot-servo-motor | 1× | 1 | 34 | assembly |
| 4.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 4.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 4.4.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 4.4.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 4.4.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 4.4.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 4.5 | Servo Encoder 3 parts | cartesian-gantry-robot-encoder | 1× | 1 | 4 | assembly |
| 4.5.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 4.5.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.5.3 | Code Disc | cartesian-gantry-robot-encoder-disc | 1× | 1 | · | part |
| 4.6 | Servo Drive 4 parts | cartesian-gantry-robot-servo-drive | 1× | 1 | 85 | assembly |
| 4.6.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.6.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 4.6.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 4.6.4 | Connector | connector | 3× | 3 | · | part |
| 4.7 | Axis Holding Brake | cartesian-gantry-robot-z-brake | 1× | 1 | · | part |
| 5 | End-Effector Mount 2 parts | cartesian-gantry-robot-effector | 1× | 1 | 5 | assembly |
| 5.1 | Tool Plate | cartesian-gantry-robot-tool-plate | 1× | 1 | · | part |
| 5.2 | Parallel Gripper 3 parts | cartesian-gantry-robot-gripper | 1× | 1 | 4 | assembly |
| 5.2.1 | Gripper Cylinder | cartesian-gantry-robot-gripper-cylinder | 1× | 1 | · | part |
| 5.2.2 | Gripper Finger | cartesian-gantry-robot-gripper-finger | 2× | 2 | · | part |
| 5.2.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 6 | Cable Carrier 3 parts | cartesian-gantry-robot-cable-carrier | 1× | 1 | 18 | assembly |
| 6.1 | Energy Chain | cartesian-gantry-robot-energy-chain | 1× | 1 | · | part |
| 6.2 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 6.3 | Connector | connector | 16× | 16 | · | part |
| 7 | Controller Cabinet 5 parts | cartesian-gantry-robot-controller | 1× | 1 | 543 | assembly |
| 7.1 | Motion Controller 5 parts | cartesian-gantry-robot-motion-board | 1× | 1 | 211 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.1.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.1.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 7.1.5 | Connector | connector | 8× | 8 | · | part |
| 7.2 | Servo Drive 4 parts | cartesian-gantry-robot-servo-drive | 3× | 3 | 85 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 3 | · | part |
| 7.2.2 | IGBT Power Module | igbt-module | 1× | 3 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 80× | 240 | · | part |
| 7.2.4 | Connector | connector | 3× | 9 | · | part |
| 7.3 | I/O Board 4 parts | cartesian-gantry-robot-io-board | 1× | 1 | 75 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.3.2 | Relay | relay | 8× | 8 | · | part |
| 7.3.3 | Connector | connector | 6× | 6 | · | part |
| 7.3.4 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 7.4 | Power Supply | cartesian-gantry-robot-power-supply | 1× | 1 | · | part |
| 7.5 | Cabinet Frame | cartesian-gantry-robot-cabinet-frame | 1× | 1 | · | part |
| 8 | Teach Pendant 5 parts | cartesian-gantry-robot-pendant | 1× | 1 | 78 | assembly |
| 8.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.3 | Pendant Board 4 parts | cartesian-gantry-robot-pendant-board | 1× | 1 | 74 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 8.3.4 | Connector | connector | 2× | 2 | · | part |
| 8.4 | E-Stop & Enable | cartesian-gantry-robot-estop | 1× | 1 | · | part |
| 8.5 | Pendant Shell | cartesian-gantry-robot-pendant-shell | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 7 with this page
Adhesive Dispensing Robot
685 parts · shares 6 with this page
Robotic Grinding Cell
1,419 parts · shares 6 with this page
Polishing/Grinding Robot
1,752 parts · shares 6 with this page
Robotic Deburring Cell
1,637 parts · shares 6 with this page
Sealant Dispensing Robot
2,056 parts · shares 6 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
359-word article