Drywall Finishing Robot
ProductOverview
A drywall finishing robot automates the mudding and taping process on vertical walls by combining vertical lift, automated spray application, and mechanical feathering in one mobile system. The robot grips a lift column, positioning a spray and trowel head at any height from 0 to 4 m. Its seam-detection camera identifies panel joints via edge contrast and a laser stripe, then drives the peristaltic pump to spray a bead of joint compound onto the seam. Immediately after, a pneumatic oscillating trowel smooths the wet compound into a feathered edge, blending the seam invisible at eye level.
Typical workflow: the operator mounts the hopper tank on the robot or nearby and loads fresh compound from a job-site mixer. The robot then traverses a wall section autonomously, spraying and troweling each joint in sequence. A single robot can finish 200–300 linear meters of seam per 8-hour shift, dramatically faster than hand-taping crews and with superior consistency.
Vertical lift and positioning
The lift column is a precision ballscrew (16 mm pitch) driven by a NEMA 34 stepper motor at 0.1–0.5 m/s travel. A spring counterweight assists gravity, reducing motor duty; the position encoder provides closed-loop feedback confirming height within ±10 mm. The robot carries its own 48 V battery, so no external power cord limits mobility. Overhead clearance and wall proximity are detected by the on-board inertial sensors and the seam camera, preventing collisions with ceiling joists or adjacent equipment.
The mobile base uses four steered wheels for omnidirectional translation along the wall, keeping the lift column perpendicular to the seam plane. A laser crosshair projects horizontal and vertical reference lines helping the operator align the robot to panel edges.
Compound application and troweling
The peristaltic pump draws hot compound from the on-board heated tank and delivers it via soft tubing to the spray nozzle. A solenoid valve gates flow, opened only during downward passes. The spray tip creates a flat fan pattern, depositing a 0.3–0.6 m wide bead at 0.5–1.5 L/min depending on coat thickness.
Immediately after spraying, the pneumatic trowel blade (100 Hz oscillation) descends through the wet compound under light spring pressure (30–50 N), feathering the edges. The blade angle and downward speed are adjustable: thick mud (taping coat) moves slower, finishing coat moves faster for a thinner feather. The controller orchestrates the timing precisely, spray stops, trowel engages, carriage descends 0.1 m, trowel retracts, spray resumes at the next seam above.
Seam detection and wall tracking
The RGB camera on the spray head sees the wall at ~40 cm standoff. A neural model detects the vertical dark line marking a drywall seam (the joint between two 4' × 8' sheets) with 95 % confidence. The laser light stripe (perpendicular to the seam line) highlights the 3D wall surface, allowing the vision pipeline to compute seam centerline to sub-pixel precision. The SoC then nudges the head left/right to center the spray nozzle over the seam, correcting for wall waviness or robot drift.
If a seam is off-vertical (angled or bowed), the system detects it and adjusts spray angle or trowel pressure to maintain joint consistency. The system also recognizes electrical outlets, fixtures, and window openings, pausing the spray until the head clears the obstruction.
Compound handling and heating
The 20 L tank is insulated and fitted with an immersion heating element maintaining compound at ~50 °C. At this temperature, drywall mud flows at optimal viscosity (1,200–2,000 cP depending on coat). A low-speed stirrer prevents settling during the job; the operator can live-refill the tank from a job-site mixer via a gravity inlet, no need to interrupt work.
The pump motor speed is proportional to seam width, allowing one spray pattern for all coat types. Waste compound drips back down the wall; the operator or a helper can catch and recycle it into the tank.
Battery and workflow
The 48 V 240 Ah LiFePO4 pack (11.5 kWh) powers the lift motor (intermittent, ~100 W lifting), pump motor (proportional, 50–200 W), and solenoids (20 W). At typical duty, endurance is 8–10 hours per charge, a full shift on one battery, with overnight shore charging (480 VAC 3-phase, 4 hour recharge).
A single operator manages the robot via a rugged tablet interface, loading the compound hopper and inputting wall dimensions. For long walls, the robot auto-sequences: spray and trowel all seams at height H, translate to height H+0.5 m, repeat. Complex patterns (e.g., arched walls, curved corners) can be taught by hand-guiding the head, and the robot records and replays the path.
Drywall Finishing Robot parts and their functions
10 top-level parts · 179 parts in total · full bill of materials below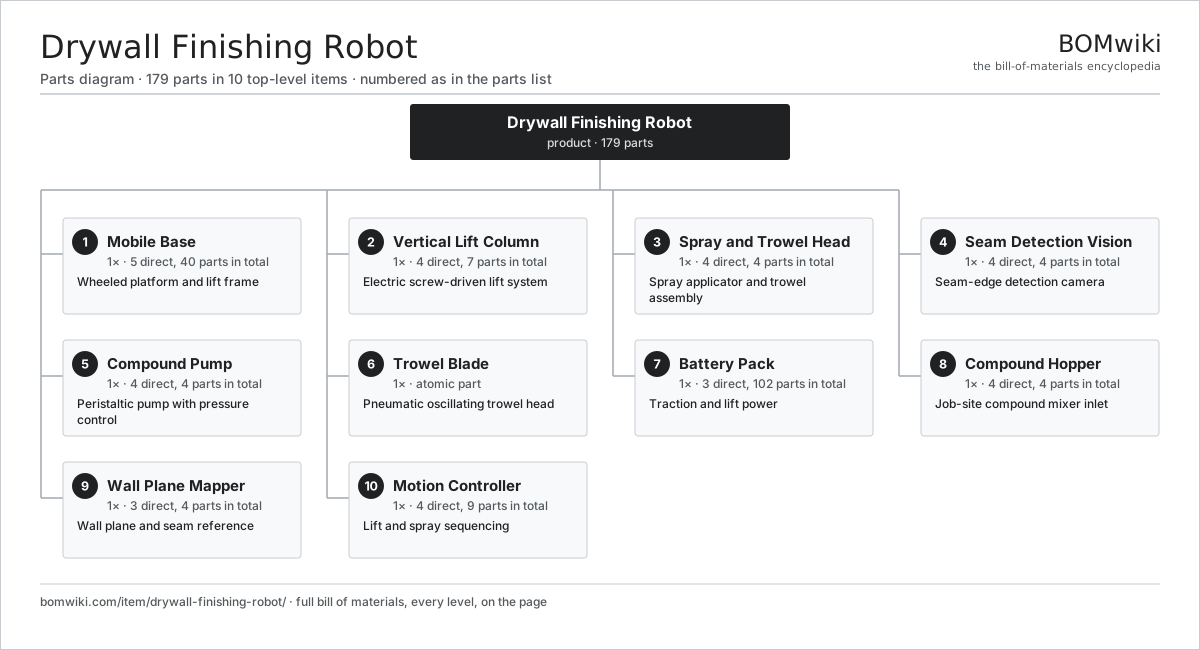
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Mobile Base 5 parts | 1× | Wheeled platform and lift frame |
| 2 | Vertical Lift Column 4 parts | 1× | Electric screw-driven lift system |
| 3 | Spray and Trowel Head 4 parts | 1× | Spray applicator and trowel assembly |
| 4 | Seam Detection Vision 4 parts | 1× | Seam-edge detection camera |
| 5 | Compound Pump 4 parts | 1× | Peristaltic pump with pressure control |
| 6 | Trowel Blade | 1× | Pneumatic oscillating trowel head |
| 7 | Battery Pack 3 parts | 1× | Traction and lift power |
| 8 | Compound Hopper 4 parts | 1× | Job-site compound mixer inlet |
| 9 | Wall Plane Mapper 3 parts | 1× | Wall plane and seam reference |
| 10 | Motion Controller 4 parts | 1× | Lift and spray sequencing |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Drywall Finishing Robot
10 top-level lines · 53 rows shown · 179 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Mobile Base 5 parts | drywall-finishing-robot-base | 1× | 1 | 40 | assembly |
| 1.1 | Base Frame | drywall-finishing-robot-frame-base | 1× | 1 | · | part |
| 1.2 | Wheel Assembly 5 parts | wheel-assembly | 4× | 4 | 9 | assembly |
| 1.2.1 | Alloy Wheel | alloy-wheel | 1× | 4 | · | part |
| 1.2.2 | Tire | tire | 1× | 4 | · | part |
| 1.2.3 | TPMS Sensor | tpms-sensor | 1× | 4 | · | part |
| 1.2.4 | Lug Nut | lug-nut | 5× | 20 | · | part |
| 1.2.5 | Valve Stem | valve-stem | 1× | 4 | · | part |
| 1.3 | Lift Screw | drywall-finishing-robot-lift-screw | 1× | 1 | · | part |
| 1.4 | Column Carriage | drywall-finishing-robot-column-carriage | 1× | 1 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Vertical Lift Column 4 parts | drywall-finishing-robot-vertical-column | 1× | 1 | 7 | assembly |
| 2.1 | Lift Motor | drywall-finishing-robot-lift-motor | 1× | 1 | · | part |
| 2.2 | Lift Encoder | drywall-finishing-robot-lift-encoder | 1× | 1 | · | part |
| 2.3 | Counterweight Spring | drywall-finishing-robot-counterweight | 1× | 1 | · | part |
| 2.4 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 3 | Spray and Trowel Head 4 parts | drywall-finishing-robot-head | 1× | 1 | 4 | assembly |
| 3.1 | Spray Nozzle | drywall-finishing-robot-spray-nozzle | 1× | 1 | · | part |
| 3.2 | Trowel Arm | drywall-finishing-robot-trowel-arm | 1× | 1 | · | part |
| 3.3 | Trowel Blade | drywall-finishing-robot-trowel-blade | 1× | 1 | · | part |
| 3.4 | Head Solenoid | drywall-finishing-robot-head-solenoid | 1× | 1 | · | part |
| 4 | Seam Detection Vision 4 parts | drywall-finishing-robot-vision | 1× | 1 | 4 | assembly |
| 4.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 4.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 4.3 | Seam Light | drywall-finishing-robot-light-stripe | 1× | 1 | · | part |
| 4.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5 | Compound Pump 4 parts | drywall-finishing-robot-compound-pump | 1× | 1 | 4 | assembly |
| 5.1 | Pump Motor | drywall-finishing-robot-pump-motor | 1× | 1 | · | part |
| 5.2 | Peristaltic Pump Head | drywall-finishing-robot-pump-peristaltic | 1× | 1 | · | part |
| 5.3 | Pump Hose | drywall-finishing-robot-pump-hose | 1× | 1 | · | part |
| 5.4 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 6 | Trowel Blade | drywall-finishing-robot-trowel-blade | 1× | 1 | · | part |
| 7 | Battery Pack 3 parts | drywall-finishing-robot-battery | 1× | 1 | 102 | assembly |
| 7.1 | Li-ion Cell, 18650 | li-cell-18650 | 100× | 100 | · | part |
| 7.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 7.3 | Battery Case | drywall-finishing-robot-battery-case | 1× | 1 | · | part |
| 8 | Compound Hopper 4 parts | drywall-finishing-robot-compound-hopper | 1× | 1 | 4 | assembly |
| 8.1 | Hopper Tank | drywall-finishing-robot-hopper-tank | 1× | 1 | · | part |
| 8.2 | Tank Heater | drywall-finishing-robot-hopper-heater | 1× | 1 | · | part |
| 8.3 | Hopper Stirrer | drywall-finishing-robot-hopper-stirrer | 1× | 1 | · | part |
| 8.4 | Thermal Fuse | thermal-fuse | 1× | 1 | · | part |
| 9 | Wall Plane Mapper 3 parts | drywall-finishing-robot-laser-mapping | 1× | 1 | 4 | assembly |
| 9.1 | Crosshair Laser | drywall-finishing-robot-laser-crosshair | 2× | 2 | · | part |
| 9.2 | IMU Module | imu-module | 1× | 1 | · | part |
| 9.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 10 | Motion Controller 4 parts | drywall-finishing-robot-controller | 1× | 1 | 9 | assembly |
| 10.1 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 10.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 10.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 10.4 | I/O Board 3 parts | drywall-finishing-robot-io-board | 1× | 1 | 6 | assembly |
| 10.4.1 | Stepper Driver | stepper-driver | 1× | 1 | · | part |
| 10.4.2 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 10.4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Bricklaying Robot
221 parts · shares 11 with this page
 Fruit Picking Robot
144 parts · shares 12 with this page
Security Patrol Robot
582 parts · shares 12 with this page
 Telepresence Robot
240 parts · shares 11 with this page
Autonomous Forklift
342 parts · shares 11 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
927-word article