Powered Exoskeleton
ProductOverview
A powered exoskeleton is a wearable robot that straps to a person's legs and adds torque at the joints they cannot drive on their own. It is used in rehabilitation, to let people with spinal injury or stroke stand and walk again, and in industry, to carry load off a worker's body during lifting or overhead work. The machine is a partner rather than a vehicle: it must read what the wearer is trying to do and assist in time, because a step it mistimes is worse than no assistance at all. An Frame & Cuffs transfers weight to the ground through cuffs and struts adjusted to the user, while powered hip and knee joints supply the muscle.
How it works
Each leg carries two actuated joints, an Hip Actuator and an Knee Actuator, built on the same design: a compact Servo Motor feeds a thin, near-zero-backlash Harmonic Reducer so the joint is both strong and back-drivable. A joint encoder reports angle and an Joint Torque Sensor reports the actual torque between the machine and the limb, which is what lets the controller assist a motion the wearer starts rather than forcing one. A local joint drive closes the current loop at each actuator.
The robot infers the wearer's intent from sensing rather than from a joystick. Instrumented Foot Plate soles detect heel-strike and toe-off, and an IMU Suite tracks the orientation of the trunk and limb segments. The Gait Controller fuses these streams into a gait state machine that decides when to flex, extend, and hold each joint through a step. An Battery Pack pack of cylindrical cells supplies a few hours of walking and clips to the spine strut for hot-swapping. The user picks sit, stand, or walk modes from a small User HMI, and the whole body of actuators and sensors is wired together by a flexible Body Harness harness that moves with the frame.
Powered Exoskeleton parts and their functions
9 top-level parts · 744 parts in total · full bill of materials below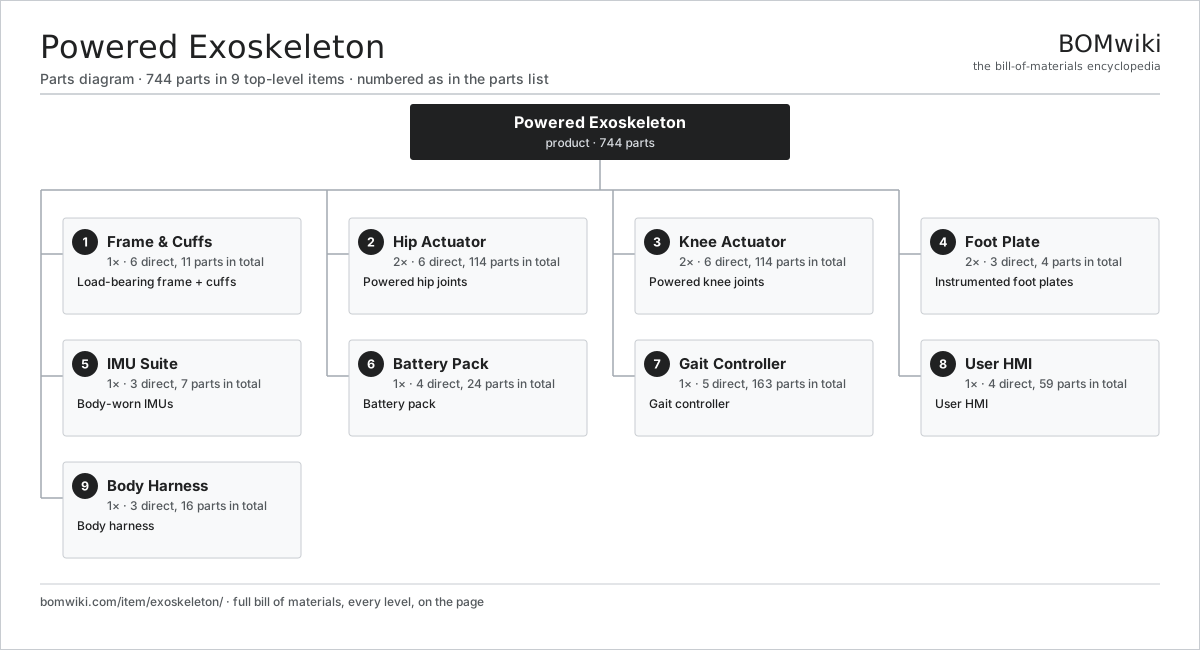
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Frame & Cuffs 6 parts | 1× | Load-bearing frame + cuffs |
| 2 | Hip Actuator 6 parts | 2× | Powered hip joints |
| 3 | Knee Actuator 6 parts | 2× | Powered knee joints |
| 4 | Foot Plate 3 parts | 2× | Instrumented foot plates |
| 5 | IMU Suite 3 parts | 1× | Body-worn IMUs |
| 6 | Battery Pack 4 parts | 1× | Battery pack |
| 7 | Gait Controller 5 parts | 1× | Gait controller |
| 8 | User HMI 4 parts | 1× | User HMI |
| 9 | Body Harness 3 parts | 1× | Body harness |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Powered Exoskeleton
9 top-level lines · 93 rows shown · 744 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Frame & Cuffs 6 parts | exoskeleton-frame | 1× | 1 | 11 | assembly |
| 1.1 | Spine & Pelvis Strut | exoskeleton-spine-strut | 1× | 1 | · | part |
| 1.2 | Thigh Strut | exoskeleton-thigh-strut | 2× | 2 | · | part |
| 1.3 | Shank Strut | exoskeleton-shank-strut | 2× | 2 | · | part |
| 1.4 | Limb Cuff | exoskeleton-cuff | 4× | 4 | · | part |
| 1.5 | Strap Set | exoskeleton-strap-set | 1× | 1 | · | part |
| 1.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Hip Actuator 6 parts | exoskeleton-hip-actuator | 2× | 2 | 114 | assembly |
| 2.1 | Servo Motor 5 parts | exoskeleton-actuator-motor | 1× | 2 | 32 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.1.3 | Copper Winding | copper-winding | 1× | 2 | · | part |
| 2.1.4 | Neodymium Magnet | neodymium-magnet | 8× | 16 | · | part |
| 2.1.5 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 2.2 | Harmonic Reducer 4 parts | exoskeleton-harmonic-reducer | 1× | 2 | 5 | assembly |
| 2.2.1 | Gearbox Housing | gearbox-housing | 1× | 2 | · | part |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 2.2.3 | Wave Generator | exoskeleton-wave-generator | 1× | 2 | · | part |
| 2.2.4 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.3 | Joint Encoder 3 parts | exoskeleton-joint-encoder | 1× | 2 | 4 | assembly |
| 2.3.1 | Hall Sensor | hall-sensor | 2× | 4 | · | part |
| 2.3.2 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.3.3 | Code Disc | exoskeleton-encoder-disc | 1× | 2 | · | part |
| 2.4 | Joint Torque Sensor 3 parts | exoskeleton-torque-sensor | 1× | 2 | 6 | assembly |
| 2.4.1 | Torque Flexure | exoskeleton-torque-flexure | 1× | 2 | · | part |
| 2.4.2 | Strain Gauge | exoskeleton-strain-gauge | 4× | 8 | · | part |
| 2.4.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.5 | Joint Drive 5 parts | exoskeleton-joint-drive | 1× | 2 | 65 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.5.2 | IGBT Power Module | igbt-module | 1× | 2 | · | part |
| 2.5.3 | Microcontroller | mcu | 1× | 2 | · | part |
| 2.5.4 | SMD Passive (R/C/L) | smd-passives | 60× | 120 | · | part |
| 2.5.5 | Connector | connector | 2× | 4 | · | part |
| 2.6 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 3 | Knee Actuator 6 parts | exoskeleton-knee-actuator | 2× | 2 | 114 | assembly |
| 3.1 | Servo Motor 5 parts | exoskeleton-actuator-motor | 1× | 2 | 32 | assembly |
| 3.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 3.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 3.1.3 | Copper Winding | copper-winding | 1× | 2 | · | part |
| 3.1.4 | Neodymium Magnet | neodymium-magnet | 8× | 16 | · | part |
| 3.1.5 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 3.2 | Harmonic Reducer 4 parts | exoskeleton-harmonic-reducer | 1× | 2 | 5 | assembly |
| 3.2.1 | Gearbox Housing | gearbox-housing | 1× | 2 | · | part |
| 3.2.2 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 3.2.3 | Wave Generator | exoskeleton-wave-generator | 1× | 2 | · | part |
| 3.2.4 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 3.3 | Joint Encoder 3 parts | exoskeleton-joint-encoder | 1× | 2 | 4 | assembly |
| 3.3.1 | Hall Sensor | hall-sensor | 2× | 4 | · | part |
| 3.3.2 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 3.3.3 | Code Disc | exoskeleton-encoder-disc | 1× | 2 | · | part |
| 3.4 | Joint Torque Sensor 3 parts | exoskeleton-torque-sensor | 1× | 2 | 6 | assembly |
| 3.4.1 | Torque Flexure | exoskeleton-torque-flexure | 1× | 2 | · | part |
| 3.4.2 | Strain Gauge | exoskeleton-strain-gauge | 4× | 8 | · | part |
| 3.4.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 3.5 | Joint Drive 5 parts | exoskeleton-joint-drive | 1× | 2 | 65 | assembly |
| 3.5.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 3.5.2 | IGBT Power Module | igbt-module | 1× | 2 | · | part |
| 3.5.3 | Microcontroller | mcu | 1× | 2 | · | part |
| 3.5.4 | SMD Passive (R/C/L) | smd-passives | 60× | 120 | · | part |
| 3.5.5 | Connector | connector | 2× | 4 | · | part |
| 3.6 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 4 | Foot Plate 3 parts | exoskeleton-foot-plate | 2× | 2 | 4 | assembly |
| 4.1 | Composite Sole | exoskeleton-sole | 1× | 2 | · | part |
| 4.2 | Ground Contact Sensor | exoskeleton-ground-sensor | 2× | 4 | · | part |
| 4.3 | Ankle Hinge | exoskeleton-ankle-hinge | 1× | 2 | · | part |
| 5 | IMU Suite 3 parts | exoskeleton-imu-suite | 1× | 1 | 7 | assembly |
| 5.1 | IMU (6-axis) | imu | 3× | 3 | · | part |
| 5.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3 | Connector | connector | 3× | 3 | · | part |
| 6 | Battery Pack 4 parts | exoskeleton-battery | 1× | 1 | 24 | assembly |
| 6.1 | Li-ion Cell, 18650 | li-cell-18650 | 20× | 20 | · | part |
| 6.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 6.3 | Pack Housing | exoskeleton-pack-case | 1× | 1 | · | part |
| 6.4 | Connector | connector | 2× | 2 | · | part |
| 7 | Gait Controller 5 parts | exoskeleton-controller | 1× | 1 | 163 | assembly |
| 7.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.4 | SMD Passive (R/C/L) | smd-passives | 150× | 150 | · | part |
| 7.5 | Connector | connector | 10× | 10 | · | part |
| 8 | User HMI 4 parts | exoskeleton-hmi | 1× | 1 | 59 | assembly |
| 8.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2 | HMI Board 4 parts | exoskeleton-hmi-board | 1× | 1 | 54 | assembly |
| 8.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.2.3 | SMD Passive (R/C/L) | smd-passives | 50× | 50 | · | part |
| 8.2.4 | Connector | connector | 2× | 2 | · | part |
| 8.3 | Mode Button | exoskeleton-mode-button | 3× | 3 | · | part |
| 8.4 | HMI Shell | exoskeleton-hmi-shell | 1× | 1 | · | part |
| 9 | Body Harness 3 parts | exoskeleton-cabling | 1× | 1 | 16 | assembly |
| 9.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 9.2 | Connector | connector | 14× | 14 | · | part |
| 9.3 | Cable Sleeve | exoskeleton-cable-sleeve | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Autonomous Mobile Robot (AMR)
627 parts · shares 6 with this page
 Humanoid Robot
3,158 parts · shares 4 with this page
 AGV Mobile Robot
383 parts · shares 6 with this page
 Mobile Manipulator
1,307 parts · shares 5 with this page
 Telepresence Robot
240 parts · shares 4 with this page
ASRS Shuttle Robot
296 parts · shares 4 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
333-word article