Rebar Tying Robot
ProductOverview
A rebar tying robot autonomously fastens reinforcing bars at construction joints with wire ties, eliminating manual labor and improving consistency. The system combines a tracked mobile base for site mobility, an X-Y gantry for precision over intersections, and a pneumatic tying gun capable of a tie every 8–12 seconds. Typical job sites include post-tensioned concrete slabs, where 50–100+ intersection points must be tied to lock bar layers before pour; the robot can handle a 3.0 m × 2.0 m section autonomously on a single battery charge.
Mobility and positioning
The Chassis and Gantry is a tracked rover frame with differential Differential Drive (left and right BLDC motors) driving independent rubber tracks. The tracks provide traction over rough formwork edges and small rubble; the differential drive allows point-turn steering. A mounted horizontal rail and vertical lift column serve as the positioning reference.
Over the rail runs the gun carriage, driven by stepper-powered X-axis and Y-axis ballscrews with position feedback to ±2 mm. The Rebar Detection Vision module, a forward-facing RGB camera, detects rebar grid lines using a trained neural network; the Motion Controller triangulates intersection candidates and drives the gantry stepwise to each point.
Tying mechanism
The Gun Carriage houses a pneumatic wrap head with a rotating hook that twists a pre-bent wire around the crossing bars. The sequence:
- Wire feed pulls ~15 cm of fresh wire from the Wire Spool.
- Clamp jaws hold the wire ends in position.
- The wrap head rotates 3–4 times under pneumatic power, circling the wire around both bar legs.
- A pneumatic cutter blade severs the tie, and the clamp releases.
- The twisted joint is secured with no excess wire, a key advantage over hand-tying, which leaves loose ends.
The pneumatic system includes an onboard 0.5 hp electric compressor and 10 L buffer tank maintaining 4.0 bar. Air demand is ~20 L/min on cycle, so the compressor duty cycle is ~40 %, sufficient for 150–200 ties/hour.
Vision and autonomy
The forward camera at ~40 cm standoff from the gantry plane images the rebar grid in ambient light, supplemented by a ring light for shadow suppression. A neural model trained on thousands of grid photos identifies bar crossings with 95 % confidence; the controller then commands the X-Y gantry to position the gun 1–2 cm above the crossing. A short height-finding routine confirms the gun is on-plane, then the wrap cycle executes.
Missed ties and slipped positions are tracked: the robot logs every attempted tie, confidence score, and visual post-check. If three consecutive ties fail at a location, it flags the operator, usually a sign the bars are misaligned or the location is inaccessible.
Battery and endurance
The pack is 48 V LiFePO4 with 200 Ah capacity (9.6 kWh), providing 8–10 hours of operation on a typical 3.0 m × 2.0 m slab (roughly 200–250 ties). Travel consumes ~200 W, tying ~150 W (motors + compressor), so the average power is ~350 W, yielding a nominal 27 hour pack life; real-world endurance is shorter due to compressor inefficiency and gantry peak loads.
Site integration
The robot is transported on a flatbed and deployed at the formwork edge. It requires 3-phase 480 VAC shore power for overnight charging (4 hour recharge from 20 %), but runs fully autonomous during the day. An operator loads the wire spool (pre-staged at the job) and inputs the grid pattern (captured from CAD or a site scan) via a rugged tablet; the system then maps its position relative to the gantry home and begins autonomous tying.
Safety contact bumpers on the front halt the rover if it strikes a worker or obstruction. A mushroom e-stop button cuts main power, and the onboard safety MCU prevents restart without manual reset.
Rebar Tying Robot parts and their functions
10 top-level parts · 144 parts in total · full bill of materials below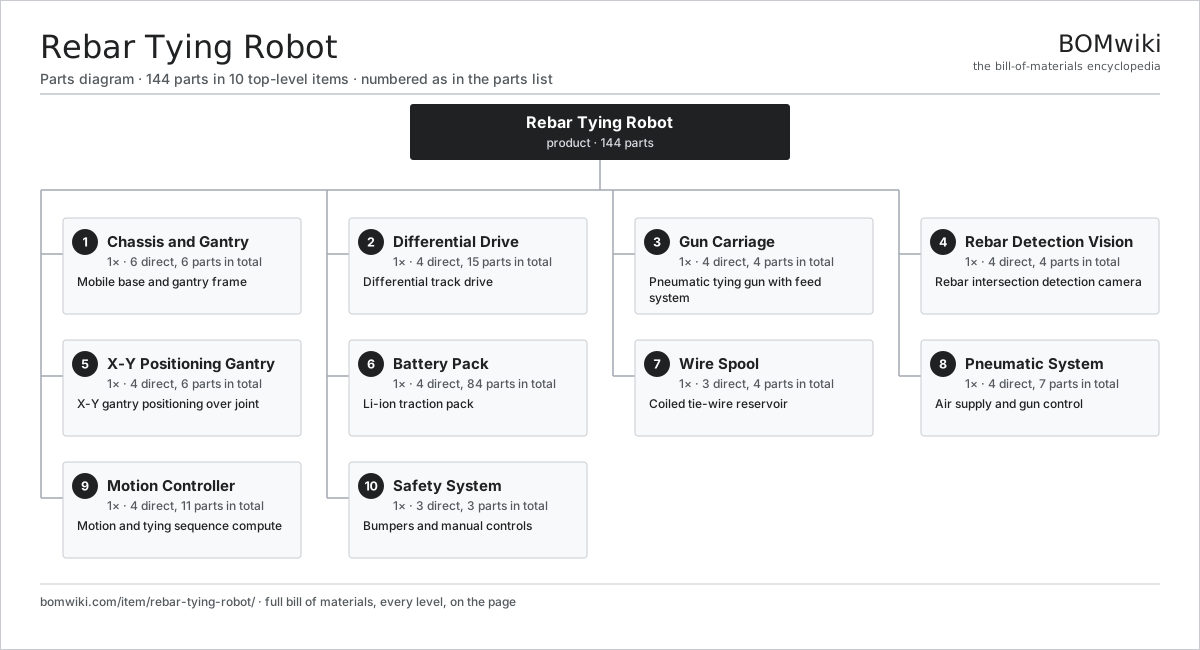
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Chassis and Gantry 6 parts | 1× | Mobile base and gantry frame |
| 2 | Differential Drive 4 parts | 1× | Differential track drive |
| 3 | Gun Carriage 4 parts | 1× | Pneumatic tying gun with feed system |
| 4 | Rebar Detection Vision 4 parts | 1× | Rebar intersection detection camera |
| 5 | X-Y Positioning Gantry 4 parts | 1× | X-Y gantry positioning over joint |
| 6 | Battery Pack 4 parts | 1× | Li-ion traction pack |
| 7 | Wire Spool 3 parts | 1× | Coiled tie-wire reservoir |
| 8 | Pneumatic System 4 parts | 1× | Air supply and gun control |
| 9 | Motion Controller 4 parts | 1× | Motion and tying sequence compute |
| 10 | Safety System 3 parts | 1× | Bumpers and manual controls |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Rebar Tying Robot
10 top-level lines · 58 rows shown · 144 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Chassis and Gantry 6 parts | rebar-tying-robot-chassis | 1× | 1 | 6 | assembly |
| 1.1 | Frame Weldment | rebar-tying-robot-frame-weld | 1× | 1 | · | part |
| 1.2 | Left Track | rebar-tying-robot-track-left | 1× | 1 | · | part |
| 1.3 | Right Track | rebar-tying-robot-track-right | 1× | 1 | · | part |
| 1.4 | X-Axis Rail | rebar-tying-robot-gantry-rail-x | 1× | 1 | · | part |
| 1.5 | Y-Axis Column | rebar-tying-robot-gantry-rail-y | 1× | 1 | · | part |
| 1.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Differential Drive 4 parts | rebar-tying-robot-drivetrain | 1× | 1 | 15 | assembly |
| 2.1 | Track Motor | rebar-tying-robot-drive-motor | 2× | 2 | · | part |
| 2.2 | Drive Gearbox | rebar-tying-robot-drive-gearbox | 2× | 2 | · | part |
| 2.3 | Track Sprocket | rebar-tying-robot-drive-sprocket | 2× | 2 | · | part |
| 2.4 | Wheel Assembly 5 parts | wheel-assembly | 1× | 1 | 9 | assembly |
| 2.4.1 | Alloy Wheel | alloy-wheel | 1× | 1 | · | part |
| 2.4.2 | Tire | tire | 1× | 1 | · | part |
| 2.4.3 | TPMS Sensor | tpms-sensor | 1× | 1 | · | part |
| 2.4.4 | Lug Nut | lug-nut | 5× | 5 | · | part |
| 2.4.5 | Valve Stem | valve-stem | 1× | 1 | · | part |
| 3 | Gun Carriage 4 parts | rebar-tying-robot-gun-carriage | 1× | 1 | 4 | assembly |
| 3.1 | Gun Head | rebar-tying-robot-gun-head | 1× | 1 | · | part |
| 3.2 | Wire Clamp | rebar-tying-robot-gun-clamp | 1× | 1 | · | part |
| 3.3 | Wire Feed Motor | rebar-tying-robot-feed-motor | 1× | 1 | · | part |
| 3.4 | Tie Cutter | rebar-tying-robot-cut-solenoid | 1× | 1 | · | part |
| 4 | Rebar Detection Vision 4 parts | rebar-tying-robot-vision | 1× | 1 | 4 | assembly |
| 4.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 4.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4 | LED Ring Light | led-ring | 1× | 1 | · | part |
| 5 | X-Y Positioning Gantry 4 parts | rebar-tying-robot-positioning-arm | 1× | 1 | 6 | assembly |
| 5.1 | X-Axis Actuator | rebar-tying-robot-x-actuator | 1× | 1 | · | part |
| 5.2 | Y-Axis Actuator | rebar-tying-robot-y-actuator | 1× | 1 | · | part |
| 5.3 | Ball Screw | ball-screw | 2× | 2 | · | part |
| 5.4 | Encoder | encoder | 2× | 2 | · | part |
| 6 | Battery Pack 4 parts | rebar-tying-robot-battery | 1× | 1 | 84 | assembly |
| 6.1 | Li-ion Cell, 18650 | li-cell-18650 | 80× | 80 | · | part |
| 6.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 6.3 | Battery Housing | rebar-tying-robot-battery-housing | 1× | 1 | · | part |
| 6.4 | Connector | connector | 2× | 2 | · | part |
| 7 | Wire Spool 3 parts | rebar-tying-robot-wire-spool | 1× | 1 | 4 | assembly |
| 7.1 | Spool Drum | rebar-tying-robot-spool-drum | 1× | 1 | · | part |
| 7.2 | Spool Bearing | rebar-tying-robot-spool-bearing | 2× | 2 | · | part |
| 7.3 | Wire Guide | rebar-tying-robot-wire-guide | 1× | 1 | · | part |
| 8 | Pneumatic System 4 parts | rebar-tying-robot-pneumatic-circuit | 1× | 1 | 7 | assembly |
| 8.1 | Air Compressor | rebar-tying-robot-compressor | 1× | 1 | · | part |
| 8.2 | Air Buffer Tank | rebar-tying-robot-air-tank | 1× | 1 | · | part |
| 8.3 | Solenoid Valve Tree | rebar-tying-robot-valve-tree | 1× | 1 | · | part |
| 8.4 | Connector | connector | 4× | 4 | · | part |
| 9 | Motion Controller 4 parts | rebar-tying-robot-controller | 1× | 1 | 11 | assembly |
| 9.1 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 9.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 9.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.4 | I/O Board 3 parts | rebar-tying-robot-io-board | 1× | 1 | 8 | assembly |
| 9.4.1 | Stepper Driver | stepper-driver | 3× | 3 | · | part |
| 9.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.4.3 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 10 | Safety System 3 parts | rebar-tying-robot-safety | 1× | 1 | 3 | assembly |
| 10.1 | Front Bumper | rebar-tying-robot-bumper-front | 1× | 1 | · | part |
| 10.2 | E-Stop Button | rebar-tying-robot-estop-button | 1× | 1 | · | part |
| 10.3 | Microcontroller | mcu | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Telepresence Robot
240 parts · shares 11 with this page
Security Patrol Robot
582 parts · shares 11 with this page
 Fruit Picking Robot
144 parts · shares 10 with this page
Sewer Inspection Crawler
236 parts · shares 10 with this page
Autonomous Forklift
342 parts · shares 9 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
768-word article