Wall-Climbing Inspection Robot
ProductOverview
A wall-climbing inspection robot drives up vertical steel surfaces, storage tank shells, ship hulls, wind-turbine towers, penstocks, carrying cameras and thickness gauges where the alternative is scaffolding, rope access, or draining the asset. A typical tank-shell survey that costs days of scaffolding becomes a few hours of crawling, with the human inspector standing on the ground at the Operator Console.
Industrial machines in this class almost universally use permanent-magnet adhesion rather than vacuum: the infrastructure they inspect is carbon steel, magnets consume no power, and they fail gracefully, holding force degrades with air gap rather than vanishing when a seal leaks.
Adhesion
The Magnetic Adhesion System is an array of 24 N52 Neodymium Magnet blocks in a machined Magnet Array Carrier carrier, backed by mild-steel Flux Back-Plate yokes that close the magnetic circuit and roughly double the force delivered into the wall. The array never touches the surface; Air-Gap Adjuster standoffs hold it a few millimetres off the steel. That air gap is the central tuning parameter, force falls steeply with distance, so a smaller gap means more margin but more drag and worse tolerance of weld beads. Set for a 3 mm gap, the array holds about 450 kgf against a 12 kg robot, better than a 3× margin in the worst orientation (inverted under a tank roof, where magnetic force is the only thing opposing gravity). Two Adhesion Sensor flux probes watch the circuit and alarm if paint thickness or surface rust pushes the effective gap out of margin.
The failure backstop is mechanical: the robot is never on the wall without its Safety Line, a Kevlar member inside the umbilical rated to ten times robot weight, terminated at the Tether Anchor eye on the chassis.
Locomotion
Two Track Drive Unit track units, one per side, skid-steer the robot at up to 12 m/min. The Track Belt compound is chosen for friction on painted and lightly rusted steel; the magnets supply normal force, but the tracks must convert it into traction without slipping on a vertical face. Each Drive Motor runs two planetary stages of Helical Gear Pair reduction with a ratio high enough to be non-backdrivable, power off, the robot simply parks on the wall, which is also what the console Emergency Stop relies on. The Frame Plate is machined as a single piece so the magnet array and both tracks stay coplanar within 0.2 mm; a twisted frame would lift one track or drag the magnets. Corner Bump Skids let the chassis ride over 10 mm weld beads without levering the array off the surface.
Inspection payload
The standard Inspection Payload pairs visual and ultrasonic survey. The PTZ Camera gives the operator a zoomable close view, lit by high-CRI Inspection Lights inside dark tanks, with a Laser Scaler projecting twin parallel beams at known spacing so defects in the image can be measured. The UT Thickness Probe presses a piezoelectric UT Transducer against the wall on a Coil Spring preload, wets the contact with gel from the Couplant Pump, and times echo returns to read remaining wall thickness to 0.1 mm through paint, the core measurement of corrosion surveys under standards such as API 653 for tank shells.
Tether and control
The Umbilical Cable bundles 48 V power, an Ethernet pair, and the strength member in a single 60 m jacket, paid out from a powered Tether Reel that keeps light tension so slack never snags on nozzles or stairways; a slip-ring Reel Drum keeps power and data flowing while winding. Tethered power is what lets a 12 kg robot run 150 W continuously for a full shift with no battery mass stuck to the wall.
Onboard, the Onboard Controller splits duties between an Microcontroller running drive and safety logic and a Compute SoC Module encoding video. Position on the wall comes from track Encoder odometry fused with the Tilt Sensor, good to about ±50 mm over an inspection pass, enough to tag every thickness reading with a location so the survey output is a corrosion map of the shell, not just a list of numbers.
Wall-Climbing Inspection Robot parts and their functions
7 top-level parts · 235 parts in total · full bill of materials below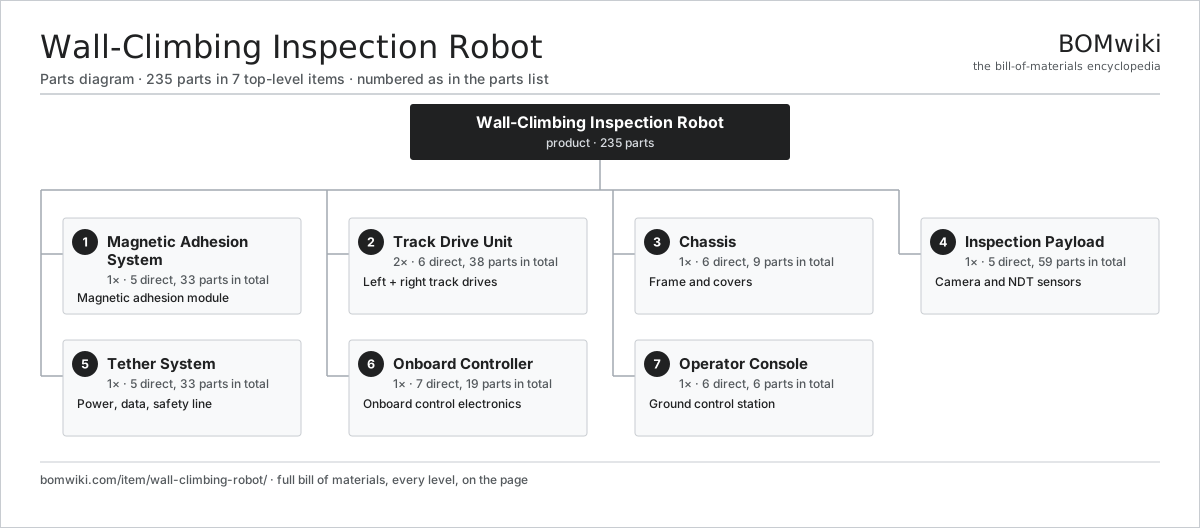
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Magnetic Adhesion System 5 parts | 1× | Magnetic adhesion module |
| 2 | Track Drive Unit 6 parts | 2× | Left + right track drives |
| 3 | Chassis 6 parts | 1× | Frame and covers |
| 4 | Inspection Payload 5 parts | 1× | Camera and NDT sensors |
| 5 | Tether System 5 parts | 1× | Power, data, safety line |
| 6 | Onboard Controller 7 parts | 1× | Onboard control electronics |
| 7 | Operator Console 6 parts | 1× | Ground control station |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Wall-Climbing Inspection Robot
7 top-level lines · 65 rows shown · 235 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Magnetic Adhesion System 5 parts | wall-climbing-robot-adhesion-system | 1× | 1 | 33 | assembly |
| 1.1 | Magnet Array Carrier | wall-climbing-robot-magnet-array | 1× | 1 | · | part |
| 1.2 | Neodymium Magnet | neodymium-magnet | 24× | 24 | · | part |
| 1.3 | Flux Back-Plate | wall-climbing-robot-flux-plate | 2× | 2 | · | part |
| 1.4 | Air-Gap Adjuster | wall-climbing-robot-gap-adjuster | 4× | 4 | · | part |
| 1.5 | Adhesion Sensor | wall-climbing-robot-adhesion-sensor | 2× | 2 | · | part |
| 2 | Track Drive Unit 6 parts | wall-climbing-robot-drive-system | 2× | 2 | 38 | assembly |
| 2.1 | Drive Motor 6 parts | wall-climbing-robot-drive-motor | 1× | 2 | 29 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.1.3 | Helical Gear Pair | gear-pair | 2× | 4 | · | part |
| 2.1.4 | Gearbox Housing | gearbox-housing | 1× | 2 | · | part |
| 2.1.5 | Hall Sensor | hall-sensor | 3× | 6 | · | part |
| 2.1.6 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 2.2 | Track Belt | wall-climbing-robot-track-belt | 1× | 2 | · | part |
| 2.3 | Drive Sprocket | wall-climbing-robot-drive-sprocket | 1× | 2 | · | part |
| 2.4 | Idler Wheel | wall-climbing-robot-idler-wheel | 2× | 4 | · | part |
| 2.5 | Encoder | encoder | 1× | 2 | · | part |
| 2.6 | Ball Bearing | ball-bearing | 4× | 8 | · | part |
| 3 | Chassis 6 parts | wall-climbing-robot-chassis | 1× | 1 | 9 | assembly |
| 3.1 | Frame Plate | wall-climbing-robot-frame-plate | 1× | 1 | · | part |
| 3.2 | Cover Shell | wall-climbing-robot-cover-shell | 1× | 1 | · | part |
| 3.3 | Tether Anchor | wall-climbing-robot-tether-anchor | 1× | 1 | · | part |
| 3.4 | Bump Skid | wall-climbing-robot-bump-skid | 4× | 4 | · | part |
| 3.5 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 3.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 4 | Inspection Payload 5 parts | wall-climbing-robot-inspection-payload | 1× | 1 | 59 | assembly |
| 4.1 | PTZ Camera 4 parts | wall-climbing-robot-ptz-camera | 1× | 1 | 51 | assembly |
| 4.1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 4.1.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 4.1.3 | Servo Motor 4 parts + deeper › | servo-motor | 2× | 2 | 24 | assembly |
| 4.1.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2 | UT Thickness Probe 4 parts | wall-climbing-robot-ut-probe | 1× | 1 | 4 | assembly |
| 4.2.1 | UT Transducer | wall-climbing-robot-ut-transducer | 1× | 1 | · | part |
| 4.2.2 | Coil Spring | coil-spring | 1× | 1 | · | part |
| 4.2.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2.4 | Connector | connector | 1× | 1 | · | part |
| 4.3 | Couplant Pump | wall-climbing-robot-couplant-pump | 1× | 1 | · | part |
| 4.4 | Inspection Light | wall-climbing-robot-led-light | 2× | 2 | · | part |
| 4.5 | Laser Scaler | wall-climbing-robot-laser-scaler | 1× | 1 | · | part |
| 5 | Tether System 5 parts | wall-climbing-robot-tether-system | 1× | 1 | 33 | assembly |
| 5.1 | Umbilical Cable | wall-climbing-robot-umbilical | 1× | 1 | · | part |
| 5.2 | Safety Line | wall-climbing-robot-safety-line | 1× | 1 | · | part |
| 5.3 | Tether Reel 4 parts | wall-climbing-robot-tether-reel | 1× | 1 | 27 | assembly |
| 5.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.3.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 5.3.3 | Reel Drum | wall-climbing-robot-reel-drum | 1× | 1 | · | part |
| 5.3.4 | Encoder | encoder | 1× | 1 | · | part |
| 5.4 | Strain Relief | wall-climbing-robot-strain-relief | 2× | 2 | · | part |
| 5.5 | Connector | connector | 2× | 2 | · | part |
| 6 | Onboard Controller 7 parts | wall-climbing-robot-controller | 1× | 1 | 19 | assembly |
| 6.1 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 6.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.4 | Power MOSFET | mosfet | 8× | 8 | · | part |
| 6.5 | Tilt Sensor | wall-climbing-robot-tilt-sensor | 1× | 1 | · | part |
| 6.6 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 6.7 | Connector | connector | 6× | 6 | · | part |
| 7 | Operator Console 6 parts | wall-climbing-robot-operator-console | 1× | 1 | 6 | assembly |
| 7.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7.2 | Control Joystick | wall-climbing-robot-joystick | 1× | 1 | · | part |
| 7.3 | Power Supply | power-supply | 1× | 1 | · | part |
| 7.4 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.5 | Emergency Stop | wall-climbing-robot-estop | 1× | 1 | · | part |
| 7.6 | Console Case | wall-climbing-robot-console-case | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 8 with this page
Sealant Dispensing Robot
2,056 parts · shares 7 with this page
Security Patrol Robot
582 parts · shares 6 with this page
Robotic Deburring Cell
1,637 parts · shares 6 with this page
Vineyard Robot
588 parts · shares 5 with this page
Sewer Inspection Crawler
236 parts · shares 7 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
764-word article