Fixed-Wing Survey Drone
ProductOverview
A fixed-wing survey drone is a long-endurance unmanned aircraft built to cover large areas in a single flight, capturing overlapping aerial images for photogrammetry and mapping. Unlike a multirotor, which spends most of its energy fighting gravity to hover, a fixed wing generates lift from forward motion across the Wing Panel panels, so it converts battery energy into distance far more efficiently. A typical machine of this class spans about 3.2 m, weighs around 6 kg empty, cruises near 18 m/s, and stays aloft for 60 to 90 minutes, enough to map several square kilometers in one sortie.
The aircraft flies a pre-loaded grid mission. The operator draws a survey boundary, sets the target ground sample distance, and the Flight Controller generates a lawnmower pattern of parallel passes with the forward and side image overlap needed for a clean orthomosaic. The drone then takes off, flies the grid, triggers the camera at fixed intervals, and returns home with minimal operator input.
Airframe
The Airframe is a pod-and-boom layout in carbon-Kevlar composite. The Fuselage Pod holds the avionics and the survey sensors, with internal Bulkhead formers carrying flight loads into the Wing Spar. A Tail Boom carries the inverted-V Empennage aft, where two ruddervators blend pitch and yaw control into a pair of surfaces.
The wing is high aspect ratio for low induced drag, built around a carbon Wing Spar with Wing Rib formers and a molded Wing Skin. Each tip carries a Winglet to trim vortex losses. Roll comes from the outboard Aileron, and a Flap inboard lowers the stall speed to about 12 m/s for slower, safer landings. Every moving surface rides on a Surface Hinge line and is driven through a Control Horn. The wings break down at the root for transport, so the whole aircraft packs into a single case. For landing without a runway the underside carries a reinforced Belly Skid.
Propulsion
Thrust comes from a single aft pusher in the Propulsion System group. The Brushless Motor is an outrunner brushless unit built on a Stator Assembly and Rotor Assembly with Neodymium Magnet poles running on a pair of Ball Bearing supports. An ESC commutates the three motor phases from the flight controller throttle signal. The Propeller is a folding type: it blades out under power and folds flat against the Spinner when the motor idles, which cuts drag during the long glide-assisted cruise and protects the blades on a belly landing. The motor bolts to a machined Motor Mount at the rear firewall, away from the survey sensors so propeller vibration does not reach the imaging payload.
Avionics and navigation
The Flight Controller PCBA runs the autopilot on a main Microcontroller with an IO co-processor, fed by dual redundant IMU (6-axis) units and a Barometer for altitude. Sensor fusion estimates attitude and airspeed many times a second and drives the control surfaces to hold heading and altitude against gusts. A Power Sense Module reports pack voltage and current so the firmware can predict remaining endurance and trigger return-to-home before the battery runs low.
Position accuracy matters more here than on most drones, because the camera geotag sets the accuracy of the final map. The Navigation System group is built on a multi-band RTK GNSS Receiver receiver using a GPS Module and a survey-grade GNSS Antenna. With RTK corrections from a base station the aircraft fixes its position to about 2 cm, which lets the survey produce georeferenced maps with few or no ground control points. An external Magnetometer sits clear of the motor for a clean heading reference, and the Air-Data Sensor uses a Pressure Sensor and a Pitot Tube to measure true airspeed, which keeps the aircraft above stall in wind and helps it hold ground track on long passes.
Survey payload
The Survey Payload carries two imagers on a damped Stabilized Payload Mount. The primary Mapping Camera is a global-shutter RGB unit built from a Camera Module, a large CMOS Image Sensor, and a fixed Lens Assembly. A mechanical Mechanical Shutter freezes each frame so forward motion at cruise speed does not smear the image, which is what keeps the ground sample distance near 2.5 cm per pixel at 120 m above ground level. Alongside it, a Multispectral Sensor sensor splits the scene into narrow bands across several CMOS Image Sensor and Lens Assembly channels, with a top-mounted Irradiance Sensor that records ambient irradiance so reflectance can be calibrated for crop health indices. The whole stack sits in a Mount Frame suspended on Vibration Damper isolators, since any high-frequency vibration reaching the lens degrades the survey.
Power and communications
The Power System runs on a Battery Pack of LiPo Cell units in a 6S2P arrangement, watched by a BMS Board that balances cells and cuts the pack on a fault. A dual BEC Regulator regulator built on Power MOSFET switches drops the pack voltage to clean rails for the avionics and the Servo Set, while a Power Distribution Board board feeds the high-current propulsion rail through XT60 Connector leads. Six Servo Motor units drive the surfaces through carbon Pushrod linkages.
The Communications System group keeps the ground operator in the loop. A 900 MHz Telemetry Radio carries the command and status link out to tens of kilometers, a separate RC Receiver gives manual override on takeoff and landing, and a diversity pair of Datalink Antenna elements holds the link through bank angles. If the link drops, the aircraft continues its mission or returns home on its own.
Variants and use
Most fixed-wing survey drones serve mapping work in farming, mining, forestry, and construction, where a single flight replaces hours of ground survey. The Recovery System system is the safety backstop: a folded Parachute Canopy fired by a spring Deployment Mechanism through an Ejector Tube, with a Bridle Harness spreading the load into the airframe, so a power or control failure ends in a slow descent rather than a crash. Operators choose payloads by job: RGB only for terrain and volume surveys, the multispectral channels added for agronomy. Launch is by hand toss or a small catapult, and recovery is by parachute or a flat belly approach onto the Belly Skid, which means the aircraft needs no runway and can work from a field edge.
Fixed-Wing Survey Drone parts and their functions
10 top-level parts · 382 parts in total · full bill of materials below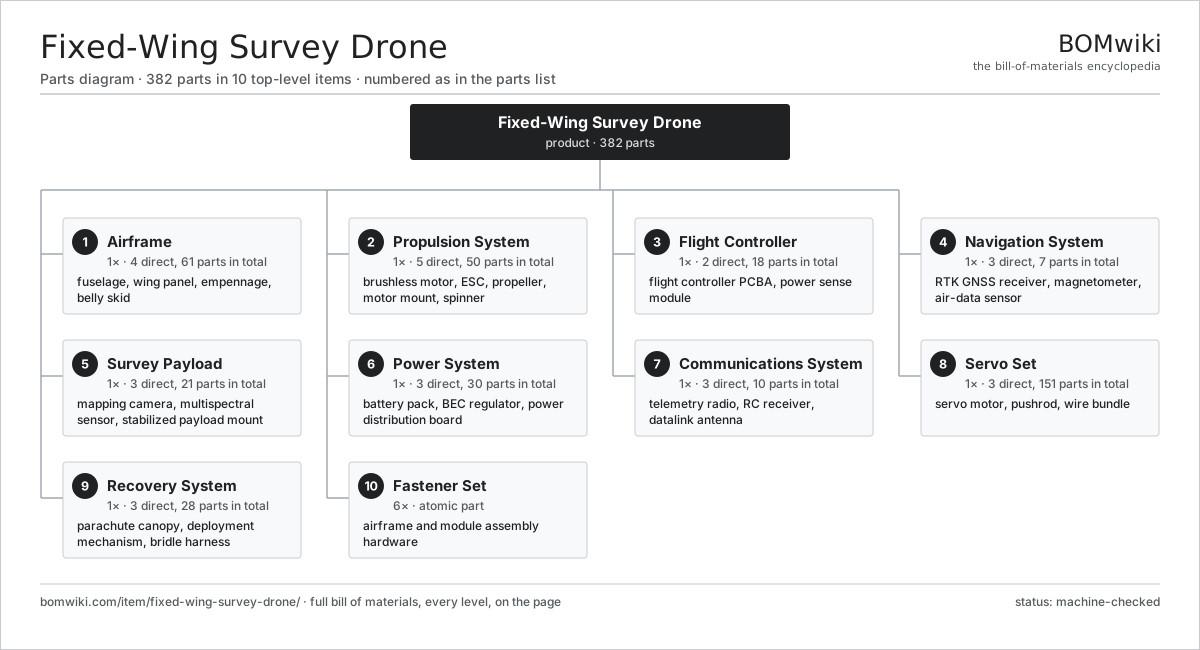
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Airframe 4 parts | 1× | Composite fuselage, wings, tail and control surfaces. |
| 2 | Propulsion System 5 parts | 1× | Pusher brushless motor, ESC and folding propeller. |
| 3 | Flight Controller 2 parts | 1× | Autopilot board running the mapping mission firmware. |
| 4 | Navigation System 3 parts | 1× | RTK GNSS, magnetometer and air-data sensing. |
| 5 | Survey Payload 3 parts | 1× | Mapping camera and multispectral sensor on a damped mount. |
| 6 | Power System 3 parts | 1× | Flight battery, BMS and avionics regulator. |
| 7 | Communications System 3 parts | 1× | Telemetry radio, RC receiver and datalink antenna. |
| 8 | Servo Set 3 parts | 1× | Digital servos driving the flight-control surfaces. |
| 9 | Recovery System 3 parts | 1× | Ballistic parachute for controlled descent on failure. |
| 10 | Fastener Set | 6× | airframe and module assembly hardware |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Fixed-Wing Survey Drone
10 top-level lines · 114 rows shown · 382 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Airframe 4 parts | fixed-wing-survey-drone-airframe | 1× | 1 | 61 | assembly |
| 1.1 | Fuselage 5 parts | fixed-wing-survey-drone-fuselage | 1× | 1 | 8 | assembly |
| 1.1.1 | Nose Cone | fixed-wing-survey-drone-nose-cone | 1× | 1 | · | part |
| 1.1.2 | Fuselage Pod | fixed-wing-survey-drone-fuselage-pod | 1× | 1 | · | part |
| 1.1.3 | Bulkhead | fixed-wing-survey-drone-bulkhead | 4× | 4 | · | part |
| 1.1.4 | Tail Boom | fixed-wing-survey-drone-tail-boom | 1× | 1 | · | part |
| 1.1.5 | Payload Hatch | fixed-wing-survey-drone-payload-hatch | 1× | 1 | · | part |
| 1.2 | Wing Panel 6 parts | fixed-wing-survey-drone-wing | 2× | 2 | 21 | assembly |
| 1.2.1 | Wing Spar | fixed-wing-survey-drone-wing-spar | 1× | 2 | · | part |
| 1.2.2 | Wing Rib | fixed-wing-survey-drone-wing-rib | 7× | 14 | · | part |
| 1.2.3 | Wing Skin | fixed-wing-survey-drone-wing-skin | 2× | 4 | · | part |
| 1.2.4 | Winglet | fixed-wing-survey-drone-winglet | 1× | 2 | · | part |
| 1.2.5 | Aileron 3 parts + deeper › | fixed-wing-survey-drone-aileron | 1× | 2 | 5 | assembly |
| 1.2.6 | Flap 3 parts + deeper › | fixed-wing-survey-drone-flap | 1× | 2 | 5 | assembly |
| 1.3 | Empennage 4 parts | fixed-wing-survey-drone-empennage | 1× | 1 | 10 | assembly |
| 1.3.1 | Tail Surface | fixed-wing-survey-drone-tail-fin | 2× | 2 | · | part |
| 1.3.2 | Control Surface Panel | fixed-wing-survey-drone-control-surface | 2× | 2 | · | part |
| 1.3.3 | Control Horn | fixed-wing-survey-drone-control-horn | 2× | 2 | · | part |
| 1.3.4 | Surface Hinge | fixed-wing-survey-drone-hinge | 4× | 4 | · | part |
| 1.4 | Belly Skid | fixed-wing-survey-drone-belly-skid | 1× | 1 | · | part |
| 2 | Propulsion System 5 parts | fixed-wing-survey-drone-propulsion | 1× | 1 | 50 | assembly |
| 2.1 | Brushless Motor 4 parts | fixed-wing-survey-drone-motor | 1× | 1 | 38 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.1.3 | Neodymium Magnet | neodymium-magnet | 14× | 14 | · | part |
| 2.1.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.2 | ESC 4 parts | esc | 1× | 1 | 9 | assembly |
| 2.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.2.2 | Power MOSFET | mosfet | 6× | 6 | · | part |
| 2.2.3 | Gate Driver IC | gate-driver-ic | 1× | 1 | · | part |
| 2.2.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 2.3 | Propeller | propeller | 1× | 1 | · | part |
| 2.4 | Motor Mount | fixed-wing-survey-drone-motor-mount | 1× | 1 | · | part |
| 2.5 | Spinner | fixed-wing-survey-drone-spinner | 1× | 1 | · | part |
| 3 | Flight Controller 2 parts | fixed-wing-survey-drone-flight-controller | 1× | 1 | 18 | assembly |
| 3.1 | Flight Controller PCBA 6 parts | fixed-wing-survey-drone-fc-pcba | 1× | 1 | 13 | assembly |
| 3.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 3.1.3 | IMU (6-axis) | imu | 2× | 2 | · | part |
| 3.1.4 | Barometer | barometer | 1× | 1 | · | part |
| 3.1.5 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 3.1.6 | Connector | connector | 6× | 6 | · | part |
| 3.2 | Power Sense Module 4 parts | fixed-wing-survey-drone-power-module | 1× | 1 | 5 | assembly |
| 3.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.2.2 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 3.2.3 | XT60 Connector | xt60-connector | 2× | 2 | · | part |
| 3.2.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 4 | Navigation System 3 parts | fixed-wing-survey-drone-navigation | 1× | 1 | 7 | assembly |
| 4.1 | RTK GNSS Receiver 4 parts | fixed-wing-survey-drone-rtk-gnss | 1× | 1 | 4 | assembly |
| 4.1.1 | GPS Module | gps-module | 1× | 1 | · | part |
| 4.1.2 | GNSS Antenna | fixed-wing-survey-drone-gnss-antenna | 1× | 1 | · | part |
| 4.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.1.4 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 4.2 | Magnetometer | fixed-wing-survey-drone-magnetometer | 1× | 1 | · | part |
| 4.3 | Air-Data Sensor 2 parts | fixed-wing-survey-drone-airdata | 1× | 1 | 2 | assembly |
| 4.3.1 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 4.3.2 | Pitot Tube | fixed-wing-survey-drone-pitot-tube | 1× | 1 | · | part |
| 5 | Survey Payload 3 parts | fixed-wing-survey-drone-payload | 1× | 1 | 21 | assembly |
| 5.1 | Mapping Camera 4 parts | fixed-wing-survey-drone-mapping-camera | 1× | 1 | 6 | assembly |
| 5.1.1 | Camera Module 3 parts + deeper › | camera-module | 1× | 1 | 3 | assembly |
| 5.1.2 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 5.1.3 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 5.1.4 | Mechanical Shutter | fixed-wing-survey-drone-camera-shutter | 1× | 1 | · | part |
| 5.2 | Multispectral Sensor 4 parts | fixed-wing-survey-drone-multispectral | 1× | 1 | 10 | assembly |
| 5.2.1 | CMOS Image Sensor | image-sensor | 4× | 4 | · | part |
| 5.2.2 | Lens Assembly | camera-lens | 4× | 4 | · | part |
| 5.2.3 | Irradiance Sensor | fixed-wing-survey-drone-light-sensor | 1× | 1 | · | part |
| 5.2.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3 | Stabilized Payload Mount 2 parts | fixed-wing-survey-drone-payload-mount | 1× | 1 | 5 | assembly |
| 5.3.1 | Mount Frame | fixed-wing-survey-drone-mount-frame | 1× | 1 | · | part |
| 5.3.2 | Vibration Damper | fixed-wing-survey-drone-vibration-damper | 4× | 4 | · | part |
| 6 | Power System 3 parts | fixed-wing-survey-drone-power-system | 1× | 1 | 30 | assembly |
| 6.1 | Battery Pack 4 parts | fixed-wing-survey-drone-battery-pack | 1× | 1 | 15 | assembly |
| 6.1.1 | LiPo Cell | lipo-cell | 12× | 12 | · | part |
| 6.1.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 6.1.3 | XT60 Connector | xt60-connector | 1× | 1 | · | part |
| 6.1.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 6.2 | BEC Regulator 4 parts | fixed-wing-survey-drone-bec | 1× | 1 | 10 | assembly |
| 6.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.2.2 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 6.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 6.2.4 | Connector | connector | 4× | 4 | · | part |
| 6.3 | Power Distribution Board 4 parts | fixed-wing-survey-drone-power-dist | 1× | 1 | 5 | assembly |
| 6.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.3.2 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 6.3.3 | XT60 Connector | xt60-connector | 2× | 2 | · | part |
| 6.3.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 7 | Communications System 3 parts | fixed-wing-survey-drone-comms | 1× | 1 | 10 | assembly |
| 7.1 | Telemetry Radio 4 parts | fixed-wing-survey-drone-telemetry-radio | 1× | 1 | 5 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | RF Transceiver Module | fixed-wing-survey-drone-rf-module | 1× | 1 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 7.1.4 | Connector | connector | 2× | 2 | · | part |
| 7.2 | RC Receiver 3 parts | fixed-wing-survey-drone-rc-receiver | 1× | 1 | 3 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2.2 | RF Transceiver Module | fixed-wing-survey-drone-rf-module | 1× | 1 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 7.3 | Datalink Antenna | fixed-wing-survey-drone-datalink-antenna | 2× | 2 | · | part |
| 8 | Servo Set 3 parts | fixed-wing-survey-drone-servo-set | 1× | 1 | 151 | assembly |
| 8.1 | Servo Motor 4 parts | servo-motor | 6× | 6 | 24 | assembly |
| 8.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 6 | 3 | assembly |
| 8.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 6 | 19 | assembly |
| 8.1.3 | Encoder | encoder | 1× | 6 | · | part |
| 8.1.4 | Motor Housing | motor-housing | 1× | 6 | · | part |
| 8.2 | Pushrod | fixed-wing-survey-drone-pushrod | 6× | 6 | · | part |
| 8.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 9 | Recovery System 3 parts | fixed-wing-survey-drone-recovery | 1× | 1 | 28 | assembly |
| 9.1 | Parachute Canopy | fixed-wing-survey-drone-parachute | 1× | 1 | · | part |
| 9.2 | Deployment Mechanism 3 parts | fixed-wing-survey-drone-deploy-mechanism | 1× | 1 | 26 | assembly |
| 9.2.1 | Coil Spring | coil-spring | 1× | 1 | · | part |
| 9.2.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 9.2.3 | Ejector Tube | fixed-wing-survey-drone-ejector-tube | 1× | 1 | · | part |
| 9.3 | Bridle Harness | fixed-wing-survey-drone-bridle | 1× | 1 | · | part |
| 10 | Fastener Set | fastener-set | 6× | 6 | · | part |
Related products
same domain, ranked by shared parts Fixed-Wing UAV
308 parts · shares 24 with this page
 Cargo Delivery Drone
545 parts · shares 21 with this page
Parcel Delivery Drone
564 parts · shares 23 with this page
 Quadcopter Drone
244 parts · shares 18 with this page
 Micro Racing Quadcopter
506 parts · shares 15 with this page
 Tiltrotor UAV
341 parts · shares 16 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $50k–$300M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇺🇸Boeing
boeing.com ↗
|
Arlington, US | Aerospace OEM | made to order | 40–80 wks |
|
🇫🇷Airbus
airbus.com ↗
|
Toulouse, FR | Aerospace OEM | made to order | 40–80 wks |
| lockheedmartin.com ↗ | Bethesda, US | Aerospace & defense | made to order | 40–80 wks |
|
🇧🇷Embraer
embraer.com ↗
|
São José dos Campos, BR | Aircraft OEM | made to order | 40–80 wks |
| txtav.com ↗ | Wichita, US | Aircraft OEM | made to order | 40–80 wks |
1,254-word article