Micro Racing Quadcopter
ProductOverview
A micro racing quadcopter is a small, high-power first-person-view aircraft built for low-latency flight around a defined course. The pilot wears goggles that show a live video feed from a forward camera, so the aircraft is flown from the cockpit view rather than line of sight. The class described here is the common 5-inch build: four Brushless Motor Assembly units swinging 5-inch propellers on a true-X Carbon Frame Set, driven by a 4-in-1 ESC and stabilized by a Flight Controller.
The design priority is power-to-weight and responsiveness. A finished aircraft weighs around 600 g with its LiPo Battery Pack fitted, and the four motors together can produce roughly eight times that in static thrust. That headroom is what lets the quad accelerate hard out of corners and hold attitude through aggressive maneuvers. Nearly every part is chosen to shave grams or cut latency, which is why the parts list runs to many small, dense subassemblies rather than a few large ones.
Airframe
The Carbon Frame Set is a carbon-fiber unibody plate set. A 3 mm Bottom Plate carries the four Frame Arm sections and forms the structural spine, while a 2 mm Top Plate caps the electronics stack. The two plates are joined by Aluminum Standoff posts in 6061 aluminum, which set the stack height and protect the boards in a crash. The wheelbase is about 220 mm measured corner to corner, which keeps the props clear while staying compact.
Two soft mounts complete the structure. The Camera Mount holds the FPV camera at an adjustable tilt, typically 30 to 45 degrees for racing so the horizon sits low when the aircraft is pitched forward. The Antenna Mount holds the video antenna up and clear of the propeller disc. Printed TPU Soft-Mount Print parts add bumpers and vibration-damping camera cages, and an Fastener Set of M2 and M3 hardware ties it all together.
Propulsion
Each Brushless Motor Assembly is a 2207 outrunner: a 22 mm diameter stator that is 7 mm tall. At around 1900 KV on a 6S pack, the motor spins fast enough to load a 5-inch Propeller hard while staying inside its thermal limit. The wound Stator Assembly sits on a machined Motor Base, and the spinning Motor Bell carries 14 Neodymium Magnet arcs around a hardened Motor Shaft. Two Ball Bearing units support the shaft and a Retaining Circlip retains the bell. The tri-blade prop threads onto the bell with an M5 nut.
Two propellers spin clockwise and two counter-clockwise so the reaction torques cancel in level flight. Differential thrust across the four motors produces roll, pitch, and yaw, which is the only control authority the aircraft has. There are no flight surfaces.
Power electronics
Motor commutation runs through the 4-in-1 ESC, a single 4-in-1 board that packs four independent speed controllers. Each channel uses six Power MOSFET devices in a three-phase bridge driven by a Gate Driver IC and switched by an Microcontroller running an open firmware such as BLHeli. A Current-Sense Shunt on each phase feeds current telemetry back to the flight controller, and a large Low-ESR Bulk Capacitor across the input absorbs the voltage spikes that fast switching throws back onto the pack.
The board is rated near 45 A continuous per channel, comfortably above the roughly 30 A each motor draws at full throttle, so the controllers stay cool through a race. The four-in-one layout keeps the wiring short and the center of mass low, both of which help handling.
Flight control
The Flight Controller is the brain. An STM32F7-class Microcontroller reads a dual-gyro IMU (6-axis) and a Barometer at high rate, then runs a PID loop that converts pilot stick demands and measured rotation into four motor commands sent to the ESC. A OSD Chip overlays voltage, timer, and signal data onto the analog video so the pilot sees it in the goggles, and a Black-Box Flash logs gyro and PID traces every flight for tuning afterward.
Power for the boards comes from an integrated Power Distribution Section, whose BEC Regulator regulator drops the 22 V pack down to clean 5 V and 9 V rails. The 9 V rail typically feeds the video transmitter, the 5 V rail the camera and receiver. Filtering capacitors on each rail keep motor noise out of the video feed.
FPV and radio links
Two radio links run at once. The video downlink is the FPV System: an analog FPV Camera built around a CMOS CMOS Image Sensor and a fast Lens Assembly feeds a Video Transmitter on 5.8 GHz, which radiates through a circular-polarized VTX Antenna. Output is switchable from 25 mW for close racing up to 800 mW. Analog video is chosen here for its near-zero latency, which matters more than image quality on a race course.
The control uplink is the Control Receiver, an ExpressLRS receiver on 2.4 GHz built around a LoRa Transceiver IC transceiver and a small RX Antenna. ExpressLRS trades raw bandwidth for range and update rate, delivering stick data to the flight controller hundreds of times a second with low latency.
Energy and accessories
The Power System system centers on a 6S1P 1300 mAh LiPo Battery Pack: six LiPo Cell units in series for about 22.2 V nominal, wrapped together with a BMS Board balance lead. A high discharge rating, often 100C or more, lets the pack deliver the brief current bursts the motors demand without sagging. The pack connects through a pair of XT60 Connector plugs and a 12 AWG Main Power Lead, with a Solder-On Capacitor soldered across the ESC input. A flight typically lasts two to four minutes.
A small Buzzer & LED Kit rounds out the build. A Lost-Model Buzzer sounds to locate a crashed aircraft, and two Addressable LED Strip runs show arming state and team color. None of these affect flight, but they make a race-day quad practical to run and recover.
Micro Racing Quadcopter parts and their functions
8 top-level parts · 506 parts in total · full bill of materials below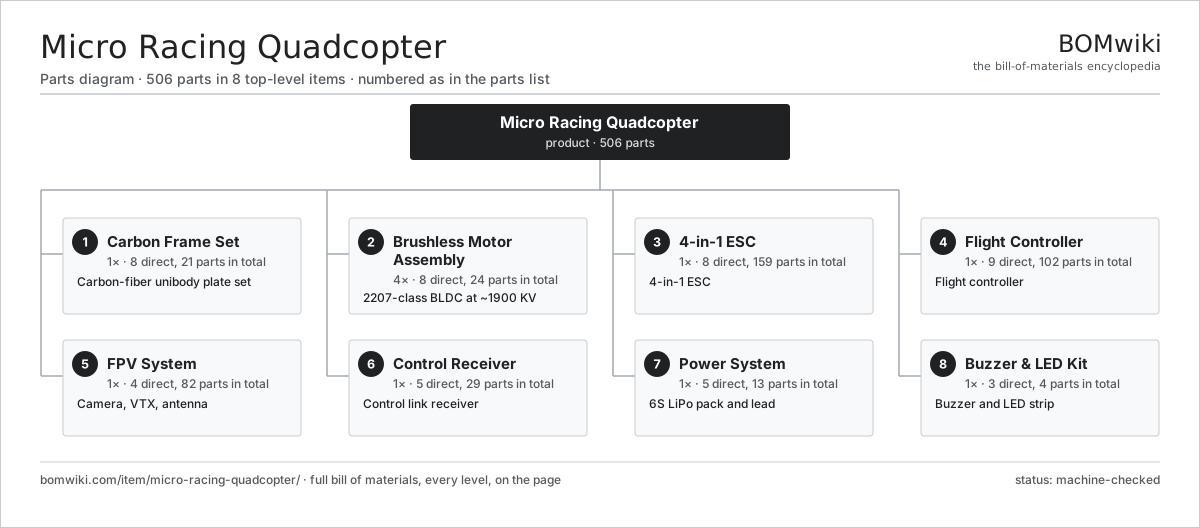
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Carbon Frame Set 8 parts | 1× | Carbon-fiber unibody plate set |
| 2 | Brushless Motor Assembly 8 parts | 4× | 2207-class BLDC at ~1900 KV |
| 3 | 4-in-1 ESC 8 parts | 1× | 4-in-1 ESC |
| 4 | Flight Controller 9 parts | 1× | Flight controller |
| 5 | FPV System 4 parts | 1× | Camera, VTX, antenna |
| 6 | Control Receiver 5 parts | 1× | Control link receiver |
| 7 | Power System 5 parts | 1× | 6S LiPo pack and lead |
| 8 | Buzzer & LED Kit 3 parts | 1× | Buzzer and LED strip |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Micro Racing Quadcopter
8 top-level lines · 80 rows shown · 506 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Carbon Frame Set 8 parts | micro-racing-quadcopter-frame | 1× | 1 | 21 | assembly |
| 1.1 | Top Plate | micro-racing-quadcopter-top-plate | 1× | 1 | · | part |
| 1.2 | Bottom Plate | micro-racing-quadcopter-bottom-plate | 1× | 1 | · | part |
| 1.3 | Frame Arm | micro-racing-quadcopter-arm | 4× | 4 | · | part |
| 1.4 | Aluminum Standoff | micro-racing-quadcopter-standoff | 8× | 8 | · | part |
| 1.5 | Camera Mount | micro-racing-quadcopter-camera-mount | 1× | 1 | · | part |
| 1.6 | Antenna Mount | micro-racing-quadcopter-antenna-mount | 1× | 1 | · | part |
| 1.7 | TPU Soft-Mount Print | micro-racing-quadcopter-tpu-print | 4× | 4 | · | part |
| 1.8 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Brushless Motor Assembly 8 parts | micro-racing-quadcopter-motor | 4× | 4 | 24 | assembly |
| 2.1 | Stator Assembly 3 parts | stator-assembly | 1× | 4 | 3 | assembly |
| 2.1.1 | Stator Core (laminations) | stator-core | 1× | 4 | · | part |
| 2.1.2 | Copper Winding | copper-winding | 1× | 4 | · | part |
| 2.1.3 | Slot Insulation | stator-insulation | 1× | 4 | · | part |
| 2.2 | Motor Bell | micro-racing-quadcopter-bell | 1× | 4 | · | part |
| 2.3 | Neodymium Magnet | neodymium-magnet | 14× | 56 | · | part |
| 2.4 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 2.5 | Motor Shaft | micro-racing-quadcopter-motor-shaft | 1× | 4 | · | part |
| 2.6 | Motor Base | micro-racing-quadcopter-motor-base | 1× | 4 | · | part |
| 2.7 | Retaining Circlip | micro-racing-quadcopter-circlip | 1× | 4 | · | part |
| 2.8 | Propeller | propeller | 1× | 4 | · | part |
| 3 | 4-in-1 ESC 8 parts | micro-racing-quadcopter-esc-stack | 1× | 1 | 159 | assembly |
| 3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.2 | Microcontroller | mcu | 4× | 4 | · | part |
| 3.3 | Gate Driver IC | gate-driver-ic | 4× | 4 | · | part |
| 3.4 | Power MOSFET | mosfet | 24× | 24 | · | part |
| 3.5 | Current-Sense Shunt | micro-racing-quadcopter-shunt | 4× | 4 | · | part |
| 3.6 | Low-ESR Bulk Capacitor | micro-racing-quadcopter-esc-cap | 1× | 1 | · | part |
| 3.7 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 3.8 | Connector | connector | 1× | 1 | · | part |
| 4 | Flight Controller 9 parts | micro-racing-quadcopter-fc | 1× | 1 | 102 | assembly |
| 4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.3 | IMU (6-axis) | imu | 1× | 1 | · | part |
| 4.4 | Barometer | barometer | 1× | 1 | · | part |
| 4.5 | OSD Chip | micro-racing-quadcopter-osd-chip | 1× | 1 | · | part |
| 4.6 | Black-Box Flash | micro-racing-quadcopter-blackbox-flash | 1× | 1 | · | part |
| 4.7 | Power Distribution Section 3 parts | micro-racing-quadcopter-pdb-section | 1× | 1 | 4 | assembly |
| 4.7.1 | BEC Regulator | micro-racing-quadcopter-bec | 1× | 1 | · | part |
| 4.7.2 | PDB Filter Capacitor | micro-racing-quadcopter-pdb-cap | 1× | 1 | · | part |
| 4.7.3 | Power MOSFET | mosfet | 2× | 2 | · | part |
| 4.8 | SMD Passive (R/C/L) | smd-passives | 90× | 90 | · | part |
| 4.9 | Connector | connector | 2× | 2 | · | part |
| 5 | FPV System 4 parts | micro-racing-quadcopter-fpv-system | 1× | 1 | 82 | assembly |
| 5.1 | FPV Camera 6 parts | micro-racing-quadcopter-fpv-camera | 1× | 1 | 35 | assembly |
| 5.1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 5.1.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 5.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.1.4 | Camera DSP | micro-racing-quadcopter-cam-dsp | 1× | 1 | · | part |
| 5.1.5 | Camera Housing | micro-racing-quadcopter-cam-housing | 1× | 1 | · | part |
| 5.1.6 | SMD Passive (R/C/L) | smd-passives | 30× | 30 | · | part |
| 5.2 | Video Transmitter 6 parts | micro-racing-quadcopter-vtx | 1× | 1 | 45 | assembly |
| 5.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.2.3 | RF Power Amplifier | micro-racing-quadcopter-rf-pa | 1× | 1 | · | part |
| 5.2.4 | VTX Heatsink | micro-racing-quadcopter-heatsink | 1× | 1 | · | part |
| 5.2.5 | SMD Passive (R/C/L) | smd-passives | 40× | 40 | · | part |
| 5.2.6 | Connector | connector | 1× | 1 | · | part |
| 5.3 | VTX Antenna | micro-racing-quadcopter-vtx-antenna | 1× | 1 | · | part |
| 5.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 6 | Control Receiver 5 parts | micro-racing-quadcopter-rx | 1× | 1 | 29 | assembly |
| 6.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.3 | LoRa Transceiver IC | micro-racing-quadcopter-lora-ic | 1× | 1 | · | part |
| 6.4 | RX Antenna | micro-racing-quadcopter-rx-antenna | 1× | 1 | · | part |
| 6.5 | SMD Passive (R/C/L) | smd-passives | 25× | 25 | · | part |
| 7 | Power System 5 parts | micro-racing-quadcopter-power | 1× | 1 | 13 | assembly |
| 7.1 | LiPo Battery Pack 4 parts | micro-racing-quadcopter-lipo-pack | 1× | 1 | 9 | assembly |
| 7.1.1 | LiPo Cell | lipo-cell | 6× | 6 | · | part |
| 7.1.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 7.1.3 | Pack Shrink Wrap | micro-racing-quadcopter-pack-wrap | 1× | 1 | · | part |
| 7.1.4 | Balance Lead | micro-racing-quadcopter-balance-lead | 1× | 1 | · | part |
| 7.2 | XT60 Connector | xt60-connector | 1× | 1 | · | part |
| 7.3 | Main Power Lead | micro-racing-quadcopter-power-lead | 1× | 1 | · | part |
| 7.4 | Solder-On Capacitor | micro-racing-quadcopter-cap | 1× | 1 | · | part |
| 7.5 | Battery Strap | micro-racing-quadcopter-battery-strap | 1× | 1 | · | part |
| 8 | Buzzer & LED Kit 3 parts | micro-racing-quadcopter-signal-kit | 1× | 1 | 4 | assembly |
| 8.1 | Lost-Model Buzzer | micro-racing-quadcopter-buzzer | 1× | 1 | · | part |
| 8.2 | Addressable LED Strip | micro-racing-quadcopter-led-strip | 2× | 2 | · | part |
| 8.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Cargo Delivery Drone
545 parts · shares 15 with this page
 Fixed-Wing Survey Drone
382 parts · shares 15 with this page
 Fixed-Wing UAV
308 parts · shares 15 with this page
 Quadcopter Drone
244 parts · shares 15 with this page
Parcel Delivery Drone
564 parts · shares 14 with this page
 Tiltrotor UAV
341 parts · shares 10 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $50k–$300M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇺🇸Boeing
boeing.com ↗
|
Arlington, US | Aerospace OEM | made to order | 40–80 wks |
|
🇫🇷Airbus
airbus.com ↗
|
Toulouse, FR | Aerospace OEM | made to order | 40–80 wks |
| lockheedmartin.com ↗ | Bethesda, US | Aerospace & defense | made to order | 40–80 wks |
|
🇧🇷Embraer
embraer.com ↗
|
São José dos Campos, BR | Aircraft OEM | made to order | 40–80 wks |
| txtav.com ↗ | Wichita, US | Aircraft OEM | made to order | 40–80 wks |
1,094-word article