Quadcopter Drone
ProductOverview
A quadcopter is a rotary-wing aircraft lifted and steered by four fixed-pitch propellers arranged at the corners of an X-shaped frame. With no swashplate or tail rotor, it controls itself purely by varying the speed of its four motors, which makes it mechanically simple and highly maneuverable. This class carries a stabilized camera on a motorized gimbal, GPS for position hold, and a radio link back to a ground controller, the configuration used for aerial photography and inspection.
How it works
Lift comes from four Propulsion Arm units, each a carbon tube carrying a brushless motor, an electronic speed controller, and a propeller. Two rotors spin clockwise and two counter-clockwise so their torques cancel in steady hover. The aircraft maneuvers by differential thrust: speeding up one pair and slowing the other rolls, pitches, or yaws the craft without any moving control surfaces.
Coordinating all four motors is the Flight Controller, which fuses readings from an inertial measurement unit and a barometer hundreds of times per second to estimate attitude and altitude, then commands each speed controller to hold the craft stable. The GPS Module adds absolute position so the drone can hover in place or follow a waypoint route against wind. Pilot commands arrive over the Radio Link link, which also streams telemetry and a video feed back to the operator.
Power for the entire vehicle comes from the LiPo Battery, a lithium-polymer pack whose high discharge rate feeds the motors during aggressive maneuvers. Imaging is the payload's purpose: the Gimbal Camera mounts the sensor on a three-axis motorized gimbal that actively counter-rotates against the airframe's motion, isolating the camera from vibration and tilt to keep footage level and smooth. The Airframe ties these subsystems together while keeping mass low enough to maximize flight time.
Quadcopter Drone parts and their functions
7 top-level parts · 244 parts in total · full bill of materials below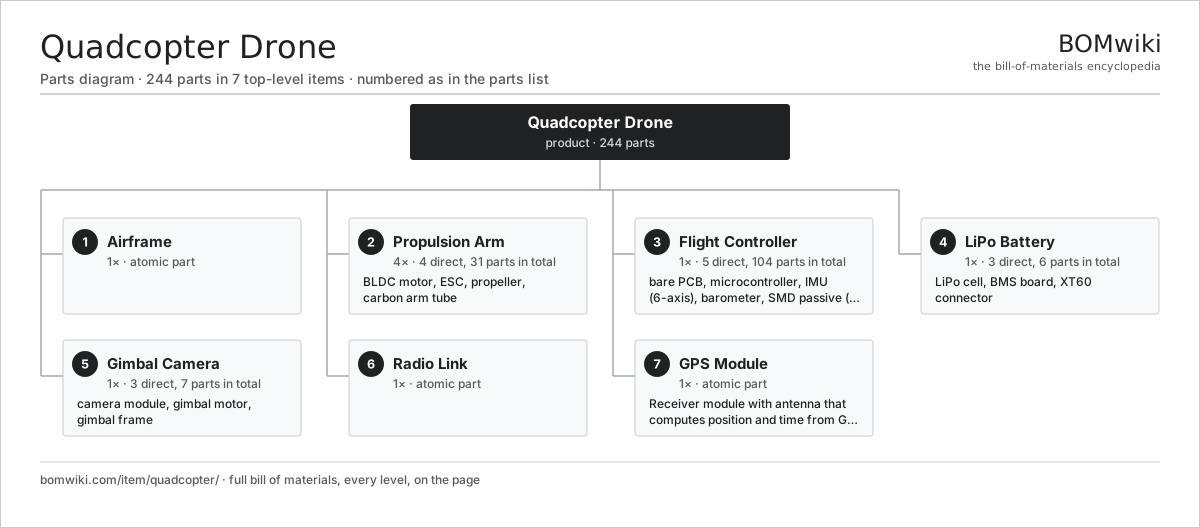
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Airframe | 1× | |
| 2 | Propulsion Arm 4 parts | 4× | |
| 3 | Flight Controller 5 parts | 1× | |
| 4 | LiPo Battery 3 parts | 1× | |
| 5 | Gimbal Camera 3 parts | 1× | |
| 6 | Radio Link | 1× | |
| 7 | GPS Module | 1× | Receiver module with antenna that computes position and time from GNSS satellite signals. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Quadcopter Drone
7 top-level lines · 33 rows shown · 244 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Airframe | drone-frame | 1× | 1 | · | part |
| 2 | Propulsion Arm 4 parts | propulsion-arm | 4× | 4 | 31 | assembly |
| 2.1 | BLDC Motor 4 parts | bldc-motor-small | 1× | 4 | 20 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 4 | 3 | assembly |
| 2.1.2 | Neodymium Magnet | neodymium-magnet | 14× | 56 | · | part |
| 2.1.3 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 2.1.4 | Motor Bell | motor-bell | 1× | 4 | · | part |
| 2.2 | ESC 4 parts | esc | 1× | 4 | 9 | assembly |
| 2.2.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 2.2.2 | Power MOSFET | mosfet | 6× | 24 | · | part |
| 2.2.3 | Gate Driver IC | gate-driver-ic | 1× | 4 | · | part |
| 2.2.4 | Microcontroller | mcu | 1× | 4 | · | part |
| 2.3 | Propeller | propeller | 1× | 4 | · | part |
| 2.4 | Carbon Arm Tube | arm-tube | 1× | 4 | · | part |
| 3 | Flight Controller 5 parts | flight-controller | 1× | 1 | 104 | assembly |
| 3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.3 | IMU (6-axis) | imu | 1× | 1 | · | part |
| 3.4 | Barometer | barometer | 1× | 1 | · | part |
| 3.5 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 4 | LiPo Battery 3 parts | drone-battery | 1× | 1 | 6 | assembly |
| 4.1 | LiPo Cell | lipo-cell | 4× | 4 | · | part |
| 4.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 4.3 | XT60 Connector | xt60-connector | 1× | 1 | · | part |
| 5 | Gimbal Camera 3 parts | gimbal-camera | 1× | 1 | 7 | assembly |
| 5.1 | Camera Module 3 parts | camera-module | 1× | 1 | 3 | assembly |
| 5.1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 5.1.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 5.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.2 | Gimbal Motor | gimbal-motor | 3× | 3 | · | part |
| 5.3 | Gimbal Frame | gimbal-frame | 1× | 1 | · | part |
| 6 | Radio Link | drone-radio | 1× | 1 | · | part |
| 7 | GPS Module | gps-module | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Cargo Delivery Drone
545 parts · shares 18 with this page
 Fixed-Wing Survey Drone
382 parts · shares 18 with this page
 Fixed-Wing UAV
308 parts · shares 18 with this page
 Micro Racing Quadcopter
506 parts · shares 15 with this page
 Tiltrotor UAV
341 parts · shares 10 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $50k–$300M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇺🇸Boeing
boeing.com ↗
|
Arlington, US | Aerospace OEM | made to order | 40–80 wks |
|
🇫🇷Airbus
airbus.com ↗
|
Toulouse, FR | Aerospace OEM | made to order | 40–80 wks |
| lockheedmartin.com ↗ | Bethesda, US | Aerospace & defense | made to order | 40–80 wks |
|
🇧🇷Embraer
embraer.com ↗
|
São José dos Campos, BR | Aircraft OEM | made to order | 40–80 wks |
| txtav.com ↗ | Wichita, US | Aircraft OEM | made to order | 40–80 wks |
306-word article