Cartesian Pick Robot
ProductOverview
A Cartesian pick robot positions a tool anywhere over a rectangular work area by stacking three linear axes at right angles, one for each coordinate. Because every axis moves in a straight line, the kinematics are trivial: an X, Y, Z command maps directly to three motor positions with no trigonometry, which makes the machine accurate over a large footprint and simple to program. That is why the Cartesian layout dominates flat pick-and-place work, machine tending, dispensing, and tray loading, where parts sit on a plane or in a shallow pallet. The machine hangs from an overhead Support Frame so the floor under it stays clear for fixtures, trays, and conveyors. This product covers a two-metre X reach with vision-guided picking of randomly placed parts.
Frame and the three axes
The structure is a bolted aluminium Support Frame of four Upright columns, two Top Beam beams carrying the bridge, and Base Beam floor beams that also locate the work fixtures, leveled on Leveling Foot feet. The three axes are built from the same parts in different combinations. The long X Bridge Axis bridge uses a steel-cord Drive Belt because a belt moves fast over a long stroke without a heavy rotating screw. The shorter Y Carriage Axis and the vertical Z Vertical Axis use a Ball Screw, which trades top speed for the stiffness and fine resolution wanted on short, precise moves. Each axis rides profiled Linear Guide Rail rails and is driven by a geared Servo Motor, and the Z axis adds a Z Holding Brake so the tool cannot fall when power is cut.
End effector
The tool itself bolts to the Pick Tool plate, which combines two gripping methods so the robot handles mixed parts. A set of Suction Cup bellows cups picks flat or smooth parts, supplied by a Vacuum Ejector venturi that makes vacuum directly from shop air, so no separate pump is needed. A Pneumatic Gripper with hardened Gripper Finger fingers handles rigid parts that suction cannot hold. A Part Sensor confirms a part is actually held before the robot starts a move, so a missed pick does not turn into a dropped part across the cell.
Cable management
Power, feedback, and air reach the moving carriages through the Cable Carriers energy chains. A X Energy Chain flexes along the X stroke and a Y Energy Chain along Y, carrying the Wire Bundle cores and two Air Hose lines for the vacuum ejector and the gripper. Sizing the bend radius and the fill of these chains correctly is what keeps a fast machine from suffering cable fatigue, since the X chain alone may flex millions of times a year.
Control and vision
A Motion Controller houses the Control Board motion compute, one Servo Drive per axis, an I/O Board for valves and signals, and a touch Operator Panel. It interpolates the three axes together to draw straight lines and arcs through the work envelope rather than moving one axis at a time, which is what makes the cycle fast. The Sensor Set gives it state: a Home Switch and dual Limit Switch switches per axis, Axis Encoder feedback, and a fixed Vision Camera that locates randomly placed parts on the plane so the robot can pick from a loose tray rather than a precise fixture. Vision-guided picking is what turns a blind pick-and-place machine into one that copes with parts that arrive in varying positions.
Safety and services
Because an operator loads and unloads trays at the cell edge, the Safety Set encloses the working zone with Guard Panel panels, stops motion through an access Light Curtain, and forces power off through a dual-channel Safety Relay and Emergency Stop buttons. The Electrical System system holds the drives and distribution in a Control Cabinet with a Power Supply, conditions shop air through a Air Preparation Unit unit, and ties the machine together with a Machine Harness. In use these robots load CNC machines, fill blister trays, palletize light parts, and tend test stations, anywhere the work is laid out on a plane and the cost and complexity of a six-axis arm are not justified. The flat kinematics also make them easy to maintain: a worn belt or screw is a stocked spare, and re-homing the machine restores full accuracy without recalibrating a joint model.
Cartesian Pick Robot parts and their functions
10 top-level parts · 781 parts in total · full bill of materials below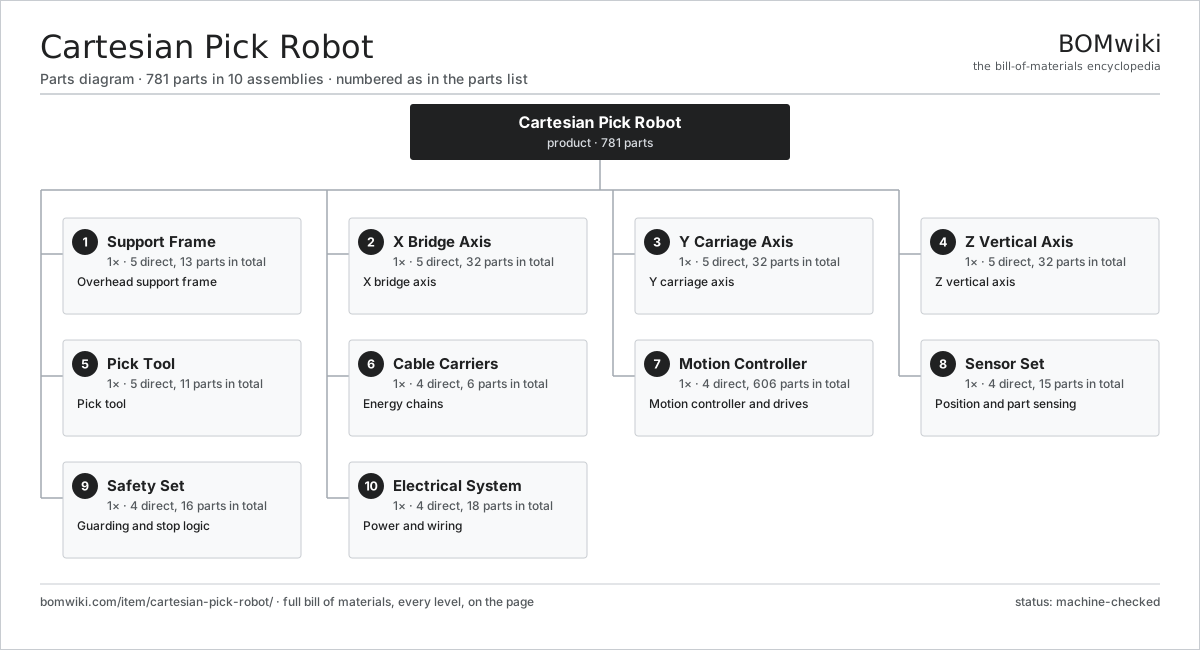
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Support Frame 5 parts | 1× | Overhead support frame |
| 2 | X Bridge Axis 5 parts | 1× | X bridge axis |
| 3 | Y Carriage Axis 5 parts | 1× | Y carriage axis |
| 4 | Z Vertical Axis 5 parts | 1× | Z vertical axis |
| 5 | Pick Tool 5 parts | 1× | Pick tool |
| 6 | Cable Carriers 4 parts | 1× | Energy chains |
| 7 | Motion Controller 4 parts | 1× | Motion controller and drives |
| 8 | Sensor Set 4 parts | 1× | Position and part sensing |
| 9 | Safety Set 4 parts | 1× | Guarding and stop logic |
| 10 | Electrical System 4 parts | 1× | Power and wiring |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Cartesian Pick Robot
10 top-level lines · 87 rows shown · 781 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Support Frame 5 parts | cartesian-pick-robot-frame | 1× | 1 | 13 | assembly |
| 1.1 | Upright | cartesian-pick-robot-upright | 4× | 4 | · | part |
| 1.2 | Top Beam | cartesian-pick-robot-top-beam | 2× | 2 | · | part |
| 1.3 | Base Beam | cartesian-pick-robot-base-beam | 2× | 2 | · | part |
| 1.4 | Leveling Foot | cartesian-pick-robot-foot | 4× | 4 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | X Bridge Axis 5 parts | cartesian-pick-robot-x-axis | 1× | 1 | 32 | assembly |
| 2.1 | Bridge Beam | cartesian-pick-robot-x-beam | 1× | 1 | · | part |
| 2.2 | X Servo 3 parts | cartesian-pick-robot-x-motor | 1× | 1 | 27 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.3 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 2.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 2.5 | X Carriage | cartesian-pick-robot-x-carriage | 1× | 1 | · | part |
| 3 | Y Carriage Axis 5 parts | cartesian-pick-robot-y-axis | 1× | 1 | 32 | assembly |
| 3.1 | Y Beam | cartesian-pick-robot-y-beam | 1× | 1 | · | part |
| 3.2 | Y Servo 3 parts | cartesian-pick-robot-y-motor | 1× | 1 | 27 | assembly |
| 3.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 3.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 3.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 3.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 3.5 | Y Carriage | cartesian-pick-robot-y-carriage | 1× | 1 | · | part |
| 4 | Z Vertical Axis 5 parts | cartesian-pick-robot-z-axis | 1× | 1 | 32 | assembly |
| 4.1 | Z Column | cartesian-pick-robot-z-column | 1× | 1 | · | part |
| 4.2 | Z Servo 3 parts | cartesian-pick-robot-z-motor | 1× | 1 | 27 | assembly |
| 4.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 4.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 4.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 4.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 4.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 4.5 | Z Holding Brake | cartesian-pick-robot-z-brake | 1× | 1 | · | part |
| 5 | Pick Tool 5 parts | cartesian-pick-robot-end-effector | 1× | 1 | 11 | assembly |
| 5.1 | Tool Plate | cartesian-pick-robot-tool-plate | 1× | 1 | · | part |
| 5.2 | Suction Cup | cartesian-pick-robot-suction-cup | 4× | 4 | · | part |
| 5.3 | Pneumatic Gripper 3 parts | cartesian-pick-robot-pneumatic-gripper | 1× | 1 | 4 | assembly |
| 5.3.1 | Gripper Body | cartesian-pick-robot-gripper-body | 1× | 1 | · | part |
| 5.3.2 | Gripper Finger | cartesian-pick-robot-gripper-finger | 2× | 2 | · | part |
| 5.3.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 5.4 | Vacuum Ejector | cartesian-pick-robot-vacuum-ejector | 1× | 1 | · | part |
| 5.5 | Part Sensor | cartesian-pick-robot-part-sensor | 1× | 1 | · | part |
| 6 | Cable Carriers 4 parts | cartesian-pick-robot-cable-carrier | 1× | 1 | 6 | assembly |
| 6.1 | X Energy Chain | cartesian-pick-robot-x-chain | 1× | 1 | · | part |
| 6.2 | Y Energy Chain | cartesian-pick-robot-y-chain | 1× | 1 | · | part |
| 6.3 | Wire Bundle | wire-bundle | 2× | 2 | · | part |
| 6.4 | Air Hose | cartesian-pick-robot-air-hose | 2× | 2 | · | part |
| 7 | Motion Controller 4 parts | cartesian-pick-robot-controller | 1× | 1 | 606 | assembly |
| 7.1 | Control Board 4 parts | cartesian-pick-robot-control-board | 1× | 1 | 193 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 180× | 180 | · | part |
| 7.1.4 | Connector | connector | 10× | 10 | · | part |
| 7.2 | Servo Drive 3 parts | cartesian-pick-robot-servo-drive | 3× | 3 | 112 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 3 | · | part |
| 7.2.2 | Microcontroller | mcu | 1× | 3 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 110× | 330 | · | part |
| 7.3 | I/O Board 3 parts | cartesian-pick-robot-io-board | 1× | 1 | 75 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.3.2 | Relay | relay | 4× | 4 | · | part |
| 7.3.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 7.4 | Operator Panel 2 parts | cartesian-pick-robot-hmi | 1× | 1 | 2 | assembly |
| 7.4.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8 | Sensor Set 4 parts | cartesian-pick-robot-sensor-set | 1× | 1 | 15 | assembly |
| 8.1 | Home Switch | cartesian-pick-robot-home-switch | 3× | 3 | · | part |
| 8.2 | Limit Switch | cartesian-pick-robot-limit-switch | 6× | 6 | · | part |
| 8.3 | Axis Encoder | cartesian-pick-robot-axis-encoder | 3× | 3 | · | part |
| 8.4 | Vision Camera 3 parts | cartesian-pick-robot-vision-camera | 1× | 1 | 3 | assembly |
| 8.4.1 | Image Sensor | cartesian-pick-robot-image-sensor | 1× | 1 | · | part |
| 8.4.2 | Camera Lens | cartesian-pick-robot-camera-lens | 1× | 1 | · | part |
| 8.4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9 | Safety Set 4 parts | cartesian-pick-robot-safety-set | 1× | 1 | 16 | assembly |
| 9.1 | Guard Panel | cartesian-pick-robot-guard-panel | 6× | 6 | · | part |
| 9.2 | Light Curtain | cartesian-pick-robot-light-curtain | 1× | 1 | · | part |
| 9.3 | Safety Relay 3 parts | cartesian-pick-robot-safety-relay | 1× | 1 | 7 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.3.2 | Relay | relay | 4× | 4 | · | part |
| 9.3.3 | Microcontroller | mcu | 2× | 2 | · | part |
| 9.4 | Emergency Stop | cartesian-pick-robot-estop | 2× | 2 | · | part |
| 10 | Electrical System 4 parts | cartesian-pick-robot-electrical | 1× | 1 | 18 | assembly |
| 10.1 | Control Cabinet | cartesian-pick-robot-cabinet | 1× | 1 | · | part |
| 10.2 | Power Supply | power-supply | 1× | 1 | · | part |
| 10.3 | Air Preparation Unit | cartesian-pick-robot-air-prep | 1× | 1 | · | part |
| 10.4 | Machine Harness 2 parts | cartesian-pick-robot-harness | 1× | 1 | 15 | assembly |
| 10.4.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 10.4.2 | Connector | connector | 14× | 14 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 7 with this page
Robotic Grinding Cell
1,419 parts · shares 7 with this page
Tote Handling Robot
1,042 parts · shares 6 with this page
Gantry Loading Robot
800 parts · shares 5 with this page
Robotic Palletizing Cell
986 parts · shares 5 with this page
Robotic Screwdriving Cell
2,109 parts · shares 5 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
831-word article