Robotic Palletizing Cell
ProductOverview
A robotic palletizing cell is a fenced workstation built around an articulated arm whose only job is to stack cases onto pallets in a programmed pattern. It replaces the older approach of a fixed-tooling layer palletizer with something far more flexible: where a mechanical palletizer needs hardware changes to switch products, the Palletizing Robot just loads a different pattern recipe. That flexibility is why these cells dominate mixed-SKU lines and contract packing, where the same machine must palletize many case sizes through the shift.
How it works
Cases arrive on the Infeed Conveyor, a powered roller bed that meters them to a fixed pick point and squares them against guide rails. A Row Former can group several cases into a row so the robot lifts a whole row at once, which is how a single-arm cell reaches throughputs above a thousand cases an hour. The robot picks with its End-of-Arm Tool, a tool that combines a zoned Vacuum Cup Bank gripping the case top with a retractable Support Fork that slides under heavy or unstable loads. Vacuum comes from a Venturi Generator Venturi, so the tool needs only compressed air and no onboard pump.
The arm itself is four cast links driven by four identical Servo Joint units. Each joint pairs an AC Servo Motor with a cycloidal RV Reducer, an absolute Encoder, and a spring-applied brake. Four axes are enough because a Wrist keeps the tool level and the fourth axis only rotates the case to the orientation the pattern calls for. The Cell Controller runs the kinematics and generates the stack pattern from the case dimensions and the pallet footprint, so an operator describes the case and the controller computes where every box goes.
Pallets and interleaving
A self-contained cell supplies its own empty pallets. The Pallet Dispenser holds a magazine of stacked empties, supports all but the lowest on retracting pawls, and lowers one at a time onto a Chain Conveyor that carries it into the build position and the full pallet out. For loads that need stability, the Slip-Sheet Dispenser dispenser places a tier sheet between layers; a vacuum head lifts one sheet from a magazine and a placement arm lays it on the building stack. Slip sheets stop layers from sliding and let lighter cases carry a taller stack without crushing.
Safety
A robot moving 160 kg fast inside a small footprint is the hazard the cell is designed around, so the Safety System system is integral rather than bolted on. A Light Curtain guards the pallet exit so a full pallet can leave but a person cannot reach in; muting logic lets the pallet pass without tripping the curtain. A Laser Area Scanner watches the floor zone, and coded interlocks on the Guard Fence access gate stop the robot the moment maintenance opens it. All of this runs through a dual-channel Safety Controller rated to performance level e, separate from the motion controller so a controller fault cannot defeat the stop.
Materials and construction
The robot links are cast aluminium for stiffness at low arm weight, with the base a heavier cast-iron foot that anchors the tipping moment of a loaded arm at full reach. Joint reducers run in oil behind an Oil Seal and use cycloidal gearing for shock tolerance, since palletizing is a duty of constant start-stop loading. The EOAT frame is welded aluminium so the arm carries tool mass, not steel. Conveyor rollers are steel tube on internal bearings, and the guard fence is welded-wire mesh on bolt-down posts. The control cabinet is sheet steel with forced-air cooling for the servo drives.
Control and integration
The Cell Controller cabinet holds three things working together: a robot motion controller running the arm, one Servo Drive per axis, and a cell Cell PLC that sequences the conveyors, dispensers, and the handshake with upstream packing. An operator works from the Operator HMI to pick a pattern, watch counts, and clear faults. Because the pattern is generated from case and pallet data, commissioning a new product is a data entry task rather than a tooling change, and the same cell can hold hundreds of stored patterns.
Variants and use
Cells scale by reach and payload: a compact cell palletizes one line to head height, while a long-reach arm on a riser serves two infeed lanes and builds to over two metres. High-rate lines add a second robot or a row-forming infeed; lower-rate cells drop the slip-sheet dispenser and run a single case pick. In service the cell runs unattended between pallet changes, with an operator loading empty pallets and slip sheets and removing finished loads by forklift or an outfeed conveyor. The recurring maintenance is the vacuum cups, which wear against case surfaces, and the gripper valves; the robot joints themselves are sealed and run on long oil-change intervals.
Robotic Palletizing Cell parts and their functions
8 top-level parts · 986 parts in total · full bill of materials below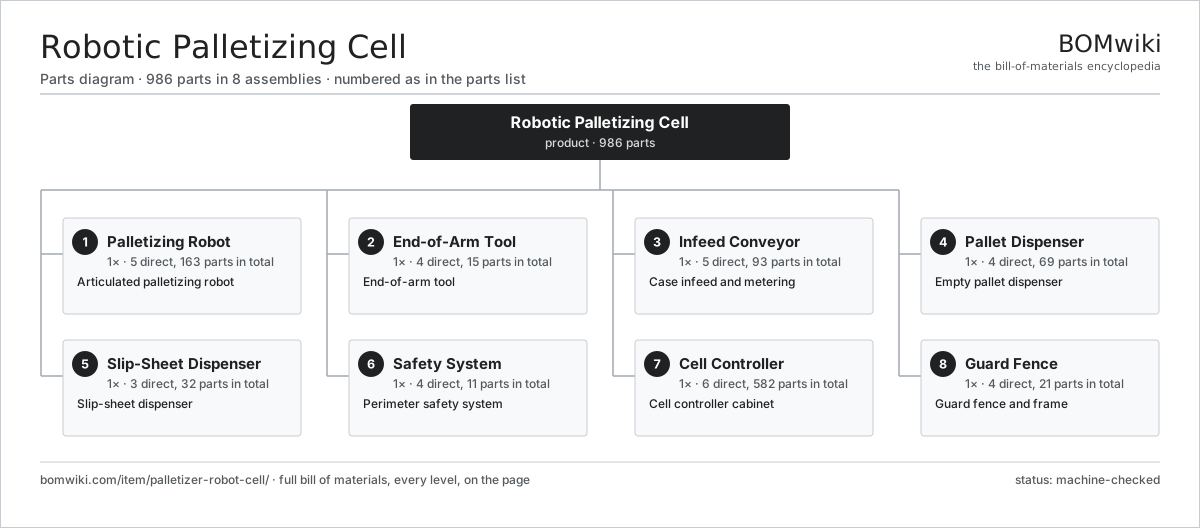
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Palletizing Robot 5 parts | 1× | Articulated palletizing robot |
| 2 | End-of-Arm Tool 4 parts | 1× | End-of-arm tool |
| 3 | Infeed Conveyor 5 parts | 1× | Case infeed and metering |
| 4 | Pallet Dispenser 4 parts | 1× | Empty pallet dispenser |
| 5 | Slip-Sheet Dispenser 3 parts | 1× | Slip-sheet dispenser |
| 6 | Safety System 4 parts | 1× | Perimeter safety system |
| 7 | Cell Controller 6 parts | 1× | Cell controller cabinet |
| 8 | Guard Fence 4 parts | 1× | Guard fence and frame |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Palletizing Cell
8 top-level lines · 109 rows shown · 986 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Palletizing Robot 5 parts | palletizer-robot-cell-robot | 1× | 1 | 163 | assembly |
| 1.1 | Robot Base 3 parts | palletizer-robot-cell-base | 1× | 1 | 3 | assembly |
| 1.1.1 | Base Casting | palletizer-robot-cell-base-casting | 1× | 1 | · | part |
| 1.1.2 | Slewing Bearing | palletizer-robot-cell-slew-bearing | 1× | 1 | · | part |
| 1.1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 1.2 | Arm Link | palletizer-robot-cell-arm-link | 2× | 2 | · | part |
| 1.3 | Wrist 3 parts | palletizer-robot-cell-wrist | 1× | 1 | 4 | assembly |
| 1.3.1 | Wrist Housing | palletizer-robot-cell-wrist-housing | 1× | 1 | · | part |
| 1.3.2 | Tool Flange | palletizer-robot-cell-tool-flange | 1× | 1 | · | part |
| 1.3.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.4 | Servo Joint 5 parts | palletizer-robot-cell-joint | 4× | 4 | 35 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 4 | 24 | assembly |
| 1.4.2 | RV Reducer 5 parts + deeper › | palletizer-robot-cell-reducer | 1× | 4 | 7 | assembly |
| 1.4.3 | Encoder | encoder | 1× | 4 | · | part |
| 1.4.4 | Holding Brake | palletizer-robot-cell-brake | 1× | 4 | · | part |
| 1.4.5 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 1.5 | Arm Cabling 3 parts | palletizer-robot-cell-cabling | 1× | 1 | 14 | assembly |
| 1.5.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.5.2 | Connector | connector | 12× | 12 | · | part |
| 1.5.3 | Cable Track | palletizer-robot-cell-cable-track | 1× | 1 | · | part |
| 2 | End-of-Arm Tool 4 parts | palletizer-robot-cell-eoat | 1× | 1 | 15 | assembly |
| 2.1 | Vacuum Cup Bank 2 parts | palletizer-robot-cell-vacuum-bank | 1× | 1 | 10 | assembly |
| 2.1.1 | Suction Cup | palletizer-robot-cell-suction-cup | 8× | 8 | · | part |
| 2.1.2 | Zone Valve | palletizer-robot-cell-zone-valve | 2× | 2 | · | part |
| 2.2 | Venturi Generator | palletizer-robot-cell-vacuum-generator | 1× | 1 | · | part |
| 2.3 | Support Fork 2 parts | palletizer-robot-cell-fork | 1× | 1 | 3 | assembly |
| 2.3.1 | Fork Tine | palletizer-robot-cell-fork-tine | 2× | 2 | · | part |
| 2.3.2 | Pneumatic Cylinder | pneumatic-cylinder | 1× | 1 | · | part |
| 2.4 | Tool Frame | palletizer-robot-cell-tool-frame | 1× | 1 | · | part |
| 3 | Infeed Conveyor 5 parts | palletizer-robot-cell-infeed-conveyor | 1× | 1 | 93 | assembly |
| 3.1 | Roller Bed 3 parts | palletizer-robot-cell-roller-bed | 1× | 1 | 61 | assembly |
| 3.1.1 | Conveyor Roller | palletizer-robot-cell-roller | 20× | 20 | · | part |
| 3.1.2 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 3.1.3 | Ball Bearing | ball-bearing | 40× | 40 | · | part |
| 3.2 | Row Former 2 parts | palletizer-robot-cell-row-former | 1× | 1 | 4 | assembly |
| 3.2.1 | Guide Rail | palletizer-robot-cell-guide-rail | 2× | 2 | · | part |
| 3.2.2 | Pneumatic Cylinder | pneumatic-cylinder | 2× | 2 | · | part |
| 3.3 | Indexing Stop | palletizer-robot-cell-stop | 2× | 2 | · | part |
| 3.4 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 3.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 3.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 3.4.3 | Encoder | encoder | 1× | 1 | · | part |
| 3.4.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 3.5 | Pressure Sensor | pressure-sensor | 2× | 2 | · | part |
| 4 | Pallet Dispenser 4 parts | palletizer-robot-cell-pallet-dispenser | 1× | 1 | 69 | assembly |
| 4.1 | Pallet Magazine 3 parts | palletizer-robot-cell-magazine | 1× | 1 | 9 | assembly |
| 4.1.1 | Magazine Frame | palletizer-robot-cell-magazine-frame | 1× | 1 | · | part |
| 4.1.2 | Holding Pawl | palletizer-robot-cell-pawl | 4× | 4 | · | part |
| 4.1.3 | Pneumatic Cylinder | pneumatic-cylinder | 4× | 4 | · | part |
| 4.2 | Dispenser Lift | palletizer-robot-cell-fork-lift | 1× | 1 | · | part |
| 4.3 | Chain Conveyor 4 parts | palletizer-robot-cell-chain-conveyor | 1× | 1 | 35 | assembly |
| 4.3.1 | Drag Chain | palletizer-robot-cell-drag-chain | 2× | 2 | · | part |
| 4.3.2 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 4.3.3 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 4.3.4 | Ball Bearing | ball-bearing | 8× | 8 | · | part |
| 4.4 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 4.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 4.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 4.4.3 | Encoder | encoder | 1× | 1 | · | part |
| 4.4.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 5 | Slip-Sheet Dispenser 3 parts | palletizer-robot-cell-slip-sheet | 1× | 1 | 32 | assembly |
| 5.1 | Sheet Magazine | palletizer-robot-cell-sheet-magazine | 1× | 1 | · | part |
| 5.2 | Sheet Vacuum Head 2 parts | palletizer-robot-cell-sheet-vacuum | 1× | 1 | 5 | assembly |
| 5.2.1 | Suction Cup | palletizer-robot-cell-suction-cup | 4× | 4 | · | part |
| 5.2.2 | Venturi Generator | palletizer-robot-cell-vacuum-generator | 1× | 1 | · | part |
| 5.3 | Sheet Placement Arm 3 parts | palletizer-robot-cell-sheet-arm | 1× | 1 | 26 | assembly |
| 5.3.1 | Linear Guide Rail | linear-guide | 1× | 1 | · | part |
| 5.3.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.3.3 | Sheet Arm Frame | palletizer-robot-cell-sheet-frame | 1× | 1 | · | part |
| 6 | Safety System 4 parts | palletizer-robot-cell-safety | 1× | 1 | 11 | assembly |
| 6.1 | Light Curtain 3 parts | palletizer-robot-cell-light-curtain | 2× | 2 | 3 | assembly |
| 6.1.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 6.1.2 | Emitter Bar | palletizer-robot-cell-led-bar | 1× | 2 | · | part |
| 6.1.3 | Receiver Bar | palletizer-robot-cell-photodiode-bar | 1× | 2 | · | part |
| 6.2 | Laser Area Scanner | palletizer-robot-cell-area-scanner | 1× | 1 | · | part |
| 6.3 | Safety Controller | palletizer-robot-cell-safety-relay | 1× | 1 | · | part |
| 6.4 | E-Stop Station | palletizer-robot-cell-estop | 3× | 3 | · | part |
| 7 | Cell Controller 6 parts | palletizer-robot-cell-controller | 1× | 1 | 582 | assembly |
| 7.1 | Robot Controller 5 parts | palletizer-robot-cell-robot-controller | 1× | 1 | 213 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.1.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.1.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 7.1.5 | Connector | connector | 10× | 10 | · | part |
| 7.2 | Servo Drive 4 parts | palletizer-robot-cell-servo-drive | 4× | 4 | 85 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 7.2.2 | IGBT Power Module | igbt-module | 1× | 4 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 80× | 320 | · | part |
| 7.2.4 | Connector | connector | 3× | 12 | · | part |
| 7.3 | Cell PLC 4 parts | palletizer-robot-cell-plc | 1× | 1 | 23 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.3.3 | Relay | relay | 8× | 8 | · | part |
| 7.3.4 | Connector | connector | 12× | 12 | · | part |
| 7.4 | Operator HMI 4 parts | palletizer-robot-cell-hmi | 1× | 1 | 4 | assembly |
| 7.4.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7.4.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 7.4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 7.6 | Cabinet Shell | palletizer-robot-cell-cabinet-shell | 1× | 1 | · | part |
| 8 | Guard Fence 4 parts | palletizer-robot-cell-fence | 1× | 1 | 21 | assembly |
| 8.1 | Mesh Panel | palletizer-robot-cell-mesh-panel | 8× | 8 | · | part |
| 8.2 | Fence Post | palletizer-robot-cell-post | 8× | 8 | · | part |
| 8.3 | Access Gate 3 parts | palletizer-robot-cell-access-gate | 1× | 1 | 4 | assembly |
| 8.3.1 | Gate Frame | palletizer-robot-cell-gate-frame | 1× | 1 | · | part |
| 8.3.2 | Gate Interlock | palletizer-robot-cell-interlock | 1× | 1 | · | part |
| 8.3.3 | Hinge | hinge | 2× | 2 | · | part |
| 8.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Robotic Case Erector
799 parts · shares 9 with this page
Robotic Screwdriving Cell
2,109 parts · shares 10 with this page
 Robotic Assembly Cell
1,746 parts · shares 10 with this page
Robotic Grinding Cell
1,419 parts · shares 10 with this page
Machine Tending Robot
1,174 parts · shares 5 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
878-word article