SCARA Robot
ProductOverview
The SCARA robot is a four-axis selective-compliance assembly arm built for fast, precise pick-and-place, screwdriving, and insertion. Its two rotary shoulder and elbow joints move in a horizontal plane, making the arm stiff vertically but compliant in the plane, which is exactly the behavior peg-in-hole assembly wants. A vertical quill at the tool end adds Z lift and tool rotation, giving four axes that cover the great majority of planar assembly tasks at short cycle times.
Construction
The arm anchors to the Base Assembly, a cast-iron pedestal bolted to the floor. The shoulder axis is the J1 Rotary Joint, an AC servo driving a Harmonic Reducer strain-wave gear with absolute feedback, which swings the Inner Arm Link. At its tip the J2 Rotary Joint drives the elbow through a timing-belt reduction and carries the Outer Arm Link.
The tool end is the Quill Assembly, built around a ball screw-spline shaft: a Z servo actuator turns the ball nut to lift the shaft while a theta servo turns the spline nut to rotate the tool, and a spring-applied brake holds the quill on power loss. End-effectors mount to the Tool Flange with air and signal pass-through. Motor and encoder runs route through the internal Internal Cabling.
All four axes are commanded by the Controller Cabinet cabinet, which houses the motion CPU, four servo drives, the power supply, a dual-channel safety I/O module, and a handheld teach pendant with an E-stop and a three-position enabling switch for safe jogging.
SCARA Robot parts and their functions
9 top-level parts · 519 parts in total · full bill of materials below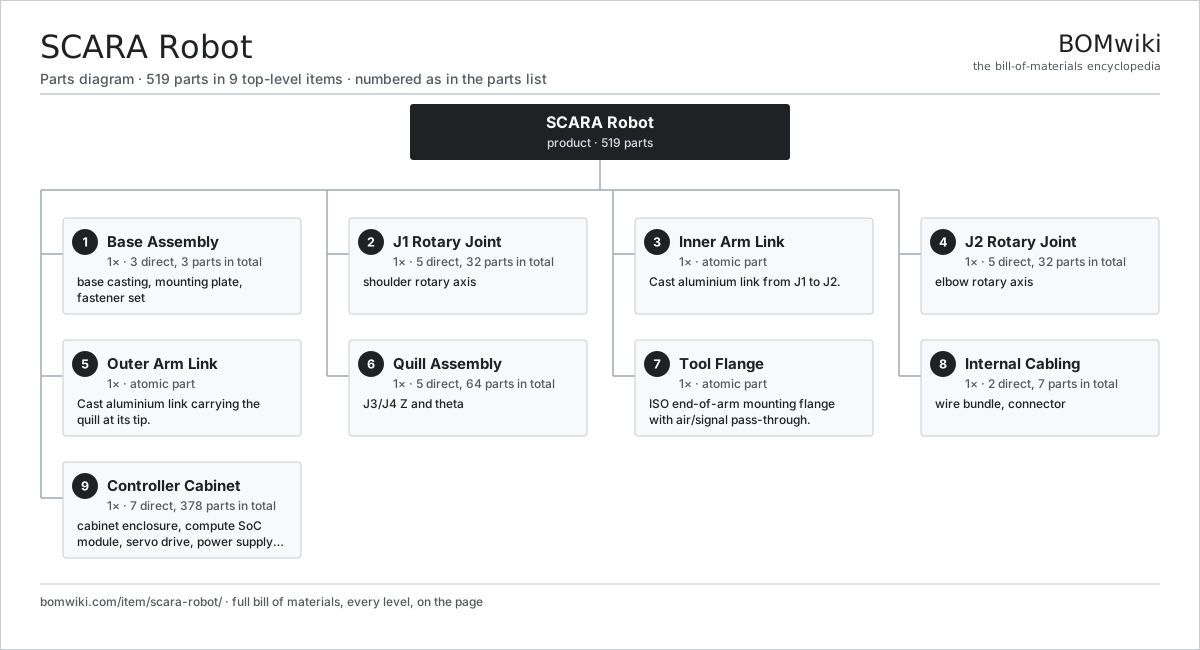
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Base Assembly 3 parts | 1× | Cast iron pedestal anchoring the arm to the floor. |
| 2 | J1 Rotary Joint 5 parts | 1× | shoulder rotary axis |
| 3 | Inner Arm Link | 1× | Cast aluminium link from J1 to J2. |
| 4 | J2 Rotary Joint 5 parts | 1× | elbow rotary axis |
| 5 | Outer Arm Link | 1× | Cast aluminium link carrying the quill at its tip. |
| 6 | Quill Assembly 5 parts | 1× | J3/J4 Z and theta |
| 7 | Tool Flange | 1× | ISO end-of-arm mounting flange with air/signal pass-through. |
| 8 | Internal Cabling 2 parts | 1× | Routed motor, encoder and I/O harnesses through the arm. |
| 9 | Controller Cabinet 7 parts | 1× | Floor cabinet with motion CPU, servo drives, power and safety I/O. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for SCARA Robot
9 top-level lines · 72 rows shown · 519 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Base Assembly 3 parts | scara-robot-base | 1× | 1 | 3 | assembly |
| 1.1 | Base Casting | scara-robot-base-casting | 1× | 1 | · | part |
| 1.2 | Mounting Plate | scara-robot-mounting-plate | 1× | 1 | · | part |
| 1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | J1 Rotary Joint 5 parts | scara-robot-j1-joint | 1× | 1 | 32 | assembly |
| 2.1 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.1.3 | Encoder | encoder | 1× | 1 | · | part |
| 2.1.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 2.2 | Harmonic Reducer 4 parts | scara-robot-harmonic-reducer | 1× | 1 | 4 | assembly |
| 2.2.1 | Wave Generator | scara-robot-wave-generator | 1× | 1 | · | part |
| 2.2.2 | Flexspline | scara-robot-flexspline | 1× | 1 | · | part |
| 2.2.3 | Circular Spline | scara-robot-circular-spline | 1× | 1 | · | part |
| 2.2.4 | Ball Bearing | ball-bearing | 1× | 1 | · | part |
| 2.3 | Encoder | encoder | 1× | 1 | · | part |
| 2.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 3 | Inner Arm Link | scara-robot-inner-arm | 1× | 1 | · | part |
| 4 | J2 Rotary Joint 5 parts | scara-robot-j2-joint | 1× | 1 | 32 | assembly |
| 4.1 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 4.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 4.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 4.1.3 | Encoder | encoder | 1× | 1 | · | part |
| 4.1.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 4.2 | Belt Reduction Drive 4 parts | scara-robot-belt-drive | 1× | 1 | 4 | assembly |
| 4.2.1 | Timing Belt | scara-robot-timing-belt | 1× | 1 | · | part |
| 4.2.2 | Drive Pulley | scara-robot-drive-pulley | 1× | 1 | · | part |
| 4.2.3 | Driven Pulley | scara-robot-driven-pulley | 1× | 1 | · | part |
| 4.2.4 | Belt Tensioner | scara-robot-belt-tensioner | 1× | 1 | · | part |
| 4.3 | Encoder | encoder | 1× | 1 | · | part |
| 4.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 4.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 5 | Outer Arm Link | scara-robot-outer-arm | 1× | 1 | · | part |
| 6 | Quill Assembly 5 parts | scara-robot-quill-assembly | 1× | 1 | 64 | assembly |
| 6.1 | Ball Screw-Spline Shaft 3 parts | scara-robot-ball-screw-spline | 1× | 1 | 3 | assembly |
| 6.1.1 | Spline Shaft | scara-robot-spline-shaft | 1× | 1 | · | part |
| 6.1.2 | Ball Nut | scara-robot-ball-nut | 1× | 1 | · | part |
| 6.1.3 | Spline Nut | scara-robot-spline-nut | 1× | 1 | · | part |
| 6.2 | Z Servo Actuator 3 parts | scara-robot-z-actuator | 1× | 1 | 29 | assembly |
| 6.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.2.2 | Belt Reduction Drive 4 parts + deeper › | scara-robot-belt-drive | 1× | 1 | 4 | assembly |
| 6.2.3 | Encoder | encoder | 1× | 1 | · | part |
| 6.3 | Theta Servo Actuator 3 parts | scara-robot-theta-actuator | 1× | 1 | 29 | assembly |
| 6.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.3.2 | Belt Reduction Drive 4 parts + deeper › | scara-robot-belt-drive | 1× | 1 | 4 | assembly |
| 6.3.3 | Encoder | encoder | 1× | 1 | · | part |
| 6.4 | Z-Axis Brake | scara-robot-z-brake | 1× | 1 | · | part |
| 6.5 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 7 | Tool Flange | scara-robot-tool-flange | 1× | 1 | · | part |
| 8 | Internal Cabling 2 parts | scara-robot-cabling | 1× | 1 | 7 | assembly |
| 8.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 8.2 | Connector | connector | 6× | 6 | · | part |
| 9 | Controller Cabinet 7 parts | scara-robot-controller | 1× | 1 | 378 | assembly |
| 9.1 | Cabinet Enclosure | scara-robot-cabinet-enclosure | 1× | 1 | · | part |
| 9.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 9.3 | Servo Drive 4 parts | servo-drive | 4× | 4 | 91 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 9.3.2 | IGBT Power Module | igbt-module | 1× | 4 | · | part |
| 9.3.3 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 4 | 87 | assembly |
| 9.3.4 | DC-Link Capacitor | dc-link-cap | 2× | 8 | · | part |
| 9.4 | Power Supply | power-supply | 1× | 1 | · | part |
| 9.5 | Safety I/O Module 3 parts | scara-robot-safety-io | 1× | 1 | 6 | assembly |
| 9.5.1 | I/O Board | io-board | 1× | 1 | · | part |
| 9.5.2 | Safety Relay | scara-robot-safety-relay | 1× | 1 | · | part |
| 9.5.3 | Connector | connector | 4× | 4 | · | part |
| 9.6 | Teach Pendant 4 parts | scara-robot-teach-pendant | 1× | 1 | 4 | assembly |
| 9.6.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 9.6.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 9.6.3 | E-Stop Button | scara-robot-estop-button | 1× | 1 | · | part |
| 9.6.4 | Enabling Switch | scara-robot-enabling-switch | 1× | 1 | · | part |
| 9.7 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts 6-Axis Industrial Robot Arm
814 parts · shares 8 with this page
Delta Pick-and-Place Robot
579 parts · shares 8 with this page
 Welding Robot Cell
999 parts · shares 8 with this page
 Humanoid Robot
3,158 parts · shares 3 with this page
 Arc Welding Robot
1,532 parts · shares 3 with this page
Gantry Loading Robot
800 parts · shares 3 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
278-word article