Robotic Assembly Cell
ProductOverview
The Robotic Assembly Cell is a self-contained workcell that assembles small mechanical and electromechanical products in a fixed sequence. A four-axis SCARA Robot Arm sits at the center of the cell and does the handling work: it picks parts presented by the feeders, places them onto a work pallet, and drives press-fit operations against a force-controlled station. The cell is built around repeatable, high-throughput motion rather than flexibility, so every fixture, feeder, and sensor is dedicated to one family of products.
A SCARA arm is chosen over a six-axis articulated robot because the work is planar. Parts arrive on a flat surface, get assembled on a flat pallet, and the only out-of-plane motion needed is a vertical insertion. The SCARA gives high speed and stiffness in that plane while keeping the vertical Z axis simple and fast. The cell runs unattended for long stretches, refilled by an operator who tops up the bowl feeder and swaps the pallet magazine.
How it works
A blank work pallet enters on the Indexing Conveyor and is raised and clamped at the first station by a Lift-and-Locate Stop, which lifts the pallet off the belt and drops two Locating Pin dowels into the pallet to fix its position within a few microns. Bulk parts are dumped into the Vibratory Bowl Feeder, which uses an electromagnetic Electromagnetic Vibratory Drive to walk parts up a spiral track and orient them. Oriented parts move down the Inline Linear Feeder to an Escapement Gate, which uses two Pneumatic Cylinder gates to release exactly one part at a time into the pick position.
The Pick Vision System confirms each part before the robot touches it. The Down-Looking Camera images the pick zone under the LED Ring Light, and the Vision Processor Board computes the part position and rotation, then sends an offset to the robot controller. The robot corrects its target so small variations in how a part lands do not cause a missed pick. For flat or sealed parts the Vacuum Pick Head lifts with a Venturi Vacuum Ejector and four bellows Bellows Suction Cup cups, and a Pressure Sensor in the head verifies that vacuum was actually achieved. For parts that need a firm grip the Servo Parallel Gripper closes its two Gripper Jaw jaws under position and force control. The two tools share the arm through a Tool Changer, so the robot can drop one and pick up the other in under a second.
Once parts are stacked on the pallet, the conveyor indexes the work to the Servo Press Station. There a servo Servo Press Ram drives a Ball Screw ram downward while the Press Load Cell measures insertion force. The press follows a force-versus-distance profile, so a bearing or pin that seats short or binds is caught and the pallet is flagged as a reject. Good pallets continue to the unload station and back into the Tray Magazine.
SCARA arm and motion
The arm has four axes. Joints theta-1 and theta-2 swing the Inner Arm Link and Outer Arm Link in the horizontal plane. Each is driven by a Servo Motor through a Harmonic Drive Gear Set strain-wave reducer running at 100:1, which gives high torque density and near-zero backlash. The output rides on a Cross-Roller Bearing that carries both the radial and moment loads of the arm. The Z / Theta-Z Axis combines a vertical Ball Screw lift with a hollow Ball Spline Shaft for the theta-Z wrist rotation, so the tool can be lowered and rotated independently. Every joint reports position through a 17-bit Absolute Encoder, which keeps the robot calibrated through a power cycle without a homing move.
Controls and safety
The Robot & Cell Controller cabinet holds the Motion Control CPU, six Servo Drive units that switch their IGBT Power Module power stages to the motors, and a Safety PLC on a separate channel. Operators jog and teach the robot with the Teach Pendant / HMI, which carries an LCD Panel with a Touch Digitizer, a three-position 3-Position Enable Switch, and an E-Stop Button. The Safety Enclosure fences the working area with mesh Mesh Fence Panel panels. A Type 4 Safety Light Curtain guards the load opening, and the Interlocked Access Door uses a guard-locking Guard-Locking Interlock that keeps the door shut while the robot is moving. Compressed air for the grippers, escapement, and stops is cleaned and regulated by the Air Preparation Unit (FRL) unit and switched by the Solenoid Valve Manifold.
Materials
Structural castings use gray iron and aluminum: the Base Casting is FC250 gray iron for damping, while the arm links are A356-T6 aluminum to keep the moving mass low. Wear surfaces such as the Gripper Jaw jaws, the Escapement Blade, and the Press Ram are hardened tool or alloy steel. The Bellows Suction Cup cups are NBR rubber for grip and oil resistance, and the pneumatic tubing is polyurethane.
Variants and use
The cell scales by reach and payload. A short-reach 350 mm SCARA with a 1 kg payload suits PCB and connector assembly, while a 800 mm arm with a 6 kg payload handles small gearboxes and pumps. Cells that join only snap-fit parts skip the Servo Press Station, and cells that assemble loose hardware add a second Vibratory Bowl Feeder. Typical buyers are contract manufacturers and OEM lines making appliances, automotive sensors, medical disposables, and consumer electronics in volumes where manual assembly cannot hold the cycle time or the placement accuracy.
Robotic Assembly Cell parts and their functions
10 top-level parts · 1,746 parts in total · full bill of materials below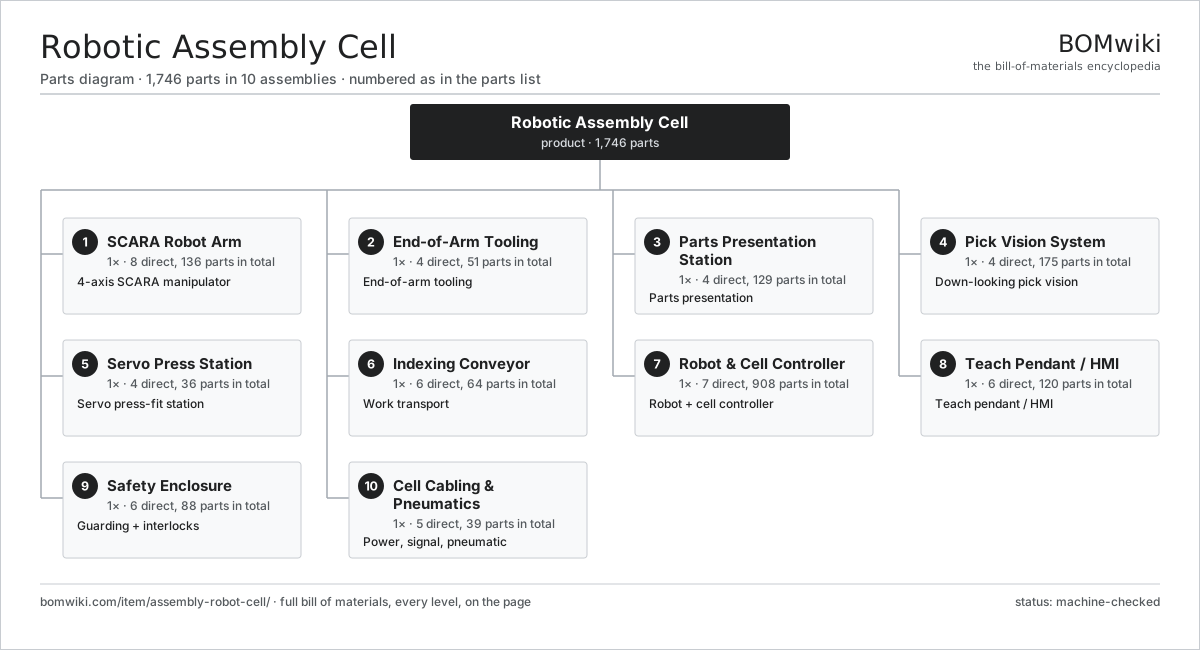
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | SCARA Robot Arm 8 parts | 1× | 4-axis SCARA manipulator |
| 2 | End-of-Arm Tooling 4 parts | 1× | End-of-arm tooling |
| 3 | Parts Presentation Station 4 parts | 1× | Parts presentation |
| 4 | Pick Vision System 4 parts | 1× | Down-looking pick vision |
| 5 | Servo Press Station 4 parts | 1× | Servo press-fit station |
| 6 | Indexing Conveyor 6 parts | 1× | Work transport |
| 7 | Robot & Cell Controller 7 parts | 1× | Robot + cell controller |
| 8 | Teach Pendant / HMI 6 parts | 1× | Teach pendant / HMI |
| 9 | Safety Enclosure 6 parts | 1× | Guarding + interlocks |
| 10 | Cell Cabling & Pneumatics 5 parts | 1× | Power, signal, pneumatic |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Assembly Cell
10 top-level lines · 171 rows shown · 1,746 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | SCARA Robot Arm 8 parts | assembly-robot-cell-scara-arm | 1× | 1 | 136 | assembly |
| 1.1 | Base Casting | assembly-robot-cell-base-casting | 1× | 1 | · | part |
| 1.2 | Inner Arm Link | assembly-robot-cell-inner-link | 1× | 1 | · | part |
| 1.3 | Outer Arm Link | assembly-robot-cell-outer-link | 1× | 1 | · | part |
| 1.4 | J1 Joint (Theta-1) 6 parts | assembly-robot-cell-j1-axis | 1× | 1 | 30 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.4.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 1.4.3 | Harmonic Drive Gear Set | assembly-robot-cell-harmonic-gear | 1× | 1 | · | part |
| 1.4.4 | Cross-Roller Bearing | assembly-robot-cell-crossroller-bearing | 1× | 1 | · | part |
| 1.4.5 | Absolute Encoder | assembly-robot-cell-abs-encoder | 1× | 1 | · | part |
| 1.4.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.5 | J2 Joint (Theta-2) 6 parts | assembly-robot-cell-j2-axis | 1× | 1 | 30 | assembly |
| 1.5.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.5.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 1.5.3 | Harmonic Drive Gear Set | assembly-robot-cell-harmonic-gear | 1× | 1 | · | part |
| 1.5.4 | Cross-Roller Bearing | assembly-robot-cell-crossroller-bearing | 1× | 1 | · | part |
| 1.5.5 | Absolute Encoder | assembly-robot-cell-abs-encoder | 1× | 1 | · | part |
| 1.5.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.6 | Z / Theta-Z Axis 7 parts | assembly-robot-cell-z-axis | 1× | 1 | 59 | assembly |
| 1.6.1 | Servo Motor 4 parts + deeper › | servo-motor | 2× | 2 | 24 | assembly |
| 1.6.2 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 1.6.3 | Ball Spline Shaft | assembly-robot-cell-spline-shaft | 1× | 1 | · | part |
| 1.6.4 | Linear Guide Rail | linear-guide | 1× | 1 | · | part |
| 1.6.5 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 1.6.6 | Drive Belt | drive-belt | 2× | 2 | · | part |
| 1.6.7 | Absolute Encoder | assembly-robot-cell-abs-encoder | 2× | 2 | · | part |
| 1.7 | Arm Dress-Out Harness 3 parts | assembly-robot-cell-arm-harness | 1× | 1 | 10 | assembly |
| 1.7.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.7.2 | Connector | connector | 8× | 8 | · | part |
| 1.7.3 | Cable Carrier Chain | assembly-robot-cell-energy-chain | 1× | 1 | · | part |
| 1.8 | Fastener Set | fastener-set | 4× | 4 | · | part |
| 2 | End-of-Arm Tooling 4 parts | assembly-robot-cell-eoat | 1× | 1 | 51 | assembly |
| 2.1 | Tool Changer 4 parts | assembly-robot-cell-tool-changer | 1× | 1 | 5 | assembly |
| 2.1.1 | Tool Changer Master Plate | assembly-robot-cell-changer-master | 1× | 1 | · | part |
| 2.1.2 | Tool Changer Tool Plate | assembly-robot-cell-changer-tool | 2× | 2 | · | part |
| 2.1.3 | Pneumatic Pass-Through Coupler | assembly-robot-cell-pneumatic-coupler | 1× | 1 | · | part |
| 2.1.4 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 2.2 | Servo Parallel Gripper 7 parts | assembly-robot-cell-servo-gripper | 1× | 1 | 33 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.2.3 | Gripper Jaw | assembly-robot-cell-gripper-jaw | 2× | 2 | · | part |
| 2.2.4 | Gripper Body | assembly-robot-cell-gripper-body | 1× | 1 | · | part |
| 2.2.5 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 2.2.6 | Hall Sensor | hall-sensor | 1× | 1 | · | part |
| 2.2.7 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.3 | Vacuum Pick Head 5 parts | assembly-robot-cell-vacuum-pick | 1× | 1 | 11 | assembly |
| 2.3.1 | Venturi Vacuum Ejector | assembly-robot-cell-venturi-ejector | 1× | 1 | · | part |
| 2.3.2 | Bellows Suction Cup | assembly-robot-cell-vacuum-cup | 4× | 4 | · | part |
| 2.3.3 | Vacuum Switch | assembly-robot-cell-vacuum-switch | 1× | 1 | · | part |
| 2.3.4 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 2.3.5 | Coil Spring | coil-spring | 4× | 4 | · | part |
| 2.4 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 3 | Parts Presentation Station 4 parts | assembly-robot-cell-feeder-station | 1× | 1 | 129 | assembly |
| 3.1 | Vibratory Bowl Feeder 4 parts | assembly-robot-cell-bowl-feeder | 1× | 1 | 77 | assembly |
| 3.1.1 | Feeder Bowl | assembly-robot-cell-feeder-bowl | 1× | 1 | · | part |
| 3.1.2 | Electromagnetic Vibratory Drive 3 parts + deeper › | assembly-robot-cell-vib-drive | 1× | 1 | 6 | assembly |
| 3.1.3 | Coil Spring | coil-spring | 6× | 6 | · | part |
| 3.1.4 | Feeder Controller 4 parts + deeper › | assembly-robot-cell-feeder-controller | 1× | 1 | 64 | assembly |
| 3.2 | Inline Linear Feeder 3 parts | assembly-robot-cell-linear-feeder | 1× | 1 | 8 | assembly |
| 3.2.1 | Feeder Track Rail | assembly-robot-cell-feeder-track | 1× | 1 | · | part |
| 3.2.2 | Electromagnetic Vibratory Drive 3 parts + deeper › | assembly-robot-cell-vib-drive | 1× | 1 | 6 | assembly |
| 3.2.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 3.3 | Escapement Gate 4 parts | assembly-robot-cell-escapement | 1× | 1 | 6 | assembly |
| 3.3.1 | Pneumatic Cylinder | assembly-robot-cell-pneumatic-cylinder | 2× | 2 | · | part |
| 3.3.2 | Escapement Blade | assembly-robot-cell-escapement-blade | 1× | 1 | · | part |
| 3.3.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 3.3.4 | Coil Spring | coil-spring | 2× | 2 | · | part |
| 3.4 | Tray Magazine 5 parts | assembly-robot-cell-tray-magazine | 1× | 1 | 38 | assembly |
| 3.4.1 | Magazine Frame | assembly-robot-cell-magazine-frame | 1× | 1 | · | part |
| 3.4.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 3.4.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 3.4.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 3.4.5 | Work Pallet Tray | assembly-robot-cell-pallet-tray | 10× | 10 | · | part |
| 4 | Pick Vision System 4 parts | assembly-robot-cell-vision-system | 1× | 1 | 175 | assembly |
| 4.1 | Down-Looking Camera 4 parts | assembly-robot-cell-down-camera | 1× | 1 | 5 | assembly |
| 4.1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 4.1.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 4.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.1.4 | Connector | connector | 2× | 2 | · | part |
| 4.2 | LED Ring Light 3 parts | assembly-robot-cell-ring-light | 1× | 1 | 42 | assembly |
| 4.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2.2 | White LED Array | assembly-robot-cell-led-array | 1× | 1 | · | part |
| 4.2.3 | SMD Passive (R/C/L) | smd-passives | 40× | 40 | · | part |
| 4.3 | Vision Processor Board 5 parts | assembly-robot-cell-vision-board | 1× | 1 | 127 | assembly |
| 4.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.3.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 4.3.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.3.4 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 4.3.5 | Connector | connector | 4× | 4 | · | part |
| 4.4 | Camera Mount Bracket | assembly-robot-cell-camera-mount | 1× | 1 | · | part |
| 5 | Servo Press Station 4 parts | assembly-robot-cell-press-station | 1× | 1 | 36 | assembly |
| 5.1 | Press C-Frame | assembly-robot-cell-press-frame | 1× | 1 | · | part |
| 5.2 | Servo Press Ram 6 parts | assembly-robot-cell-press-actuator | 1× | 1 | 33 | assembly |
| 5.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.2.2 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 5.2.3 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 5.2.4 | Press Ram | assembly-robot-cell-press-ram | 1× | 1 | · | part |
| 5.2.5 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 5.2.6 | Absolute Encoder | assembly-robot-cell-abs-encoder | 1× | 1 | · | part |
| 5.3 | Press Load Cell | assembly-robot-cell-load-cell | 1× | 1 | · | part |
| 5.4 | Press Tooling Nest | assembly-robot-cell-press-nest | 1× | 1 | · | part |
| 6 | Indexing Conveyor 6 parts | assembly-robot-cell-index-conveyor | 1× | 1 | 64 | assembly |
| 6.1 | Conveyor Frame | assembly-robot-cell-conveyor-frame | 1× | 1 | · | part |
| 6.2 | Cam Index Drive 4 parts | assembly-robot-cell-index-drive | 1× | 1 | 30 | assembly |
| 6.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 6.2.3 | Roller Gear Cam | assembly-robot-cell-index-cam | 1× | 1 | · | part |
| 6.2.4 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 6.3 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 6.4 | Work Pallet Tray | assembly-robot-cell-pallet-tray | 8× | 8 | · | part |
| 6.5 | Lift-and-Locate Stop 3 parts | assembly-robot-cell-stop-station | 4× | 4 | 4 | assembly |
| 6.5.1 | Pneumatic Cylinder | assembly-robot-cell-pneumatic-cylinder | 1× | 4 | · | part |
| 6.5.2 | Locating Pin | assembly-robot-cell-locate-pin | 2× | 8 | · | part |
| 6.5.3 | Pressure Sensor | pressure-sensor | 1× | 4 | · | part |
| 6.6 | Ball Bearing | ball-bearing | 8× | 8 | · | part |
| 7 | Robot & Cell Controller 7 parts | assembly-robot-cell-controller | 1× | 1 | 908 | assembly |
| 7.1 | Control Cabinet | assembly-robot-cell-control-cabinet | 1× | 1 | · | part |
| 7.2 | Motion Control CPU 5 parts | assembly-robot-cell-motion-cpu | 1× | 1 | 212 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.2.3 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.2.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 7.2.5 | Connector | connector | 8× | 8 | · | part |
| 7.3 | Servo Drive 5 parts | assembly-robot-cell-servo-drive | 6× | 6 | 94 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 7.3.2 | IGBT Power Module | igbt-module | 1× | 6 | · | part |
| 7.3.3 | Microcontroller | mcu | 1× | 6 | · | part |
| 7.3.4 | SMD Passive (R/C/L) | smd-passives | 90× | 540 | · | part |
| 7.3.5 | Relay | relay | 1× | 6 | · | part |
| 7.4 | Safety PLC 4 parts | assembly-robot-cell-safety-plc | 1× | 1 | 87 | assembly |
| 7.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.4.3 | Relay | relay | 4× | 4 | · | part |
| 7.4.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 7.5 | Power Supply | power-supply | 2× | 2 | · | part |
| 7.6 | Relay | relay | 12× | 12 | · | part |
| 7.7 | Connector | connector | 30× | 30 | · | part |
| 8 | Teach Pendant / HMI 6 parts | assembly-robot-cell-pendant | 1× | 1 | 120 | assembly |
| 8.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.3 | Pendant Main Board 4 parts | assembly-robot-cell-pendant-board | 1× | 1 | 115 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 8.3.3 | SMD Passive (R/C/L) | smd-passives | 110× | 110 | · | part |
| 8.3.4 | Connector | connector | 3× | 3 | · | part |
| 8.4 | E-Stop Button | assembly-robot-cell-estop-button | 1× | 1 | · | part |
| 8.5 | 3-Position Enable Switch | assembly-robot-cell-enable-switch | 1× | 1 | · | part |
| 8.6 | Pendant Housing | assembly-robot-cell-pendant-housing | 1× | 1 | · | part |
| 9 | Safety Enclosure 6 parts | assembly-robot-cell-safety-enclosure | 1× | 1 | 88 | assembly |
| 9.1 | Mesh Fence Panel | assembly-robot-cell-fence-panel | 8× | 8 | · | part |
| 9.2 | Sheet Metal Panel | sheet-panel | 4× | 4 | · | part |
| 9.3 | Safety Light Curtain 4 parts | assembly-robot-cell-light-curtain | 1× | 1 | 64 | assembly |
| 9.3.1 | Light Curtain Emitter | assembly-robot-cell-lc-emitter | 1× | 1 | · | part |
| 9.3.2 | Light Curtain Receiver | assembly-robot-cell-lc-receiver | 1× | 1 | · | part |
| 9.3.3 | Bare PCB | pcb-bare | 2× | 2 | · | part |
| 9.3.4 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 9.4 | Interlocked Access Door 3 parts | assembly-robot-cell-access-door | 1× | 1 | 3 | assembly |
| 9.4.1 | Door Frame | assembly-robot-cell-door-frame | 1× | 1 | · | part |
| 9.4.2 | Guard-Locking Interlock | assembly-robot-cell-safety-interlock | 1× | 1 | · | part |
| 9.4.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 9.5 | E-Stop Button | assembly-robot-cell-estop-button | 3× | 3 | · | part |
| 9.6 | Fastener Set | fastener-set | 6× | 6 | · | part |
| 10 | Cell Cabling & Pneumatics 5 parts | assembly-robot-cell-cabling | 1× | 1 | 39 | assembly |
| 10.1 | Wire Bundle | wire-bundle | 2× | 2 | · | part |
| 10.2 | Connector | connector | 24× | 24 | · | part |
| 10.3 | Air Preparation Unit (FRL) | assembly-robot-cell-air-prep | 1× | 1 | · | part |
| 10.4 | Solenoid Valve Manifold 3 parts | assembly-robot-cell-valve-manifold | 1× | 1 | 11 | assembly |
| 10.4.1 | 5/2 Solenoid Valve | assembly-robot-cell-solenoid-valve | 8× | 8 | · | part |
| 10.4.2 | Manifold Block | assembly-robot-cell-manifold-block | 1× | 1 | · | part |
| 10.4.3 | Connector | connector | 2× | 2 | · | part |
| 10.5 | Pneumatic Tubing Kit | assembly-robot-cell-air-tubing | 1× | 1 | · | part |
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
1,043-word article