Autonomous Warehouse Robot
ProductOverview
An autonomous warehouse robot is a low, flat drive unit that slides under a mobile storage rack, lifts it a few centimetres off the floor, and carries the whole rack to a human picker or a packing station. This is the goods-to-person pattern that large e-commerce fulfilment centres run at scale: instead of people walking miles of aisle, fleets of these robots bring the inventory to a fixed work cell. The robot finds its way with onboard sensing rather than fixed wire guidance, so the warehouse floor stays a clear, reconfigurable grid marked only with fiducials. The whole machine is built around a low-profile Drive Chassis tall enough to clear a few hundred millimetres yet stiff enough to bear a full rack.
Drive and chassis
The base is the welded Base Weldment, a deliberately low and wide frame so the centre of gravity stays under control with a tall rack on top. Two Drive Module units mounted on the centreline give differential steering: driving the wheels at different speeds turns the robot, and driving them opposite spins it in place within its own footprint, which matters in dense aisle grids. Each module pairs a BLDC Wheel Motor BLDC motor with a two-stage Wheel Gearbox and a polyurethane Drive Wheel. A sprung Wheel Suspension rocker keeps both drive wheels firmly loaded on uneven concrete so the robot does not lose traction under an off-centre load. Four Support Caster casters at the corners carry the static rack weight, and a Wheel Encoder on each drive wheel feeds the odometry estimate.
Lift and rotate
Picking up a rack is the job of the Rack Lift. A Lift Gearmotor turns a Cam Jack that raises the load deck by about forty millimetres, just enough to take the rack legs off the floor. A self-locking Worm Gear Set holds the deck up without drawing power, so a robot can sit parked under load all shift. A separate Rotation Motor spins the deck on a Slewing Ring slewing ring, letting the robot present any face of the rack to the picker without changing its own heading. A Lift Encoder confirms both the lift height and the rotation angle before the robot moves off.
Power
The robot runs on an Battery Pack built from LFP Cell lithium iron phosphate cells. LFP chemistry is chosen because warehouse robots are opportunity charged: they top up for a few minutes between jobs at an auto-dock rather than swapping or doing a full cycle, and LFP tolerates that constant partial charging far better than other chemistries. An Battery Management System balances the cells and tracks state of charge through a precision Current Shunt, while a Pack Contactor isolates the pack on fault. The Charge Interface drives the robot onto a floor dock where Charge Contacts meet the station, and the onboard Charge Controller runs the charge profile.
Navigation and perception
Localization is the hard part of the product. The Navigation Computer runs SLAM on the Navigation Board using a spinning Navigation LiDAR to track aisle walls and racks, while a Motion Control MCU closes the wheel loops in real time and an IMU supplies heading between scans. For the final approach to a rack or a dock, a downward Floor Camera reads floor fiducials to pin position to within ten millimetres, far tighter than LiDAR odometry alone. Forward Depth Camera modules and Cliff Sensor drop detectors handle obstacles and dock edges.
Safety and fleet operation
Because hundreds of these robots share a floor with people at the pick stations, the Safety System is certified hardware, not software best-effort. Front and rear Safety Laser Scanner units define protective fields that shrink as the robot slows, a dual-channel Safety Controller enforces speed and zone limits and commands a SIL2 safe stop, and Emergency Stop buttons cut drive power directly. A Warning Beacon beacon shows state. The robot reports to a central fleet manager over the Fleet Radio radio, which assigns jobs, schedules charging, and plans traffic so robots do not deadlock at intersections. All of it is wired through the Wiring Harness and protected at the Fuse Panel. The economic case is straightforward: one picker served by a stream of these robots fulfils several times the order lines per hour of a picker who walks the aisles.
Autonomous Warehouse Robot parts and their functions
11 top-level parts · 829 parts in total · full bill of materials below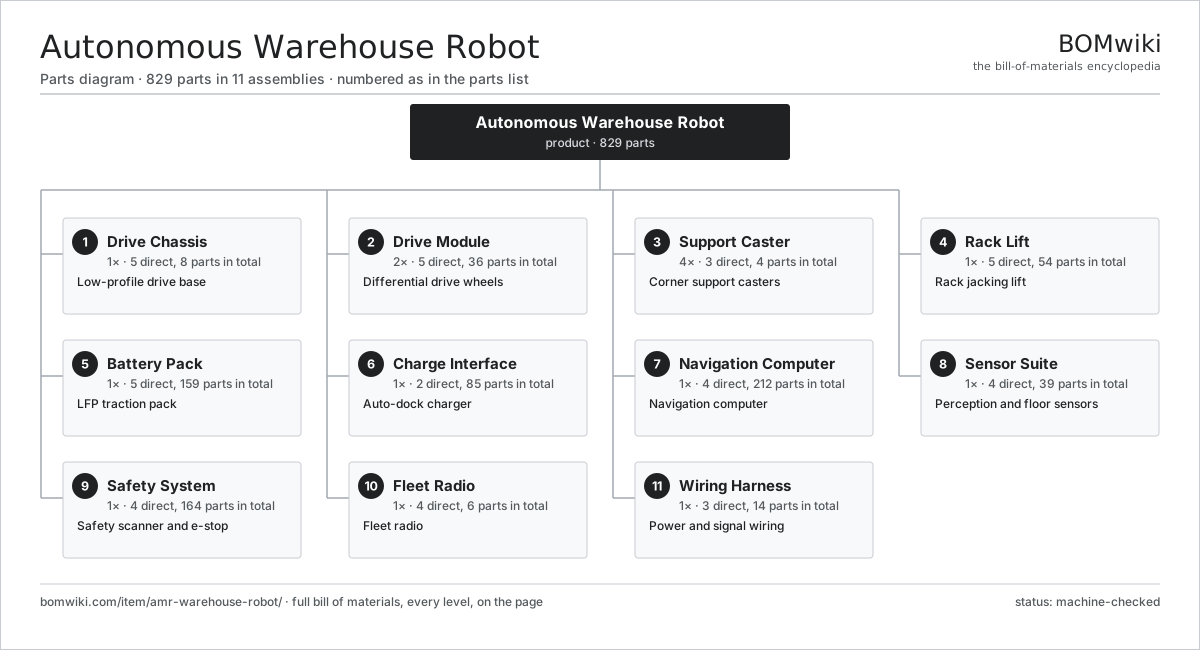
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Drive Chassis 5 parts | 1× | Low-profile drive base |
| 2 | Drive Module 5 parts | 2× | Differential drive wheels |
| 3 | Support Caster 3 parts | 4× | Corner support casters |
| 4 | Rack Lift 5 parts | 1× | Rack jacking lift |
| 5 | Battery Pack 5 parts | 1× | LFP traction pack |
| 6 | Charge Interface 2 parts | 1× | Auto-dock charger |
| 7 | Navigation Computer 4 parts | 1× | Navigation computer |
| 8 | Sensor Suite 4 parts | 1× | Perception and floor sensors |
| 9 | Safety System 4 parts | 1× | Safety scanner and e-stop |
| 10 | Fleet Radio 4 parts | 1× | Fleet radio |
| 11 | Wiring Harness 3 parts | 1× | Power and signal wiring |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Autonomous Warehouse Robot
11 top-level lines · 99 rows shown · 829 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Drive Chassis 5 parts | amr-warehouse-robot-chassis | 1× | 1 | 8 | assembly |
| 1.1 | Base Weldment | amr-warehouse-robot-base-weldment | 1× | 1 | · | part |
| 1.2 | Load Deck Plate | amr-warehouse-robot-deck-plate | 1× | 1 | · | part |
| 1.3 | Skirt Guard | amr-warehouse-robot-skirt | 1× | 1 | · | part |
| 1.4 | Corner Bumper | amr-warehouse-robot-corner-bumper | 4× | 4 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Drive Module 5 parts | amr-warehouse-robot-drive-module | 2× | 2 | 36 | assembly |
| 2.1 | BLDC Wheel Motor 3 parts | amr-warehouse-robot-wheel-motor | 1× | 2 | 24 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.1.3 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.2 | Wheel Gearbox 4 parts | amr-warehouse-robot-wheel-gearbox | 1× | 2 | 6 | assembly |
| 2.2.1 | Helical Gear Pair | gear-pair | 2× | 4 | · | part |
| 2.2.2 | Gearbox Housing | gearbox-housing | 1× | 2 | · | part |
| 2.2.3 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.2.4 | Oil Seal | oil-seal | 1× | 2 | · | part |
| 2.3 | Drive Wheel 2 parts | amr-warehouse-robot-drive-wheel | 1× | 2 | 2 | assembly |
| 2.3.1 | Wheel Hub | amr-warehouse-robot-wheel-hub | 1× | 2 | · | part |
| 2.3.2 | Polyurethane Tread | amr-warehouse-robot-pu-tread | 1× | 2 | · | part |
| 2.4 | Wheel Suspension 3 parts | amr-warehouse-robot-suspension | 1× | 2 | 3 | assembly |
| 2.4.1 | Suspension Rocker | amr-warehouse-robot-rocker | 1× | 2 | · | part |
| 2.4.2 | Coil Spring | coil-spring | 1× | 2 | · | part |
| 2.4.3 | Ball Bearing | ball-bearing | 1× | 2 | · | part |
| 2.5 | Wheel Encoder | amr-warehouse-robot-wheel-encoder | 1× | 2 | · | part |
| 3 | Support Caster 3 parts | amr-warehouse-robot-caster-module | 4× | 4 | 4 | assembly |
| 3.1 | Caster Fork | amr-warehouse-robot-caster-fork | 1× | 4 | · | part |
| 3.2 | Caster Wheel | amr-warehouse-robot-caster-wheel | 1× | 4 | · | part |
| 3.3 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 4 | Rack Lift 5 parts | amr-warehouse-robot-lift-mechanism | 1× | 1 | 54 | assembly |
| 4.1 | Lift Gearmotor 3 parts | amr-warehouse-robot-lift-motor | 1× | 1 | 26 | assembly |
| 4.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 4.1.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 4.1.3 | Worm Gear Set | amr-warehouse-robot-worm-set | 1× | 1 | · | part |
| 4.2 | Cam Jack | amr-warehouse-robot-cam-jack | 1× | 1 | · | part |
| 4.3 | Rotation Motor 2 parts | amr-warehouse-robot-rotate-motor | 1× | 1 | 25 | assembly |
| 4.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 4.3.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 4.4 | Slewing Ring | amr-warehouse-robot-rotate-bearing | 1× | 1 | · | part |
| 4.5 | Lift Encoder | amr-warehouse-robot-lift-encoder | 1× | 1 | · | part |
| 5 | Battery Pack 5 parts | amr-warehouse-robot-battery-pack | 1× | 1 | 159 | assembly |
| 5.1 | LFP Cell | amr-warehouse-robot-lfp-cell | 32× | 32 | · | part |
| 5.2 | Battery Management System 4 parts | amr-warehouse-robot-bms | 1× | 1 | 123 | assembly |
| 5.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.2.3 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 5.2.4 | Current Shunt | amr-warehouse-robot-shunt | 1× | 1 | · | part |
| 5.3 | Battery Tray | amr-warehouse-robot-battery-tray | 1× | 1 | · | part |
| 5.4 | Pack Contactor | amr-warehouse-robot-contactor | 1× | 1 | · | part |
| 5.5 | Connector | connector | 2× | 2 | · | part |
| 6 | Charge Interface 2 parts | amr-warehouse-robot-charge-interface | 1× | 1 | 85 | assembly |
| 6.1 | Charge Contacts | amr-warehouse-robot-charge-contacts | 1× | 1 | · | part |
| 6.2 | Charge Controller 4 parts | amr-warehouse-robot-charge-controller | 1× | 1 | 84 | assembly |
| 6.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.2.3 | Relay | relay | 2× | 2 | · | part |
| 6.2.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 7 | Navigation Computer 4 parts | amr-warehouse-robot-nav-compute | 1× | 1 | 212 | assembly |
| 7.1 | Navigation Board 3 parts | amr-warehouse-robot-nav-board | 1× | 1 | 202 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 7.2 | Motion Control MCU | amr-warehouse-robot-motion-mcu | 1× | 1 | · | part |
| 7.3 | IMU | amr-warehouse-robot-imu | 1× | 1 | · | part |
| 7.4 | Connector | connector | 8× | 8 | · | part |
| 8 | Sensor Suite 4 parts | amr-warehouse-robot-sensor-suite | 1× | 1 | 39 | assembly |
| 8.1 | Navigation LiDAR 4 parts | amr-warehouse-robot-nav-lidar | 1× | 1 | 27 | assembly |
| 8.1.1 | LiDAR Optics | amr-warehouse-robot-lidar-optics | 1× | 1 | · | part |
| 8.1.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 8.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.4 | Wheel Encoder | amr-warehouse-robot-wheel-encoder | 1× | 1 | · | part |
| 8.2 | Depth Camera 2 parts | amr-warehouse-robot-depth-camera | 2× | 2 | 3 | assembly |
| 8.2.1 | Image Sensor | amr-warehouse-robot-camera-sensor | 2× | 4 | · | part |
| 8.2.2 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 8.3 | Floor Camera 2 parts | amr-warehouse-robot-floor-camera | 1× | 1 | 2 | assembly |
| 8.3.1 | Image Sensor | amr-warehouse-robot-camera-sensor | 1× | 1 | · | part |
| 8.3.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.4 | Cliff Sensor | amr-warehouse-robot-cliff-sensor | 4× | 4 | · | part |
| 9 | Safety System 4 parts | amr-warehouse-robot-safety-system | 1× | 1 | 164 | assembly |
| 9.1 | Safety Laser Scanner 4 parts | amr-warehouse-robot-safety-scanner | 2× | 2 | 27 | assembly |
| 9.1.1 | LiDAR Optics | amr-warehouse-robot-lidar-optics | 1× | 2 | · | part |
| 9.1.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 9.1.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 9.1.4 | Microcontroller | mcu | 1× | 2 | · | part |
| 9.2 | Safety Controller 4 parts | amr-warehouse-robot-safety-plc | 1× | 1 | 107 | assembly |
| 9.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.2.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 9.2.3 | Relay | relay | 4× | 4 | · | part |
| 9.2.4 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 9.3 | Emergency Stop | amr-warehouse-robot-estop | 2× | 2 | · | part |
| 9.4 | Warning Beacon | amr-warehouse-robot-warning-light | 1× | 1 | · | part |
| 10 | Fleet Radio 4 parts | amr-warehouse-robot-comms | 1× | 1 | 6 | assembly |
| 10.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 10.2 | Radio Module | amr-warehouse-robot-radio-module | 1× | 1 | · | part |
| 10.3 | Antenna | amr-warehouse-robot-antenna | 2× | 2 | · | part |
| 10.4 | Connector | connector | 2× | 2 | · | part |
| 11 | Wiring Harness 3 parts | amr-warehouse-robot-harness | 1× | 1 | 14 | assembly |
| 11.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 11.2 | Connector | connector | 12× | 12 | · | part |
| 11.3 | Fuse Panel | amr-warehouse-robot-fuse-panel | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 4 with this page
Robotic Deburring Cell
1,637 parts · shares 4 with this page
Robotic Grinding Cell
1,419 parts · shares 4 with this page
Robotic Sanding Cell
1,464 parts · shares 4 with this page
Robotic Screwdriving Cell
2,109 parts · shares 4 with this page
Vineyard Robot
588 parts · shares 3 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
832-word article