Robotic Sanding Cell
ProductOverview
A robotic sanding cell automates surface finishing that is otherwise done by hand: knocking down weld beads, blending body filler, scuffing primer, and bringing castings to a uniform finish. The cell is built around a 6-Axis Robot Arm, a 6-axis articulated manipulator with 1,800 mm reach and a 20 kg payload, carrying a finishing tool over the workpiece along programmed paths. Two tools mount to the same wrist flange: a Random-Orbital Sanding Head for flat and gently curved faces, and a Belt-Sander Head for edges, fillets, and weld blending. Between the flange and the tool sits a Active Force-Control Unit that holds a constant contact force as the surface height varies, which is the part hand sanders do by feel and rigid robots cannot do at all.
Around the arm, the cell adds the support systems that let it run unattended: a Abrasive-Disc Changer that swaps worn abrasive, a Dust Extraction System cyclone that pulls swarf through the pad, a Fixture / Index Table that presents parts, a Robot Controller cabinet, a Teach Pendant / HMI for programming, and a Safety Enclosure that keeps people out of the work zone.
How it works
The robot moves the tool along a path taught on the Teach Pendant / HMI or imported from a CAD model. On its own, a rigid arm would press too hard where the part bulges and lift off where it dips, because joint position cannot track a surface it does not know precisely. The Active Force-Control Unit solves this. A Force/Torque Sensor reads the actual contact load, and a Proportional Valve sets the pressure in a Compliance Cylinder that rides on a Air-Bearing Guide. The tool floats on this cushion, and the control loop holds the commanded force, typically 5-150 N, at 1 kHz. The robot supplies the path; the force unit supplies the touch.
Each of the six joints uses the same building blocks. A Servo Motor drives a Harmonic Drive Reducer strain-wave reducer, whose Flexspline and Circular Spline give a high ratio with zero backlash in a thin package. A Cross-Roller Bearing carries the output load, a Absolute Encoder reports position without homing, and a Holding Brake locks the joint when power drops. The waist, shoulder, and elbow are single joints; the Wrist Cluster (Axes 4-6) packs the last three axes into one cluster ending at the Tool Flange.
Finishing tools
The Random-Orbital Sanding Head is a pneumatic random-orbital sander. A Orbital Air Motor spins a Eccentric Drive Bushing that offsets the Backing Pad by 5 mm, while a Pad Bearing lets the pad free-spin so the scratch pattern is random and leaves no swirl marks. A Pad Counterweight balances the offset mass. The Abrasive Disc and pad share a hole pattern so the Dust Extraction System can pull dust straight through the cut, helped by a Suction Shroud around the rim.
The Belt-Sander Head runs a Abrasive Belt over a Contact Wheel driven by a Belt Drive Motor through a Drive Belt. A Belt Tensioner with a Tracking Screw keeps the belt centered on the Idler Wheel pair. The belt head removes metal fast and reaches into corners the flat pad cannot.
Abrasive handling and dust
Abrasive wears out, so the cell changes it on its own. The Abrasive-Disc Changer holds fresh discs in a Disc Magazine, strips the worn disc at a Peel Station, and seats a new one at a Press Station, with a Grit Detect Sensor sensor confirming the result. Sanding produces fine dust, which a Vacuum Blower pulls through a Cyclone Separator into a Collection Bin, with an HEPA Filter catching the respirable fraction and a Pressure Sensor flagging a clogged filter.
Cell control and safety
The Robot Controller runs a Motion CPU, six Servo Drive amplifiers, and a Safety PLC. The Fixture / Index Table indexes parts in and out so the robot never waits for an operator. Safety is hard-guarded: the Safety Enclosure fences the work zone, a Light Curtain watches the load opening, and a Door Interlock keeps the Safety Door locked while the robot moves. Air, vacuum, power, and signal lines run to the tool through a Dress-Pack Cabling carried in an Energy Chain with a Rotary Union at the wrist.
Where it is used
These cells run in automotive body shops, foundries, aerospace component lines, and furniture plants, anywhere parts need a repeatable finish at volume. Compared with manual sanding, the robot holds force and grit constant part after part, removes the operator from the dust, and runs unattended through the magazine of discs. The same arm is rebuilt with different tooling for deburring, polishing, or buffing by changing only the end-effector. A cell sized for one part family handles a mix of castings and weldments once their finishing paths are programmed and stored.
Robotic Sanding Cell parts and their functions
11 top-level parts · 1,464 parts in total · full bill of materials below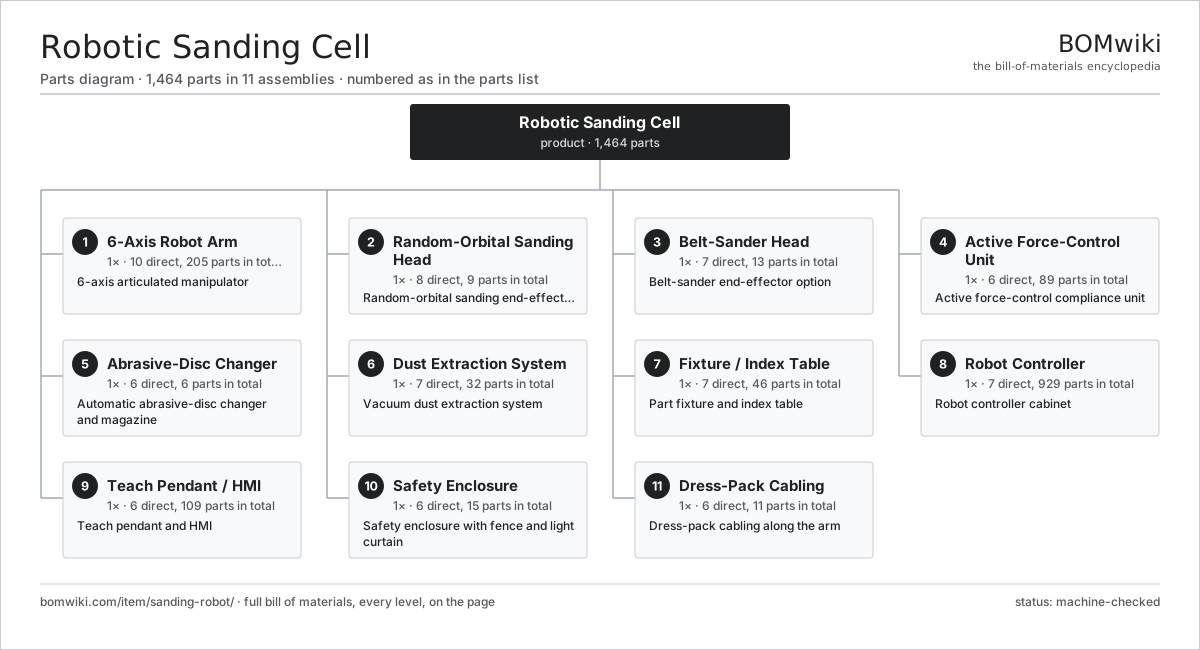
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | 6-Axis Robot Arm 10 parts | 1× | 6-axis articulated manipulator |
| 2 | Random-Orbital Sanding Head 8 parts | 1× | Random-orbital sanding end-effector |
| 3 | Belt-Sander Head 7 parts | 1× | Belt-sander end-effector option |
| 4 | Active Force-Control Unit 6 parts | 1× | Active force-control compliance unit |
| 5 | Abrasive-Disc Changer 6 parts | 1× | Automatic abrasive-disc changer and magazine |
| 6 | Dust Extraction System 7 parts | 1× | Vacuum dust extraction system |
| 7 | Fixture / Index Table 7 parts | 1× | Part fixture and index table |
| 8 | Robot Controller 7 parts | 1× | Robot controller cabinet |
| 9 | Teach Pendant / HMI 6 parts | 1× | Teach pendant and HMI |
| 10 | Safety Enclosure 6 parts | 1× | Safety enclosure with fence and light curtain |
| 11 | Dress-Pack Cabling 6 parts | 1× | Dress-pack cabling along the arm |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Sanding Cell
11 top-level lines · 153 rows shown · 1,464 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | 6-Axis Robot Arm 10 parts | sanding-robot-arm | 1× | 1 | 205 | assembly |
| 1.1 | Base Casting | sanding-robot-base-casting | 1× | 1 | · | part |
| 1.2 | Axis 1 Waist Joint 6 parts | sanding-robot-joint-1 | 1× | 1 | 33 | assembly |
| 1.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.2.2 | Harmonic Drive Reducer 4 parts + deeper › | sanding-robot-harmonic-drive | 1× | 1 | 4 | assembly |
| 1.2.3 | Cross-Roller Bearing | sanding-robot-crossroller-bearing | 1× | 1 | · | part |
| 1.2.4 | Absolute Encoder | sanding-robot-abs-encoder | 1× | 1 | · | part |
| 1.2.5 | Holding Brake | sanding-robot-brake | 1× | 1 | · | part |
| 1.2.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.3 | Axis 2 Shoulder Joint 6 parts | sanding-robot-joint-2 | 1× | 1 | 33 | assembly |
| 1.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.3.2 | Harmonic Drive Reducer 4 parts + deeper › | sanding-robot-harmonic-drive | 1× | 1 | 4 | assembly |
| 1.3.3 | Cross-Roller Bearing | sanding-robot-crossroller-bearing | 1× | 1 | · | part |
| 1.3.4 | Absolute Encoder | sanding-robot-abs-encoder | 1× | 1 | · | part |
| 1.3.5 | Holding Brake | sanding-robot-brake | 1× | 1 | · | part |
| 1.3.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.4 | Axis 3 Elbow Joint 6 parts | sanding-robot-joint-3 | 1× | 1 | 33 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.4.2 | Harmonic Drive Reducer 4 parts + deeper › | sanding-robot-harmonic-drive | 1× | 1 | 4 | assembly |
| 1.4.3 | Cross-Roller Bearing | sanding-robot-crossroller-bearing | 1× | 1 | · | part |
| 1.4.4 | Absolute Encoder | sanding-robot-abs-encoder | 1× | 1 | · | part |
| 1.4.5 | Holding Brake | sanding-robot-brake | 1× | 1 | · | part |
| 1.4.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.5 | Wrist Cluster (Axes 4-6) 6 parts | sanding-robot-wrist | 1× | 1 | 97 | assembly |
| 1.5.1 | Servo Motor 4 parts + deeper › | servo-motor | 3× | 3 | 24 | assembly |
| 1.5.2 | Harmonic Drive Reducer 4 parts + deeper › | sanding-robot-harmonic-drive | 3× | 3 | 4 | assembly |
| 1.5.3 | Absolute Encoder | sanding-robot-abs-encoder | 3× | 3 | · | part |
| 1.5.4 | Tool Flange | sanding-robot-tool-flange | 1× | 1 | · | part |
| 1.5.5 | Ball Bearing | ball-bearing | 6× | 6 | · | part |
| 1.5.6 | Oil Seal | oil-seal | 3× | 3 | · | part |
| 1.6 | Upper Arm Link | sanding-robot-link-upper | 1× | 1 | · | part |
| 1.7 | Forearm Link | sanding-robot-link-fore | 1× | 1 | · | part |
| 1.8 | Gas-Spring Counterbalance | sanding-robot-counterbalance | 1× | 1 | · | part |
| 1.9 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.10 | Fastener Set | fastener-set | 4× | 4 | · | part |
| 2 | Random-Orbital Sanding Head 8 parts | sanding-robot-orbital-head | 1× | 1 | 9 | assembly |
| 2.1 | Orbital Air Motor | sanding-robot-orbital-motor | 1× | 1 | · | part |
| 2.2 | Eccentric Drive Bushing | sanding-robot-eccentric | 1× | 1 | · | part |
| 2.3 | Pad Counterweight | sanding-robot-counterweight | 1× | 1 | · | part |
| 2.4 | Backing Pad | sanding-robot-backing-pad | 1× | 1 | · | part |
| 2.5 | Abrasive Disc | sanding-robot-abrasive-disc | 1× | 1 | · | part |
| 2.6 | Pad Bearing | sanding-robot-pad-bearing | 1× | 1 | · | part |
| 2.7 | Suction Shroud | sanding-robot-shroud | 1× | 1 | · | part |
| 2.8 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3 | Belt-Sander Head 7 parts | sanding-robot-belt-head | 1× | 1 | 13 | assembly |
| 3.1 | Belt Drive Motor | sanding-robot-belt-motor | 1× | 1 | · | part |
| 3.2 | Contact Wheel | sanding-robot-contact-wheel | 1× | 1 | · | part |
| 3.3 | Abrasive Belt | sanding-robot-belt | 1× | 1 | · | part |
| 3.4 | Idler Wheel | sanding-robot-idler-wheel | 2× | 2 | · | part |
| 3.5 | Belt Tensioner 3 parts | sanding-robot-belt-tensioner | 1× | 1 | 3 | assembly |
| 3.5.1 | Coil Spring | coil-spring | 1× | 1 | · | part |
| 3.5.2 | Tracking Screw | sanding-robot-tracking-screw | 1× | 1 | · | part |
| 3.5.3 | Ball Bearing | ball-bearing | 1× | 1 | · | part |
| 3.6 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 3.7 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 4 | Active Force-Control Unit 6 parts | sanding-robot-force-unit | 1× | 1 | 89 | assembly |
| 4.1 | Compliance Cylinder | sanding-robot-pneumatic-cylinder | 1× | 1 | · | part |
| 4.2 | Force/Torque Sensor | sanding-robot-force-sensor | 1× | 1 | · | part |
| 4.3 | Proportional Valve | sanding-robot-proportional-valve | 1× | 1 | · | part |
| 4.4 | Air-Bearing Guide | sanding-robot-air-bearing-guide | 1× | 1 | · | part |
| 4.5 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 4.6 | Force-Control Board 4 parts | sanding-robot-force-board | 1× | 1 | 84 | assembly |
| 4.6.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.6.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.6.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 4.6.4 | Connector | connector | 2× | 2 | · | part |
| 5 | Abrasive-Disc Changer 6 parts | sanding-robot-disc-changer | 1× | 1 | 6 | assembly |
| 5.1 | Disc Magazine | sanding-robot-disc-magazine | 1× | 1 | · | part |
| 5.2 | Peel Station | sanding-robot-peel-station | 1× | 1 | · | part |
| 5.3 | Press Station | sanding-robot-press-station | 1× | 1 | · | part |
| 5.4 | Changer Index Motor | sanding-robot-changer-motor | 1× | 1 | · | part |
| 5.5 | Grit Detect Sensor | sanding-robot-grit-detect | 1× | 1 | · | part |
| 5.6 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 6 | Dust Extraction System 7 parts | sanding-robot-dust-extraction | 1× | 1 | 32 | assembly |
| 6.1 | Vacuum Blower 5 parts | sanding-robot-vacuum-blower | 1× | 1 | 26 | assembly |
| 6.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 6.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 6.1.3 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 6.1.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 6.1.5 | Blower Impeller | sanding-robot-impeller | 1× | 1 | · | part |
| 6.2 | Cyclone Separator | sanding-robot-cyclone | 1× | 1 | · | part |
| 6.3 | HEPA Filter | sanding-robot-hepa-filter | 1× | 1 | · | part |
| 6.4 | Collection Bin | sanding-robot-collection-bin | 1× | 1 | · | part |
| 6.5 | Suction Hose | sanding-robot-suction-hose | 1× | 1 | · | part |
| 6.6 | Filter Pulse Cleaner | sanding-robot-filter-pulse | 1× | 1 | · | part |
| 6.7 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 7 | Fixture / Index Table 7 parts | sanding-robot-fixture-table | 1× | 1 | 46 | assembly |
| 7.1 | Rotary Indexer 3 parts | sanding-robot-rotary-index | 1× | 1 | 3 | assembly |
| 7.1.1 | Cross-Roller Bearing | sanding-robot-crossroller-bearing | 1× | 1 | · | part |
| 7.1.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 7.1.3 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 7.2 | Fixture Plate | sanding-robot-fixture-plate | 2× | 2 | · | part |
| 7.3 | Clamp Cylinder | sanding-robot-clamp-cylinder | 4× | 4 | · | part |
| 7.4 | Part-Present Sensor | sanding-robot-part-present-sensor | 2× | 2 | · | part |
| 7.5 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 7.5.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 7.5.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 7.5.3 | Encoder | encoder | 1× | 1 | · | part |
| 7.5.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 7.6 | Helical Gearbox 4 parts | gearbox | 1× | 1 | 9 | assembly |
| 7.6.1 | Helical Gear Pair | gear-pair | 2× | 2 | · | part |
| 7.6.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 7.6.3 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 7.6.4 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 7.7 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 8 | Robot Controller 7 parts | sanding-robot-controller | 1× | 1 | 929 | assembly |
| 8.1 | Motion CPU 4 parts | sanding-robot-motion-cpu | 1× | 1 | 210 | assembly |
| 8.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 8.1.3 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 8.1.4 | Connector | connector | 8× | 8 | · | part |
| 8.2 | Servo Drive 4 parts | sanding-robot-servo-drive | 6× | 6 | 96 | assembly |
| 8.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 8.2.2 | IGBT Power Module | igbt-module | 1× | 6 | · | part |
| 8.2.3 | SMD Passive (R/C/L) | smd-passives | 90× | 540 | · | part |
| 8.2.4 | Connector | connector | 4× | 24 | · | part |
| 8.3 | Safety PLC 4 parts | sanding-robot-safety-plc | 1× | 1 | 129 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 8.3.3 | Relay | relay | 6× | 6 | · | part |
| 8.3.4 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 8.4 | I/O Module | sanding-robot-io-module | 2× | 2 | · | part |
| 8.5 | Power Supply | power-supply | 2× | 2 | · | part |
| 8.6 | DC Bus & Brake Resistor | sanding-robot-bus-bar | 1× | 1 | · | part |
| 8.7 | Controller Cabinet 3 parts | sanding-robot-cabinet | 1× | 1 | 9 | assembly |
| 8.7.1 | Sheet Metal Panel | sheet-panel | 6× | 6 | · | part |
| 8.7.2 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 8.7.3 | Cooling Fan | sanding-robot-cooling-fan | 2× | 2 | · | part |
| 9 | Teach Pendant / HMI 6 parts | sanding-robot-pendant | 1× | 1 | 109 | assembly |
| 9.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 9.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 9.3 | Pendant Board 4 parts | sanding-robot-pendant-board | 1× | 1 | 104 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 9.3.3 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 9.3.4 | Connector | connector | 2× | 2 | · | part |
| 9.4 | E-Stop Button | sanding-robot-estop-button | 1× | 1 | · | part |
| 9.5 | Enabling Switch | sanding-robot-enabling-switch | 1× | 1 | · | part |
| 9.6 | Pendant Cable | sanding-robot-pendant-cable | 1× | 1 | · | part |
| 10 | Safety Enclosure 6 parts | sanding-robot-enclosure | 1× | 1 | 15 | assembly |
| 10.1 | Fence Panel | sanding-robot-fence-panel | 8× | 8 | · | part |
| 10.2 | Light Curtain | sanding-robot-light-curtain | 1× | 1 | · | part |
| 10.3 | Safety Door | sanding-robot-safety-door | 1× | 1 | · | part |
| 10.4 | Door Interlock | sanding-robot-door-interlock | 1× | 1 | · | part |
| 10.5 | E-Stop Button | sanding-robot-estop-button | 2× | 2 | · | part |
| 10.6 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 11 | Dress-Pack Cabling 6 parts | sanding-robot-dress-pack | 1× | 1 | 11 | assembly |
| 11.1 | Air Supply Line | sanding-robot-air-line | 1× | 1 | · | part |
| 11.2 | Suction Hose | sanding-robot-suction-hose | 1× | 1 | · | part |
| 11.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 11.4 | Energy Chain | sanding-robot-energy-chain | 1× | 1 | · | part |
| 11.5 | Rotary Union | sanding-robot-rotary-union | 1× | 1 | · | part |
| 11.6 | Connector | connector | 6× | 6 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 11 with this page
Robotic Grinding Cell
1,419 parts · shares 11 with this page
Robotic Deburring Cell
1,637 parts · shares 10 with this page
Robotic Screwdriving Cell
2,109 parts · shares 10 with this page
Sealant Dispensing Robot
2,056 parts · shares 9 with this page
Robotic Palletizing Cell
986 parts · shares 9 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
895-word article