Goods-to-Person Picking Robot
ProductOverview
A goods-to-person picking robot collects a mobile storage pod from anywhere in a warehouse grid and carries it to a fixed operator station, so the picker stands still and the inventory comes to them. It differs from a simple under-rack carrier in two ways: it can move in any direction without turning its body, and it rotates the pod once it arrives so the operator always faces the correct shelf. The result is a pick rate several times higher than walk-and-pick, with the robot doing all the travel. Everything is built on a rigid Drive Base that slides under a pod, lifts it, and steers it through the aisles.
Base and traction
The base centres on the welded Base Frame, with a perimeter Bumper Ring and four Support Caster casters sharing the static load. Motion comes from two Traction Module units, and the key feature is that each wheel is both driven and steered. A Drive Motor turns the Tread Wheel while a separate Steering Motor rotates the whole wheel about a vertical Steering Bearing. By steering both wheels to the same angle the robot can crab sideways, and by steering them to opposing angles it spins in place. This omnidirectional capability lets the robot enter a narrow pod slot from any heading without the multi-point turns a fixed-axle robot would need. Two Traction Encoder sensors per module report drive speed and steer angle.
Load handler
Lifting the pod is the job of the Load Handler. A Lift Actuator drives a Ball Screw through a Ball Nut Carrier carrier to extend a Scissor Frame, raising the deck about eighty millimetres so the pod legs clear the floor. The ball screw is chosen over a hydraulic ram because it holds height precisely without leaks and draws no power once stopped. On top sits a powered Turntable running on a Slew Ring and driven by a geared Turntable Motor; this is what rotates the lifted pod to present the right face to the operator. A high-friction Deck Grip Pad couples the deck to the pod base so the pod turns with the deck rather than slipping, and a Lift Sensor confirms height and pod presence before the robot drives off.
Power
The Energy System runs the robot through a full shift on opportunity charging. A Traction Battery of lithium Lithium Cell cells in a sealed Battery Case supplies traction power, managed by a Battery Management that balances cells and reports state of charge. Rather than swapping packs, the robot drives onto a floor rail where a spring Charge Shoe meets the contacts and tops up between jobs. A DC-DC Converter converter steps the pack voltage down to the logic and sensor rails.
Control and perception
The Control Core houses the Compute Board that runs navigation and task logic, three Motor Drive amplifiers for the drive, steer, and lift axes, and an I/O Board for field signals, with a IMU aiding dead reckoning. Localization uses the Perception Suite suite: a spinning Navigation LiDAR tracks aisle structure for coarse position, a downward Floor Reader decodes floor fiducials to pin location to within a centimetre, and an upward Pod Camera aligns the deck to the pod base before lifting. Perimeter Proximity Sensor sensors catch near obstacles the scanners miss.
Safety and fleet operation
Sharing a floor with people at the pick stations makes the Safety Stack mandatory certified hardware. Two Safety Scanner units monitor protective fields, a Safety Relay Module module enforces a dual-channel safe stop, and Emergency Stop buttons cut drive power directly, with a Status Beacon showing state. Jobs arrive over the Operator Link, where a Fleet Radio exchanges tasks with the warehouse control system and a small Status Panel shows local state. The central system schedules which pod goes to which station, sequences charging, and routes traffic so robots do not block one another. All circuits run through the Wiring Harness harness and are protected at the Fuse Block. The payoff is that a single operator, fed by a steady stream of pods, picks far more order lines per hour than they could on foot, and the warehouse layout can be re-densified by software because nothing is fixed to the floor but the fiducials.
Goods-to-Person Picking Robot parts and their functions
9 top-level parts · 1,093 parts in total · full bill of materials below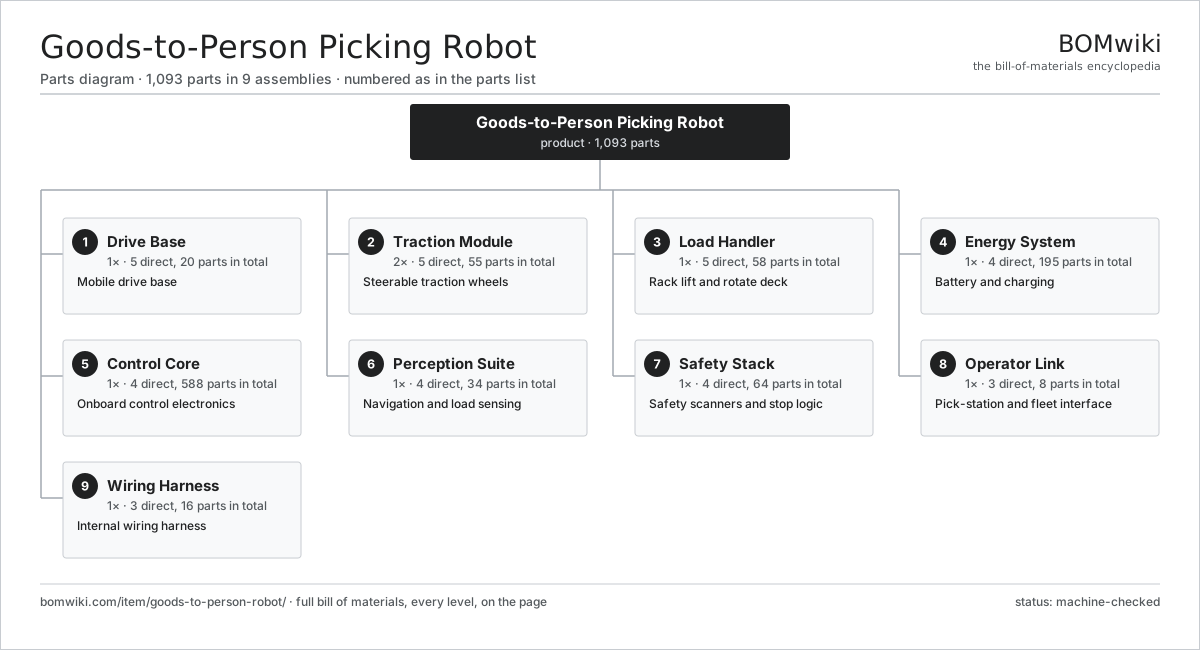
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Drive Base 5 parts | 1× | Mobile drive base |
| 2 | Traction Module 5 parts | 2× | Steerable traction wheels |
| 3 | Load Handler 5 parts | 1× | Rack lift and rotate deck |
| 4 | Energy System 4 parts | 1× | Battery and charging |
| 5 | Control Core 4 parts | 1× | Onboard control electronics |
| 6 | Perception Suite 4 parts | 1× | Navigation and load sensing |
| 7 | Safety Stack 4 parts | 1× | Safety scanners and stop logic |
| 8 | Operator Link 3 parts | 1× | Pick-station and fleet interface |
| 9 | Wiring Harness 3 parts | 1× | Internal wiring harness |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Goods-to-Person Picking Robot
9 top-level lines · 102 rows shown · 1,093 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Drive Base 5 parts | goods-to-person-robot-drive-base | 1× | 1 | 20 | assembly |
| 1.1 | Base Frame | goods-to-person-robot-base-frame | 1× | 1 | · | part |
| 1.2 | Cover Set | goods-to-person-robot-cover-set | 1× | 1 | · | part |
| 1.3 | Bumper Ring | goods-to-person-robot-bumper-ring | 1× | 1 | · | part |
| 1.4 | Support Caster 3 parts | goods-to-person-robot-support-caster | 4× | 4 | 4 | assembly |
| 1.4.1 | Caster Fork | goods-to-person-robot-caster-fork | 1× | 4 | · | part |
| 1.4.2 | Caster Wheel | goods-to-person-robot-caster-wheel | 1× | 4 | · | part |
| 1.4.3 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Traction Module 5 parts | goods-to-person-robot-traction-module | 2× | 2 | 55 | assembly |
| 2.1 | Drive Motor 4 parts | goods-to-person-robot-drive-motor | 1× | 2 | 25 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.1.3 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 2.1.4 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.2 | Steering Motor 2 parts | goods-to-person-robot-steer-motor | 1× | 2 | 25 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 2.3 | Tread Wheel 2 parts | goods-to-person-robot-wheel | 1× | 2 | 2 | assembly |
| 2.3.1 | Wheel Hub | goods-to-person-robot-wheel-hub | 1× | 2 | · | part |
| 2.3.2 | Wheel Tread | goods-to-person-robot-tread | 1× | 2 | · | part |
| 2.4 | Steering Bearing | goods-to-person-robot-steer-bearing | 1× | 2 | · | part |
| 2.5 | Traction Encoder | goods-to-person-robot-traction-encoder | 2× | 4 | · | part |
| 3 | Load Handler 5 parts | goods-to-person-robot-load-handler | 1× | 1 | 58 | assembly |
| 3.1 | Lift Actuator 4 parts | goods-to-person-robot-lift-actuator | 1× | 1 | 28 | assembly |
| 3.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 3.1.2 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 3.1.3 | Ball Nut Carrier | goods-to-person-robot-lift-nut | 1× | 1 | · | part |
| 3.1.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.2 | Scissor Frame | goods-to-person-robot-scissor-frame | 1× | 1 | · | part |
| 3.3 | Turntable 3 parts | goods-to-person-robot-turntable | 1× | 1 | 27 | assembly |
| 3.3.1 | Turntable Motor 2 parts + deeper › | goods-to-person-robot-turntable-motor | 1× | 1 | 25 | assembly |
| 3.3.2 | Slew Ring | goods-to-person-robot-slew-ring | 1× | 1 | · | part |
| 3.3.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 3.4 | Deck Grip Pad | goods-to-person-robot-deck-pad | 1× | 1 | · | part |
| 3.5 | Lift Sensor | goods-to-person-robot-lift-sensor | 1× | 1 | · | part |
| 4 | Energy System 4 parts | goods-to-person-robot-energy-system | 1× | 1 | 195 | assembly |
| 4.1 | Traction Battery 3 parts | goods-to-person-robot-battery | 1× | 1 | 31 | assembly |
| 4.1.1 | Lithium Cell | goods-to-person-robot-cell | 28× | 28 | · | part |
| 4.1.2 | Battery Case | goods-to-person-robot-battery-case | 1× | 1 | · | part |
| 4.1.3 | Connector | connector | 2× | 2 | · | part |
| 4.2 | Battery Management 3 parts | goods-to-person-robot-bms | 1× | 1 | 102 | assembly |
| 4.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.2.3 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 4.3 | Charge Shoe | goods-to-person-robot-charge-shoe | 1× | 1 | · | part |
| 4.4 | DC-DC Converter 2 parts | goods-to-person-robot-dcdc | 1× | 1 | 61 | assembly |
| 4.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4.2 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 5 | Control Core 4 parts | goods-to-person-robot-control-core | 1× | 1 | 588 | assembly |
| 5.1 | Compute Board 4 parts | goods-to-person-robot-compute-board | 1× | 1 | 230 | assembly |
| 5.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.1.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.1.3 | SMD Passive (R/C/L) | smd-passives | 220× | 220 | · | part |
| 5.1.4 | Connector | connector | 8× | 8 | · | part |
| 5.2 | Motor Drive 4 parts | goods-to-person-robot-motor-drive | 3× | 3 | 94 | assembly |
| 5.2.1 | Bare PCB | pcb-bare | 1× | 3 | · | part |
| 5.2.2 | Microcontroller | mcu | 1× | 3 | · | part |
| 5.2.3 | SMD Passive (R/C/L) | smd-passives | 90× | 270 | · | part |
| 5.2.4 | Connector | connector | 2× | 6 | · | part |
| 5.3 | I/O Board 3 parts | goods-to-person-robot-io-board | 1× | 1 | 75 | assembly |
| 5.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3.2 | Relay | relay | 4× | 4 | · | part |
| 5.3.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 5.4 | IMU | goods-to-person-robot-imu | 1× | 1 | · | part |
| 6 | Perception Suite 4 parts | goods-to-person-robot-perception | 1× | 1 | 34 | assembly |
| 6.1 | Navigation LiDAR 3 parts | goods-to-person-robot-nav-lidar | 1× | 1 | 26 | assembly |
| 6.1.1 | LiDAR Optics | goods-to-person-robot-lidar-optics | 1× | 1 | · | part |
| 6.1.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.2 | Floor Reader 2 parts | goods-to-person-robot-floor-reader | 1× | 1 | 2 | assembly |
| 6.2.1 | Image Sensor | goods-to-person-robot-image-sensor | 1× | 1 | · | part |
| 6.2.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.3 | Pod Camera 2 parts | goods-to-person-robot-pod-camera | 1× | 1 | 2 | assembly |
| 6.3.1 | Image Sensor | goods-to-person-robot-image-sensor | 1× | 1 | · | part |
| 6.3.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.4 | Proximity Sensor | goods-to-person-robot-proximity | 4× | 4 | · | part |
| 7 | Safety Stack 4 parts | goods-to-person-robot-safety-stack | 1× | 1 | 64 | assembly |
| 7.1 | Safety Scanner 4 parts | goods-to-person-robot-safety-scanner | 2× | 2 | 27 | assembly |
| 7.1.1 | LiDAR Optics | goods-to-person-robot-lidar-optics | 1× | 2 | · | part |
| 7.1.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 7.1.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 7.1.4 | Microcontroller | mcu | 1× | 2 | · | part |
| 7.2 | Safety Relay Module 3 parts | goods-to-person-robot-safety-relay | 1× | 1 | 7 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2.2 | Relay | relay | 4× | 4 | · | part |
| 7.2.3 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.3 | Emergency Stop | goods-to-person-robot-estop | 2× | 2 | · | part |
| 7.4 | Status Beacon | goods-to-person-robot-beacon | 1× | 1 | · | part |
| 8 | Operator Link 3 parts | goods-to-person-robot-operator-link | 1× | 1 | 8 | assembly |
| 8.1 | Fleet Radio 3 parts | goods-to-person-robot-fleet-radio | 1× | 1 | 4 | assembly |
| 8.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.1.3 | Connector | connector | 2× | 2 | · | part |
| 8.2 | Status Panel 2 parts | goods-to-person-robot-status-panel | 1× | 1 | 2 | assembly |
| 8.2.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3 | Antenna | goods-to-person-robot-antenna | 2× | 2 | · | part |
| 9 | Wiring Harness 3 parts | goods-to-person-robot-wiring | 1× | 1 | 16 | assembly |
| 9.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 9.2 | Connector | connector | 14× | 14 | · | part |
| 9.3 | Fuse Block | goods-to-person-robot-fuse-block | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Cartesian Gantry Robot
1,051 parts · shares 3 with this page
 Cartesian Pick Robot
781 parts · shares 3 with this page
 Robotic Assembly Cell
1,746 parts · shares 3 with this page
Robotic Grinding Cell
1,419 parts · shares 3 with this page
Tote Handling Robot
1,042 parts · shares 3 with this page
Adhesive Dispensing Robot
685 parts · shares 2 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
884-word article