AGV Mobile Robot
ProductOverview
The AGV mobile robot is an autonomous load carrier for intralogistics, moving totes, pallets, and racks between stations without fixed guide paths. A differential drive layout with two centrally mounted wheel modules lets it rotate in place, while swivel casters at each end carry the load. Onboard LiDAR mapping and SLAM let it localize against the building rather than floor markers, so routes can be reconfigured in software. A signal tower and touch panel report status, and a certified safety scanner slows or stops the robot when a person enters its field.
Construction
The vehicle is built on the Chassis, a welded steel base frame with bolt-on covers and a compliant safety bumper around the perimeter. Two Drive Module units provide propulsion: each pairs a geared BLDC wheel motor with an encoder and a local field-oriented controller. Each drive module rides on a sprung Suspension Arm rocker that keeps the wheel loaded on uneven floors, and unpowered Swivel Caster units at the front and rear share the load.
Energy comes from the Battery Pack, a 10S6P Li-ion array with an integrated BMS and pack fusing; the robot returns to its dock and mates the Charge Contacts plate automatically when charge runs low. The Navigation Compute module runs SLAM and path planning on a navigation SoC alongside a real-time safety MCU, fusing data from the Sensor Suite of navigation LiDAR, cameras, ultrasonics, and the certified safety scanner.
Payload handling is done by the Lift Module, a leadscrew-driven scissor deck with powered transfer rollers that raises a load off a stand or hands it to a conveyor. The Motor Driver Board supplies the high-current drive stage, and a wireless Wireless Comms Board keeps the robot in contact with the fleet manager for traffic and task assignment.
AGV Mobile Robot parts and their functions
14 top-level parts · 383 parts in total · full bill of materials below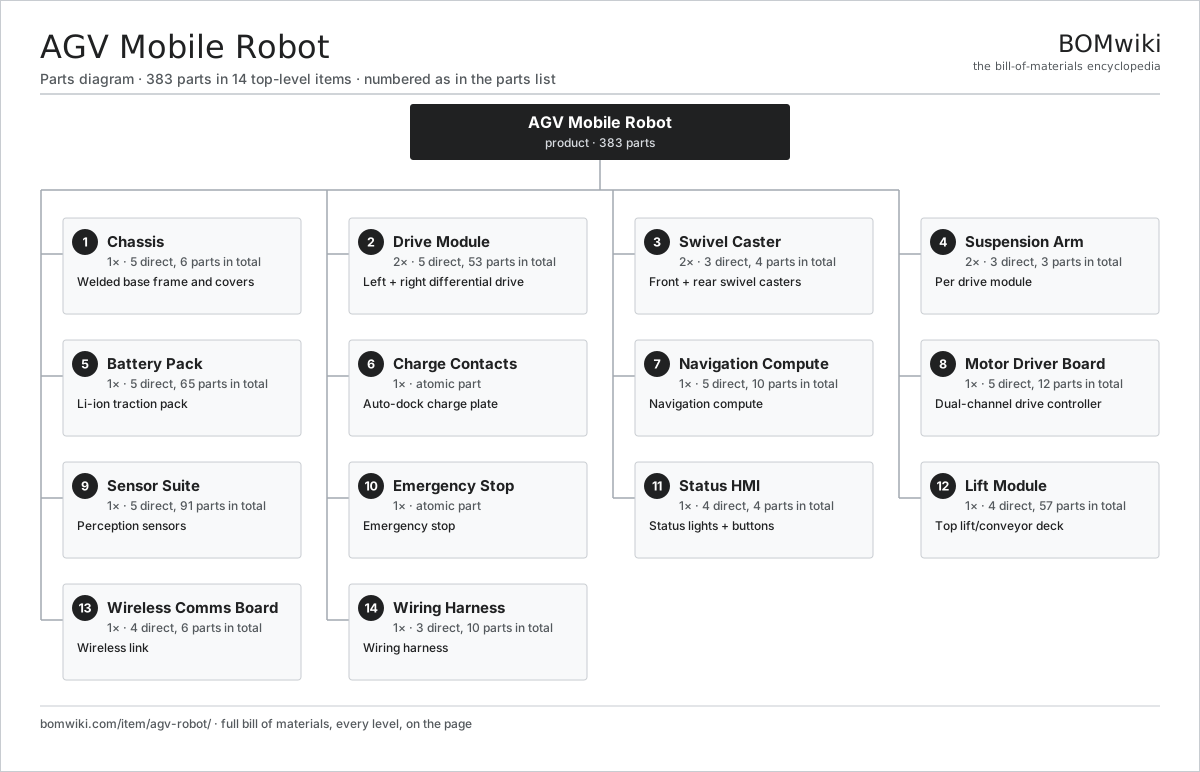
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Chassis 5 parts | 1× | Welded base frame and covers |
| 2 | Drive Module 5 parts | 2× | Left + right differential drive |
| 3 | Swivel Caster 3 parts | 2× | Front + rear swivel casters |
| 4 | Suspension Arm 3 parts | 2× | Per drive module |
| 5 | Battery Pack 5 parts | 1× | Li-ion traction pack |
| 6 | Charge Contacts | 1× | Auto-dock charge plate |
| 7 | Navigation Compute 5 parts | 1× | Navigation compute |
| 8 | Motor Driver Board 5 parts | 1× | Dual-channel drive controller |
| 9 | Sensor Suite 5 parts | 1× | Perception sensors |
| 10 | Emergency Stop | 1× | Emergency stop |
| 11 | Status HMI 4 parts | 1× | Status lights + buttons |
| 12 | Lift Module 4 parts | 1× | Top lift/conveyor deck |
| 13 | Wireless Comms Board 4 parts | 1× | Wireless link |
| 14 | Wiring Harness 3 parts | 1× | Wiring harness |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for AGV Mobile Robot
14 top-level lines · 100 rows shown · 383 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Chassis 5 parts | agv-robot-chassis | 1× | 1 | 6 | assembly |
| 1.1 | Base Weldment | agv-robot-base-weldment | 1× | 1 | · | part |
| 1.2 | Top Cover | agv-robot-top-cover | 1× | 1 | · | part |
| 1.3 | Side Cover | agv-robot-side-cover | 2× | 2 | · | part |
| 1.4 | Safety Bumper | agv-robot-bumper | 1× | 1 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Drive Module 5 parts | agv-robot-drive-module | 2× | 2 | 53 | assembly |
| 2.1 | BLDC Wheel Motor 6 parts | agv-robot-wheel-motor | 1× | 2 | 36 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.1.3 | Neodymium Magnet | neodymium-magnet | 8× | 16 | · | part |
| 2.1.4 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 2.1.5 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.1.6 | Hall Sensor | hall-sensor | 3× | 6 | · | part |
| 2.2 | Drive Gearbox 3 parts | agv-robot-drive-gearbox | 1× | 2 | 4 | assembly |
| 2.2.1 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 2.2.2 | Gearbox Housing | gearbox-housing | 1× | 2 | · | part |
| 2.2.3 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 2.3 | Drive Wheel 2 parts | agv-robot-drive-wheel | 1× | 2 | 2 | assembly |
| 2.3.1 | Wheel Hub | agv-robot-wheel-hub | 1× | 2 | · | part |
| 2.3.2 | Tire | tire | 1× | 2 | · | part |
| 2.4 | Encoder | encoder | 1× | 2 | · | part |
| 2.5 | Wheel Motor Controller 4 parts | agv-robot-wheel-controller | 1× | 2 | 10 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.5.2 | Microcontroller | mcu | 1× | 2 | · | part |
| 2.5.3 | Power MOSFET | mosfet | 6× | 12 | · | part |
| 2.5.4 | Connector | connector | 2× | 4 | · | part |
| 3 | Swivel Caster 3 parts | agv-robot-caster | 2× | 2 | 4 | assembly |
| 3.1 | Caster Fork | agv-robot-caster-fork | 1× | 2 | · | part |
| 3.2 | Caster Wheel | agv-robot-caster-wheel | 1× | 2 | · | part |
| 3.3 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 4 | Suspension Arm 3 parts | agv-robot-suspension | 2× | 2 | 3 | assembly |
| 4.1 | Rocker Arm | agv-robot-rocker-arm | 1× | 2 | · | part |
| 4.2 | Suspension Spring | agv-robot-suspension-spring | 1× | 2 | · | part |
| 4.3 | Ball Bearing | ball-bearing | 1× | 2 | · | part |
| 5 | Battery Pack 5 parts | agv-robot-battery-pack | 1× | 1 | 65 | assembly |
| 5.1 | Li-ion Cell, 18650 | li-cell-18650 | 60× | 60 | · | part |
| 5.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 5.3 | Battery Enclosure | agv-robot-battery-enclosure | 1× | 1 | · | part |
| 5.4 | Fuse Box | fuse-box | 1× | 1 | · | part |
| 5.5 | Connector | connector | 2× | 2 | · | part |
| 6 | Charge Contacts | agv-robot-charge-contacts | 1× | 1 | · | part |
| 7 | Navigation Compute 5 parts | agv-robot-compute | 1× | 1 | 10 | assembly |
| 7.1 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4 | IMU Module | agv-robot-imu | 1× | 1 | · | part |
| 7.5 | Connector | connector | 6× | 6 | · | part |
| 8 | Motor Driver Board 5 parts | agv-robot-motor-driver | 1× | 1 | 12 | assembly |
| 8.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2 | IGBT Power Module | igbt-module | 2× | 2 | · | part |
| 8.3 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 8.4 | Relay | relay | 1× | 1 | · | part |
| 8.5 | Connector | connector | 4× | 4 | · | part |
| 9 | Sensor Suite 5 parts | agv-robot-sensor-suite | 1× | 1 | 91 | assembly |
| 9.1 | 2D LiDAR 4 parts | agv-robot-lidar-2d | 1× | 1 | 27 | assembly |
| 9.1.1 | LiDAR Optics Module | agv-robot-lidar-optics | 1× | 1 | · | part |
| 9.1.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 9.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.1.4 | Encoder | encoder | 1× | 1 | · | part |
| 9.2 | 3D LiDAR 3 parts | agv-robot-lidar-3d | 1× | 1 | 27 | assembly |
| 9.2.1 | LiDAR Optics Module | agv-robot-lidar-optics | 2× | 2 | · | part |
| 9.2.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 9.2.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.3 | Camera Module 3 parts | camera-module | 2× | 2 | 3 | assembly |
| 9.3.1 | CMOS Image Sensor | image-sensor | 1× | 2 | · | part |
| 9.3.2 | Lens Assembly | camera-lens | 1× | 2 | · | part |
| 9.3.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 9.4 | Ultrasonic Sensor | agv-robot-ultrasonic | 4× | 4 | · | part |
| 9.5 | Safety Laser Scanner 4 parts | agv-robot-safety-scanner | 1× | 1 | 27 | assembly |
| 9.5.1 | LiDAR Optics Module | agv-robot-lidar-optics | 1× | 1 | · | part |
| 9.5.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 9.5.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.5.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 10 | Emergency Stop | agv-robot-estop | 1× | 1 | · | part |
| 11 | Status HMI 4 parts | agv-robot-hmi | 1× | 1 | 4 | assembly |
| 11.1 | Signal Tower | agv-robot-signal-tower | 1× | 1 | · | part |
| 11.2 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 11.3 | Button Panel | agv-robot-button-panel | 1× | 1 | · | part |
| 11.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 12 | Lift Module 4 parts | agv-robot-lift-module | 1× | 1 | 57 | assembly |
| 12.1 | Lift Actuator 3 parts | agv-robot-lift-motor | 1× | 1 | 26 | assembly |
| 12.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 12.1.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 12.1.3 | Lift Leadscrew | agv-robot-leadscrew | 1× | 1 | · | part |
| 12.2 | Scissor Mechanism | agv-robot-scissor-mech | 1× | 1 | · | part |
| 12.3 | Conveyor Deck 3 parts | agv-robot-conveyor-deck | 1× | 1 | 29 | assembly |
| 12.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 12.3.2 | Roller Set | agv-robot-roller-set | 1× | 1 | · | part |
| 12.3.3 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 12.4 | Payload Sensor | agv-robot-payload-sensor | 1× | 1 | · | part |
| 13 | Wireless Comms Board 4 parts | agv-robot-comms-board | 1× | 1 | 6 | assembly |
| 13.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 13.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 13.3 | Antenna | agv-robot-antenna | 2× | 2 | · | part |
| 13.4 | Connector | connector | 2× | 2 | · | part |
| 14 | Wiring Harness 3 parts | agv-robot-harness | 1× | 1 | 10 | assembly |
| 14.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 14.2 | Connector | connector | 8× | 8 | · | part |
| 14.3 | Fuse Box | fuse-box | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Mobile Manipulator
1,307 parts · shares 10 with this page
 Humanoid Robot
3,158 parts · shares 7 with this page
Delta Pick-and-Place Robot
579 parts · shares 6 with this page
Security Patrol Robot
582 parts · shares 7 with this page
 Telepresence Robot
240 parts · shares 7 with this page
Drywall Finishing Robot
179 parts · shares 6 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
318-word article