Adhesive Dispensing Robot
ProductOverview
An adhesive dispensing robot lays a controlled bead of glue, sealant, grease, or potting compound onto a part along a programmed path. It shows up wherever a fluid has to go exactly where the design says and nowhere else: bonding phone housings, sealing automotive electronics, gasketing enclosures, underfilling chips. The two things that matter are where the bead goes and how much fluid comes out, so the machine is really two coordinated systems, a Frame & Enclosure carrying three linear axes that move the nozzle, and a metering valve that doses fluid by volume, with a camera tying the path to the actual part in front of it.
How it works
Positioning uses three stacked ball-screw axes. The X Linear Axis and Y Linear Axis sweep the nozzle across the work area while the Z Linear Axis sets the gap between nozzle and part and lifts clear between beads. Each axis runs a precision Ball Screw on profiled Linear Guide rails, driven by an AC AC Servo Motor whose Servo Encoder closes the position loop through a Servo Drive; ball screws are chosen over belts here because dispensing rewards fine, repeatable positioning over speed.
Fluid handling is separate from motion. A Cartridge Feed feeds material under regulated air pressure to the Dispense Valve & Pump, where a stepper-driven auger meters the dose by volume and a needle starts and stops the bead cleanly so it does not string or drool. Before dispensing, a down-looking Vision Alignment camera finds fiducials on the part and shifts the whole program to match the part's real position and rotation, which removes the need for precise fixturing. The Controller coordinates axes, valve, and vision so flow rate tracks travel speed and the bead width stays constant around corners. An operator runs and edits programs from the touchscreen Operator HMI, and everything is wired through the Internal Harness harness inside the guarded enclosure.
Adhesive Dispensing Robot parts and their functions
10 top-level parts · 685 parts in total · full bill of materials below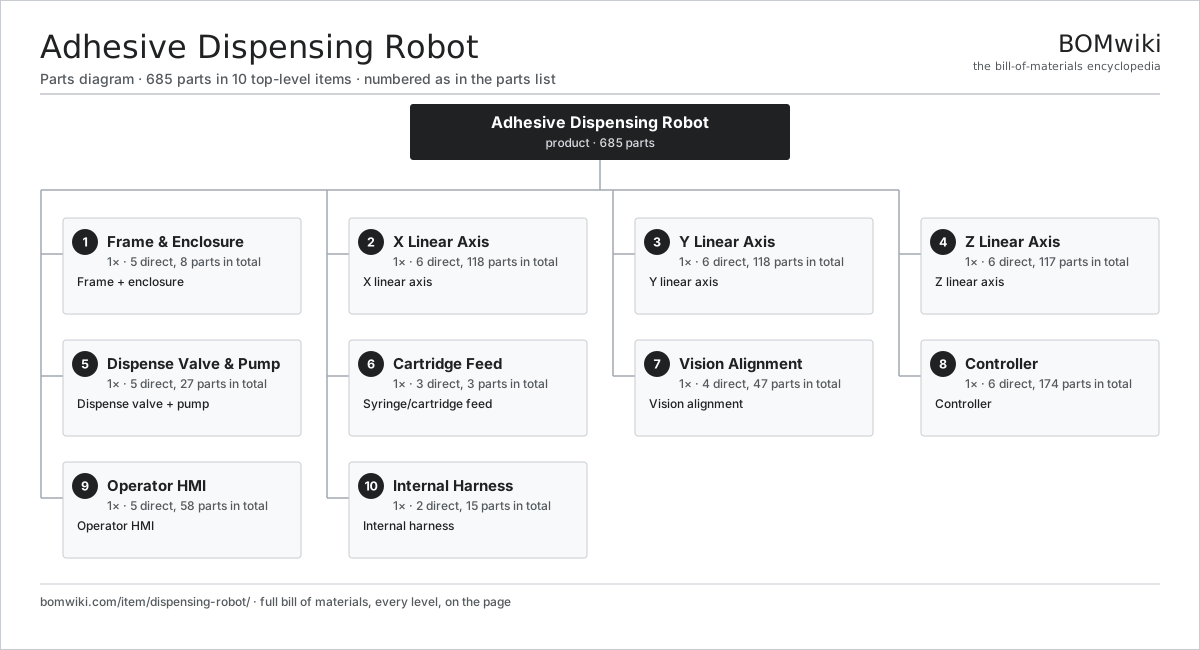
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Frame & Enclosure 5 parts | 1× | Frame + enclosure |
| 2 | X Linear Axis 6 parts | 1× | X linear axis |
| 3 | Y Linear Axis 6 parts | 1× | Y linear axis |
| 4 | Z Linear Axis 6 parts | 1× | Z linear axis |
| 5 | Dispense Valve & Pump 5 parts | 1× | Dispense valve + pump |
| 6 | Cartridge Feed 3 parts | 1× | Syringe/cartridge feed |
| 7 | Vision Alignment 4 parts | 1× | Vision alignment |
| 8 | Controller 6 parts | 1× | Controller |
| 9 | Operator HMI 5 parts | 1× | Operator HMI |
| 10 | Internal Harness 2 parts | 1× | Internal harness |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Adhesive Dispensing Robot
10 top-level lines · 108 rows shown · 685 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Frame & Enclosure 5 parts | dispensing-robot-frame | 1× | 1 | 8 | assembly |
| 1.1 | Base Frame | dispensing-robot-base-frame | 1× | 1 | · | part |
| 1.2 | Work Platen | dispensing-robot-work-platen | 1× | 1 | · | part |
| 1.3 | Enclosure Panel | dispensing-robot-enclosure-panel | 4× | 4 | · | part |
| 1.4 | Door Interlock | dispensing-robot-door-interlock | 1× | 1 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | X Linear Axis 6 parts | dispensing-robot-x-axis | 1× | 1 | 118 | assembly |
| 2.1 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 2.2 | Linear Guide | dispensing-robot-linear-guide | 2× | 2 | · | part |
| 2.3 | AC Servo Motor 6 parts | dispensing-robot-servo-motor | 1× | 1 | 34 | assembly |
| 2.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.3.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 2.3.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 2.3.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 2.3.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.4 | Servo Encoder 3 parts | dispensing-robot-encoder | 1× | 1 | 4 | assembly |
| 2.4.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 2.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.4.3 | Code Disc | dispensing-robot-encoder-disc | 1× | 1 | · | part |
| 2.5 | Servo Drive 4 parts | dispensing-robot-servo-drive | 1× | 1 | 75 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.5.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 2.5.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 2.5.4 | Connector | connector | 3× | 3 | · | part |
| 2.6 | Limit Switch | dispensing-robot-limit-switch | 2× | 2 | · | part |
| 3 | Y Linear Axis 6 parts | dispensing-robot-y-axis | 1× | 1 | 118 | assembly |
| 3.1 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 3.2 | Linear Guide | dispensing-robot-linear-guide | 2× | 2 | · | part |
| 3.3 | AC Servo Motor 6 parts | dispensing-robot-servo-motor | 1× | 1 | 34 | assembly |
| 3.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 3.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 3.3.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 3.3.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 3.3.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 3.3.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.4 | Servo Encoder 3 parts | dispensing-robot-encoder | 1× | 1 | 4 | assembly |
| 3.4.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 3.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.4.3 | Code Disc | dispensing-robot-encoder-disc | 1× | 1 | · | part |
| 3.5 | Servo Drive 4 parts | dispensing-robot-servo-drive | 1× | 1 | 75 | assembly |
| 3.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.5.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 3.5.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 3.5.4 | Connector | connector | 3× | 3 | · | part |
| 3.6 | Limit Switch | dispensing-robot-limit-switch | 2× | 2 | · | part |
| 4 | Z Linear Axis 6 parts | dispensing-robot-z-axis | 1× | 1 | 117 | assembly |
| 4.1 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 4.2 | Linear Guide | dispensing-robot-linear-guide | 2× | 2 | · | part |
| 4.3 | AC Servo Motor 6 parts | dispensing-robot-servo-motor | 1× | 1 | 34 | assembly |
| 4.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 4.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 4.3.3 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 4.3.4 | Neodymium Magnet | neodymium-magnet | 8× | 8 | · | part |
| 4.3.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 4.3.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 4.4 | Servo Encoder 3 parts | dispensing-robot-encoder | 1× | 1 | 4 | assembly |
| 4.4.1 | Hall Sensor | hall-sensor | 2× | 2 | · | part |
| 4.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4.3 | Code Disc | dispensing-robot-encoder-disc | 1× | 1 | · | part |
| 4.5 | Servo Drive 4 parts | dispensing-robot-servo-drive | 1× | 1 | 75 | assembly |
| 4.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.5.2 | IGBT Power Module | igbt-module | 1× | 1 | · | part |
| 4.5.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 4.5.4 | Connector | connector | 3× | 3 | · | part |
| 4.6 | Axis Holding Brake | dispensing-robot-z-brake | 1× | 1 | · | part |
| 5 | Dispense Valve & Pump 5 parts | dispensing-robot-valve | 1× | 1 | 27 | assembly |
| 5.1 | Valve Body | dispensing-robot-valve-body | 1× | 1 | · | part |
| 5.2 | Metering Needle | dispensing-robot-needle | 1× | 1 | · | part |
| 5.3 | Dispense Nozzle | dispensing-robot-nozzle | 1× | 1 | · | part |
| 5.4 | Pump Stepper Motor 3 parts | dispensing-robot-pump-stepper | 1× | 1 | 23 | assembly |
| 5.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 5.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 5.4.3 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 5.5 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 6 | Cartridge Feed 3 parts | dispensing-robot-cartridge | 1× | 1 | 3 | assembly |
| 6.1 | Fluid Cartridge | dispensing-robot-syringe | 1× | 1 | · | part |
| 6.2 | Pressure Regulator | dispensing-robot-pressure-reg | 1× | 1 | · | part |
| 6.3 | Feed Tube | dispensing-robot-feed-tube | 1× | 1 | · | part |
| 7 | Vision Alignment 4 parts | dispensing-robot-vision | 1× | 1 | 47 | assembly |
| 7.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 7.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 7.3 | Ring Light | dispensing-robot-ring-light | 1× | 1 | · | part |
| 7.4 | Vision Board 4 parts | dispensing-robot-vision-board | 1× | 1 | 44 | assembly |
| 7.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.4.3 | SMD Passive (R/C/L) | smd-passives | 40× | 40 | · | part |
| 7.4.4 | Connector | connector | 2× | 2 | · | part |
| 8 | Controller 6 parts | dispensing-robot-controller | 1× | 1 | 174 | assembly |
| 8.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 8.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.4 | Power Supply | dispensing-robot-power-supply | 1× | 1 | · | part |
| 8.5 | SMD Passive (R/C/L) | smd-passives | 160× | 160 | · | part |
| 8.6 | Connector | connector | 10× | 10 | · | part |
| 9 | Operator HMI 5 parts | dispensing-robot-hmi | 1× | 1 | 58 | assembly |
| 9.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 9.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 9.3 | HMI Board 4 parts | dispensing-robot-hmi-board | 1× | 1 | 54 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 9.3.3 | SMD Passive (R/C/L) | smd-passives | 50× | 50 | · | part |
| 9.3.4 | Connector | connector | 2× | 2 | · | part |
| 9.4 | E-Stop | dispensing-robot-estop | 1× | 1 | · | part |
| 9.5 | HMI Shell | dispensing-robot-hmi-shell | 1× | 1 | · | part |
| 10 | Internal Harness 2 parts | dispensing-robot-cabling | 1× | 1 | 15 | assembly |
| 10.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 10.2 | Connector | connector | 14× | 14 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 8 with this page
Sealant Dispensing Robot
2,056 parts · shares 7 with this page
 Cartesian Gantry Robot
1,051 parts · shares 6 with this page
Drone Docking Station
210 parts · shares 5 with this page
Robotic Grinding Cell
1,419 parts · shares 5 with this page
 Telepresence Robot
240 parts · shares 5 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
336-word article