Robotic Piece-Picking Cell
ProductOverview
A robotic piece-picking cell does the job that has long resisted automation in fulfilment: reaching into a bin of mixed, jumbled items and pulling out the single piece an order calls for. It combines a six-axis arm, a 3D camera that understands the pile of items in a bin, and a gripper that can handle objects from a soft poly bag to a rigid box. Source bins arrive on one conveyor, the robot picks the requested item, and order totes leave on another. The whole thing sits inside a guarded Cell Frame and is coordinated by a Cell Controller that talks to the warehouse management system. The difficulty is not the motion but the perception and grasping of unknown items, which is where most of the engineering goes.
The arm
The Pick Arm is a conventional six-axis design sized for the short, fast moves of bin picking. The heavy lower joints, the Base Joint (Axis 1) and Shoulder Joint (Axis 2), use cycloidal RV Reducer reducers for their high torque and shock tolerance, with a Axis Brake on the gravity-loaded shoulder. The Elbow Joint (Axis 3) and the three-axis Wrist (Axes 4-6) use Harmonic Reducer strain-wave gears, which give zero backlash in a small package so the tool pose stays precise. Each joint is a Servo Motor geared through its reducer. The arm links are Arm Link Casting aluminium, and a Arm Harness routes wiring and a vacuum Air Line internally to the tool flange so nothing snags in the bin.
Gripper
The Hybrid Gripper is a hybrid because no single end effector handles every SKU. A Suction Head with multiple bellows Suction Cup cups picks flat, smooth, and bagged goods; each cup has a Check Valve so cups that miss an item do not bleed away the vacuum holding the ones that hit. For rigid or non-porous items a Finger Gripper with a Grip Force Sensor clamps gently enough not to crush packaging. A Tool Changer passes power, signal, and vacuum, and a Vacuum Sensor confirms the grip before the arm lifts so the cell knows immediately if a pick failed.
Vision
The 3D Vision System is what lets the robot pick items it has never seen arranged in a pile it has never seen. A Pattern Projector casts a pattern that the 3D Camera uses to build a dense point cloud of the bin, lit evenly by a Bin Light ring. The Vision Processor segments the cloud into individual items, then computes a grasp pose: where to place a suction cup or how to align fingers, and in what order to clear items so the robot does not dig itself into a corner. This grasp planning runs every cycle because the bin looks different after each pick.
Material flow and vacuum
Items reach and leave the cell on the Tote Conveyor. A Infeed Belt presents a source bin to the pick zone and an Outfeed Belt carries order totes away, each driven by a geared Belt Motor and registered by a Tote Stop. Suction power comes from the Vacuum Unit, where a Vacuum Pump charges a Vacuum Reservoir reservoir so the Vacuum Valve valves can snap full vacuum to a cup the instant it touches an item. A Inlet Filter keeps warehouse dust out of the pump.
Control and safety
The Cell Controller holds a real-time Motion Board, one Servo Drive per axis, and a Cell PLC that sequences conveyor, vision, and arm against orders streamed from the warehouse system; operators set up and recover the cell from the Teach Pendant with its Enabling Switch. Because a person must occasionally clear a jam, the Safety Package guards every access path with a Light Curtain, coded Door Interlock switches, Emergency Stop buttons, and a Safety Controller that brings the arm to a safe stop. Power and distribution live in the Electrical Cabinet, built around a steel Cabinet Enclosure with a Power Supply, a Breaker Set, and Cooling Fan cooling. Measured in practice, a single cell sustains several hundred to a thousand picks an hour and runs unattended through the night, which is the economic reason these cells are spreading even though their grasp success rate on the hardest SKUs is still improving.
Robotic Piece-Picking Cell parts and their functions
9 top-level parts · 1,797 parts in total · full bill of materials below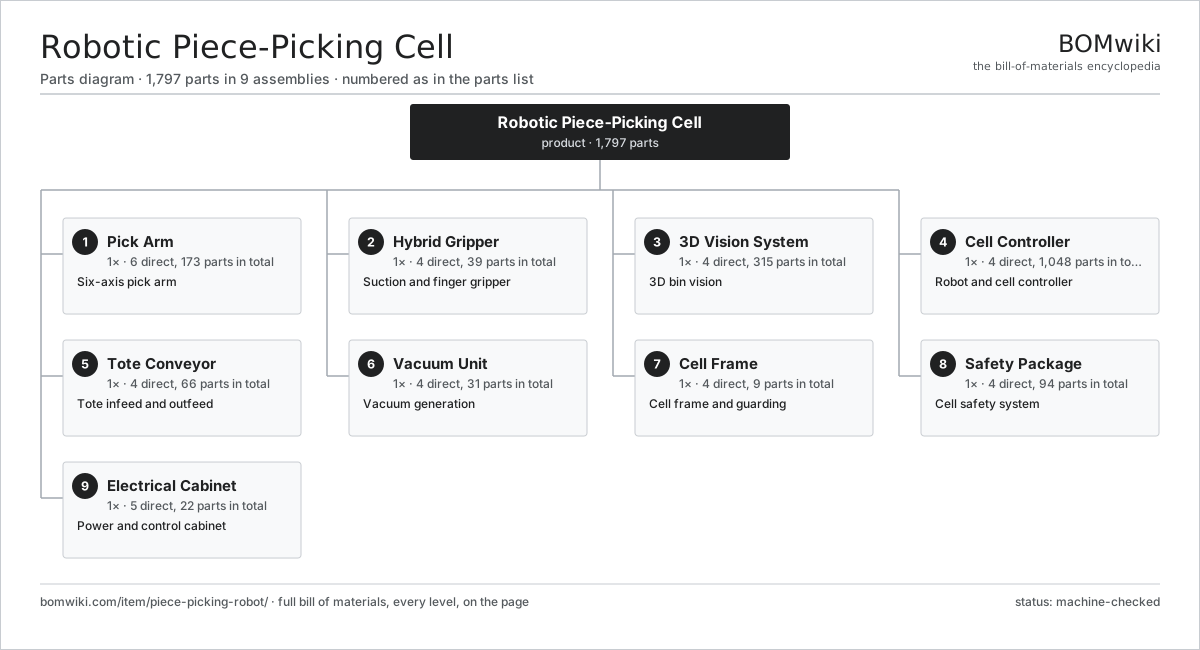
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Pick Arm 6 parts | 1× | Six-axis pick arm |
| 2 | Hybrid Gripper 4 parts | 1× | Suction and finger gripper |
| 3 | 3D Vision System 4 parts | 1× | 3D bin vision |
| 4 | Cell Controller 4 parts | 1× | Robot and cell controller |
| 5 | Tote Conveyor 4 parts | 1× | Tote infeed and outfeed |
| 6 | Vacuum Unit 4 parts | 1× | Vacuum generation |
| 7 | Cell Frame 4 parts | 1× | Cell frame and guarding |
| 8 | Safety Package 4 parts | 1× | Cell safety system |
| 9 | Electrical Cabinet 5 parts | 1× | Power and control cabinet |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Piece-Picking Cell
9 top-level lines · 111 rows shown · 1,797 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Pick Arm 6 parts | piece-picking-robot-arm | 1× | 1 | 173 | assembly |
| 1.1 | Base Joint (Axis 1) 4 parts | piece-picking-robot-base-axis | 1× | 1 | 28 | assembly |
| 1.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.1.2 | RV Reducer | piece-picking-robot-rv-reducer | 1× | 1 | · | part |
| 1.1.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.1.4 | Oil Seal | oil-seal | 1× | 1 | · | part |
| 1.2 | Shoulder Joint (Axis 2) 4 parts | piece-picking-robot-shoulder-axis | 1× | 1 | 28 | assembly |
| 1.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.2.2 | RV Reducer | piece-picking-robot-rv-reducer | 1× | 1 | · | part |
| 1.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.2.4 | Axis Brake | piece-picking-robot-brake | 1× | 1 | · | part |
| 1.3 | Elbow Joint (Axis 3) 3 parts | piece-picking-robot-elbow-axis | 1× | 1 | 27 | assembly |
| 1.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.3.2 | Harmonic Reducer | piece-picking-robot-harmonic-reducer | 1× | 1 | · | part |
| 1.3.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.4 | Wrist (Axes 4-6) 4 parts | piece-picking-robot-wrist | 1× | 1 | 82 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 3× | 3 | 24 | assembly |
| 1.4.2 | Harmonic Reducer | piece-picking-robot-harmonic-reducer | 3× | 3 | · | part |
| 1.4.3 | Ball Bearing | ball-bearing | 6× | 6 | · | part |
| 1.4.4 | Tool Flange | piece-picking-robot-tool-flange | 1× | 1 | · | part |
| 1.5 | Arm Link Casting | piece-picking-robot-arm-casting | 2× | 2 | · | part |
| 1.6 | Arm Harness 3 parts | piece-picking-robot-arm-harness | 1× | 1 | 6 | assembly |
| 1.6.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.6.2 | Air Line | piece-picking-robot-air-line | 1× | 1 | · | part |
| 1.6.3 | Connector | connector | 4× | 4 | · | part |
| 2 | Hybrid Gripper 4 parts | piece-picking-robot-gripper-tool | 1× | 1 | 39 | assembly |
| 2.1 | Suction Head 3 parts | piece-picking-robot-suction-head | 1× | 1 | 9 | assembly |
| 2.1.1 | Suction Cup | piece-picking-robot-suction-cup | 4× | 4 | · | part |
| 2.1.2 | Cup Manifold | piece-picking-robot-cup-manifold | 1× | 1 | · | part |
| 2.1.3 | Check Valve | piece-picking-robot-check-valve | 4× | 4 | · | part |
| 2.2 | Finger Gripper 4 parts | piece-picking-robot-finger-gripper | 1× | 1 | 28 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.2.2 | Gripper Finger | piece-picking-robot-finger | 2× | 2 | · | part |
| 2.2.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.2.4 | Grip Force Sensor | piece-picking-robot-force-sensor | 1× | 1 | · | part |
| 2.3 | Tool Changer | piece-picking-robot-tool-changer | 1× | 1 | · | part |
| 2.4 | Vacuum Sensor | piece-picking-robot-vacuum-sensor | 1× | 1 | · | part |
| 3 | 3D Vision System 4 parts | piece-picking-robot-vision-system | 1× | 1 | 315 | assembly |
| 3.1 | 3D Camera 3 parts | piece-picking-robot-3d-camera | 1× | 1 | 5 | assembly |
| 3.1.1 | Image Sensor | piece-picking-robot-image-sensor | 2× | 2 | · | part |
| 3.1.2 | Camera Lens | piece-picking-robot-camera-lens | 2× | 2 | · | part |
| 3.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.2 | Pattern Projector | piece-picking-robot-projector | 1× | 1 | · | part |
| 3.3 | Bin Light | piece-picking-robot-bin-light | 1× | 1 | · | part |
| 3.4 | Vision Processor 4 parts | piece-picking-robot-vision-pc | 1× | 1 | 308 | assembly |
| 3.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.4.3 | SMD Passive (R/C/L) | smd-passives | 300× | 300 | · | part |
| 3.4.4 | Connector | connector | 6× | 6 | · | part |
| 4 | Cell Controller 4 parts | piece-picking-robot-controller | 1× | 1 | 1,048 | assembly |
| 4.1 | Motion Board 4 parts | piece-picking-robot-motion-board | 1× | 1 | 213 | assembly |
| 4.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 4.1.3 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 4.1.4 | Connector | connector | 10× | 10 | · | part |
| 4.2 | Servo Drive 3 parts | piece-picking-robot-servo-drive | 6× | 6 | 122 | assembly |
| 4.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 4.2.2 | Microcontroller | mcu | 1× | 6 | · | part |
| 4.2.3 | SMD Passive (R/C/L) | smd-passives | 120× | 720 | · | part |
| 4.3 | Cell PLC 4 parts | piece-picking-robot-cell-plc | 1× | 1 | 100 | assembly |
| 4.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.3.3 | Relay | relay | 8× | 8 | · | part |
| 4.3.4 | SMD Passive (R/C/L) | smd-passives | 90× | 90 | · | part |
| 4.4 | Teach Pendant 3 parts | piece-picking-robot-teach-pendant | 1× | 1 | 3 | assembly |
| 4.4.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 4.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4.3 | Enabling Switch | piece-picking-robot-enable-switch | 1× | 1 | · | part |
| 5 | Tote Conveyor 4 parts | piece-picking-robot-conveyor | 1× | 1 | 66 | assembly |
| 5.1 | Infeed Belt 3 parts | piece-picking-robot-infeed-belt | 1× | 1 | 7 | assembly |
| 5.1.1 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 5.1.2 | Belt Roller | piece-picking-robot-belt-roller | 2× | 2 | · | part |
| 5.1.3 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 5.2 | Outfeed Belt 3 parts | piece-picking-robot-outfeed-belt | 1× | 1 | 7 | assembly |
| 5.2.1 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 5.2.2 | Belt Roller | piece-picking-robot-belt-roller | 2× | 2 | · | part |
| 5.2.3 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 5.3 | Belt Motor 2 parts | piece-picking-robot-belt-motor | 2× | 2 | 25 | assembly |
| 5.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 5.3.2 | Helical Gear Pair | gear-pair | 1× | 2 | · | part |
| 5.4 | Tote Stop | piece-picking-robot-tote-stop | 2× | 2 | · | part |
| 6 | Vacuum Unit 4 parts | piece-picking-robot-vacuum-unit | 1× | 1 | 31 | assembly |
| 6.1 | Vacuum Pump 3 parts | piece-picking-robot-vacuum-pump | 1× | 1 | 27 | assembly |
| 6.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.1.2 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 6.1.3 | Pump Vane Set | piece-picking-robot-vane-set | 1× | 1 | · | part |
| 6.2 | Vacuum Reservoir | piece-picking-robot-vacuum-tank | 1× | 1 | · | part |
| 6.3 | Vacuum Valve | piece-picking-robot-vacuum-valve | 2× | 2 | · | part |
| 6.4 | Inlet Filter | piece-picking-robot-filter | 1× | 1 | · | part |
| 7 | Cell Frame 4 parts | piece-picking-robot-frame | 1× | 1 | 9 | assembly |
| 7.1 | Profile Frame | piece-picking-robot-profile-frame | 1× | 1 | · | part |
| 7.2 | Guard Panel | piece-picking-robot-guard-panel | 6× | 6 | · | part |
| 7.3 | Robot Pedestal | piece-picking-robot-pedestal | 1× | 1 | · | part |
| 7.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 8 | Safety Package 4 parts | piece-picking-robot-safety-package | 1× | 1 | 94 | assembly |
| 8.1 | Light Curtain | piece-picking-robot-light-curtain | 1× | 1 | · | part |
| 8.2 | Door Interlock | piece-picking-robot-door-interlock | 2× | 2 | · | part |
| 8.3 | Safety Controller 4 parts | piece-picking-robot-safety-controller | 1× | 1 | 89 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 8.3.3 | Relay | relay | 6× | 6 | · | part |
| 8.3.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 8.4 | Emergency Stop | piece-picking-robot-estop | 2× | 2 | · | part |
| 9 | Electrical Cabinet 5 parts | piece-picking-robot-electrical-cabinet | 1× | 1 | 22 | assembly |
| 9.1 | Cabinet Enclosure | piece-picking-robot-cabinet-enclosure | 1× | 1 | · | part |
| 9.2 | Power Supply | power-supply | 1× | 1 | · | part |
| 9.3 | Breaker Set | piece-picking-robot-breaker-set | 1× | 1 | · | part |
| 9.4 | Cabinet Harness 2 parts | piece-picking-robot-cabinet-harness | 1× | 1 | 17 | assembly |
| 9.4.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 9.4.2 | Connector | connector | 16× | 16 | · | part |
| 9.5 | Cooling Fan | piece-picking-robot-cabinet-fan | 2× | 2 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 5 with this page
Robotic Depalletizer
1,401 parts · shares 5 with this page
Robotic Grinding Cell
1,419 parts · shares 5 with this page
Robotic Palletizing Cell
986 parts · shares 5 with this page
Robotic Sanding Cell
1,464 parts · shares 5 with this page
Sewer Inspection Crawler
236 parts · shares 4 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
845-word article