Humanoid Robot
ProductOverview
The humanoid robot is a bipedal, general-purpose platform designed to operate in spaces built for people: handling objects, walking on flat and uneven ground, and reacting to a changing environment. Forty degrees of freedom across two legs, two arms, two dexterous hands, and an articulated head give it a roughly human range of motion. Perception, planning, and motor control all run on board, so the robot balances and manipulates without external compute.
Construction
The Torso & Chassis is the structural core, an aluminium and CFRP skeleton that carries every limb mount and houses the electronics. Inside it, the AI Compute Module module runs neural-net inference on an AI SoC and discrete GPU with a real-time safety co-processor, while several motor-controller boards close the current loops for the limbs and a perception suite fuses navigation LiDAR and depth cameras. The articulated Head adds binocular cameras, a depth sensor, a far-field microphone array, and pan/tilt neck actuators.
Limb motion comes from the Arm and Leg assemblies, each built around the Frameless Joint Actuator: a frameless BLDC motor, a zero-backlash harmonic reducer, an output encoder, a joint torque sensor for compliant control, and an integrated driver. The legs use higher-torque hip, knee, and ankle variants with dual encoders. At the wrists, the tendon-driven Hand gives five fingers with fingertip tactile sensing, and each Foot carries a six-axis force/torque sensor and a compliant sole for stable footfalls.
Power is supplied by the Power System, a high-density Li-ion pack with battery management, DC-DC conversion, and a fused distribution board. The whole-body Cabling Harness routes power and data from the torso out to every joint and sensor.
Humanoid Robot parts and their functions
8 top-level parts · 3,158 parts in total · full bill of materials below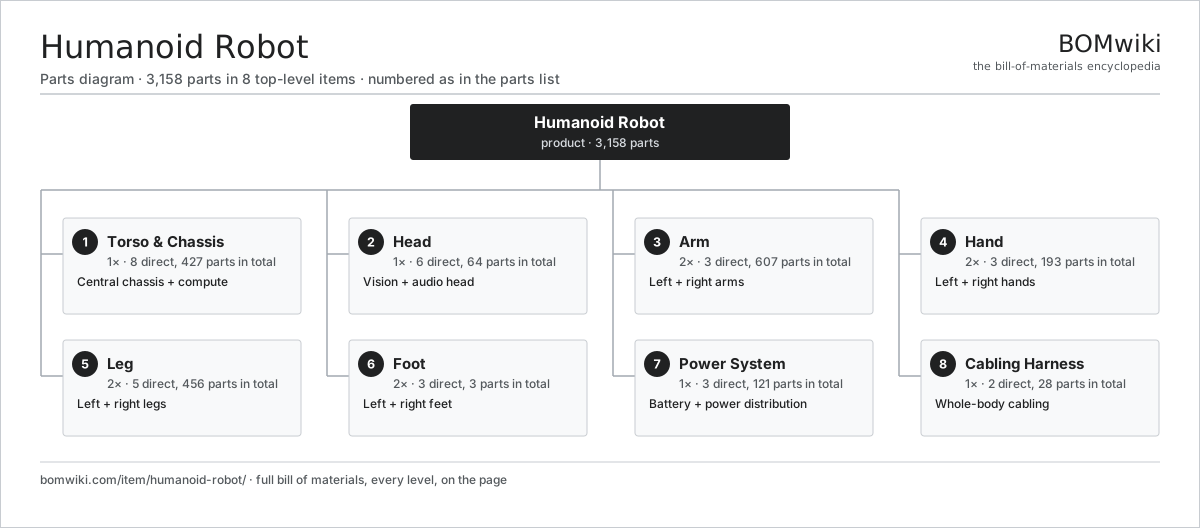
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Torso & Chassis 8 parts | 1× | Central chassis + compute |
| 2 | Head 6 parts | 1× | Vision + audio head |
| 3 | Arm 3 parts | 2× | Left + right arms |
| 4 | Hand 3 parts | 2× | Left + right hands |
| 5 | Leg 5 parts | 2× | Left + right legs |
| 6 | Foot 3 parts | 2× | Left + right feet |
| 7 | Power System 3 parts | 1× | Battery + power distribution |
| 8 | Cabling Harness 2 parts | 1× | Whole-body cabling |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Humanoid Robot
8 top-level lines · 105 rows shown · 3,158 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Torso & Chassis 8 parts | humanoid-robot-torso | 1× | 1 | 427 | assembly |
| 1.1 | Torso Frame | humanoid-robot-torso-frame | 1× | 1 | · | part |
| 1.2 | Cover Panel | humanoid-robot-cover-panel | 6× | 6 | · | part |
| 1.3 | AI Compute Module 5 parts | humanoid-robot-compute | 1× | 1 | 16 | assembly |
| 1.3.1 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 1.3.2 | GPU Accelerator Module | humanoid-robot-gpu-module | 1× | 1 | · | part |
| 1.3.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 1.3.4 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 1.3.5 | Connector | connector | 12× | 12 | · | part |
| 1.4 | Motor Controller Board 5 parts | humanoid-robot-motor-controller | 4× | 4 | 98 | assembly |
| 1.4.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 1.4.2 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 4 | 87 | assembly |
| 1.4.3 | IGBT Power Module | igbt-module | 3× | 12 | · | part |
| 1.4.4 | Microcontroller | mcu | 1× | 4 | · | part |
| 1.4.5 | Connector | connector | 6× | 24 | · | part |
| 1.5 | Perception Sensor Suite 3 parts | humanoid-robot-perception | 1× | 1 | 8 | assembly |
| 1.5.1 | Navigation LiDAR | humanoid-robot-lidar | 1× | 1 | · | part |
| 1.5.2 | Depth Camera 2 parts + deeper › | humanoid-robot-depth-camera | 2× | 2 | 3 | assembly |
| 1.5.3 | IMU (6-axis) | imu | 1× | 1 | · | part |
| 1.6 | Cooling Fan | humanoid-robot-cooling-fan | 2× | 2 | · | part |
| 1.7 | IMU (6-axis) | imu | 1× | 1 | · | part |
| 1.8 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Head 6 parts | humanoid-robot-head | 1× | 1 | 64 | assembly |
| 2.1 | Head Shell | humanoid-robot-head-shell | 1× | 1 | · | part |
| 2.2 | Camera Module 3 parts | camera-module | 2× | 2 | 3 | assembly |
| 2.2.1 | CMOS Image Sensor | image-sensor | 1× | 2 | · | part |
| 2.2.2 | Lens Assembly | camera-lens | 1× | 2 | · | part |
| 2.2.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.3 | Depth Camera 2 parts | humanoid-robot-depth-camera | 1× | 1 | 3 | assembly |
| 2.3.1 | CMOS Image Sensor | image-sensor | 2× | 2 | · | part |
| 2.3.2 | IR Pattern Projector | humanoid-robot-ir-projector | 1× | 1 | · | part |
| 2.4 | Microphone Array | humanoid-robot-mic-array | 1× | 1 | · | part |
| 2.5 | Speaker | speaker | 1× | 1 | · | part |
| 2.6 | Neck Actuator 3 parts | humanoid-robot-neck-actuator | 2× | 2 | 26 | assembly |
| 2.6.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 2.6.2 | Encoder | encoder | 1× | 2 | · | part |
| 2.6.3 | Actuator Housing | humanoid-robot-actuator-housing | 1× | 2 | · | part |
| 3 | Arm 3 parts | humanoid-robot-arm | 2× | 2 | 607 | assembly |
| 3.1 | Frameless Joint Actuator 7 parts | humanoid-robot-joint-actuator | 4× | 8 | 151 | assembly |
| 3.1.1 | Frameless BLDC Motor 5 parts + deeper › | humanoid-robot-frameless-motor | 1× | 8 | 50 | assembly |
| 3.1.2 | Harmonic Reducer 4 parts + deeper › | humanoid-robot-harmonic-reducer | 1× | 8 | 4 | assembly |
| 3.1.3 | Encoder | encoder | 1× | 8 | · | part |
| 3.1.4 | Joint Torque Sensor | humanoid-robot-torque-sensor | 1× | 8 | · | part |
| 3.1.5 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 8 | 87 | assembly |
| 3.1.6 | Power MOSFET | mosfet | 6× | 48 | · | part |
| 3.1.7 | Ball Bearing | ball-bearing | 2× | 16 | · | part |
| 3.2 | Arm Link | humanoid-robot-arm-link | 2× | 4 | · | part |
| 3.3 | Fastener Set | fastener-set | 1× | 2 | · | part |
| 4 | Hand 3 parts | humanoid-robot-hand | 2× | 2 | 193 | assembly |
| 4.1 | Palm Chassis | humanoid-robot-palm | 1× | 2 | · | part |
| 4.2 | Finger 3 parts | humanoid-robot-finger | 5× | 10 | 6 | assembly |
| 4.2.1 | Phalanx Link | humanoid-robot-phalanx | 3× | 30 | · | part |
| 4.2.2 | Tendon Cable | humanoid-robot-tendon | 2× | 20 | · | part |
| 4.2.3 | Tactile Sensor | humanoid-robot-tactile-sensor | 1× | 10 | · | part |
| 4.3 | Finger Actuator 4 parts | humanoid-robot-finger-actuator | 6× | 12 | 27 | assembly |
| 4.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 12 | 24 | assembly |
| 4.3.2 | Helical Gear Pair | gear-pair | 1× | 12 | · | part |
| 4.3.3 | Encoder | encoder | 1× | 12 | · | part |
| 4.3.4 | Actuator Housing | humanoid-robot-actuator-housing | 1× | 12 | · | part |
| 5 | Leg 5 parts | humanoid-robot-leg | 2× | 2 | 456 | assembly |
| 5.1 | Hip Actuator 6 parts | humanoid-robot-hip-actuator | 1× | 2 | 151 | assembly |
| 5.1.1 | Frameless BLDC Motor 5 parts + deeper › | humanoid-robot-frameless-motor | 1× | 2 | 50 | assembly |
| 5.1.2 | Planetary Reducer 3 parts + deeper › | humanoid-robot-planetary-reducer | 1× | 2 | 4 | assembly |
| 5.1.3 | Encoder | encoder | 2× | 4 | · | part |
| 5.1.4 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 2 | 87 | assembly |
| 5.1.5 | Power MOSFET | mosfet | 6× | 12 | · | part |
| 5.1.6 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 5.2 | Knee Actuator 6 parts | humanoid-robot-knee-actuator | 1× | 2 | 151 | assembly |
| 5.2.1 | Frameless BLDC Motor 5 parts + deeper › | humanoid-robot-frameless-motor | 1× | 2 | 50 | assembly |
| 5.2.2 | Harmonic Reducer 4 parts + deeper › | humanoid-robot-harmonic-reducer | 1× | 2 | 4 | assembly |
| 5.2.3 | Encoder | encoder | 2× | 4 | · | part |
| 5.2.4 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 2 | 87 | assembly |
| 5.2.5 | Power MOSFET | mosfet | 6× | 12 | · | part |
| 5.2.6 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 5.3 | Ankle Actuator 6 parts | humanoid-robot-ankle-actuator | 1× | 2 | 151 | assembly |
| 5.3.1 | Frameless BLDC Motor 5 parts + deeper › | humanoid-robot-frameless-motor | 1× | 2 | 50 | assembly |
| 5.3.2 | Harmonic Reducer 4 parts + deeper › | humanoid-robot-harmonic-reducer | 1× | 2 | 4 | assembly |
| 5.3.3 | Encoder | encoder | 2× | 4 | · | part |
| 5.3.4 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 2 | 87 | assembly |
| 5.3.5 | Power MOSFET | mosfet | 6× | 12 | · | part |
| 5.3.6 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 5.4 | Leg Link | humanoid-robot-leg-link | 2× | 4 | · | part |
| 5.5 | Fastener Set | fastener-set | 1× | 2 | · | part |
| 6 | Foot 3 parts | humanoid-robot-foot | 2× | 2 | 3 | assembly |
| 6.1 | Foot Plate | humanoid-robot-foot-plate | 1× | 2 | · | part |
| 6.2 | 6-Axis Force/Torque Sensor | humanoid-robot-ft-sensor | 1× | 2 | · | part |
| 6.3 | Compliant Sole | humanoid-robot-sole | 1× | 2 | · | part |
| 7 | Power System 3 parts | humanoid-robot-power-system | 1× | 1 | 121 | assembly |
| 7.1 | Battery Pack 4 parts | humanoid-robot-battery-pack | 1× | 1 | 99 | assembly |
| 7.1.1 | Li-ion Cell, 21700 | li-cell-21700 | 96× | 96 | · | part |
| 7.1.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 7.1.3 | Pack Housing | humanoid-robot-pack-housing | 1× | 1 | · | part |
| 7.1.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 7.2 | DC-DC Converter 4 parts | humanoid-robot-dcdc | 1× | 1 | 10 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2.2 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 7.2.4 | Connector | connector | 4× | 4 | · | part |
| 7.3 | Power Distribution Board 3 parts | humanoid-robot-pdb | 1× | 1 | 12 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.3.2 | Connector | connector | 10× | 10 | · | part |
| 7.3.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 8 | Cabling Harness 2 parts | humanoid-robot-harness | 1× | 1 | 28 | assembly |
| 8.1 | Wire Bundle | wire-bundle | 4× | 4 | · | part |
| 8.2 | Connector | connector | 24× | 24 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts AGV Mobile Robot
383 parts · shares 7 with this page
 Autonomous Mobile Robot (AMR)
627 parts · shares 6 with this page
 Powered Exoskeleton
744 parts · shares 4 with this page
Security Patrol Robot
582 parts · shares 6 with this page
 Sidewalk Delivery Robot
568 parts · shares 6 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
302-word article