Laser Welding Robot
ProductOverview
A laser welding robot guides a focused laser beam along a joint to weld metal with a narrow, deep fusion zone and very little heat spread into the surrounding part. It is used where weld appearance, speed and low distortion matter: battery trays, transmission components, appliance bodies and stainless assemblies. The six-axis arm carries a process head fed by a process fiber from a fiber laser source, and a vision seam tracker keeps the small spot exactly on the joint.
Laser welding differs from arc and spot welding in how the energy is delivered. Instead of an electric arc or a current pulse, a focused beam concentrates kilowatts of power into a spot a few tenths of a millimetre across. At high power the beam vaporises a keyhole that lets it penetrate deep into the metal, producing a weld several times deeper than it is wide. Because the spot is so small, the robot path and the seam tracking have to be far more accurate than in arc welding, and the whole cell has to contain the beam for safety.
The arm
The arm is a six-axis design built for path accuracy rather than payload. A rigid cast base, three link arms and a hollow wrist carry the lightweight head. The six joints each use a servo motor and a low-backlash strain-wave reducer with an absolute encoder, because any backlash or path wobble shows up directly as a weld that wanders off the seam. The wrist is hollow so the process fiber passes through the centre, protected from snagging and from the tight bends that would damage it.
Fiber laser source
The fiber laser source generates the beam. A bank of pump diodes feeds light through a pump combiner into an ytterbium-doped gain fiber that amplifies it into a high-quality beam at 1070 nm. The diode driver regulates diode current and beam power, and a cold plate carries away the heat. The pump diodes are the wear-limited part of the source, with lifetimes measured in tens of thousands of hours, so the source is built to keep them within a tight temperature band.
Process head
The process head shapes and aims the beam. A collimator turns the diverging fiber output into a parallel beam and a focus lens brings it to a small spot on the joint. Scanning heads add galvo mirrors that steer the spot at high speed, allowing remote welding where the robot holds the head a half-metre back and the mirrors jump the beam from weld to weld faster than the arm could move. A sacrificial cover glass protects the focus lens from spatter, and a head sensor watches cover-glass contamination and back-reflected power so a dirty optic is caught before it cracks the expensive lens.
Fiber delivery
The beam travels from source to head through the fiber delivery. An armored process fiber carries kilowatts of power, terminated in an interlocked connector that disables the laser if the fiber is unseated, and routed along the arm in a fiber chain that keeps it within its minimum bend radius. A fiber bent too tightly leaks power into the cladding and burns, so this routing is treated as critical.
Seam tracking
The laser spot is too small to forgive a joint that has shifted, so the seam tracker is essential, not optional. A line laser profiles the joint just ahead of the weld by triangulation, a vision camera images the joint and the weld pool, and the tracker CPU turns that into path corrections that keep the spot centred on the seam. The same vision can monitor the weld pool for process faults in real time.
Shielding and protecting the optic
The shield system does two jobs. A cross-jet blows an air knife across the head aperture to deflect spatter away from the cover glass, because a single weld can throw enough spatter to fog the optic. A gas nozzle fed through a valve delivers shielding gas to keep air off the molten pool on reactive metals, and a flow sensor confirms the gas is present before the beam fires.
Cooling
The laser dumps a lot of waste heat, so the chiller runs a closed loop. A refrigeration compressor and heat exchanger pull heat from the coolant that a pump circulates through the source and head. Coolant temperature is held tightly because the pump diode wavelength, and so the beam, drifts with temperature.
Control
The robot and laser controller coordinates motion and beam. Its motion CPU runs the path, the beam-on timing and the tracking corrections, commanding one servo drive per axis, and a laser interface commands beam power and ramp in step with the path so the weld starts and ends cleanly. The teach pendant sets paths and beam schedules, and a 24 VDC supply feeds logic and brakes.
Laser safety
A multi-kilowatt beam is a serious eye and skin hazard, and the wavelength is invisible, so the safety enclosure contains it to make the cell Class 1. Laser-rated wall panels absorb or reflect stray beam, a wavelength-filtered viewing window lets the operator watch safely, door interlocks disable the beam the instant the enclosure opens, and a beam leak sensor trips the laser if it detects stray energy on a wall. Emergency stops cut beam and motion together.
Variants and use
Fixed-focus heads on a 2 kW source weld seams and lap joints at moderate speed; scanning heads on a 6 to 8 kW source do remote welding, jumping the spot between many short stitch welds far faster than the arm can travel, which is common on car body and battery assembly. The same robot can switch from welding to laser cutting or brazing by changing the head and schedule. Laser welding is chosen wherever the part needs deep penetration with little distortion, a clean appearance, or weld speeds an arc cannot reach, and where the volume justifies the higher capital cost of the laser source and enclosure.
Laser Welding Robot parts and their functions
9 top-level parts · 1,294 parts in total · full bill of materials below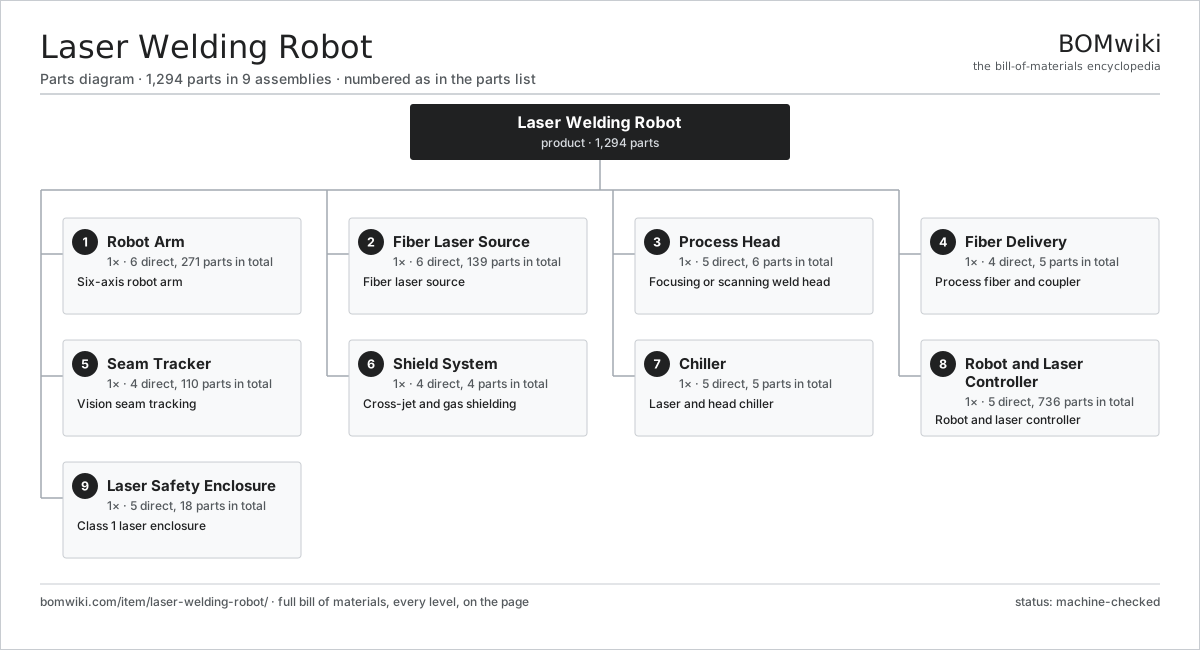
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Robot Arm 6 parts | 1× | Six-axis robot arm |
| 2 | Fiber Laser Source 6 parts | 1× | Fiber laser source |
| 3 | Process Head 5 parts | 1× | Focusing or scanning weld head |
| 4 | Fiber Delivery 4 parts | 1× | Process fiber and coupler |
| 5 | Seam Tracker 4 parts | 1× | Vision seam tracking |
| 6 | Shield System 4 parts | 1× | Cross-jet and gas shielding |
| 7 | Chiller 5 parts | 1× | Laser and head chiller |
| 8 | Robot and Laser Controller 5 parts | 1× | Robot and laser controller |
| 9 | Laser Safety Enclosure 5 parts | 1× | Class 1 laser enclosure |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Laser Welding Robot
9 top-level lines · 81 rows shown · 1,294 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Robot Arm 6 parts | laser-welding-robot-arm | 1× | 1 | 271 | assembly |
| 1.1 | Arm Base | laser-welding-robot-base | 1× | 1 | · | part |
| 1.2 | Axis Joint 5 parts | laser-welding-robot-axis-joint | 6× | 6 | 29 | assembly |
| 1.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 6 | 24 | assembly |
| 1.2.2 | Strain-Wave Reducer | laser-welding-robot-reducer | 1× | 6 | · | part |
| 1.2.3 | Ball Bearing | ball-bearing | 2× | 12 | · | part |
| 1.2.4 | Oil Seal | oil-seal | 1× | 6 | · | part |
| 1.2.5 | Joint Encoder | laser-welding-robot-encoder | 1× | 6 | · | part |
| 1.3 | Link Arm | laser-welding-robot-link | 3× | 3 | · | part |
| 1.4 | Hollow Wrist 3 parts | laser-welding-robot-wrist | 1× | 1 | 91 | assembly |
| 1.4.1 | Axis Joint 5 parts + deeper › | laser-welding-robot-axis-joint | 3× | 3 | 29 | assembly |
| 1.4.2 | Helical Gear Pair | gear-pair | 2× | 2 | · | part |
| 1.4.3 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.5 | Tool Flange | laser-welding-robot-tool-flange | 1× | 1 | · | part |
| 1.6 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 2 | Fiber Laser Source 6 parts | laser-welding-robot-laser-source | 1× | 1 | 139 | assembly |
| 2.1 | Pump Diode Bank | laser-welding-robot-diode-bank | 1× | 1 | · | part |
| 2.2 | Gain Fiber | laser-welding-robot-gain-fiber | 1× | 1 | · | part |
| 2.3 | Pump Combiner | laser-welding-robot-combiner | 1× | 1 | · | part |
| 2.4 | Diode Driver Board 5 parts | laser-welding-robot-driver-board | 1× | 1 | 134 | assembly |
| 2.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 2.4.3 | Power MOSFET | mosfet | 6× | 6 | · | part |
| 2.4.4 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 2.4.5 | Connector | connector | 6× | 6 | · | part |
| 2.5 | Cold Plate | laser-welding-robot-cold-plate | 1× | 1 | · | part |
| 2.6 | Power Supply | power-supply | 1× | 1 | · | part |
| 3 | Process Head 5 parts | laser-welding-robot-process-head | 1× | 1 | 6 | assembly |
| 3.1 | Collimator | laser-welding-robot-collimator | 1× | 1 | · | part |
| 3.2 | Focus Lens | laser-welding-robot-focus-lens | 1× | 1 | · | part |
| 3.3 | Galvo Scan Mirror | laser-welding-robot-scan-mirror | 2× | 2 | · | part |
| 3.4 | Cover Glass | laser-welding-robot-cover-glass | 1× | 1 | · | part |
| 3.5 | Head Sensor | laser-welding-robot-head-sensor | 1× | 1 | · | part |
| 4 | Fiber Delivery 4 parts | laser-welding-robot-fiber-delivery | 1× | 1 | 5 | assembly |
| 4.1 | Process Fiber | laser-welding-robot-process-fiber | 1× | 1 | · | part |
| 4.2 | Fiber Connector | laser-welding-robot-fiber-connector | 1× | 1 | · | part |
| 4.3 | Fiber Routing Chain | laser-welding-robot-fiber-chain | 1× | 1 | · | part |
| 4.4 | Connector | connector | 2× | 2 | · | part |
| 5 | Seam Tracker 4 parts | laser-welding-robot-seam-tracker | 1× | 1 | 110 | assembly |
| 5.1 | Vision Camera | laser-welding-robot-vision-camera | 1× | 1 | · | part |
| 5.2 | Line Laser | laser-welding-robot-line-laser | 1× | 1 | · | part |
| 5.3 | Tracker CPU 4 parts | laser-welding-robot-tracker-cpu | 1× | 1 | 106 | assembly |
| 5.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.3.3 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 5.3.4 | Connector | connector | 4× | 4 | · | part |
| 5.4 | Connector | connector | 2× | 2 | · | part |
| 6 | Shield System 4 parts | laser-welding-robot-shield-system | 1× | 1 | 4 | assembly |
| 6.1 | Cross-Jet | laser-welding-robot-cross-jet | 1× | 1 | · | part |
| 6.2 | Gas Nozzle | laser-welding-robot-gas-nozzle | 1× | 1 | · | part |
| 6.3 | Gas Valve | laser-welding-robot-gas-valve | 1× | 1 | · | part |
| 6.4 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 7 | Chiller 5 parts | laser-welding-robot-chiller | 1× | 1 | 5 | assembly |
| 7.1 | Compressor | laser-welding-robot-compressor | 1× | 1 | · | part |
| 7.2 | Coolant Pump | laser-welding-robot-coolant-pump | 1× | 1 | · | part |
| 7.3 | Heat Exchanger | laser-welding-robot-heat-exchanger | 1× | 1 | · | part |
| 7.4 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 7.5 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 8 | Robot and Laser Controller 5 parts | laser-welding-robot-controller | 1× | 1 | 736 | assembly |
| 8.1 | Motion CPU 4 parts | laser-welding-robot-cpu | 1× | 1 | 193 | assembly |
| 8.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 8.1.3 | SMD Passive (R/C/L) | smd-passives | 180× | 180 | · | part |
| 8.1.4 | Connector | connector | 10× | 10 | · | part |
| 8.2 | Servo Drive 5 parts | laser-welding-robot-servo-drive | 6× | 6 | 90 | assembly |
| 8.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 8.2.2 | Power MOSFET | mosfet | 6× | 36 | · | part |
| 8.2.3 | Gate Driver IC | gate-driver-ic | 1× | 6 | · | part |
| 8.2.4 | DC-Link Capacitor | dc-link-cap | 2× | 12 | · | part |
| 8.2.5 | SMD Passive (R/C/L) | smd-passives | 80× | 480 | · | part |
| 8.3 | Laser Interface | laser-welding-robot-laser-interface | 1× | 1 | · | part |
| 8.4 | Teach Pendant | laser-welding-robot-pendant | 1× | 1 | · | part |
| 8.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 9 | Laser Safety Enclosure 5 parts | laser-welding-robot-safety-enclosure | 1× | 1 | 18 | assembly |
| 9.1 | Enclosure Panel 2 parts | laser-welding-robot-enclosure-panel | 6× | 6 | 2 | assembly |
| 9.1.1 | Sheet Metal Panel | sheet-panel | 1× | 6 | · | part |
| 9.1.2 | Fastener Set | fastener-set | 1× | 6 | · | part |
| 9.2 | Viewing Window | laser-welding-robot-view-window | 1× | 1 | · | part |
| 9.3 | Interlock Switch | laser-welding-robot-interlock-switch | 2× | 2 | · | part |
| 9.4 | Beam Leak Sensor | laser-welding-robot-beam-sensor | 1× | 1 | · | part |
| 9.5 | Emergency Stop | laser-welding-robot-estop | 2× | 2 | · | part |
Related products
same domain, ranked by shared parts Arc Welding Robot
1,532 parts · shares 6 with this page
 Spot Welding Robot
1,295 parts · shares 6 with this page
 Welding Robot Cell
999 parts · shares 5 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
1,268-word article