Robotic Depalletizer
ProductOverview
A robotic depalletizer does the reverse of a palletizer: it takes loaded pallets arriving from a warehouse or a supplier and strips the cases off, layer by layer, onto a conveyor that feeds an unpacking, repacking, or production line. The job is harder than palletizing because the incoming load is not under the machine's control. Pallets arrive with cases shifted in transit, with slip sheets between layers, and sometimes mixed across SKUs, so a depalletizer leans on a 3D Vision System system to see what is actually on the pallet rather than assuming a fixed pattern.
How it works
A full pallet enters on the Pallet Infeed, a heavy roller conveyor that indexes it into the pick position and squares it with a Centering Unit unit so the robot has a known datum. The 3D 3D Vision System head looks down on the top layer, builds a depth map, and segments it into individual cases. From that map the Cell Controller decides the pick: a clean, aligned layer is lifted whole, a shifted or partial layer is taken as rows or single cases. This adaptive pick is what separates a robotic depalletizer from a fixed mechanical one, which can only handle perfectly stacked uniform loads.
The Articulated Robot is a six-axis arm on a Mounting Riser so it can reach both the top of a tall stack and the bottom of an empty pallet. Six axes rather than four are needed here because the tool must tilt and reach into a load that is not always square. Each axis is a Servo Joint of servo motor, low-backlash reducer, absolute encoder, and brake. The arm carries a large Layer-Pick Tool, a layer tool that combines a zoned Vacuum Cup Array gripping the case tops with powered Side Clamp plates that squeeze a layer for a secure lift. The vacuum is switched in zones so the tool grips only the footprint the vision system found, which lets it pick a partial layer without disturbing the rest.
The outfeed
A depalletizer creates a new problem at its output: it sets down a whole layer of cases at once, but the downstream line wants them one at a time. The Case Outfeed solves this. The robot deposits the layer on a Layer Receiver roller table, and a Singulator of diverging belts and a metering gate breaks the layer into a single-file stream on the Outfeed Belt. Getting singulation right matters as much as the pick, since a downstream filler or unpacker can only run as steady as the case stream feeding it.
Empty pallets and slip sheets
As each layer comes off, the robot also handles the slip sheets between layers, usually by switching to a separate small vacuum zone or a sheet gripper, and discards them to a chute. When the pallet is empty the Empty Pallet Stacker takes it: a lift raises each empty under a growing stack held by pawls, and a conveyor moves the finished stack out for removal. Closing this loop is what lets the cell run unattended through a shift, taking full pallets in one side and putting empties out the other.
Materials and construction
The robot links are cast aluminium on a heavy cast-iron base, and the riser is a welded steel pedestal that adds reach without adding arm mass. Joint reducers run in oil behind an Oil Seal. The layer tool frame is welded aluminium spanning a full pallet footprint, kept light because the arm pays for every kilogram of tool weight in payload. The vacuum array uses bellows foam cups that conform to slightly crushed or printed case tops, and a regenerative Vacuum Pump supplies the high flow a leaky case surface demands, unlike the low-flow Venturi a palletizer can use on clean sealed cases. Conveyors are steel roller on internal bearings, sized heavy on the infeed for loaded pallets.
Control, vision, and safety
The Cell Controller cabinet ties together a robot motion controller, one Servo Drive per axis, a cell Cell PLC, and a link to the Vision Compute. The vision computer does the heavy lifting of turning a depth map into pick coordinates, and the robot controller plans a collision-free path into the load. Safety is integral: a Light Curtain guards the pallet openings, an Area Scanner watches the floor, and interlocks on the Guard Fence gate stop the arm when opened, all through a dual-channel safety controller rated to performance level e.
Variants and use
Simple depalletizers for single-SKU uniform loads, like beverage cans, skip the 3D vision and run a taught pattern, which is faster and cheaper. Mixed-case and unstable-load depalletizing, common in distribution and grocery, needs the full vision-guided pick described here and accepts the lower rate that single-case picking sometimes forces. In service the recurring maintenance is the vacuum cups and the singulator belts, both wear items, plus periodic recalibration of the vision head to the robot frame. The robot joints are sealed and run on long oil-change intervals, so the cell's uptime is set mostly by how reliably the incoming pallets are stacked.
Robotic Depalletizer parts and their functions
9 top-level parts · 1,401 parts in total · full bill of materials below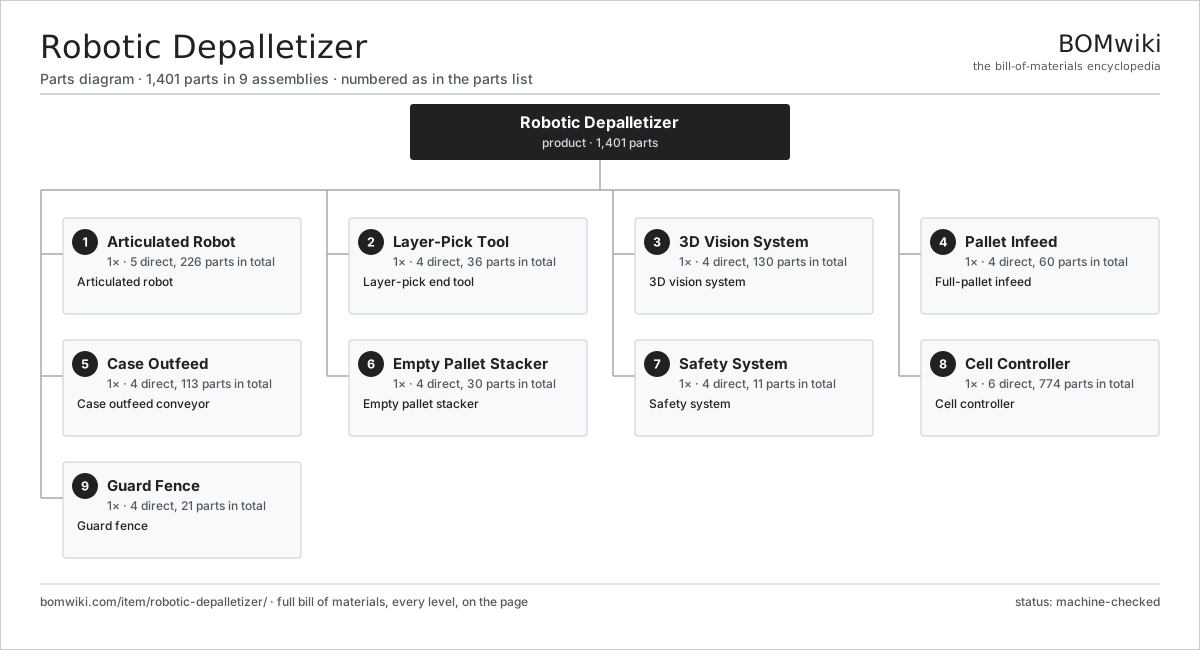
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Articulated Robot 5 parts | 1× | Articulated robot |
| 2 | Layer-Pick Tool 4 parts | 1× | Layer-pick end tool |
| 3 | 3D Vision System 4 parts | 1× | 3D vision system |
| 4 | Pallet Infeed 4 parts | 1× | Full-pallet infeed |
| 5 | Case Outfeed 4 parts | 1× | Case outfeed conveyor |
| 6 | Empty Pallet Stacker 4 parts | 1× | Empty pallet stacker |
| 7 | Safety System 4 parts | 1× | Safety system |
| 8 | Cell Controller 6 parts | 1× | Cell controller |
| 9 | Guard Fence 4 parts | 1× | Guard fence |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Depalletizer
9 top-level lines · 120 rows shown · 1,401 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Articulated Robot 5 parts | robotic-depalletizer-robot | 1× | 1 | 226 | assembly |
| 1.1 | Robot Base 4 parts | robotic-depalletizer-base | 1× | 1 | 4 | assembly |
| 1.1.1 | Base Casting | robotic-depalletizer-base-casting | 1× | 1 | · | part |
| 1.1.2 | Slewing Bearing | robotic-depalletizer-slew-bearing | 1× | 1 | · | part |
| 1.1.3 | Mounting Riser | robotic-depalletizer-riser | 1× | 1 | · | part |
| 1.1.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 1.2 | Arm Link | robotic-depalletizer-arm-link | 3× | 3 | · | part |
| 1.3 | Wrist 3 parts | robotic-depalletizer-wrist | 1× | 1 | 5 | assembly |
| 1.3.1 | Wrist Housing | robotic-depalletizer-wrist-housing | 1× | 1 | · | part |
| 1.3.2 | Tool Flange | robotic-depalletizer-tool-flange | 1× | 1 | · | part |
| 1.3.3 | Ball Bearing | ball-bearing | 3× | 3 | · | part |
| 1.4 | Servo Joint 5 parts | robotic-depalletizer-joint | 6× | 6 | 33 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 6 | 24 | assembly |
| 1.4.2 | Joint Reducer 4 parts + deeper › | robotic-depalletizer-reducer | 1× | 6 | 5 | assembly |
| 1.4.3 | Encoder | encoder | 1× | 6 | · | part |
| 1.4.4 | Holding Brake | robotic-depalletizer-brake | 1× | 6 | · | part |
| 1.4.5 | Ball Bearing | ball-bearing | 2× | 12 | · | part |
| 1.5 | Arm Cabling 3 parts | robotic-depalletizer-cabling | 1× | 1 | 16 | assembly |
| 1.5.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.5.2 | Connector | connector | 14× | 14 | · | part |
| 1.5.3 | Cable Track | robotic-depalletizer-cable-track | 1× | 1 | · | part |
| 2 | Layer-Pick Tool 4 parts | robotic-depalletizer-eoat | 1× | 1 | 36 | assembly |
| 2.1 | Vacuum Cup Array 2 parts | robotic-depalletizer-vacuum-array | 1× | 1 | 30 | assembly |
| 2.1.1 | Suction Cup | robotic-depalletizer-suction-cup | 24× | 24 | · | part |
| 2.1.2 | Zone Valve | robotic-depalletizer-zone-valve | 6× | 6 | · | part |
| 2.2 | Vacuum Pump | robotic-depalletizer-vacuum-pump | 1× | 1 | · | part |
| 2.3 | Side Clamp 2 parts | robotic-depalletizer-side-clamp | 2× | 2 | 2 | assembly |
| 2.3.1 | Clamp Plate | robotic-depalletizer-clamp-plate | 1× | 2 | · | part |
| 2.3.2 | Pneumatic Cylinder | pneumatic-cylinder | 1× | 2 | · | part |
| 2.4 | Tool Frame | robotic-depalletizer-tool-frame | 1× | 1 | · | part |
| 3 | 3D Vision System 4 parts | robotic-depalletizer-vision | 1× | 1 | 130 | assembly |
| 3.1 | 3D Camera Head 3 parts | robotic-depalletizer-3d-camera | 1× | 1 | 5 | assembly |
| 3.1.1 | CMOS Image Sensor | image-sensor | 2× | 2 | · | part |
| 3.1.2 | Lens Assembly | camera-lens | 2× | 2 | · | part |
| 3.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.2 | Structured-Light Projector | robotic-depalletizer-projector | 1× | 1 | · | part |
| 3.3 | Vision Compute 4 parts | robotic-depalletizer-vision-pc | 1× | 1 | 123 | assembly |
| 3.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.3.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 3.3.3 | Power Supply | power-supply | 1× | 1 | · | part |
| 3.3.4 | SMD Passive (R/C/L) | smd-passives | 120× | 120 | · | part |
| 3.4 | Light Ring | robotic-depalletizer-light-ring | 1× | 1 | · | part |
| 4 | Pallet Infeed 4 parts | robotic-depalletizer-pallet-infeed | 1× | 1 | 60 | assembly |
| 4.1 | Pallet Conveyor 3 parts | robotic-depalletizer-pallet-conveyor | 1× | 1 | 31 | assembly |
| 4.1.1 | Heavy Roller | robotic-depalletizer-heavy-roller | 10× | 10 | · | part |
| 4.1.2 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 4.1.3 | Ball Bearing | ball-bearing | 20× | 20 | · | part |
| 4.2 | Centering Unit 2 parts | robotic-depalletizer-centering | 1× | 1 | 4 | assembly |
| 4.2.1 | Centering Plate | robotic-depalletizer-center-plate | 2× | 2 | · | part |
| 4.2.2 | Pneumatic Cylinder | pneumatic-cylinder | 2× | 2 | · | part |
| 4.3 | Index Stop | robotic-depalletizer-stop | 1× | 1 | · | part |
| 4.4 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 4.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 4.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 4.4.3 | Encoder | encoder | 1× | 1 | · | part |
| 4.4.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 5 | Case Outfeed 4 parts | robotic-depalletizer-outfeed | 1× | 1 | 113 | assembly |
| 5.1 | Layer Receiver 3 parts | robotic-depalletizer-layer-receiver | 1× | 1 | 37 | assembly |
| 5.1.1 | Receiver Roller | robotic-depalletizer-receiver-roller | 12× | 12 | · | part |
| 5.1.2 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 5.1.3 | Ball Bearing | ball-bearing | 24× | 24 | · | part |
| 5.2 | Singulator 3 parts | robotic-depalletizer-singulator | 1× | 1 | 27 | assembly |
| 5.2.1 | Diverging Belt | robotic-depalletizer-diverge-belt | 2× | 2 | · | part |
| 5.2.2 | Metering Gate | robotic-depalletizer-gate | 1× | 1 | · | part |
| 5.2.3 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.3 | Outfeed Belt | robotic-depalletizer-outfeed-belt | 1× | 1 | · | part |
| 5.4 | Servo Motor 4 parts | servo-motor | 2× | 2 | 24 | assembly |
| 5.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 5.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 5.4.3 | Encoder | encoder | 1× | 2 | · | part |
| 5.4.4 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 6 | Empty Pallet Stacker 4 parts | robotic-depalletizer-empty-stacker | 1× | 1 | 30 | assembly |
| 6.1 | Stacker Lift | robotic-depalletizer-stacker-lift | 1× | 1 | · | part |
| 6.2 | Stack Pawl | robotic-depalletizer-stacker-pawl | 4× | 4 | · | part |
| 6.3 | Empty Discharge | robotic-depalletizer-stacker-conveyor | 1× | 1 | · | part |
| 6.4 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 6.4.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 6.4.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 6.4.3 | Encoder | encoder | 1× | 1 | · | part |
| 6.4.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 7 | Safety System 4 parts | robotic-depalletizer-safety | 1× | 1 | 11 | assembly |
| 7.1 | Light Curtain 3 parts | robotic-depalletizer-light-curtain | 2× | 2 | 3 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 7.1.2 | Emitter Bar | robotic-depalletizer-emitter-bar | 1× | 2 | · | part |
| 7.1.3 | Receiver Bar | robotic-depalletizer-receiver-bar | 1× | 2 | · | part |
| 7.2 | Area Scanner | robotic-depalletizer-area-scanner | 1× | 1 | · | part |
| 7.3 | Safety Controller | robotic-depalletizer-safety-relay | 1× | 1 | · | part |
| 7.4 | E-Stop Station | robotic-depalletizer-estop | 3× | 3 | · | part |
| 8 | Cell Controller 6 parts | robotic-depalletizer-controller | 1× | 1 | 774 | assembly |
| 8.1 | Robot Controller 5 parts | robotic-depalletizer-robot-controller | 1× | 1 | 235 | assembly |
| 8.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 8.1.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.1.4 | SMD Passive (R/C/L) | smd-passives | 220× | 220 | · | part |
| 8.1.5 | Connector | connector | 12× | 12 | · | part |
| 8.2 | Servo Drive 4 parts | robotic-depalletizer-servo-drive | 6× | 6 | 85 | assembly |
| 8.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 8.2.2 | IGBT Power Module | igbt-module | 1× | 6 | · | part |
| 8.2.3 | SMD Passive (R/C/L) | smd-passives | 80× | 480 | · | part |
| 8.2.4 | Connector | connector | 3× | 18 | · | part |
| 8.3 | Cell PLC 4 parts | robotic-depalletizer-plc | 1× | 1 | 23 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 8.3.3 | Relay | relay | 8× | 8 | · | part |
| 8.3.4 | Connector | connector | 12× | 12 | · | part |
| 8.4 | Operator HMI 4 parts | robotic-depalletizer-hmi | 1× | 1 | 4 | assembly |
| 8.4.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.4.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.4.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 8.6 | Cabinet Shell | robotic-depalletizer-cabinet-shell | 1× | 1 | · | part |
| 9 | Guard Fence 4 parts | robotic-depalletizer-fence | 1× | 1 | 21 | assembly |
| 9.1 | Mesh Panel | robotic-depalletizer-mesh-panel | 8× | 8 | · | part |
| 9.2 | Fence Post | robotic-depalletizer-post | 8× | 8 | · | part |
| 9.3 | Access Gate 3 parts | robotic-depalletizer-access-gate | 1× | 1 | 4 | assembly |
| 9.3.1 | Gate Frame | robotic-depalletizer-gate-frame | 1× | 1 | · | part |
| 9.3.2 | Gate Interlock | robotic-depalletizer-interlock | 1× | 1 | · | part |
| 9.3.3 | Hinge | hinge | 2× | 2 | · | part |
| 9.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Robotic Case Erector
799 parts · shares 9 with this page
Robotic Screwdriving Cell
2,109 parts · shares 8 with this page
 Robotic Assembly Cell
1,746 parts · shares 10 with this page
Machine Tending Robot
1,174 parts · shares 4 with this page
Robotic Grinding Cell
1,419 parts · shares 8 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
893-word article