Pick-and-Place Robot
ProductOverview
A pick-and-place robot moves parts from one fixed location to another, over and over, faster and more consistently than a person can. It is the workhorse of a production line: feeding parts into a machine, taking finished pieces out, transferring components between conveyors, or loading a tray. This unit is a SCARA, short for Selective Compliance Assembly Robot Arm, a layout chosen because it is rigid in the vertical direction and quick in the horizontal plane, which is exactly the motion most transfer tasks need. Four axes give it everything it requires: two horizontal rotary joints to reach any point in a circle, a vertical lift to dip down and pick up, and a tool rotation to set the part down at the right angle.
How it works
The arm has two horizontal links. The Inner Link Casting swings on the Shoulder Joint at the shoulder, and the Outer Link Casting swings on the Elbow Joint at the elbow. Together these two rotations let the tool reach any X-Y position inside the working circle. Both joints use the same building blocks: a Servo Motor driving a Strain-Wave Reducer strain-wave gearbox, which multiplies torque and removes backlash, with an Absolute Encoder reading the angle. The reducer matters because it is what gives a SCARA its accuracy: the Wave Generator flexes a thin steel cup against an outer ring, and the small tooth mismatch produces a large reduction with no measurable play.
At the tip of the outer link sits the Z and Theta Axis. This is the clever part of a SCARA: a single Ball-Spline Shaft shaft both slides up and down and rotates, so one shaft does the work of two axes. A Ball Screw driven by one servo lifts the shaft, and a second servo spins it through a timing belt for tool rotation. The whole vertical assembly is compact and light, which is what lets the arm cycle in well under half a second.
End effector
The shaft ends in a Vacuum Gripper, a vacuum gripper. Most pick-and-place work handles flat or smooth parts, so suction is faster and gentler than mechanical fingers. A Venturi Ejector turns compressed air into a vacuum with no moving parts, and the Suction Cup bellows conform to the part and seal against it. A Vacuum Sensor confirms the part is actually held before the arm moves, so a dropped or missed part is caught immediately rather than discovered at the place location. The tool mounts on a Tool Plate that can be swapped for a different gripper when the line changes product.
Control and sensing
All four axes are coordinated by the Motion Controller. Its Controller CPU Board generates the trajectory, blending the joint moves so the tool follows a smooth path rather than stopping at each axis in turn, and a Servo Drive for each motor closes the current and velocity loops. The robot does not decide on its own when a part has arrived; that comes from the Part-Present Sensing module, a set of Photoelectric Sensor beams that tell the controller a part is at the pick point and the place point is clear. This keeps the robot in step with the conveyors around it.
Air and structure
The gripper and any clamps run on filtered shop air conditioned by the Pneumatics Module module. A Filter-Regulator dries and regulates the supply, and a Solenoid Valve Manifold switches air to the venturi on demand. The arm bolts to a Base Frame, a cast pedestal heavy enough to absorb the inertia of fast moves without shaking. Power, feedback, and air all travel through the Internal Cabling, a continuous-flex bundle guided by a hinged carrier so the wiring survives millions of cycles without fatigue.
Materials and variants
The link castings are aluminium, ribbed for stiffness without mass, while the base is cast iron for weight where weight helps. Reducer flexsplines are alloy steel, and the suction cups are nitrile or silicone depending on whether the parts are oily. SCARAs are sold across a range of reaches, from about 300 mm for small electronics work to over 1000 mm for larger assembly, and the payload scales with the joint and reducer sizes. Cleanroom variants seal the joints and route the cabling internally, and food-grade versions use stainless covers and washdown-rated seals. Where parts are not flat or are presented at random, the photoelectric trigger is replaced by a camera, but the arm and its motion stay the same.
Use
Pick-and-place SCARAs dominate electronics assembly, packaging, and machine tending, anywhere the same short transfer repeats thousands of times an hour. They are valued less for flexibility than for speed and accuracy on a fixed task, and a single arm often pays for itself by replacing a repetitive manual station that is hard to staff. Programming is straightforward: an operator teaches the pick point, the place point, and the heights, and the controller handles the path between them.
Pick-and-Place Robot parts and their functions
8 top-level parts · 838 parts in total · full bill of materials below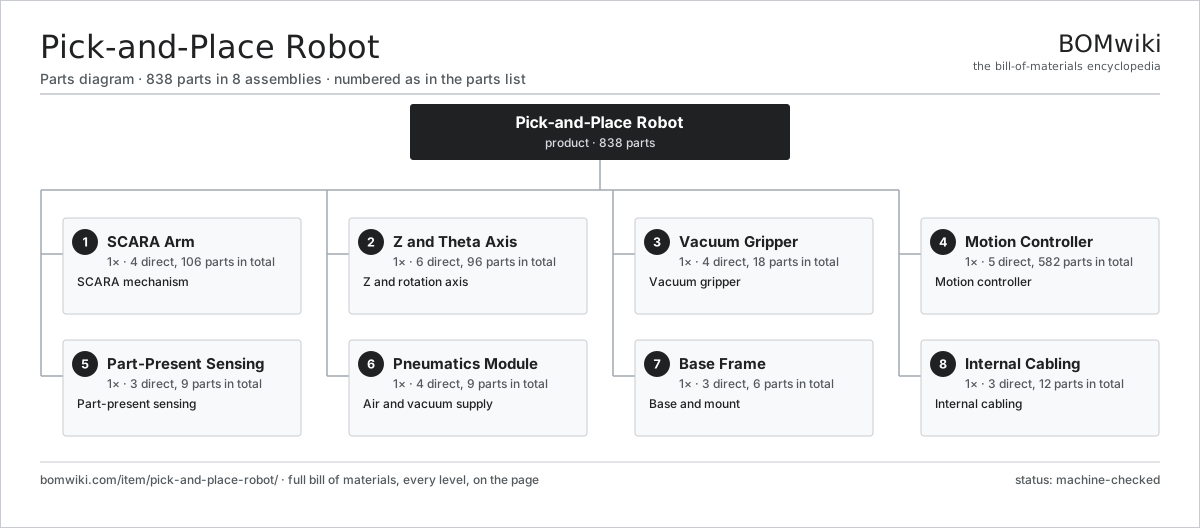
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | SCARA Arm 4 parts | 1× | SCARA mechanism |
| 2 | Z and Theta Axis 6 parts | 1× | Z and rotation axis |
| 3 | Vacuum Gripper 4 parts | 1× | Vacuum gripper |
| 4 | Motion Controller 5 parts | 1× | Motion controller |
| 5 | Part-Present Sensing 3 parts | 1× | Part-present sensing |
| 6 | Pneumatics Module 4 parts | 1× | Air and vacuum supply |
| 7 | Base Frame 3 parts | 1× | Base and mount |
| 8 | Internal Cabling 3 parts | 1× | Internal cabling |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Pick-and-Place Robot
8 top-level lines · 73 rows shown · 838 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | SCARA Arm 4 parts | pick-and-place-robot-scara-arm | 1× | 1 | 106 | assembly |
| 1.1 | Inner Link Casting | pick-and-place-robot-link1 | 1× | 1 | · | part |
| 1.2 | Outer Link Casting | pick-and-place-robot-link2 | 1× | 1 | · | part |
| 1.3 | Shoulder Joint 4 parts | pick-and-place-robot-j1-joint | 1× | 1 | 52 | assembly |
| 1.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.3.2 | Strain-Wave Reducer 4 parts + deeper › | pick-and-place-robot-reducer | 1× | 1 | 5 | assembly |
| 1.3.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.3.4 | Absolute Encoder 2 parts + deeper › | pick-and-place-robot-encoder | 1× | 1 | 21 | assembly |
| 1.4 | Elbow Joint 4 parts | pick-and-place-robot-j2-joint | 1× | 1 | 52 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.4.2 | Strain-Wave Reducer 4 parts + deeper › | pick-and-place-robot-reducer | 1× | 1 | 5 | assembly |
| 1.4.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.4.4 | Absolute Encoder 2 parts + deeper › | pick-and-place-robot-encoder | 1× | 1 | 21 | assembly |
| 2 | Z and Theta Axis 6 parts | pick-and-place-robot-z-theta-axis | 1× | 1 | 96 | assembly |
| 2.1 | Ball-Spline Shaft | pick-and-place-robot-ball-spline | 1× | 1 | · | part |
| 2.2 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 2.3 | Servo Motor 4 parts | servo-motor | 2× | 2 | 24 | assembly |
| 2.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 2 | 3 | assembly |
| 2.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 2 | 19 | assembly |
| 2.3.3 | Encoder | encoder | 1× | 2 | · | part |
| 2.3.4 | Motor Housing | motor-housing | 1× | 2 | · | part |
| 2.4 | Drive Belt | drive-belt | 2× | 2 | · | part |
| 2.5 | Absolute Encoder 2 parts | pick-and-place-robot-encoder | 2× | 2 | 21 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 2.5.2 | SMD Passive (R/C/L) | smd-passives | 20× | 40 | · | part |
| 2.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3 | Vacuum Gripper 4 parts | pick-and-place-robot-end-effector | 1× | 1 | 18 | assembly |
| 3.1 | Suction Cup | pick-and-place-robot-suction-cup | 2× | 2 | · | part |
| 3.2 | Venturi Ejector | pick-and-place-robot-venturi | 1× | 1 | · | part |
| 3.3 | Vacuum Sensor 3 parts | pick-and-place-robot-vacuum-sensor | 1× | 1 | 14 | assembly |
| 3.3.1 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 3.3.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.3.3 | SMD Passive (R/C/L) | smd-passives | 12× | 12 | · | part |
| 3.4 | Tool Plate | pick-and-place-robot-tool-plate | 1× | 1 | · | part |
| 4 | Motion Controller 5 parts | pick-and-place-robot-controller | 1× | 1 | 582 | assembly |
| 4.1 | Controller CPU Board 4 parts | pick-and-place-robot-cpu-board | 1× | 1 | 191 | assembly |
| 4.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 4.1.3 | SMD Passive (R/C/L) | smd-passives | 180× | 180 | · | part |
| 4.1.4 | Connector | connector | 8× | 8 | · | part |
| 4.2 | Servo Drive 5 parts | pick-and-place-robot-servo-drive | 4× | 4 | 81 | assembly |
| 4.2.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 4.2.2 | Power MOSFET | mosfet | 6× | 24 | · | part |
| 4.2.3 | Gate Driver IC | gate-driver-ic | 1× | 4 | · | part |
| 4.2.4 | SMD Passive (R/C/L) | smd-passives | 70× | 280 | · | part |
| 4.2.5 | Connector | connector | 3× | 12 | · | part |
| 4.3 | Power Supply | power-supply | 1× | 1 | · | part |
| 4.4 | Digital I/O Board 4 parts | pick-and-place-robot-io-board | 1× | 1 | 65 | assembly |
| 4.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4.2 | Relay | relay | 8× | 8 | · | part |
| 4.4.3 | Connector | connector | 6× | 6 | · | part |
| 4.4.4 | SMD Passive (R/C/L) | smd-passives | 50× | 50 | · | part |
| 4.5 | Control Enclosure | pick-and-place-robot-control-enclosure | 1× | 1 | · | part |
| 5 | Part-Present Sensing 3 parts | pick-and-place-robot-vision-trigger | 1× | 1 | 9 | assembly |
| 5.1 | Photoelectric Sensor | pick-and-place-robot-photo-sensor | 3× | 3 | · | part |
| 5.2 | Sensor Bracket | pick-and-place-robot-sensor-bracket | 3× | 3 | · | part |
| 5.3 | Connector | connector | 3× | 3 | · | part |
| 6 | Pneumatics Module 4 parts | pick-and-place-robot-pneumatics | 1× | 1 | 9 | assembly |
| 6.1 | Filter-Regulator | pick-and-place-robot-fr-unit | 1× | 1 | · | part |
| 6.2 | Solenoid Valve Manifold 3 parts | pick-and-place-robot-valve-manifold | 1× | 1 | 6 | assembly |
| 6.2.1 | Solenoid Valve | pick-and-place-robot-solenoid-valve | 4× | 4 | · | part |
| 6.2.2 | Manifold Block | pick-and-place-robot-manifold-block | 1× | 1 | · | part |
| 6.2.3 | Connector | connector | 1× | 1 | · | part |
| 6.3 | Air Tubing Set | pick-and-place-robot-air-tubing | 1× | 1 | · | part |
| 6.4 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 7 | Base Frame 3 parts | pick-and-place-robot-base-frame | 1× | 1 | 6 | assembly |
| 7.1 | Base Casting | pick-and-place-robot-base-casting | 1× | 1 | · | part |
| 7.2 | Leveling Foot | pick-and-place-robot-leveling-foot | 4× | 4 | · | part |
| 7.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 8 | Internal Cabling 3 parts | pick-and-place-robot-cabling | 1× | 1 | 12 | assembly |
| 8.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 8.2 | Connector | connector | 10× | 10 | · | part |
| 8.3 | Cable Carrier | pick-and-place-robot-cable-carrier | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 6 with this page
Robotic Grinding Cell
1,419 parts · shares 6 with this page
 Vision-Guided Robot
1,735 parts · shares 6 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
918-word article