Delta Pick-and-Place Robot
ProductOverview
The delta robot is a parallel-kinematic manipulator built for high-speed pick-and-place: sorting, packing, and feeding small parts moving on a conveyor. Three arms hang from an overhead platform at 120° spacing, and because the heavy servo motors stay fixed on the frame, only the light arms and end plate move. That low moving mass is what lets a delta reach accelerations many times gravity and sustain well over a hundred picks per minute. A central fourth axis adds tool rotation, and an overhead vision system locates parts on the belt so the robot can track and grip them on the fly.
How it works
Each of the three Drive Actuator units mounts on the Fixed Base Plate and pairs an AC servo with a low-backlash planetary gearbox, an absolute encoder, and a holding brake. Each actuator swings a rigid Upper Arm Link, which connects through a Lower Arm Parallelogram parallelogram of carbon-fibre rods on spherical ball joints to the moving end plate. The parallelogram geometry keeps the Traveling Platform level at all times, so the controller only has to solve for position. The Fourth Axis Drive runs a telescoping spline shaft down the center to spin the tool independently of the arms.
The Vacuum Gripper is a vacuum gripper with a Venturi ejector, fast solenoid valve, suction cups, and a vacuum sensor that confirms each grip. Part positions come from the Vision System, which combines an overhead camera, ring light, and a conveyor encoder so the robot can track moving parts. All four axes are commanded by the Controller Cabinet cabinet, which houses the motion CPU, servo drives, power supply, and a dual-channel safety module. The whole robot hangs over the line on the Mounting Gantry.
Delta Pick-and-Place Robot parts and their functions
12 top-level parts · 579 parts in total · full bill of materials below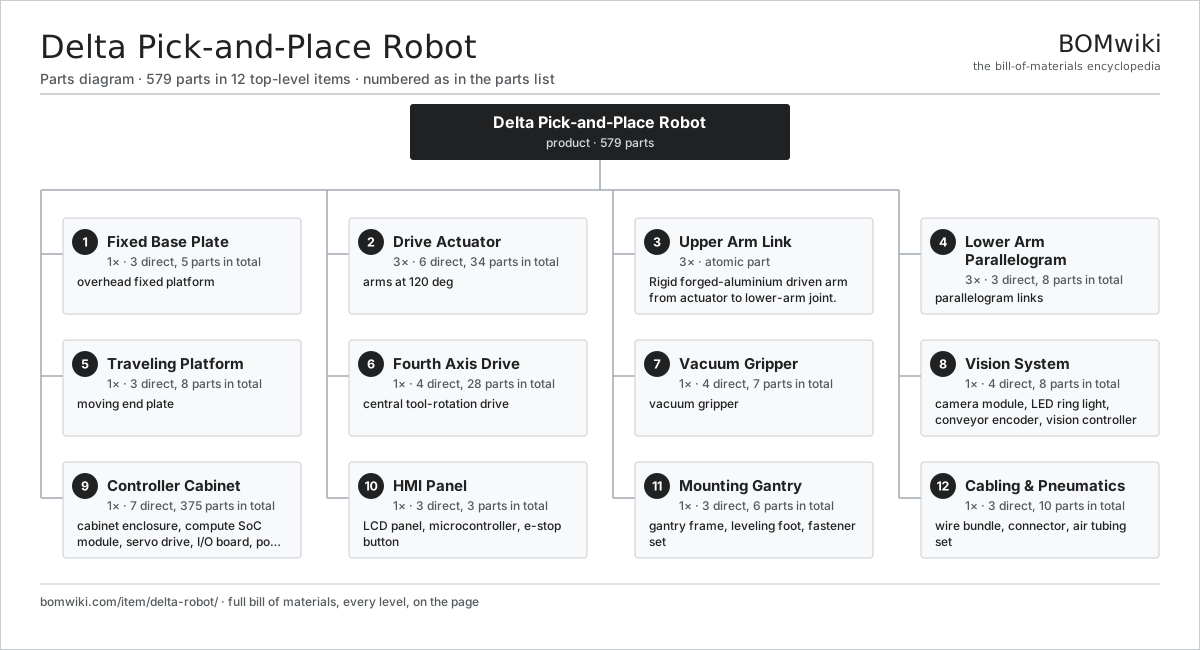
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Fixed Base Plate 3 parts | 1× | overhead fixed platform |
| 2 | Drive Actuator 6 parts | 3× | arms at 120 deg |
| 3 | Upper Arm Link | 3× | Rigid forged-aluminium driven arm from actuator to lower-arm joint. |
| 4 | Lower Arm Parallelogram 3 parts | 3× | parallelogram links |
| 5 | Traveling Platform 3 parts | 1× | moving end plate |
| 6 | Fourth Axis Drive 4 parts | 1× | central tool-rotation drive |
| 7 | Vacuum Gripper 4 parts | 1× | vacuum gripper |
| 8 | Vision System 4 parts | 1× | Overhead camera, lighting and conveyor encoder feeding part positions to the controller. |
| 9 | Controller Cabinet 7 parts | 1× | Floor cabinet with motion CPU, four servo drives, I/O, power and safety. |
| 10 | HMI Panel 3 parts | 1× | Touchscreen operator panel for setup, jogging and diagnostics. |
| 11 | Mounting Gantry 3 parts | 1× | Welded steel frame suspending the robot over the conveyor. |
| 12 | Cabling & Pneumatics 3 parts | 1× | Motor, encoder and air runs between cabinet, robot and tool. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Delta Pick-and-Place Robot
12 top-level lines · 80 rows shown · 579 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Fixed Base Plate 3 parts | delta-robot-base-frame | 1× | 1 | 5 | assembly |
| 1.1 | Base Casting | delta-robot-base-casting | 1× | 1 | · | part |
| 1.2 | Actuator Mount Bracket | delta-robot-actuator-mount | 3× | 3 | · | part |
| 1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Drive Actuator 6 parts | delta-robot-drive-actuator | 3× | 3 | 34 | assembly |
| 2.1 | Servo Motor 4 parts | servo-motor | 1× | 3 | 24 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 3 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 3 | 19 | assembly |
| 2.1.3 | Encoder | encoder | 1× | 3 | · | part |
| 2.1.4 | Motor Housing | motor-housing | 1× | 3 | · | part |
| 2.2 | Planetary Gearbox 4 parts | delta-robot-actuator-gearbox | 1× | 3 | 5 | assembly |
| 2.2.1 | Gearbox Housing | gearbox-housing | 1× | 3 | · | part |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 3 | · | part |
| 2.2.3 | Ball Bearing | ball-bearing | 2× | 6 | · | part |
| 2.2.4 | O-Ring Set | oring-set | 1× | 3 | · | part |
| 2.3 | Encoder | encoder | 1× | 3 | · | part |
| 2.4 | Holding Brake | delta-robot-holding-brake | 1× | 3 | · | part |
| 2.5 | Ball Bearing | ball-bearing | 2× | 6 | · | part |
| 2.6 | Fastener Set | fastener-set | 1× | 3 | · | part |
| 3 | Upper Arm Link | delta-robot-upper-arm | 3× | 3 | · | part |
| 4 | Lower Arm Parallelogram 3 parts | delta-robot-lower-arm | 3× | 3 | 8 | assembly |
| 4.1 | Carbon-Fibre Rod | delta-robot-carbon-rod | 2× | 6 | · | part |
| 4.2 | Spherical Ball Joint | delta-robot-ball-joint | 4× | 12 | · | part |
| 4.3 | Tension Spring | delta-robot-tension-spring | 2× | 6 | · | part |
| 5 | Traveling Platform 3 parts | delta-robot-traveling-platform | 1× | 1 | 8 | assembly |
| 5.1 | Platform Plate | delta-robot-platform-plate | 1× | 1 | · | part |
| 5.2 | Spherical Ball Joint | delta-robot-ball-joint | 6× | 6 | · | part |
| 5.3 | Tool Interface Flange | delta-robot-tool-interface | 1× | 1 | · | part |
| 6 | Fourth Axis Drive 4 parts | delta-robot-fourth-axis | 1× | 1 | 28 | assembly |
| 6.1 | Servo Motor 4 parts | servo-motor | 1× | 1 | 24 | assembly |
| 6.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 6.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 6.1.3 | Encoder | encoder | 1× | 1 | · | part |
| 6.1.4 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 6.2 | Telescoping Spline Shaft | delta-robot-telescoping-spline | 1× | 1 | · | part |
| 6.3 | Universal Joint | delta-robot-universal-joint | 2× | 2 | · | part |
| 6.4 | Encoder | encoder | 1× | 1 | · | part |
| 7 | Vacuum Gripper 4 parts | delta-robot-end-effector | 1× | 1 | 7 | assembly |
| 7.1 | Vacuum Ejector | delta-robot-vacuum-ejector | 1× | 1 | · | part |
| 7.2 | Vacuum Solenoid Valve | delta-robot-vacuum-valve | 1× | 1 | · | part |
| 7.3 | Suction Cup | delta-robot-suction-cup | 4× | 4 | · | part |
| 7.4 | Vacuum Sensor | delta-robot-vacuum-sensor | 1× | 1 | · | part |
| 8 | Vision System 4 parts | delta-robot-vision-system | 1× | 1 | 8 | assembly |
| 8.1 | Camera Module 3 parts | camera-module | 1× | 1 | 3 | assembly |
| 8.1.1 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 8.1.2 | Lens Assembly | camera-lens | 1× | 1 | · | part |
| 8.1.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2 | LED Ring Light | delta-robot-ring-light | 1× | 1 | · | part |
| 8.3 | Conveyor Encoder | delta-robot-conveyor-encoder | 1× | 1 | · | part |
| 8.4 | Vision Controller 3 parts | delta-robot-vision-controller | 1× | 1 | 3 | assembly |
| 8.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.4.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 8.4.3 | I/O Board | io-board | 1× | 1 | · | part |
| 9 | Controller Cabinet 7 parts | delta-robot-controller | 1× | 1 | 375 | assembly |
| 9.1 | Cabinet Enclosure | delta-robot-cabinet-enclosure | 1× | 1 | · | part |
| 9.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 9.3 | Servo Drive 4 parts | servo-drive | 4× | 4 | 91 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 9.3.2 | IGBT Power Module | igbt-module | 1× | 4 | · | part |
| 9.3.3 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 4 | 87 | assembly |
| 9.3.4 | DC-Link Capacitor | dc-link-cap | 2× | 8 | · | part |
| 9.4 | I/O Board | io-board | 1× | 1 | · | part |
| 9.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 9.6 | Safety Module 3 parts | delta-robot-safety-module | 1× | 1 | 6 | assembly |
| 9.6.1 | I/O Board | io-board | 1× | 1 | · | part |
| 9.6.2 | Safety Relay | delta-robot-safety-relay | 1× | 1 | · | part |
| 9.6.3 | Connector | connector | 4× | 4 | · | part |
| 9.7 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 10 | HMI Panel 3 parts | delta-robot-hmi | 1× | 1 | 3 | assembly |
| 10.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 10.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 10.3 | E-Stop Button | delta-robot-estop-button | 1× | 1 | · | part |
| 11 | Mounting Gantry 3 parts | delta-robot-mounting-gantry | 1× | 1 | 6 | assembly |
| 11.1 | Gantry Frame | delta-robot-gantry-frame | 1× | 1 | · | part |
| 11.2 | Leveling Foot | delta-robot-leveling-foot | 4× | 4 | · | part |
| 11.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 12 | Cabling & Pneumatics 3 parts | delta-robot-cabling | 1× | 1 | 10 | assembly |
| 12.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 12.2 | Connector | connector | 8× | 8 | · | part |
| 12.3 | Air Tubing Set | delta-robot-air-tubing | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Welding Robot Cell
999 parts · shares 10 with this page
 6-Axis Industrial Robot Arm
814 parts · shares 8 with this page
 SCARA Robot
519 parts · shares 8 with this page
 Humanoid Robot
3,158 parts · shares 6 with this page
 AGV Mobile Robot
383 parts · shares 6 with this page
Gantry Loading Robot
800 parts · shares 5 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
309-word article