Palletizing Robot
ProductOverview
A palletizing robot is an articulated arm that stacks finished cases, cartons, bags, or trays onto pallets at the discharge of a packaging or filling line. It is purpose-built for one motion: pick a unit load from an infeed conveyor and place it accurately onto a growing pallet stack, then repeat hundreds of times an hour. Because that task only needs the tool kept level and rotated to a programmed orientation, the arm uses four axes rather than the six of a general manipulator. A Parallelogram Link parallelogram linkage ties the upper-arm motion to the wrist, so the Wrist stays horizontal automatically and the fourth axis only has to spin the load to the right angle.
How it works
The arm is a chain of cast links, Base & Turntable, lower arm, upper arm, and wrist, each driven by an identical Servo Joint. Every joint pairs an AC AC Servo Motor with a near-zero-backlash Harmonic Reducer (a strain-wave gearbox), an absolute encoder for position feedback, and a spring-applied brake that locks the axis when power is removed. A Servo Drive amplifier closes the current and velocity loops for each axis. A Spring Balancer on the lower arm offsets gravity so the J2 motor can be sized for acceleration rather than holding torque, which is what lets a mid-size arm move a 180 kg load quickly.
The end effector, the EOAT Gripper, is matched to the product. Zoned vacuum cups handle sealed cases and trays, while pneumatic side clamps grip open trays or layers of bags; a Venturi generator makes the vacuum from shop compressed air. The Controller Cabinet cabinet holds the motion compute, one servo drive per axis, field I/O, and a safety relay; it plans each trajectory, sequences the gripper, and coordinates with the conveyor. An operator builds and edits stacking patterns from the Teach Pendant, a rugged touchscreen with an emergency stop and enabling switch. Power, feedback, and tool air run through the Dress-Out Cabling energy chain that flexes with the arm so nothing snags as it cycles between the infeed and the pallet.
Palletizing Robot parts and their functions
9 top-level parts · 1,289 parts in total · full bill of materials below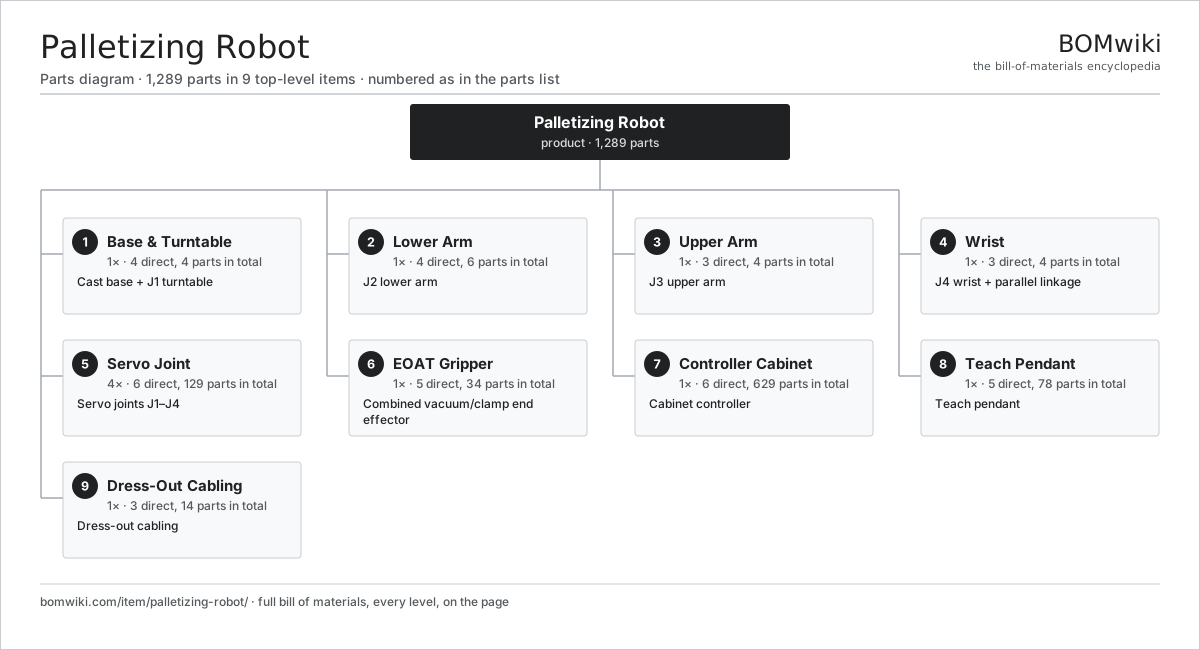
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Base & Turntable 4 parts | 1× | Cast base + J1 turntable |
| 2 | Lower Arm 4 parts | 1× | J2 lower arm |
| 3 | Upper Arm 3 parts | 1× | J3 upper arm |
| 4 | Wrist 3 parts | 1× | J4 wrist + parallel linkage |
| 5 | Servo Joint 6 parts | 4× | Servo joints J1–J4 |
| 6 | EOAT Gripper 5 parts | 1× | Combined vacuum/clamp end effector |
| 7 | Controller Cabinet 6 parts | 1× | Cabinet controller |
| 8 | Teach Pendant 5 parts | 1× | Teach pendant |
| 9 | Dress-Out Cabling 3 parts | 1× | Dress-out cabling |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Palletizing Robot
9 top-level lines · 85 rows shown · 1,289 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Base & Turntable 4 parts | palletizing-robot-base | 1× | 1 | 4 | assembly |
| 1.1 | Base Casting | palletizing-robot-base-casting | 1× | 1 | · | part |
| 1.2 | Turntable Column | palletizing-robot-turntable | 1× | 1 | · | part |
| 1.3 | Slewing Bearing | palletizing-robot-slew-bearing | 1× | 1 | · | part |
| 1.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Lower Arm 4 parts | palletizing-robot-lower-arm | 1× | 1 | 6 | assembly |
| 2.1 | Lower Arm Casting | palletizing-robot-lower-casting | 1× | 1 | · | part |
| 2.2 | Parallelogram Link | palletizing-robot-parallel-link | 1× | 1 | · | part |
| 2.3 | Spring Balancer 2 parts | palletizing-robot-balancer | 1× | 1 | 2 | assembly |
| 2.3.1 | Balancer Cylinder | palletizing-robot-balancer-cylinder | 1× | 1 | · | part |
| 2.3.2 | Balancer Spring | palletizing-robot-balancer-spring | 1× | 1 | · | part |
| 2.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3 | Upper Arm 3 parts | palletizing-robot-upper-arm | 1× | 1 | 4 | assembly |
| 3.1 | Upper Arm Casting | palletizing-robot-upper-casting | 1× | 1 | · | part |
| 3.2 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 4 | Wrist 3 parts | palletizing-robot-wrist | 1× | 1 | 4 | assembly |
| 4.1 | Wrist Housing | palletizing-robot-wrist-housing | 1× | 1 | · | part |
| 4.2 | Tool Flange | palletizing-robot-wrist-flange | 1× | 1 | · | part |
| 4.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 5 | Servo Joint 6 parts | palletizing-robot-joint | 4× | 4 | 129 | assembly |
| 5.1 | AC Servo Motor 5 parts | palletizing-robot-servo-motor | 1× | 4 | 32 | assembly |
| 5.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 4 | 3 | assembly |
| 5.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 4 | 19 | assembly |
| 5.1.3 | Copper Winding | copper-winding | 1× | 4 | · | part |
| 5.1.4 | Neodymium Magnet | neodymium-magnet | 8× | 32 | · | part |
| 5.1.5 | Motor Housing | motor-housing | 1× | 4 | · | part |
| 5.2 | Harmonic Reducer 4 parts | palletizing-robot-reducer | 1× | 4 | 5 | assembly |
| 5.2.1 | Gearbox Housing | gearbox-housing | 1× | 4 | · | part |
| 5.2.2 | Helical Gear Pair | gear-pair | 1× | 4 | · | part |
| 5.2.3 | Wave Generator | palletizing-robot-wave-generator | 1× | 4 | · | part |
| 5.2.4 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 5.3 | Absolute Encoder 3 parts | palletizing-robot-encoder | 1× | 4 | 4 | assembly |
| 5.3.1 | Hall Sensor | hall-sensor | 2× | 8 | · | part |
| 5.3.2 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 5.3.3 | Code Disc | palletizing-robot-encoder-disc | 1× | 4 | · | part |
| 5.4 | Servo Drive 4 parts | palletizing-robot-servo-drive | 1× | 4 | 85 | assembly |
| 5.4.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 5.4.2 | IGBT Power Module | igbt-module | 1× | 4 | · | part |
| 5.4.3 | SMD Passive (R/C/L) | smd-passives | 80× | 320 | · | part |
| 5.4.4 | Connector | connector | 3× | 12 | · | part |
| 5.5 | Holding Brake | palletizing-robot-brake | 1× | 4 | · | part |
| 5.6 | Ball Bearing | ball-bearing | 2× | 8 | · | part |
| 6 | EOAT Gripper 5 parts | palletizing-robot-gripper | 1× | 1 | 34 | assembly |
| 6.1 | Vacuum Pad Zone 2 parts | palletizing-robot-vacuum-zone | 4× | 4 | 7 | assembly |
| 6.1.1 | Suction Cup | palletizing-robot-suction-cup | 6× | 24 | · | part |
| 6.1.2 | Zone Valve | palletizing-robot-vacuum-valve | 1× | 4 | · | part |
| 6.2 | Venturi Vacuum Generator | palletizing-robot-vacuum-generator | 1× | 1 | · | part |
| 6.3 | Clamp Plate | palletizing-robot-clamp | 2× | 2 | · | part |
| 6.4 | Clamp Cylinder | palletizing-robot-clamp-cylinder | 2× | 2 | · | part |
| 6.5 | EOAT Frame | palletizing-robot-tool-frame | 1× | 1 | · | part |
| 7 | Controller Cabinet 6 parts | palletizing-robot-controller | 1× | 1 | 629 | assembly |
| 7.1 | Motion Controller 5 parts | palletizing-robot-motion-board | 1× | 1 | 211 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.1.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.1.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 7.1.5 | Connector | connector | 8× | 8 | · | part |
| 7.2 | Servo Drive 4 parts | palletizing-robot-servo-drive | 4× | 4 | 85 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 7.2.2 | IGBT Power Module | igbt-module | 1× | 4 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 80× | 320 | · | part |
| 7.2.4 | Connector | connector | 3× | 12 | · | part |
| 7.3 | I/O Board 4 parts | palletizing-robot-io-board | 1× | 1 | 75 | assembly |
| 7.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.3.2 | Relay | relay | 8× | 8 | · | part |
| 7.3.3 | Connector | connector | 6× | 6 | · | part |
| 7.3.4 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 7.4 | Power Supply | palletizing-robot-power-supply | 1× | 1 | · | part |
| 7.5 | Safety Relay | palletizing-robot-safety-relay | 1× | 1 | · | part |
| 7.6 | Cabinet Frame | palletizing-robot-cabinet-frame | 1× | 1 | · | part |
| 8 | Teach Pendant 5 parts | palletizing-robot-pendant | 1× | 1 | 78 | assembly |
| 8.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.3 | Pendant Board 4 parts | palletizing-robot-pendant-board | 1× | 1 | 74 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 8.3.4 | Connector | connector | 2× | 2 | · | part |
| 8.4 | E-Stop & Enable | palletizing-robot-estop | 1× | 1 | · | part |
| 8.5 | Pendant Shell | palletizing-robot-pendant-shell | 1× | 1 | · | part |
| 9 | Dress-Out Cabling 3 parts | palletizing-robot-cabling | 1× | 1 | 14 | assembly |
| 9.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 9.2 | Connector | connector | 12× | 12 | · | part |
| 9.3 | Cable Track | palletizing-robot-cable-track | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Painting Robot
1,768 parts · shares 6 with this page
Polishing/Grinding Robot
1,752 parts · shares 6 with this page
 Robotic Assembly Cell
1,746 parts · shares 6 with this page
Robotic Deburring Cell
1,637 parts · shares 6 with this page
 Cartesian Gantry Robot
1,051 parts · shares 5 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
369-word article