Tote Handling Robot
ProductOverview
A tote handling robot builds and breaks down stacks of standard plastic totes at the head of a conveyor line. Empty or full totes arrive one at a time on the infeed, the robot lifts each and places it onto a growing stack on the outfeed, and in reverse it pulls totes off an incoming stack to feed them singly downstream. This is a small, repetitive job that wears people out fast: a tote weighs up to fifty kilograms full and a line can run several hundred an hour. The robot is a two-axis gantry rather than a jointed arm because the motion is purely up and across, so a simple Horizontal Travel Axis and Vertical Lift Axis pair does the work faster and more cheaply than an articulated robot would. Everything hangs on a Gantry Frame that straddles the two conveyor lanes.
Frame and axes
The Gantry Frame is a welded steel gantry: two Column uprights, a top Cross Beam, and Base Rail floor rails that also locate the conveyors, leveled on four Leveling Foot feet. The vertical Vertical Lift Axis carries a Lift Carriage up and down two Linear Guide Rail rails on a steel-cord Lift Belt driven by the Lift Servo. A Counterbalance gas spring offsets the carriage weight so the lift motor sizes for the tote load rather than the dead weight, and a Lift Brake holds the carriage if power fails. The horizontal Horizontal Travel Axis moves the whole vertical assembly between the infeed and outfeed lanes on its own belt and rails, with a Energy Chain feeding power and signal to the moving head.
Gripper head
The Tote Gripper Head grips a tote by clamping its side walls rather than lifting from inside, so it works whether the tote is empty or full. Two Clamp Actuator units drive rubber-faced Clamp Jaw jaws inward against the tote, while tapered Centering Guide guides square the tote to the head as it descends. A Grip Sensor on each side confirms the jaws have seated before the carriage lifts, which prevents a dropped tote when a stack is slightly out of position. The head bolts to the carriage through a stiff Head Frame.
Conveyors
Two roller conveyors define the line. The Infeed Conveyor presents single totes to the pick position on driven Conveyor Roller rollers turned by an Conveyor Motor, registered by a pop-up Pick Stop and kept square by Side Guide rails. The Outfeed Conveyor carries the built stacks away on Outfeed Roller rollers, holding the stack location with a Stack Stop while the robot adds totes. Running infeed and outfeed as separate driven lanes lets the robot work continuously: a new tote queues while the previous one is being placed.
Sensing and control
The Sensor Set gives the controller the state of the line. Presence Sensor photoeyes confirm totes at each station, a Height Sensor measures the growing stack so the robot lowers to the right level each cycle, a Barcode Reader logs tote IDs for tracking, and Axis Encoder feedback closes the position loops. The Control System runs it through a Motion Controller that coordinates the two axes, gripper, and conveyors, four Axis Drive amplifiers, an I/O Module, and a touch Operator Panel for setup and recovery. Coordinating X and Z lets the head move in a smooth diagonal between pick and place rather than stopping at corners, which is where the cycle time is won.
Safety and electrical
A gantry slinging fifty-kilogram totes overhead is enclosed by the Safety System: a Guard Fence perimeter, Light Curtain curtains at the conveyor openings that mute for passing totes but stop the machine for a person, Emergency Stop buttons, and a Safety Controller that evaluates them all. Muting the curtain for totes while still catching people is the central safety trick of any conveyor-fed cell. Power and drives live in the Electrical System cabinet, built around a Control Cabinet enclosure with a Power Supply, a Breaker Set, and a machine Machine Harness. In service these robots sit at depalletizing stations, order consolidation, and line buffers where the same tote is stacked, stored, and destacked many times across its life, and the robot removes a job that is both dull and a common source of back injury.
Tote Handling Robot parts and their functions
10 top-level parts · 1,042 parts in total · full bill of materials below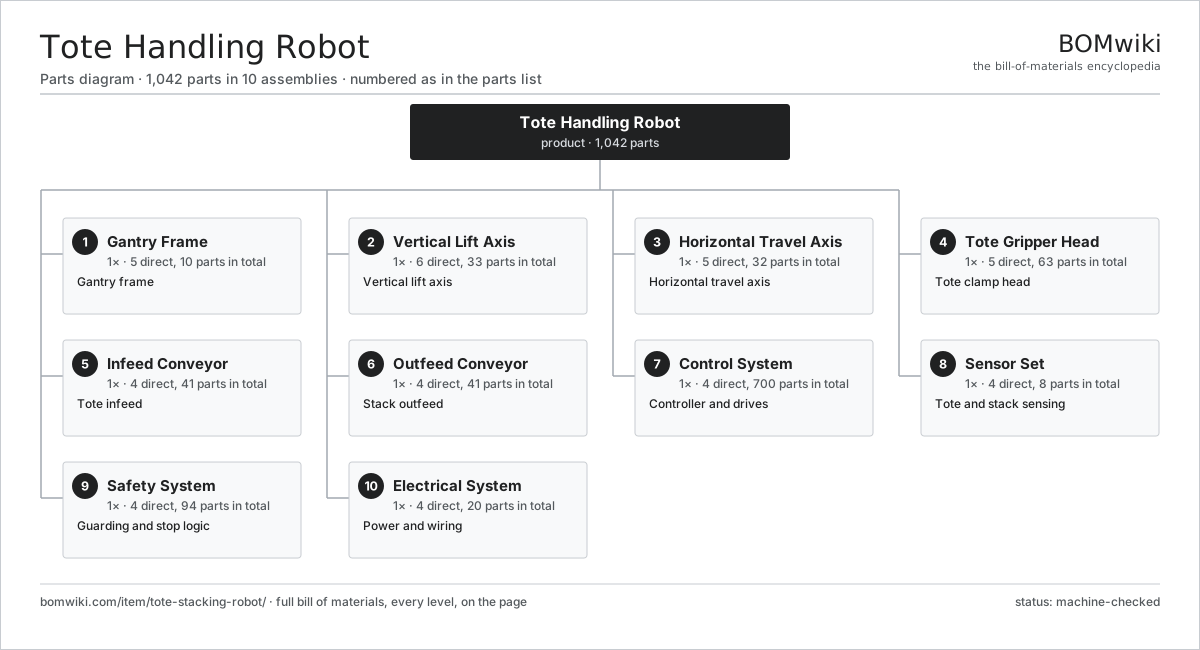
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Gantry Frame 5 parts | 1× | Gantry frame |
| 2 | Vertical Lift Axis 6 parts | 1× | Vertical lift axis |
| 3 | Horizontal Travel Axis 5 parts | 1× | Horizontal travel axis |
| 4 | Tote Gripper Head 5 parts | 1× | Tote clamp head |
| 5 | Infeed Conveyor 4 parts | 1× | Tote infeed |
| 6 | Outfeed Conveyor 4 parts | 1× | Stack outfeed |
| 7 | Control System 4 parts | 1× | Controller and drives |
| 8 | Sensor Set 4 parts | 1× | Tote and stack sensing |
| 9 | Safety System 4 parts | 1× | Guarding and stop logic |
| 10 | Electrical System 4 parts | 1× | Power and wiring |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Tote Handling Robot
10 top-level lines · 88 rows shown · 1,042 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Gantry Frame 5 parts | tote-stacking-robot-frame | 1× | 1 | 10 | assembly |
| 1.1 | Column | tote-stacking-robot-column | 2× | 2 | · | part |
| 1.2 | Cross Beam | tote-stacking-robot-cross-beam | 1× | 1 | · | part |
| 1.3 | Base Rail | tote-stacking-robot-base-rail | 2× | 2 | · | part |
| 1.4 | Leveling Foot | tote-stacking-robot-foot | 4× | 4 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Vertical Lift Axis 6 parts | tote-stacking-robot-z-axis | 1× | 1 | 33 | assembly |
| 2.1 | Lift Carriage | tote-stacking-robot-z-carriage | 1× | 1 | · | part |
| 2.2 | Lift Servo 3 parts | tote-stacking-robot-z-motor | 1× | 1 | 27 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.3 | Lift Belt | tote-stacking-robot-z-belt | 1× | 1 | · | part |
| 2.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 2.5 | Counterbalance | tote-stacking-robot-counterbalance | 1× | 1 | · | part |
| 2.6 | Lift Brake | tote-stacking-robot-z-brake | 1× | 1 | · | part |
| 3 | Horizontal Travel Axis 5 parts | tote-stacking-robot-x-axis | 1× | 1 | 32 | assembly |
| 3.1 | Travel Carriage | tote-stacking-robot-x-carriage | 1× | 1 | · | part |
| 3.2 | Travel Servo 3 parts | tote-stacking-robot-x-motor | 1× | 1 | 27 | assembly |
| 3.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 3.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 3.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3.3 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 3.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 3.5 | Energy Chain | tote-stacking-robot-energy-chain | 1× | 1 | · | part |
| 4 | Tote Gripper Head 5 parts | tote-stacking-robot-gripper-head | 1× | 1 | 63 | assembly |
| 4.1 | Clamp Actuator 3 parts | tote-stacking-robot-clamp-actuator | 2× | 2 | 27 | assembly |
| 4.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 2 | 24 | assembly |
| 4.1.2 | Ball Screw | ball-screw | 1× | 2 | · | part |
| 4.1.3 | Ball Bearing | ball-bearing | 2× | 4 | · | part |
| 4.2 | Clamp Jaw | tote-stacking-robot-clamp-jaw | 2× | 2 | · | part |
| 4.3 | Centering Guide | tote-stacking-robot-centering-guide | 4× | 4 | · | part |
| 4.4 | Grip Sensor | tote-stacking-robot-grip-sensor | 2× | 2 | · | part |
| 4.5 | Head Frame | tote-stacking-robot-head-frame | 1× | 1 | · | part |
| 5 | Infeed Conveyor 4 parts | tote-stacking-robot-infeed-conveyor | 1× | 1 | 41 | assembly |
| 5.1 | Conveyor Roller | tote-stacking-robot-infeed-roller | 12× | 12 | · | part |
| 5.2 | Conveyor Motor 3 parts | tote-stacking-robot-infeed-motor | 1× | 1 | 26 | assembly |
| 5.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 5.2.3 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 5.3 | Pick Stop | tote-stacking-robot-infeed-stop | 1× | 1 | · | part |
| 5.4 | Side Guide | tote-stacking-robot-side-guide | 2× | 2 | · | part |
| 6 | Outfeed Conveyor 4 parts | tote-stacking-robot-outfeed-conveyor | 1× | 1 | 41 | assembly |
| 6.1 | Outfeed Roller | tote-stacking-robot-outfeed-roller | 12× | 12 | · | part |
| 6.2 | Outfeed Motor 3 parts | tote-stacking-robot-outfeed-motor | 1× | 1 | 26 | assembly |
| 6.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 6.2.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 6.2.3 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 6.3 | Stack Stop | tote-stacking-robot-stack-stop | 1× | 1 | · | part |
| 6.4 | Side Guide | tote-stacking-robot-side-guide | 2× | 2 | · | part |
| 7 | Control System 4 parts | tote-stacking-robot-control-system | 1× | 1 | 700 | assembly |
| 7.1 | Motion Controller 4 parts | tote-stacking-robot-motion-controller | 1× | 1 | 173 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 160× | 160 | · | part |
| 7.1.4 | Connector | connector | 10× | 10 | · | part |
| 7.2 | Axis Drive 3 parts | tote-stacking-robot-axis-drive | 4× | 4 | 112 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 4 | · | part |
| 7.2.2 | Microcontroller | mcu | 1× | 4 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 110× | 440 | · | part |
| 7.3 | Operator Panel 2 parts | tote-stacking-robot-hmi | 1× | 1 | 2 | assembly |
| 7.3.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7.3.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4 | I/O Module 3 parts | tote-stacking-robot-io-module | 1× | 1 | 77 | assembly |
| 7.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.2 | Relay | relay | 6× | 6 | · | part |
| 7.4.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 8 | Sensor Set 4 parts | tote-stacking-robot-sensor-set | 1× | 1 | 8 | assembly |
| 8.1 | Presence Sensor | tote-stacking-robot-presence-sensor | 4× | 4 | · | part |
| 8.2 | Height Sensor | tote-stacking-robot-height-sensor | 1× | 1 | · | part |
| 8.3 | Barcode Reader | tote-stacking-robot-barcode-reader | 1× | 1 | · | part |
| 8.4 | Axis Encoder | tote-stacking-robot-encoder | 2× | 2 | · | part |
| 9 | Safety System 4 parts | tote-stacking-robot-safety-system | 1× | 1 | 94 | assembly |
| 9.1 | Guard Fence | tote-stacking-robot-guard-fence | 1× | 1 | · | part |
| 9.2 | Light Curtain | tote-stacking-robot-light-curtain | 2× | 2 | · | part |
| 9.3 | Safety Controller 4 parts | tote-stacking-robot-safety-controller | 1× | 1 | 89 | assembly |
| 9.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 9.3.3 | Relay | relay | 6× | 6 | · | part |
| 9.3.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 9.4 | Emergency Stop | tote-stacking-robot-estop | 2× | 2 | · | part |
| 10 | Electrical System 4 parts | tote-stacking-robot-electrical | 1× | 1 | 20 | assembly |
| 10.1 | Control Cabinet | tote-stacking-robot-cabinet | 1× | 1 | · | part |
| 10.2 | Power Supply | power-supply | 1× | 1 | · | part |
| 10.3 | Breaker Set | tote-stacking-robot-breaker-set | 1× | 1 | · | part |
| 10.4 | Machine Harness 2 parts | tote-stacking-robot-harness | 1× | 1 | 17 | assembly |
| 10.4.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 10.4.2 | Connector | connector | 16× | 16 | · | part |
Related products
same domain, ranked by shared parts Cartesian Pick Robot
781 parts · shares 6 with this page
 Robotic Assembly Cell
1,746 parts · shares 6 with this page
Robotic Grinding Cell
1,419 parts · shares 6 with this page
Gantry Loading Robot
800 parts · shares 4 with this page
Robotic Palletizing Cell
986 parts · shares 5 with this page
 Vision-Guided Robot
1,735 parts · shares 4 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
848-word article