Robotic Screwdriving Cell
ProductRobotic Screwdriving Cell
The Robotic Screwdriving Cell is an automated workstation that picks fasteners from a bulk supply, positions a driver over each hole, and tightens every screw to a recorded torque. It replaces hand-held tightening on assembly lines where a product has many small fasteners, where torque has to be documented per screw, or where cycle time and consistency matter more than a human operator can hold. A typical application is fastening the case screws on consumer electronics, the bracket screws on an appliance, or the cover screws on an automotive electronic control unit.
Overview
The cell is built around a Six-Axis Robot Arm, a six-axis articulated manipulator with a 7 kg payload and 900 mm reach. The arm carries the Screwdriving Spindle (End-Effector), an electric nutrunner end-effector. Screws arrive from the Automatic Screw Feeder, which orients them out of a bulk hopper and presents one at a time. The workpiece sits on the Part Fixture & Index Table, an indexing table that locates and clamps the part so its hole pattern is held in a known position. Everything is coordinated from the Controller Cabinet, and an operator works through the Teach Pendant / HMI. The whole cell sits inside a Safety Enclosure for safety, with power and air routed by the Cell Cabling & Pneumatics.
How it works
A cycle starts when a part is loaded into a nest on the Rotary Index Table and the Part-Present Sensor confirms it is seated. The Pneumatic Toggle Clamp units close to hold the part flat. The Escapement Mechanism separates a single screw from the feed track, and the Blow-Feed Hose & Pickup sends it through a hose to the pickup point. The driver bit collects the screw and holds it with the Vacuum Screw Retention Sleeve, which applies suction so the screw cannot fall off during the move.
The robot moves the spindle over the first hole. The Z-Stroke Feed / Compliance Unit drives the bit down using a pneumatic stroke, while a Driver Bit in the Quick-Change Bit Holder engages the screw recess. The Servo Nutrunner Spindle spins the screw in. As torque builds, the Torque/Angle Transducer reads it continuously through bonded Strain Gauge sensors, and the Fastening (Torque) Controller watches both torque and rotation angle. When the target torque is reached, or when a torque-and-angle window is satisfied, the controller stops the spindle and records the result. The Stroke Position Sensor confirms the bit reached the expected depth, which catches cross-threaded or missing screws. The robot indexes to the next hole and repeats until the pattern is done, then the table rotates to present the next part.
Robot arm
The arm is six servo-driven joints. The J1 Base Axis Module, J2 Shoulder Axis Module and J3 Elbow Axis Module position the wrist in space, and three Wrist Axis Module modules orient the tool. Each joint uses an AC Servo Motor feeding a Strain-Wave Reducer strain-wave reducer for high stiffness and low backlash, with a Absolute Joint Encoder giving absolute position. The large joints ride on a Cross-Roller Bearing that carries radial, axial and moment loads together, and a J2 Counterbalance Unit offloads the shoulder so the J2 motor is not fighting gravity all day. The links are Cast Arm Link aluminum, and the tool mounts to an Tool Mounting Flange cut to the ISO 9409 pattern. Cables and air run inside a Internal Energy Chain so nothing snags during motion.
Screwdriving spindle
The end-effector is the part that does the actual fastening. The Servo Nutrunner Spindle is a brushless Servo Motor geared through a Helical Gear Pair planetary stage to the Output Spindle Shaft. Mounting it on a servo rather than an air motor is what allows controlled torque and angle. The inline Torque/Angle Transducer measures the real torque at the bit instead of inferring it from motor current, which is how the cell hits ±3% accuracy. The Z-Stroke Feed / Compliance Unit gives the bit a Z stroke on a pair of Linear Guide Rail rails, with a Coil Spring and a Pneumatic Feed Cylinder providing down-force and compliance so the bit stays engaged as the screw sinks. The Vacuum Screw Retention Sleeve uses a Venturi Vacuum Generator venturi to hold the screw on the bit during transfer.
Screw feeder
Loose screws are useless to a robot until they are oriented head-up and singulated. The Vibratory Bowl Feeder does this: a Electromagnetic Vibratory Drive shakes a tooled Tooled Feed Bowl so screws climb a spiral track, and track geometry rejects any that are not the right way around. Oriented screws collect on the Linear Feed Track, the Escapement Mechanism releases them one by one, and the Blow-Feed Hose & Pickup delivers each through a Screw Delivery Hose to the Pickup Nest. A Bulk Screw Hopper refills the bowl as it empties.
Controls and safety
The Robot Motion Controller plans the joint paths and runs the cell sequence, sending commands to six Servo Drive Amplifier amplifiers, one per joint, each built on an IGBT Power Module. The Fastening (Torque) Controller owns the fastening logic and keeps a per-screw log for traceability. A Safety PLC watches the Safety Light Curtain, the Interlocked Access Door and every Emergency Stop Button, and it cuts motor power if anyone reaches into the Safety Enclosure while the robot is running. The operator jogs and programs the cell from the Teach Pendant / HMI, which has an LCD Panel, a 3-Position Enabling Switch for manual moves, and its own e-stop.
Variants and use
Smaller versions use a SCARA arm instead of a six-axis arm where every screw goes in vertically, which is cheaper and faster for flat parts. Larger cells add a second robot or more fixture stations on the Rotary Index Table to overlap loading with driving. The same architecture scales from M2 instrument screws up to M6 structural screws by changing the bit, the feed bowl tooling and the spindle torque setting. Because every result is logged, these cells are common wherever a fastening record is required for warranty or regulatory reasons.
Robotic Screwdriving Cell parts and their functions
8 top-level parts · 2,109 parts in total · full bill of materials below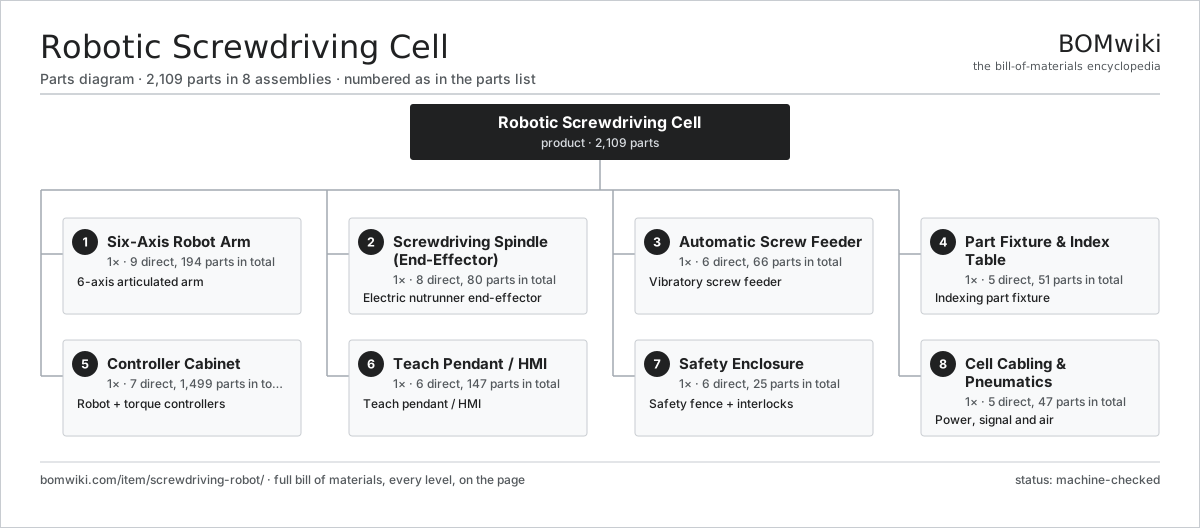
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Six-Axis Robot Arm 9 parts | 1× | 6-axis articulated arm |
| 2 | Screwdriving Spindle (End-Effector) 8 parts | 1× | Electric nutrunner end-effector |
| 3 | Automatic Screw Feeder 6 parts | 1× | Vibratory screw feeder |
| 4 | Part Fixture & Index Table 5 parts | 1× | Indexing part fixture |
| 5 | Controller Cabinet 7 parts | 1× | Robot + torque controllers |
| 6 | Teach Pendant / HMI 6 parts | 1× | Teach pendant / HMI |
| 7 | Safety Enclosure 6 parts | 1× | Safety fence + interlocks |
| 8 | Cell Cabling & Pneumatics 5 parts | 1× | Power, signal and air |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Screwdriving Cell
8 top-level lines · 160 rows shown · 2,109 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Six-Axis Robot Arm 9 parts | screwdriving-robot-arm | 1× | 1 | 194 | assembly |
| 1.1 | J1 Base Axis Module 6 parts | screwdriving-robot-base-axis | 1× | 1 | 30 | assembly |
| 1.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.1.2 | Strain-Wave Reducer | screwdriving-robot-reducer | 1× | 1 | · | part |
| 1.1.3 | Absolute Joint Encoder | screwdriving-robot-encoder | 1× | 1 | · | part |
| 1.1.4 | Cross-Roller Bearing | screwdriving-robot-cross-roller-bearing | 1× | 1 | · | part |
| 1.1.5 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 1.1.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.2 | J2 Shoulder Axis Module 6 parts | screwdriving-robot-shoulder-axis | 1× | 1 | 30 | assembly |
| 1.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.2.2 | Strain-Wave Reducer | screwdriving-robot-reducer | 1× | 1 | · | part |
| 1.2.3 | Absolute Joint Encoder | screwdriving-robot-encoder | 1× | 1 | · | part |
| 1.2.4 | Cross-Roller Bearing | screwdriving-robot-cross-roller-bearing | 1× | 1 | · | part |
| 1.2.5 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 1.2.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.3 | J3 Elbow Axis Module 6 parts | screwdriving-robot-elbow-axis | 1× | 1 | 31 | assembly |
| 1.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.3.2 | Strain-Wave Reducer | screwdriving-robot-reducer | 1× | 1 | · | part |
| 1.3.3 | Absolute Joint Encoder | screwdriving-robot-encoder | 1× | 1 | · | part |
| 1.3.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.3.5 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 1.3.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 1.4 | Wrist Axis Module 5 parts | screwdriving-robot-wrist-axis | 3× | 3 | 29 | assembly |
| 1.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 3 | 24 | assembly |
| 1.4.2 | Helical Gear Pair | gear-pair | 1× | 3 | · | part |
| 1.4.3 | Absolute Joint Encoder | screwdriving-robot-encoder | 1× | 3 | · | part |
| 1.4.4 | Ball Bearing | ball-bearing | 2× | 6 | · | part |
| 1.4.5 | Oil Seal | oil-seal | 1× | 3 | · | part |
| 1.5 | Cast Arm Link | screwdriving-robot-arm-casting | 4× | 4 | · | part |
| 1.6 | Tool Mounting Flange | screwdriving-robot-tool-flange | 1× | 1 | · | part |
| 1.7 | J2 Counterbalance Unit 2 parts | screwdriving-robot-counterbalance | 1× | 1 | 3 | assembly |
| 1.7.1 | Coil Spring | coil-spring | 1× | 1 | · | part |
| 1.7.2 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.8 | Internal Energy Chain 2 parts | screwdriving-robot-energy-chain | 1× | 1 | 2 | assembly |
| 1.8.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 1.8.2 | Pneumatic Air Hose | screwdriving-robot-air-hose | 1× | 1 | · | part |
| 1.9 | Fastener Set | fastener-set | 6× | 6 | · | part |
| 2 | Screwdriving Spindle (End-Effector) 8 parts | screwdriving-robot-spindle | 1× | 1 | 80 | assembly |
| 2.1 | Servo Nutrunner Spindle 5 parts | screwdriving-robot-nutrunner | 1× | 1 | 29 | assembly |
| 2.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.1.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.1.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.1.4 | Output Spindle Shaft | screwdriving-robot-output-spindle | 1× | 1 | · | part |
| 2.1.5 | Motor Housing | motor-housing | 1× | 1 | · | part |
| 2.2 | Torque/Angle Transducer 3 parts | screwdriving-robot-transducer | 1× | 1 | 35 | assembly |
| 2.2.1 | Strain Gauge | screwdriving-robot-strain-gauge | 4× | 4 | · | part |
| 2.2.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.2.3 | SMD Passive (R/C/L) | smd-passives | 30× | 30 | · | part |
| 2.3 | Z-Stroke Feed / Compliance Unit 4 parts | screwdriving-robot-feed-unit | 1× | 1 | 8 | assembly |
| 2.3.1 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 2.3.2 | Coil Spring | coil-spring | 1× | 1 | · | part |
| 2.3.3 | Pneumatic Feed Cylinder 3 parts + deeper › | screwdriving-robot-stroke-cylinder | 1× | 1 | 4 | assembly |
| 2.3.4 | Stroke Position Sensor | screwdriving-robot-depth-sensor | 1× | 1 | · | part |
| 2.4 | Quick-Change Bit Holder | screwdriving-robot-bit-holder | 1× | 1 | · | part |
| 2.5 | Driver Bit | screwdriving-robot-bit | 1× | 1 | · | part |
| 2.6 | Vacuum Screw Retention Sleeve 3 parts | screwdriving-robot-vacuum-bit | 1× | 1 | 3 | assembly |
| 2.6.1 | Vacuum Sleeve | screwdriving-robot-vacuum-sleeve | 1× | 1 | · | part |
| 2.6.2 | Venturi Vacuum Generator | screwdriving-robot-vacuum-generator | 1× | 1 | · | part |
| 2.6.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 2.7 | Spindle Housing | screwdriving-robot-spindle-housing | 1× | 1 | · | part |
| 2.8 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 3 | Automatic Screw Feeder 6 parts | screwdriving-robot-feeder | 1× | 1 | 66 | assembly |
| 3.1 | Vibratory Bowl Feeder 4 parts | screwdriving-robot-bowl-feeder | 1× | 1 | 14 | assembly |
| 3.1.1 | Tooled Feed Bowl | screwdriving-robot-feed-bowl | 1× | 1 | · | part |
| 3.1.2 | Electromagnetic Vibratory Drive 3 parts + deeper › | screwdriving-robot-vibratory-drive | 1× | 1 | 5 | assembly |
| 3.1.3 | Coil Spring | coil-spring | 6× | 6 | · | part |
| 3.1.4 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 3.2 | Linear Feed Track | screwdriving-robot-linear-track | 1× | 1 | · | part |
| 3.3 | Escapement Mechanism 3 parts | screwdriving-robot-escapement | 1× | 1 | 4 | assembly |
| 3.3.1 | Escapement Air Cylinder | screwdriving-robot-escapement-cylinder | 1× | 1 | · | part |
| 3.3.2 | Escapement Jaw | screwdriving-robot-escapement-jaw | 2× | 2 | · | part |
| 3.3.3 | Screw Presence Sensor | screwdriving-robot-screw-present-sensor | 1× | 1 | · | part |
| 3.4 | Blow-Feed Hose & Pickup 3 parts | screwdriving-robot-blow-feed | 1× | 1 | 3 | assembly |
| 3.4.1 | Screw Delivery Hose | screwdriving-robot-feed-hose | 1× | 1 | · | part |
| 3.4.2 | Pickup Nest | screwdriving-robot-pickup-nest | 1× | 1 | · | part |
| 3.4.3 | Air-Blast Valve | screwdriving-robot-blow-valve | 1× | 1 | · | part |
| 3.5 | Feeder Vibration Controller 4 parts | screwdriving-robot-feeder-controller | 1× | 1 | 43 | assembly |
| 3.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.5.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.5.3 | Triac | triac | 1× | 1 | · | part |
| 3.5.4 | SMD Passive (R/C/L) | smd-passives | 40× | 40 | · | part |
| 3.6 | Bulk Screw Hopper | screwdriving-robot-hopper | 1× | 1 | · | part |
| 4 | Part Fixture & Index Table 5 parts | screwdriving-robot-fixture | 1× | 1 | 51 | assembly |
| 4.1 | Rotary Index Table 4 parts | screwdriving-robot-index-table | 1× | 1 | 27 | assembly |
| 4.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 4.1.2 | Strain-Wave Reducer | screwdriving-robot-reducer | 1× | 1 | · | part |
| 4.1.3 | Cross-Roller Bearing | screwdriving-robot-cross-roller-bearing | 1× | 1 | · | part |
| 4.1.4 | Dial Plate | screwdriving-robot-dial-plate | 1× | 1 | · | part |
| 4.2 | Workpiece Nest Plate | screwdriving-robot-nest-plate | 2× | 2 | · | part |
| 4.3 | Pneumatic Toggle Clamp 3 parts | screwdriving-robot-clamp | 4× | 4 | 3 | assembly |
| 4.3.1 | Clamp Air Cylinder | screwdriving-robot-clamp-cylinder | 1× | 4 | · | part |
| 4.3.2 | Clamp Arm | screwdriving-robot-clamp-arm | 1× | 4 | · | part |
| 4.3.3 | O-Ring Set | oring-set | 1× | 4 | · | part |
| 4.4 | Locating Pin | screwdriving-robot-locating-pin | 8× | 8 | · | part |
| 4.5 | Part-Present Sensor | screwdriving-robot-part-present-sensor | 2× | 2 | · | part |
| 5 | Controller Cabinet 7 parts | screwdriving-robot-controller-cabinet | 1× | 1 | 1,499 | assembly |
| 5.1 | Robot Motion Controller 4 parts | screwdriving-robot-robot-controller | 1× | 1 | 364 | assembly |
| 5.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 5.1.3 | Digital I/O Board 5 parts + deeper › | screwdriving-robot-io-board | 1× | 1 | 162 | assembly |
| 5.1.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 5.2 | Servo Drive Amplifier 5 parts | screwdriving-robot-servo-drive | 6× | 6 | 135 | assembly |
| 5.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 5.2.2 | IGBT Power Module | igbt-module | 1× | 6 | · | part |
| 5.2.3 | Gate Driver Board 2 parts + deeper › | screwdriving-robot-gate-driver | 1× | 6 | 41 | assembly |
| 5.2.4 | DC Bus Capacitor | screwdriving-robot-dc-bus-cap | 2× | 12 | · | part |
| 5.2.5 | SMD Passive (R/C/L) | smd-passives | 90× | 540 | · | part |
| 5.3 | Fastening (Torque) Controller 5 parts | screwdriving-robot-torque-controller | 1× | 1 | 216 | assembly |
| 5.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 5.3.3 | Transducer Amplifier 2 parts + deeper › | screwdriving-robot-transducer-amp | 1× | 1 | 51 | assembly |
| 5.3.4 | Connector | connector | 12× | 12 | · | part |
| 5.3.5 | SMD Passive (R/C/L) | smd-passives | 150× | 150 | · | part |
| 5.4 | Safety PLC 4 parts | screwdriving-robot-safety-plc | 1× | 1 | 87 | assembly |
| 5.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.4.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 5.4.3 | Relay | relay | 4× | 4 | · | part |
| 5.4.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 5.5 | Power Supply | power-supply | 2× | 2 | · | part |
| 5.6 | Cabinet Enclosure 4 parts | screwdriving-robot-cabinet-enclosure | 1× | 1 | 12 | assembly |
| 5.6.1 | Sheet Metal Panel | sheet-panel | 5× | 5 | · | part |
| 5.6.2 | Cabinet Cooling Fan | screwdriving-robot-cabinet-fan | 2× | 2 | · | part |
| 5.6.3 | DIN Rail | screwdriving-robot-din-rail | 4× | 4 | · | part |
| 5.6.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 5.7 | Relay | relay | 8× | 8 | · | part |
| 6 | Teach Pendant / HMI 6 parts | screwdriving-robot-pendant | 1× | 1 | 147 | assembly |
| 6.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 6.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 6.3 | Pendant Mainboard 3 parts | screwdriving-robot-pendant-board | 1× | 1 | 142 | assembly |
| 6.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.3.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 6.3.3 | SMD Passive (R/C/L) | smd-passives | 140× | 140 | · | part |
| 6.4 | 3-Position Enabling Switch | screwdriving-robot-deadman-switch | 1× | 1 | · | part |
| 6.5 | Emergency Stop Button | screwdriving-robot-estop-button | 1× | 1 | · | part |
| 6.6 | Pendant Housing | screwdriving-robot-pendant-housing | 1× | 1 | · | part |
| 7 | Safety Enclosure 6 parts | screwdriving-robot-enclosure | 1× | 1 | 25 | assembly |
| 7.1 | Mesh Fence Panel | screwdriving-robot-fence-panel | 8× | 8 | · | part |
| 7.2 | Fence Post | screwdriving-robot-fence-post | 6× | 6 | · | part |
| 7.3 | Safety Light Curtain 3 parts | screwdriving-robot-light-curtain | 1× | 1 | 4 | assembly |
| 7.3.1 | Light Curtain Emitter | screwdriving-robot-lc-emitter | 1× | 1 | · | part |
| 7.3.2 | Light Curtain Receiver | screwdriving-robot-lc-receiver | 1× | 1 | · | part |
| 7.3.3 | Connector | connector | 2× | 2 | · | part |
| 7.4 | Interlocked Access Door 3 parts | screwdriving-robot-interlock-door | 1× | 1 | 4 | assembly |
| 7.4.1 | Mesh Fence Panel | screwdriving-robot-fence-panel | 1× | 1 | · | part |
| 7.4.2 | Guard-Locking Safety Switch | screwdriving-robot-safety-switch | 1× | 1 | · | part |
| 7.4.3 | Hinge | hinge | 2× | 2 | · | part |
| 7.5 | Emergency Stop Button | screwdriving-robot-estop-button | 2× | 2 | · | part |
| 7.6 | Status Stack Light | screwdriving-robot-status-beacon | 1× | 1 | · | part |
| 8 | Cell Cabling & Pneumatics 5 parts | screwdriving-robot-cabling | 1× | 1 | 47 | assembly |
| 8.1 | Wire Bundle | wire-bundle | 2× | 2 | · | part |
| 8.2 | Connector | connector | 30× | 30 | · | part |
| 8.3 | Air Preparation Unit (FRL) 3 parts | screwdriving-robot-air-prep | 1× | 1 | 3 | assembly |
| 8.3.1 | Air Filter Element | screwdriving-robot-air-filter | 1× | 1 | · | part |
| 8.3.2 | Air Pressure Regulator | screwdriving-robot-air-regulator | 1× | 1 | · | part |
| 8.3.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 8.4 | Pneumatic Valve Island 3 parts | screwdriving-robot-valve-island | 1× | 1 | 8 | assembly |
| 8.4.1 | Solenoid Valve | screwdriving-robot-solenoid-valve | 6× | 6 | · | part |
| 8.4.2 | Valve Manifold Block | screwdriving-robot-manifold-block | 1× | 1 | · | part |
| 8.4.3 | Connector | connector | 1× | 1 | · | part |
| 8.5 | Pneumatic Air Hose | screwdriving-robot-air-hose | 4× | 4 | · | part |
Related products
same domain, ranked by shared parts Robotic Assembly Cell
1,746 parts · shares 12 with this page
Robotic Grinding Cell
1,419 parts · shares 12 with this page
Robotic Depalletizer
1,401 parts · shares 8 with this page
 Robotic Case Erector
799 parts · shares 8 with this page
Robotic Deburring Cell
1,637 parts · shares 11 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $3k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇯🇵Fanuc
fanuc.com ↗
|
Oshino, JP | Industrial robots & CNC | 20 units | 10–18 wks |
| abb.com ↗ | Zurich, CH | Industrial robots | 20 units | 10–18 wks |
|
🇯🇵Yaskawa
yaskawa.com ↗
|
Kitakyushu, JP | Robots & motion | 20 units | 10–18 wks |
|
🇩🇪KUKA
kuka.com ↗
|
Augsburg, DE | Industrial robots | 20 units | 10–18 wks |
| universal-robots.com ↗ | Odense, DK | Collaborative robots | 20 units | 10–18 wks |
1,059-word article