Leg
AssemblySix-DoF leg with high-torque hip, knee, and ankle actuators. A full specification article for this item is being written. Meanwhile its bill of materials and connections are below.
Leg parts and their functions
5 top-level parts · 456 parts in total · full bill of materials below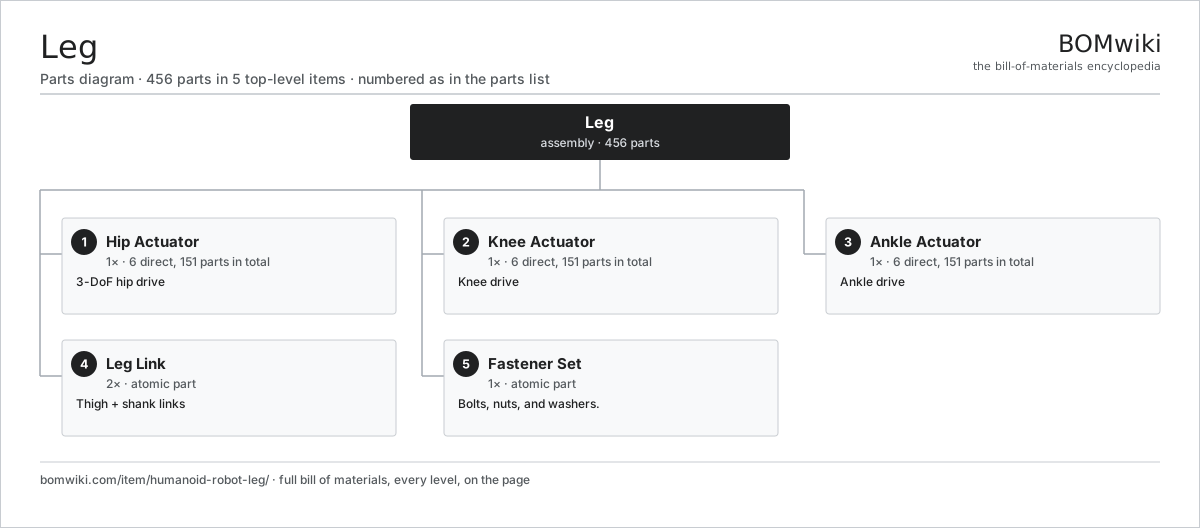
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Hip Actuator 6 parts | 1× | 3-DoF hip drive |
| 2 | Knee Actuator 6 parts | 1× | Knee drive |
| 3 | Ankle Actuator 6 parts | 1× | Ankle drive |
| 4 | Leg Link | 2× | Thigh + shank links |
| 5 | Fastener Set | 1× | Bolts, nuts, and washers. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labour
product / assembly
shared across products
atomic part
related product
Tap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Leg
5 top-level lines · 58 rows shown · 456 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Hip Actuator 6 parts | humanoid-robot-hip-actuator | 1× | 1 | 151 | assembly |
| 1.1 | Frameless BLDC Motor 5 parts | humanoid-robot-frameless-motor | 1× | 1 | 50 | assembly |
| 1.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 1.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 1.1.3 | Neodymium Magnet | neodymium-magnet | 24× | 24 | · | part |
| 1.1.4 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 1.1.5 | Hall Sensor | hall-sensor | 3× | 3 | · | part |
| 1.2 | Planetary Reducer 3 parts | humanoid-robot-planetary-reducer | 1× | 1 | 4 | assembly |
| 1.2.1 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 1.2.2 | Ring Gear | humanoid-robot-ring-gear | 1× | 1 | · | part |
| 1.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.3 | Encoder | encoder | 2× | 2 | · | part |
| 1.4 | Gate Driver Board 3 parts | gate-driver-board | 1× | 1 | 87 | assembly |
| 1.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 1.4.2 | Gate Driver IC | gate-driver-ic | 6× | 6 | · | part |
| 1.4.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 1.5 | Power MOSFET | mosfet | 6× | 6 | · | part |
| 1.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2 | Knee Actuator 6 parts | humanoid-robot-knee-actuator | 1× | 1 | 151 | assembly |
| 2.1 | Frameless BLDC Motor 5 parts | humanoid-robot-frameless-motor | 1× | 1 | 50 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.1.3 | Neodymium Magnet | neodymium-magnet | 24× | 24 | · | part |
| 2.1.4 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 2.1.5 | Hall Sensor | hall-sensor | 3× | 3 | · | part |
| 2.2 | Harmonic Reducer 4 parts | humanoid-robot-harmonic-reducer | 1× | 1 | 4 | assembly |
| 2.2.1 | Wave Generator | humanoid-robot-wave-generator | 1× | 1 | · | part |
| 2.2.2 | Flexspline | humanoid-robot-flexspline | 1× | 1 | · | part |
| 2.2.3 | Circular Spline | humanoid-robot-circular-spline | 1× | 1 | · | part |
| 2.2.4 | Ball Bearing | ball-bearing | 1× | 1 | · | part |
| 2.3 | Encoder | encoder | 2× | 2 | · | part |
| 2.4 | Gate Driver Board 3 parts | gate-driver-board | 1× | 1 | 87 | assembly |
| 2.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.4.2 | Gate Driver IC | gate-driver-ic | 6× | 6 | · | part |
| 2.4.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 2.5 | Power MOSFET | mosfet | 6× | 6 | · | part |
| 2.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3 | Ankle Actuator 6 parts | humanoid-robot-ankle-actuator | 1× | 1 | 151 | assembly |
| 3.1 | Frameless BLDC Motor 5 parts | humanoid-robot-frameless-motor | 1× | 1 | 50 | assembly |
| 3.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 3.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 3.1.3 | Neodymium Magnet | neodymium-magnet | 24× | 24 | · | part |
| 3.1.4 | Copper Winding | copper-winding | 1× | 1 | · | part |
| 3.1.5 | Hall Sensor | hall-sensor | 3× | 3 | · | part |
| 3.2 | Harmonic Reducer 4 parts | humanoid-robot-harmonic-reducer | 1× | 1 | 4 | assembly |
| 3.2.1 | Wave Generator | humanoid-robot-wave-generator | 1× | 1 | · | part |
| 3.2.2 | Flexspline | humanoid-robot-flexspline | 1× | 1 | · | part |
| 3.2.3 | Circular Spline | humanoid-robot-circular-spline | 1× | 1 | · | part |
| 3.2.4 | Ball Bearing | ball-bearing | 1× | 1 | · | part |
| 3.3 | Encoder | encoder | 2× | 2 | · | part |
| 3.4 | Gate Driver Board 3 parts | gate-driver-board | 1× | 1 | 87 | assembly |
| 3.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.4.2 | Gate Driver IC | gate-driver-ic | 6× | 6 | · | part |
| 3.4.3 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 3.5 | Power MOSFET | mosfet | 6× | 6 | · | part |
| 3.6 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 4 | Leg Link | humanoid-robot-leg-link | 2× | 2 | · | part |
| 5 | Fastener Set | fastener-set | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Where the leg is used
1 product across 1 domain contain it, directly or inside a sub-assemblyUsed in 1 assembly
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $0.50–$100. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇨🇳Foxconn
foxconn.com ↗
|
Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| flex.com ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| dixoninfo.com ↗ | Noida, IN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| bydelectronic.com ↗ | Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| venture.com.sg ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |