End-of-Arm Tool (EOAT)
AssemblyVacuum-based loading tool that picks product and releases it into the case. A full specification article for this item is being written. Meanwhile its bill of materials and connections are below.
End-of-Arm Tool (EOAT) parts and their functions
5 top-level parts · 19 parts in total · full bill of materials below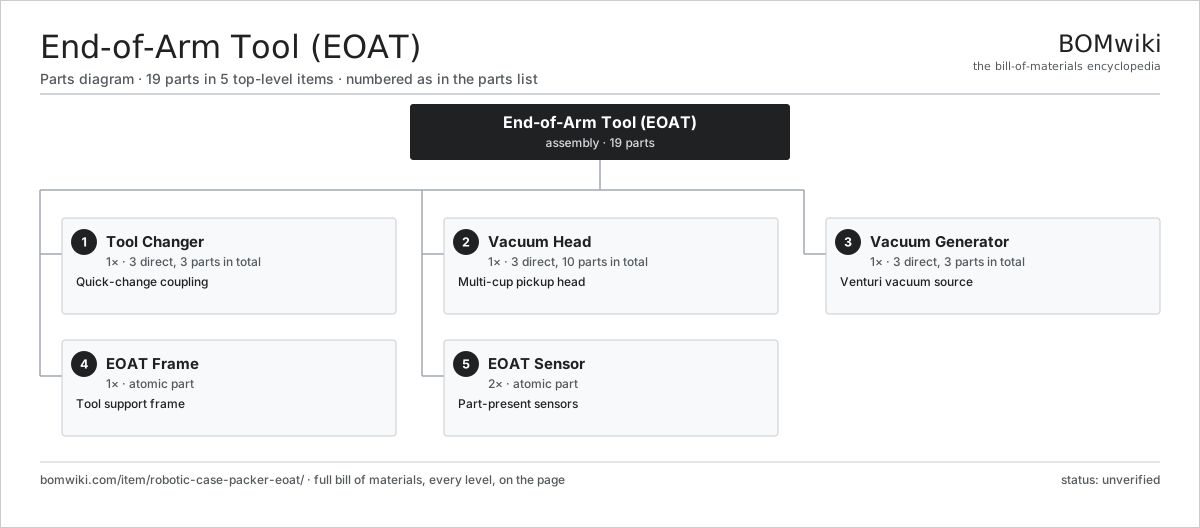
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Tool Changer 3 parts | 1× | Quick-change coupling |
| 2 | Vacuum Head 3 parts | 1× | Multi-cup pickup head |
| 3 | Vacuum Generator 3 parts | 1× | Venturi vacuum source |
| 4 | EOAT Frame | 1× | Tool support frame |
| 5 | EOAT Sensor | 2× | Part-present sensors |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labour
product / assembly
shared across products
atomic part
related product
Tap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for End-of-Arm Tool (EOAT)
5 top-level lines · 14 rows shown · 19 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Tool Changer 3 parts | robotic-case-packer-tool-changer | 1× | 1 | 3 | assembly |
| 1.1 | Tool Changer Master | robotic-case-packer-changer-master | 1× | 1 | · | part |
| 1.2 | Tool Changer Tool Plate | robotic-case-packer-changer-tool | 1× | 1 | · | part |
| 1.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 2 | Vacuum Head 3 parts | robotic-case-packer-vacuum-head | 1× | 1 | 10 | assembly |
| 2.1 | Suction Cup | robotic-case-packer-suction-cup | 8× | 8 | · | part |
| 2.2 | Vacuum Manifold | robotic-case-packer-vacuum-manifold | 1× | 1 | · | part |
| 2.3 | Vacuum Sensor | robotic-case-packer-vacuum-sensor | 1× | 1 | · | part |
| 3 | Vacuum Generator 3 parts | robotic-case-packer-vacuum-generator | 1× | 1 | 3 | assembly |
| 3.1 | Venturi Nozzle | robotic-case-packer-venturi-nozzle | 1× | 1 | · | part |
| 3.2 | Vacuum Valve | robotic-case-packer-vacuum-valve | 1× | 1 | · | part |
| 3.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 4 | EOAT Frame | robotic-case-packer-eoat-frame | 1× | 1 | · | part |
| 5 | EOAT Sensor | robotic-case-packer-eoat-sensor | 2× | 2 | · | part |
Where the end-of-arm tool (EOAT) is used
1 product across 1 domain contain it, directly or inside a sub-assemblyUsed in 1 assembly
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $0.50–$100. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇨🇳Foxconn
foxconn.com ↗
|
Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| flex.com ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| dixoninfo.com ↗ | Noida, IN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| bydelectronic.com ↗ | Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| venture.com.sg ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |