Robotic Case Packing Cell
ProductOverview
A robotic case packing cell loads product into shipping cases using an articulated robot instead of fixed mechanical tooling. Product arrives on a conveyor, a camera finds each piece, the robot picks one or several at a time, and it places them into an open case held nearby. The cell suits lines that change product or case format often, because a recipe change is mostly software rather than mechanical tooling swaps. A typical cell runs 6 to 15 cases per minute and handles cases from 250 to 600 mm long. The whole machine sits inside Safety Fencing and Light Curtains so people stay clear of the moving arm.
Cell frame and layout
The Cell Frame and Base is a welded steel base that holds everything in fixed relation. The robot bolts to a Robot Pedestal that raises it to a height where the arm can reach both the infeed conveyor and the case position without straining its joints. A machined Base Platform gives a flat datum so the robot keeps its calibration, and Leveling Foot feet take out floor unevenness. Getting the geometry right at install matters, because the robot picks and places against taught coordinates, and a frame that flexes or settles puts product outside the case.
The robot arm
The Robot Arm has six joints, each built the same way: a Servo Motor driving through a Helical Gear Pair reducer inside a Gearbox Housing, with a Joint Encoder reporting the joint angle back to the controller. The Robot Base (Axis 1) is axis 1, a turntable on a Slewing Bearing that swings the whole arm. The Shoulder Joint (Axis 2) and Elbow Joint (Axis 3) do the heavy lifting against gravity and payload, so their motors and reducers are the largest. The Wrist Assembly (Axes 4-6) packs three smaller Servo Motor drives into a compact head that orients the tool in roll, pitch and yaw, ending at a Tool Flange. Power and feedback run inside the Arm Harness so nothing snags during fast moves. The arm casting links are aluminium to keep the moving mass down.
End-of-arm tooling
The End-of-Arm Tool (EOAT) is the part that touches product, and it is the part most often changed between jobs. A Tool Changer couples it to the wrist with a pneumatic lock, so the cell can swap a cup head for a finger gripper without tools. For most boxed and bagged goods the cell uses a Vacuum Head, an array of Suction Cup cups fed from a shared Vacuum Manifold. Vacuum comes from a Vacuum Generator, a venturi ejector that needs only shop air, so there is no separate pump. A Vacuum Sensor confirms every cup has sealed before the arm lifts, which stops the robot dropping product mid-move. When the case position is reached, a fast blow-off through the Vacuum Valve releases the grip cleanly.
Product infeed and vision
Product reaches the cell on the Infeed Conveyor, a flat-belt unit driven by a Conveyor Motor gearmotor. Above the belt sits the Vision System: a Vision Camera built around a CMOS Image Sensor, a Vision Light for even illumination, and a Vision Lens. The camera finds the position and angle of each item and sends pick coordinates to the robot. With a Infeed Encoder tracking belt travel, the robot can pick from a moving belt by following the product as it advances, which removes the need to stop the conveyor for every pick. A Product Stop meters product into the zone when fixed-position picking is used instead.
Case handling
Empty cases come from the Case Infeed and Erector. Flat blanks sit in a Blank Magazine; the Erect Head pulls one open with vacuum, and the Bottom Sealer folds and tapes the bottom flaps. The open case then moves to the Case Indexer, a servo unit that holds it square under the robot with a pair of Case Clamp clamps while a Case Sensor confirms it is in position. After loading, the case leaves on the Discharge Conveyor, guided by adjustable side rails, toward a separate top sealer or a palletizer.
Control and safety
Motion is handled by the Robot Controller. A Motion CPU runs the kinematics and path planning, and one Servo Drive per axis closes the loops on its joint motor. An operator programs and jogs the robot with the Teach Pendant. The wider cell is sequenced by the Cell Control System system, where a PLC Module coordinates the conveyors, erector and tooling, and an HMI Panel shows rate, recipe and faults. A Safety Controller watches the Light Curtain curtains and door interlocks, stopping the robot if anyone crosses the boundary. Air for the cups, clamps and gates is conditioned by the Pneumatic and Vacuum System and switched through the Valve Manifold.
Where it fits
Robotic cells earn their place where products and cases vary, since a new pattern is a new program rather than new hardware. They also handle delicate or oddly shaped product that fixed wipe-in tooling would crush. For very high single-product volumes a dedicated mechanical case packer is faster and cheaper, but for mixed, seasonal or short-run packing the robot cell pays back through quick changeover and one machine covering many formats.
Robotic Case Packing Cell parts and their functions
10 top-level parts · 497 parts in total · full bill of materials below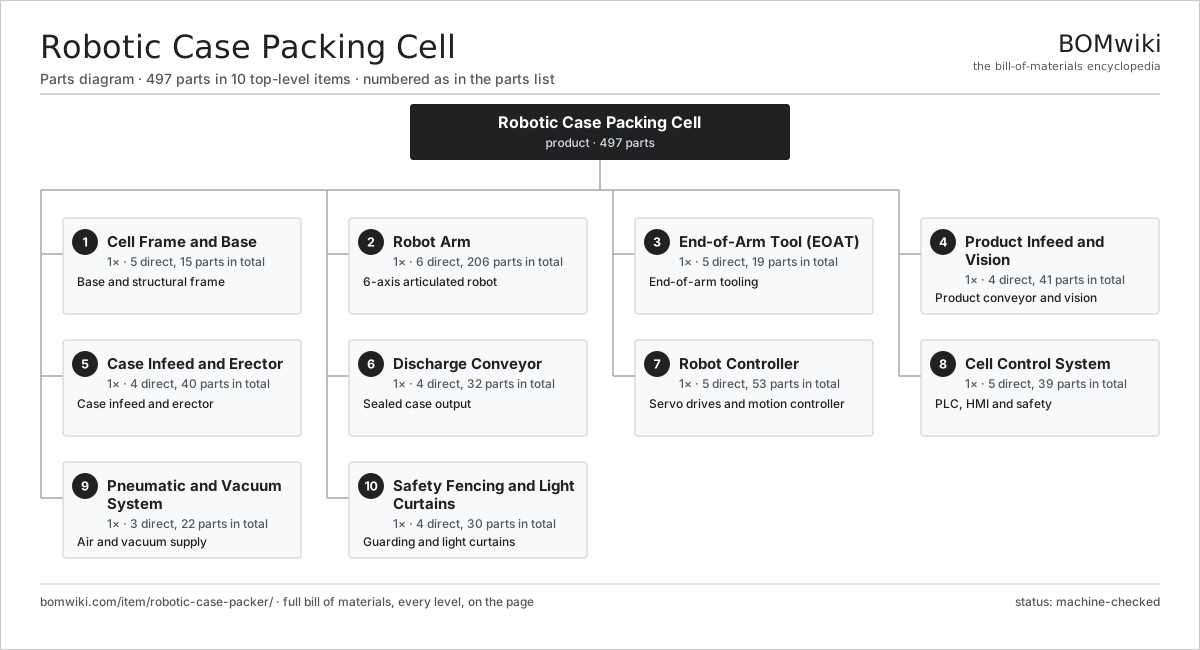
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Cell Frame and Base 5 parts | 1× | Base and structural frame |
| 2 | Robot Arm 6 parts | 1× | 6-axis articulated robot |
| 3 | End-of-Arm Tool (EOAT) 5 parts | 1× | End-of-arm tooling |
| 4 | Product Infeed and Vision 4 parts | 1× | Product conveyor and vision |
| 5 | Case Infeed and Erector 4 parts | 1× | Case infeed and erector |
| 6 | Discharge Conveyor 4 parts | 1× | Sealed case output |
| 7 | Robot Controller 5 parts | 1× | Servo drives and motion controller |
| 8 | Cell Control System 5 parts | 1× | PLC, HMI and safety |
| 9 | Pneumatic and Vacuum System 3 parts | 1× | Air and vacuum supply |
| 10 | Safety Fencing and Light Curtains 4 parts | 1× | Guarding and light curtains |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Robotic Case Packing Cell
10 top-level lines · 146 rows shown · 497 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Cell Frame and Base 5 parts | robotic-case-packer-cell-frame | 1× | 1 | 15 | assembly |
| 1.1 | Robot Pedestal | robotic-case-packer-robot-pedestal | 1× | 1 | · | part |
| 1.2 | Base Platform | robotic-case-packer-base-platform | 1× | 1 | · | part |
| 1.3 | Frame Rail | robotic-case-packer-frame-rail | 4× | 4 | · | part |
| 1.4 | Leveling Foot | robotic-case-packer-leveling-foot | 8× | 8 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Robot Arm 6 parts | robotic-case-packer-robot-arm | 1× | 1 | 206 | assembly |
| 2.1 | Robot Base (Axis 1) 6 parts | robotic-case-packer-robot-base | 1× | 1 | 33 | assembly |
| 2.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.1.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 2.1.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.1.4 | Slewing Bearing | robotic-case-packer-slewing-bearing | 1× | 1 | · | part |
| 2.1.5 | Joint Encoder 4 parts + deeper › | robotic-case-packer-joint-encoder | 1× | 1 | 4 | assembly |
| 2.1.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 2.2 | Shoulder Joint (Axis 2) 6 parts | robotic-case-packer-shoulder-axis | 1× | 1 | 34 | assembly |
| 2.2.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.2.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 2.2.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.2.4 | Joint Encoder 4 parts + deeper › | robotic-case-packer-joint-encoder | 1× | 1 | 4 | assembly |
| 2.2.5 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.2.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 2.3 | Elbow Joint (Axis 3) 6 parts | robotic-case-packer-elbow-axis | 1× | 1 | 34 | assembly |
| 2.3.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.3.2 | Gearbox Housing | gearbox-housing | 1× | 1 | · | part |
| 2.3.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 2.3.4 | Joint Encoder 4 parts + deeper › | robotic-case-packer-joint-encoder | 1× | 1 | 4 | assembly |
| 2.3.5 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.3.6 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 2.4 | Wrist Assembly (Axes 4-6) 6 parts | robotic-case-packer-wrist-assembly | 1× | 1 | 95 | assembly |
| 2.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 3× | 3 | 24 | assembly |
| 2.4.2 | Helical Gear Pair | gear-pair | 3× | 3 | · | part |
| 2.4.3 | Joint Encoder 4 parts + deeper › | robotic-case-packer-joint-encoder | 3× | 3 | 4 | assembly |
| 2.4.4 | Tool Flange | robotic-case-packer-tool-flange | 1× | 1 | · | part |
| 2.4.5 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 2.4.6 | Oil Seal | oil-seal | 3× | 3 | · | part |
| 2.5 | Arm Link Casting | robotic-case-packer-arm-link | 2× | 2 | · | part |
| 2.6 | Arm Harness 3 parts | robotic-case-packer-arm-harness | 1× | 1 | 8 | assembly |
| 2.6.1 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 2.6.2 | Connector | connector | 6× | 6 | · | part |
| 2.6.3 | Air Hose | robotic-case-packer-air-hose | 1× | 1 | · | part |
| 3 | End-of-Arm Tool (EOAT) 5 parts | robotic-case-packer-eoat | 1× | 1 | 19 | assembly |
| 3.1 | Tool Changer 3 parts | robotic-case-packer-tool-changer | 1× | 1 | 3 | assembly |
| 3.1.1 | Tool Changer Master | robotic-case-packer-changer-master | 1× | 1 | · | part |
| 3.1.2 | Tool Changer Tool Plate | robotic-case-packer-changer-tool | 1× | 1 | · | part |
| 3.1.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 3.2 | Vacuum Head 3 parts | robotic-case-packer-vacuum-head | 1× | 1 | 10 | assembly |
| 3.2.1 | Suction Cup | robotic-case-packer-suction-cup | 8× | 8 | · | part |
| 3.2.2 | Vacuum Manifold | robotic-case-packer-vacuum-manifold | 1× | 1 | · | part |
| 3.2.3 | Vacuum Sensor | robotic-case-packer-vacuum-sensor | 1× | 1 | · | part |
| 3.3 | Vacuum Generator 3 parts | robotic-case-packer-vacuum-generator | 1× | 1 | 3 | assembly |
| 3.3.1 | Venturi Nozzle | robotic-case-packer-venturi-nozzle | 1× | 1 | · | part |
| 3.3.2 | Vacuum Valve | robotic-case-packer-vacuum-valve | 1× | 1 | · | part |
| 3.3.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 3.4 | EOAT Frame | robotic-case-packer-eoat-frame | 1× | 1 | · | part |
| 3.5 | EOAT Sensor | robotic-case-packer-eoat-sensor | 2× | 2 | · | part |
| 4 | Product Infeed and Vision 4 parts | robotic-case-packer-product-infeed | 1× | 1 | 41 | assembly |
| 4.1 | Infeed Conveyor 4 parts | robotic-case-packer-infeed-conveyor | 1× | 1 | 31 | assembly |
| 4.1.1 | Conveyor Belt | robotic-case-packer-conveyor-belt | 1× | 1 | · | part |
| 4.1.2 | Conveyor Motor 4 parts + deeper › | robotic-case-packer-conveyor-motor | 1× | 1 | 25 | assembly |
| 4.1.3 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 4.1.4 | Drive Belt | drive-belt | 1× | 1 | · | part |
| 4.2 | Vision System 3 parts | robotic-case-packer-vision-system | 1× | 1 | 8 | assembly |
| 4.2.1 | Vision Camera 5 parts + deeper › | robotic-case-packer-vision-camera | 1× | 1 | 6 | assembly |
| 4.2.2 | Vision Light | robotic-case-packer-vision-light | 1× | 1 | · | part |
| 4.2.3 | Vision Lens | robotic-case-packer-vision-lens | 1× | 1 | · | part |
| 4.3 | Infeed Encoder | robotic-case-packer-infeed-encoder | 1× | 1 | · | part |
| 4.4 | Product Stop | robotic-case-packer-product-stop | 1× | 1 | · | part |
| 5 | Case Infeed and Erector 4 parts | robotic-case-packer-case-erector | 1× | 1 | 40 | assembly |
| 5.1 | Blank Magazine | robotic-case-packer-blank-magazine | 1× | 1 | · | part |
| 5.2 | Erect Head 3 parts | robotic-case-packer-erect-head | 1× | 1 | 9 | assembly |
| 5.2.1 | Suction Cup | robotic-case-packer-suction-cup | 4× | 4 | · | part |
| 5.2.2 | Vacuum Generator 3 parts + deeper › | robotic-case-packer-vacuum-generator | 1× | 1 | 3 | assembly |
| 5.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 5.3 | Bottom Sealer 2 parts | robotic-case-packer-bottom-sealer | 1× | 1 | 2 | assembly |
| 5.3.1 | Flap Folder | robotic-case-packer-flap-folder | 1× | 1 | · | part |
| 5.3.2 | Tape Head | robotic-case-packer-tape-head | 1× | 1 | · | part |
| 5.4 | Case Indexer 4 parts | robotic-case-packer-case-indexer | 1× | 1 | 28 | assembly |
| 5.4.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 5.4.2 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 5.4.3 | Case Clamp | robotic-case-packer-case-clamp | 2× | 2 | · | part |
| 5.4.4 | Case Sensor | robotic-case-packer-case-sensor | 1× | 1 | · | part |
| 6 | Discharge Conveyor 4 parts | robotic-case-packer-discharge-conveyor | 1× | 1 | 32 | assembly |
| 6.1 | Conveyor Belt | robotic-case-packer-conveyor-belt | 1× | 1 | · | part |
| 6.2 | Conveyor Motor 4 parts | robotic-case-packer-conveyor-motor | 1× | 1 | 25 | assembly |
| 6.2.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 6.2.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 6.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 6.2.4 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 6.3 | Discharge Guide | robotic-case-packer-discharge-guide | 2× | 2 | · | part |
| 6.4 | Ball Bearing | ball-bearing | 4× | 4 | · | part |
| 7 | Robot Controller 5 parts | robotic-case-packer-robot-controller | 1× | 1 | 53 | assembly |
| 7.1 | Motion CPU 4 parts | robotic-case-packer-motion-cpu | 1× | 1 | 11 | assembly |
| 7.1.1 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.1.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 7.1.4 | Connector | connector | 8× | 8 | · | part |
| 7.2 | Servo Drive 4 parts | robotic-case-packer-servo-drive | 6× | 6 | 6 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 7.2.2 | Power Module | robotic-case-packer-power-module | 1× | 6 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 6 | · | part |
| 7.2.4 | Connector | connector | 3× | 18 | · | part |
| 7.3 | Power Supply | power-supply | 1× | 1 | · | part |
| 7.4 | Teach Pendant 4 parts | robotic-case-packer-teach-pendant | 1× | 1 | 4 | assembly |
| 7.4.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7.4.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 7.4.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.4 | E-Stop Button | robotic-case-packer-estop-button | 1× | 1 | · | part |
| 7.5 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 8 | Cell Control System 5 parts | robotic-case-packer-cell-control | 1× | 1 | 39 | assembly |
| 8.1 | PLC Module 4 parts | robotic-case-packer-plc-module | 1× | 1 | 11 | assembly |
| 8.1.1 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.1.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.1.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 8.1.4 | Connector | connector | 8× | 8 | · | part |
| 8.2 | HMI Panel 4 parts | robotic-case-packer-hmi-panel | 1× | 1 | 4 | assembly |
| 8.2.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.2.3 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2.4 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3 | Safety Controller 4 parts | robotic-case-packer-safety-controller | 1× | 1 | 13 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 8.3.3 | Relay | relay | 4× | 4 | · | part |
| 8.3.4 | Connector | connector | 6× | 6 | · | part |
| 8.4 | Relay | relay | 10× | 10 | · | part |
| 8.5 | Power Supply | power-supply | 1× | 1 | · | part |
| 9 | Pneumatic and Vacuum System 3 parts | robotic-case-packer-pneumatic-system | 1× | 1 | 22 | assembly |
| 9.1 | Air Prep Unit 4 parts | robotic-case-packer-air-prep-unit | 1× | 1 | 4 | assembly |
| 9.1.1 | Air Filter | robotic-case-packer-air-filter | 1× | 1 | · | part |
| 9.1.2 | Air Regulator | robotic-case-packer-air-regulator | 1× | 1 | · | part |
| 9.1.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 9.1.4 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 9.2 | Valve Manifold 3 parts | robotic-case-packer-valve-manifold | 1× | 1 | 17 | assembly |
| 9.2.1 | Relay | relay | 6× | 6 | · | part |
| 9.2.2 | Solenoid Valve | robotic-case-packer-solenoid-valve | 10× | 10 | · | part |
| 9.2.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 9.3 | Air Reservoir | robotic-case-packer-air-reservoir | 1× | 1 | · | part |
| 10 | Safety Fencing and Light Curtains 4 parts | robotic-case-packer-safety-fencing | 1× | 1 | 30 | assembly |
| 10.1 | Fence Panel | robotic-case-packer-fence-panel | 8× | 8 | · | part |
| 10.2 | Fence Post | robotic-case-packer-fence-post | 8× | 8 | · | part |
| 10.3 | Light Curtain 4 parts | robotic-case-packer-light-curtain | 2× | 2 | 6 | assembly |
| 10.3.1 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 10.3.2 | SMD Passive (R/C/L) | smd-passives | 1× | 2 | · | part |
| 10.3.3 | Curtain Optic | robotic-case-packer-curtain-optic | 2× | 4 | · | part |
| 10.3.4 | Connector | connector | 2× | 4 | · | part |
| 10.4 | Interlock Switch | robotic-case-packer-interlock-switch | 2× | 2 | · | part |
Related products
same domain, ranked by shared parts Automatic Strapping Machine
251 parts · shares 9 with this page
Wraparound Case Packer
278 parts · shares 9 with this page
Case Labeling Machine
120 parts · shares 8 with this page
Counter-Pressure Filler
519 parts · shares 8 with this page
 Paper Banding Machine
173 parts · shares 8 with this page
Channel Letter Bender
196 parts · shares 7 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $10k–$3M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| heidelberg.com ↗ | Heidelberg, DE | Printing presses | 10 units | 12–22 wks |
|
🇨🇭Bobst
bobst.com ↗
|
Lausanne, CH | Packaging machinery | 10 units | 12–22 wks |
| koenig-bauer.com ↗ | Würzburg, DE | Printing presses | 10 units | 12–22 wks |
| wuh-group.com ↗ | Lengerich, DE | Flexible packaging machines | 10 units | 12–22 wks |
| markandy.com ↗ | Chesterfield, US | Label presses | 10 units | 12–22 wks |
1,006-word article