Submarine ROV
ProductOverview
A submarine ROV is an unmanned, tethered underwater robot flown by a pilot at the surface for inspection, survey and light intervention work, on tasks such as hull surveys, pipeline checks, dam and offshore-structure inspection and search operations. An umbilical tether carries power and high-bandwidth fiber-optic video and control between the surface and the vehicle. This is an inspection-class machine rated to 300 meters, with six thrusters for full maneuverability, a camera and sonar payload, and a small manipulator arm.
The vehicle is built on an open Frame Assembly, a machined aluminium chassis trimmed with syntactic foam for near-neutral buoyancy. Its electronics ride inside the Electronics Enclosure, a watertight acrylic tube with O-ring-sealed end caps housing the flight controller and motor drivers. Six Thruster units provide vectored propulsion in all axes, fed by the onboard Power Pack. The Tether System links the vehicle to the surface, the Sensor Suite supplies vision, sonar and navigation data, the Manipulator Arm performs light tasks, and the Ballast & Trim trims buoyancy.
How it works
The vehicle is ballasted to hover at neutral buoyancy, so its thrusters only have to move it rather than fight a constant tendency to sink or float. The pilot's commands travel down the fiber-optic tether to the main control board, which drives the brushless thrusters through the ESC board; four horizontal thrusters mounted at angles let the vehicle move and yaw in the plane, while two vertical thrusters control depth and pitch. The pressure-tolerant acrylic tube and O-ring-sealed bulkhead penetrators keep seawater out of the electronics, with a leak sensor watching for ingress. The IMU and depth sensor feed an attitude-and-depth hold loop so the craft can station-keep against currents. Live HD video from the camera, lit by the LED lights, and a sonar picture stream back up the tether to the pilot's console. When intervention is needed, the operator works the servo-driven manipulator arm to grasp or recover objects, and trim weights are set before each dive to balance the vehicle for its payload.
Submarine ROV parts and their functions
8 top-level parts · 436 parts in total · full bill of materials below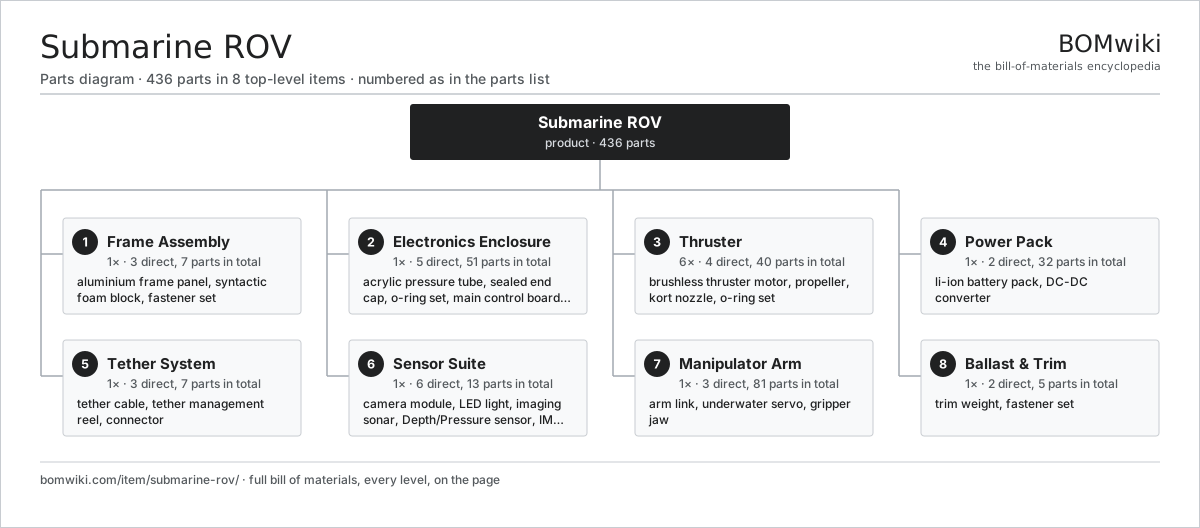
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Frame Assembly 3 parts | 1× | Open aluminium chassis with syntactic foam buoyancy. |
| 2 | Electronics Enclosure 5 parts | 1× | Watertight acrylic tube with sealed end caps housing control boards. |
| 3 | Thruster 4 parts | 6× | Brushless thruster with ducted propeller. |
| 4 | Power Pack 2 parts | 1× | Li-ion battery with management and DC-DC regulation. |
| 5 | Tether System 3 parts | 1× | Neutrally buoyant tether with surface management reel. |
| 6 | Sensor Suite 6 parts | 1× | Vision, sonar, and navigation sensors. |
| 7 | Manipulator Arm 3 parts | 1× | Servo-driven arm with gripper. |
| 8 | Ballast & Trim 2 parts | 1× | Adjustable weights for buoyancy trim. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Submarine ROV
8 top-level lines · 74 rows shown · 436 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Frame Assembly 3 parts | submarine-rov-frame | 1× | 1 | 7 | assembly |
| 1.1 | Aluminium Frame Panel | submarine-rov-frame-panel | 4× | 4 | · | part |
| 1.2 | Syntactic Foam Block | submarine-rov-syntactic-foam | 2× | 2 | · | part |
| 1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Electronics Enclosure 5 parts | submarine-rov-enclosure | 1× | 1 | 51 | assembly |
| 2.1 | Acrylic Pressure Tube | submarine-rov-enclosure-tube | 1× | 1 | · | part |
| 2.2 | Sealed End Cap 3 parts | submarine-rov-end-cap | 2× | 2 | 6 | assembly |
| 2.2.1 | End Cap Body | submarine-rov-end-cap-body | 1× | 2 | · | part |
| 2.2.2 | Bulkhead Penetrator | submarine-rov-penetrator | 4× | 8 | · | part |
| 2.2.3 | O-Ring Set | oring-set | 1× | 2 | · | part |
| 2.3 | O-Ring Set | oring-set | 2× | 2 | · | part |
| 2.4 | Main Control Board 4 parts | submarine-rov-control-board | 1× | 1 | 9 | assembly |
| 2.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 2.4.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 2.4.4 | Connector | connector | 6× | 6 | · | part |
| 2.5 | Thruster ESC Board 5 parts | submarine-rov-esc-board | 1× | 1 | 27 | assembly |
| 2.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.5.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 2.5.3 | Power MOSFET | mosfet | 18× | 18 | · | part |
| 2.5.4 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 2.5.5 | Connector | connector | 6× | 6 | · | part |
| 3 | Thruster 4 parts | submarine-rov-thruster | 6× | 6 | 40 | assembly |
| 3.1 | Brushless Thruster Motor 5 parts | submarine-rov-bldc-motor | 1× | 6 | 37 | assembly |
| 3.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 6 | 3 | assembly |
| 3.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 6 | 19 | assembly |
| 3.1.3 | Neodymium Magnet | neodymium-magnet | 12× | 72 | · | part |
| 3.1.4 | Ball Bearing | ball-bearing | 2× | 12 | · | part |
| 3.1.5 | Oil Seal | oil-seal | 1× | 6 | · | part |
| 3.2 | Propeller | submarine-rov-propeller | 1× | 6 | · | part |
| 3.3 | Kort Nozzle | submarine-rov-nozzle | 1× | 6 | · | part |
| 3.4 | O-Ring Set | oring-set | 1× | 6 | · | part |
| 4 | Power Pack 2 parts | submarine-rov-power-pack | 1× | 1 | 32 | assembly |
| 4.1 | Li-ion Battery Pack 3 parts | submarine-rov-battery | 1× | 1 | 26 | assembly |
| 4.1.1 | Li-ion Cell, 18650 | li-cell-18650 | 24× | 24 | · | part |
| 4.1.2 | BMS Board | bms-board | 1× | 1 | · | part |
| 4.1.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 4.2 | DC-DC Converter 3 parts | submarine-rov-dcdc | 1× | 1 | 6 | assembly |
| 4.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.2.2 | Power MOSFET | mosfet | 4× | 4 | · | part |
| 4.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 5 | Tether System 3 parts | submarine-rov-tether-system | 1× | 1 | 7 | assembly |
| 5.1 | Tether Cable | submarine-rov-tether-cable | 1× | 1 | · | part |
| 5.2 | Tether Management Reel 3 parts | submarine-rov-tether-reel | 1× | 1 | 4 | assembly |
| 5.2.1 | Reel Drum | submarine-rov-reel-drum | 1× | 1 | · | part |
| 5.2.2 | Slip Ring | submarine-rov-slip-ring | 1× | 1 | · | part |
| 5.2.3 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 5.3 | Connector | connector | 2× | 2 | · | part |
| 6 | Sensor Suite 6 parts | submarine-rov-sensor-suite | 1× | 1 | 13 | assembly |
| 6.1 | Camera Module 2 parts | submarine-rov-camera | 1× | 1 | 4 | assembly |
| 6.1.1 | Camera Module 3 parts + deeper › | camera-module | 1× | 1 | 3 | assembly |
| 6.1.2 | CMOS Image Sensor | image-sensor | 1× | 1 | · | part |
| 6.2 | LED Light | submarine-rov-led-light | 2× | 2 | · | part |
| 6.3 | Imaging Sonar 3 parts | submarine-rov-sonar | 1× | 1 | 3 | assembly |
| 6.3.1 | Sonar Transducer | submarine-rov-transducer | 1× | 1 | · | part |
| 6.3.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.3.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.4 | Depth/Pressure Sensor | submarine-rov-depth-sensor | 1× | 1 | · | part |
| 6.5 | IMU Module 2 parts | submarine-rov-imu | 1× | 1 | 2 | assembly |
| 6.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.5.2 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 6.6 | Leak Sensor | submarine-rov-leak-sensor | 1× | 1 | · | part |
| 7 | Manipulator Arm 3 parts | submarine-rov-manipulator | 1× | 1 | 81 | assembly |
| 7.1 | Arm Link | submarine-rov-arm-link | 2× | 2 | · | part |
| 7.2 | Underwater Servo 5 parts | submarine-rov-servo | 3× | 3 | 26 | assembly |
| 7.2.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 3 | 3 | assembly |
| 7.2.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 3 | 19 | assembly |
| 7.2.3 | Hall Sensor | hall-sensor | 1× | 3 | · | part |
| 7.2.4 | Ball Bearing | ball-bearing | 2× | 6 | · | part |
| 7.2.5 | Oil Seal | oil-seal | 1× | 3 | · | part |
| 7.3 | Gripper Jaw | submarine-rov-gripper | 1× | 1 | · | part |
| 8 | Ballast & Trim 2 parts | submarine-rov-ballast | 1× | 1 | 5 | assembly |
| 8.1 | Trim Weight | submarine-rov-ballast-weight | 4× | 4 | · | part |
| 8.2 | Fastener Set | fastener-set | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Houseboat
444 parts · shares 16 with this page
 Work-Class ROV
155 parts · shares 8 with this page
 Sailboat
275 parts · shares 14 with this page
 Anchor Windlass
79 parts · shares 15 with this page
 Diver Propulsion Vehicle
56 parts · shares 3 with this page
Zoo Habitat Filtration
99 parts · shares 11 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $2k–$500M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| hd.com ↗ | Ulsan, KR | Shipbuilder | made to order | 52–104 wks |
| fincantieri.com ↗ | Trieste, IT | Shipbuilder | made to order | 52–104 wks |
| damen.com ↗ | Gorinchem, NL | Shipbuilder | made to order | 52–104 wks |
| brunswick.com ↗ | Mettawa, US | Marine & boats | made to order | 52–104 wks |
|
🇨🇳CSSC
cssc.net.cn ↗
|
Shanghai, CN | Shipbuilding conglomerate | made to order | 52–104 wks |
365-word article