Crewed Submersible
ProductOverview
A crewed submersible carries a small team into the deep ocean and brings them back at one atmosphere. The whole design follows from one fact: at 6000 m the water pushes in at about 600 bar, roughly 600 times the pressure at the surface, so the people inside have to sit behind a wall strong enough to hold that load without flexing enough to fail. The Pressure Hull does that job, and almost every other system on the craft exists to move it, keep it alive, power it, or let it see and work.
The craft described here rates to 6000 m, which reaches about 98 percent of the seabed. It seats a pilot and two observers, dives for eight to ten hours at a time, and keeps a life-support reserve of three to four days in case it cannot surface on schedule. Net weight in air is around 11500 kg, most of it the hull, the Buoyancy Module foam, and the Power System pods.
Pressure Hull
The crew sits inside a Titanium Hull Sphere, two forged Ti-6Al-4V hemispheres welded at an Equatorial Joining Ring into a sphere about 2.1 m across with a 70 mm wall. A sphere is used because it spreads external pressure evenly and gives the most internal volume for the least metal. Titanium is chosen for its strength-to-weight ratio and its resistance to seawater corrosion, which lets the wall stay thin enough that the hull still floats once the foam is added.
Crew see out through three Acrylic Viewport windows. Each is a Cast Acrylic Cone, a cast PMMA frustum that seats into a titanium Viewport Retainer. The cone shape matters: external pressure drives the acrylic deeper into its seat, so the window seals harder the deeper the craft goes. People and gear enter through the Entry Hatch, whose Hatch Cover also seals inward, clamped down by a ring of Hatch Dog latches before descent. Every wire and hydraulic line crosses the hull through a Hull Penetrator, a feed-through that holds pressure where the wall is broken.
Ballast, Trim, and Buoyancy
The submersible flies by managing its weight in water. It starts a dive slightly heavy and sinks. The Ballast & Trim System holds two Variable Ballast Tank hard tanks that flood to descend and blow clear with high-pressure air through a Ballast Blow Valve to rise. Two Trim Tank volumes shift water fore and aft, moved by the Trim Pump, to hold the craft level. Fine weight changes near the bottom come from the Ballast Pump, which pushes water against full ambient pressure.
Two Droppable Weight assemblies hang on a Release Electromagnet. If power is lost the magnet lets go, the Steel Ballast Shot falls away, and the craft becomes positively buoyant and rises on its own. That fail-safe is backed by the Buoyancy Module module: blocks of Syntactic Foam Block, hollow glass microspheres set in epoxy, that stay nearly incompressible and buoyant even at 6000 m, where ordinary foam would crush.
Propulsion and Manipulation
Six DC Thruster units arranged for horizontal, lateral, and vertical control move the craft. Each is a brushless motor turning a Thruster Propeller inside a Thruster Duct that raises thrust at low speed. The motors are not sealed against pressure: an Oil Compensator fills each one with oil and equalises its internal pressure to the surrounding water, so the thin housing carries almost no load. A sealed Thruster Controller drives each one. The same oil-compensation trick appears across the craft, in the thrusters, the battery pods, the lights, and the arm, because it removes the weight penalty of a thick pressure case.
Sampling is done with the Manipulator Arm, a six-function electric arm. Each Arm Joint pairs a servo motor with a reduction gearbox in an oil-filled body, and the joints connect through Arm Link tubes. At the end is the Gripper, a parallel-jaw effector whose Gripper Jaw fingers can take sediment cores or place instruments. The Arm Controller turns console inputs into coordinated joint motion.
Life Support and Power
The cabin is a sealed box of air that the Life Support System system keeps breathable. The CO2 Scrubber draws cabin air through a bed of Soda-Lime Absorbent that reacts with carbon dioxide and removes it, while the Oxygen Supply meters oxygen from a high-pressure Oxygen Cylinder through the Oxygen Regulator to replace what the crew uses. The Cabin Atmosphere Monitor logs oxygen and carbon dioxide with its Oxygen Sensor and CO2 Sensor and warns the crew before either drifts out of range. Each person also has an Emergency Rebreather for use if the cabin atmosphere fails.
Power comes from the Power System. Two Battery Pod units hold lithium Pressure-Tolerant Cell stacks in oil, so they need only a thin Pod Housing rather than a heavy pressure vessel, watched by a Pod BMS. The pods feed a Junction Pod and then the DC Distribution Board board, which fuses each branch through a DC Breaker.
Sensing and Crew Station
In the dark of the deep the craft sees by sound and by light. The Navigation & Sonar suite carries a forward Sonar Transducer built from a Piezo Element Stack behind an Acoustic Window, a Depth Sensor that reads depth from a Pressure Sensor, a Compass & IMU for heading, an Acoustic Transponder that answers the surface ship for positioning, and a Doppler Velocity Log for speed over the bottom. For close work the Lighting & Imaging package adds LED Light Array floodlights and Camera units behind a Dome Port, with footage written to the Video Recorder.
The crew flies all of this from the Command Console. A Hand Controller commands the thrusters or the arm, a Console Display built on an LCD Panel shows sonar and video, and a guarded Switch Panel handles lights, pumps, and the weight release. The Console Computer fuses the navigation, sensor, and video streams into one picture.
Variants and Use
The same architecture scales by depth and role. A shallower coastal variant rated to 1000 m can use a cheaper steel hull and fewer foam blocks, while a full-ocean version near 11000 m needs a thicker sphere and far more syntactic foam. Science craft carry extra sample baskets and a second arm; inspection craft for pipelines and cables trade sampling gear for more cameras and sonar. Typical work includes seabed geology, marine biology surveys, archaeological documentation, and inspection of subsea infrastructure, where having people aboard lets the crew judge a scene and adapt the dive plan in real time.
Crewed Submersible parts and their functions
10 top-level parts · 2,830 parts in total · full bill of materials below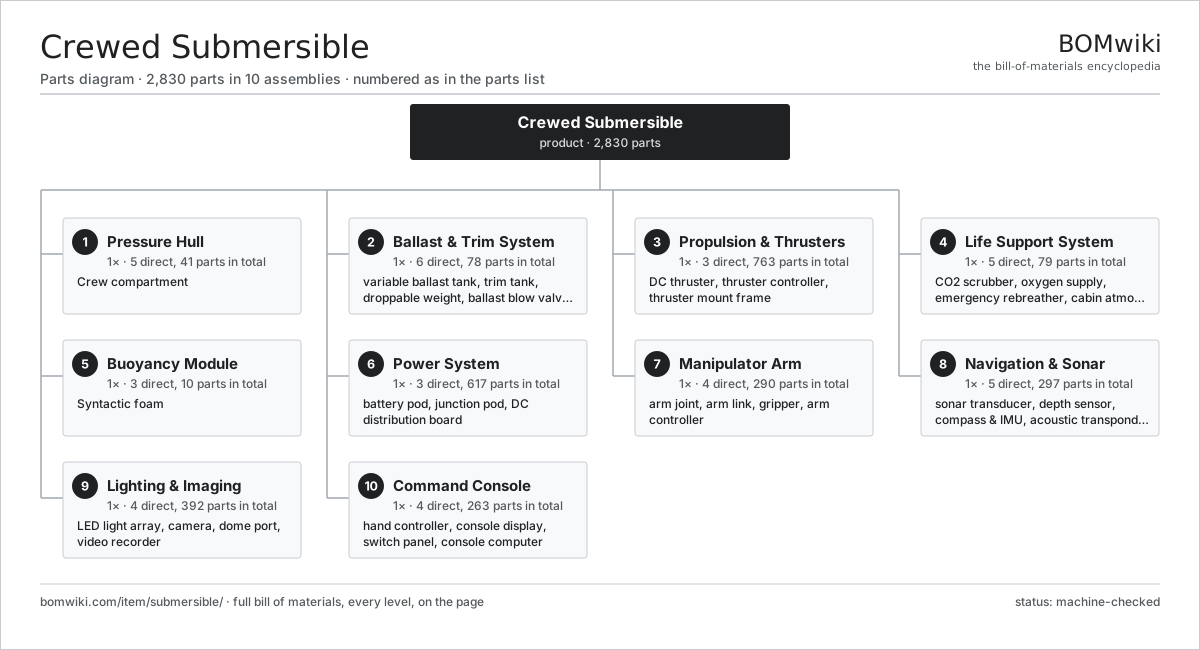
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Pressure Hull 5 parts | 1× | Crew compartment |
| 2 | Ballast & Trim System 6 parts | 1× | Variable ballast, trim, and droppable weights that set descent, hover, and ascent. |
| 3 | Propulsion & Thrusters 3 parts | 1× | Oil-filled DC thrusters giving fore, aft, lateral, and vertical control. |
| 4 | Life Support System 5 parts | 1× | Closed-circuit life support holding cabin oxygen and removing carbon dioxide for 72-96 hours of reserve. |
| 5 | Buoyancy Module 3 parts | 1× | Syntactic foam |
| 6 | Power System 3 parts | 1× | Pressure-tolerant battery pods feeding a DC distribution bus at about 120 V. |
| 7 | Manipulator Arm 4 parts | 1× | Six-function electric arm for sampling and instrument placement, oil-compensated to depth. |
| 8 | Navigation & Sonar 5 parts | 1× | Acoustic and inertial sensors for positioning, obstacle detection, and surface tracking. |
| 9 | Lighting & Imaging 4 parts | 1× | LED arrays and cameras behind pressure-rated dome ports for documentation. |
| 10 | Command Console 4 parts | 1× | Pilot station with hand controllers and displays for flying the craft and its tools. |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Crewed Submersible
10 top-level lines · 169 rows shown · 2,830 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Pressure Hull 5 parts | submersible-pressure-hull | 1× | 1 | 41 | assembly |
| 1.1 | Titanium Hull Sphere 3 parts | submersible-hull-sphere | 1× | 1 | 4 | assembly |
| 1.1.1 | Hull Hemisphere | submersible-hull-hemisphere | 2× | 2 | · | part |
| 1.1.2 | Equatorial Joining Ring | submersible-equatorial-ring | 1× | 1 | · | part |
| 1.1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 1.2 | Acrylic Viewport 3 parts | submersible-viewport | 3× | 3 | 4 | assembly |
| 1.2.1 | Cast Acrylic Cone | submersible-acrylic-cone | 1× | 3 | · | part |
| 1.2.2 | Viewport Retainer | submersible-viewport-retainer | 1× | 3 | · | part |
| 1.2.3 | O-Ring Set | oring-set | 2× | 6 | · | part |
| 1.3 | Entry Hatch 4 parts | submersible-entry-hatch | 1× | 1 | 10 | assembly |
| 1.3.1 | Hatch Cover | submersible-hatch-cover | 1× | 1 | · | part |
| 1.3.2 | Hatch Coaming | submersible-hatch-coaming | 1× | 1 | · | part |
| 1.3.3 | Hatch Dog | submersible-hatch-dog | 6× | 6 | · | part |
| 1.3.4 | O-Ring Set | oring-set | 2× | 2 | · | part |
| 1.4 | Hull Penetrator | submersible-hull-penetrator | 14× | 14 | · | part |
| 1.5 | Interior Liner | submersible-hull-liner | 1× | 1 | · | part |
| 2 | Ballast & Trim System 6 parts | submersible-ballast-system | 1× | 1 | 78 | assembly |
| 2.1 | Variable Ballast Tank | submersible-variable-ballast-tank | 2× | 2 | · | part |
| 2.2 | Trim Tank | submersible-trim-tank | 2× | 2 | · | part |
| 2.3 | Droppable Weight 2 parts | submersible-drop-weight | 2× | 2 | 2 | assembly |
| 2.3.1 | Steel Ballast Shot | submersible-ballast-shot | 1× | 2 | · | part |
| 2.3.2 | Release Electromagnet | submersible-release-magnet | 1× | 2 | · | part |
| 2.4 | Ballast Blow Valve 3 parts | submersible-blow-valve | 4× | 4 | 3 | assembly |
| 2.4.1 | Valve Body | submersible-valve-body | 1× | 4 | · | part |
| 2.4.2 | Solenoid Actuator | submersible-solenoid | 1× | 4 | · | part |
| 2.4.3 | O-Ring Set | oring-set | 1× | 4 | · | part |
| 2.5 | Ballast Pump 4 parts | submersible-ballast-pump | 1× | 1 | 29 | assembly |
| 2.5.1 | Pump Head | submersible-pump-head | 1× | 1 | · | part |
| 2.5.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.5.3 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 2.5.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 2.6 | Trim Pump 4 parts | submersible-trim-pump | 1× | 1 | 29 | assembly |
| 2.6.1 | Pump Head | submersible-pump-head | 1× | 1 | · | part |
| 2.6.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 2.6.3 | Oil Seal | oil-seal | 2× | 2 | · | part |
| 2.6.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 3 | Propulsion & Thrusters 3 parts | submersible-propulsion | 1× | 1 | 763 | assembly |
| 3.1 | DC Thruster 7 parts | submersible-thruster | 6× | 6 | 29 | assembly |
| 3.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 6 | 3 | assembly |
| 3.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 6 | 19 | assembly |
| 3.1.3 | Thruster Propeller | submersible-propeller | 1× | 6 | · | part |
| 3.1.4 | Thruster Duct | submersible-thruster-duct | 1× | 6 | · | part |
| 3.1.5 | Oil Compensator | submersible-oil-compensator | 1× | 6 | · | part |
| 3.1.6 | Ball Bearing | ball-bearing | 2× | 12 | · | part |
| 3.1.7 | Oil Seal | oil-seal | 2× | 12 | · | part |
| 3.2 | Thruster Controller 4 parts | submersible-thruster-controller | 6× | 6 | 98 | assembly |
| 3.2.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 3.2.2 | Microcontroller | mcu | 1× | 6 | · | part |
| 3.2.3 | Power MOSFET | mosfet | 6× | 36 | · | part |
| 3.2.4 | SMD Passive (R/C/L) | smd-passives | 90× | 540 | · | part |
| 3.3 | Thruster Mount Frame | submersible-thruster-frame | 1× | 1 | · | part |
| 4 | Life Support System 5 parts | submersible-life-support | 1× | 1 | 79 | assembly |
| 4.1 | CO2 Scrubber 3 parts | submersible-co2-scrubber | 1× | 1 | 3 | assembly |
| 4.1.1 | Scrubber Canister | submersible-scrubber-canister | 1× | 1 | · | part |
| 4.1.2 | Soda-Lime Absorbent | submersible-soda-lime | 1× | 1 | · | part |
| 4.1.3 | Cabin Circulation Fan | submersible-cabin-fan | 1× | 1 | · | part |
| 4.2 | Oxygen Supply 3 parts | submersible-o2-supply | 1× | 1 | 4 | assembly |
| 4.2.1 | Oxygen Cylinder | submersible-o2-cylinder | 2× | 2 | · | part |
| 4.2.2 | Oxygen Regulator | submersible-o2-regulator | 1× | 1 | · | part |
| 4.2.3 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 4.3 | Emergency Rebreather 3 parts | submersible-emergency-rebreather | 2× | 2 | 3 | assembly |
| 4.3.1 | Counterlung Bag | submersible-rebreather-bag | 1× | 2 | · | part |
| 4.3.2 | Scrubber Canister | submersible-scrubber-canister | 1× | 2 | · | part |
| 4.3.3 | Oxygen Cylinder | submersible-o2-cylinder | 1× | 2 | · | part |
| 4.4 | Cabin Atmosphere Monitor 5 parts | submersible-cabin-monitor | 1× | 1 | 64 | assembly |
| 4.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.4.3 | Oxygen Sensor | submersible-o2-sensor | 1× | 1 | · | part |
| 4.4.4 | CO2 Sensor | submersible-co2-sensor | 1× | 1 | · | part |
| 4.4.5 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 4.5 | Cabin Circulation Fan | submersible-cabin-fan | 2× | 2 | · | part |
| 5 | Buoyancy Module 3 parts | submersible-buoyancy | 1× | 1 | 10 | assembly |
| 5.1 | Syntactic Foam Block | submersible-syntactic-foam-block | 8× | 8 | · | part |
| 5.2 | Foam Retention Frame | submersible-foam-frame | 1× | 1 | · | part |
| 5.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 6 | Power System 3 parts | submersible-power-system | 1× | 1 | 617 | assembly |
| 6.1 | Battery Pod 4 parts | submersible-battery-pod | 2× | 2 | 244 | assembly |
| 6.1.1 | Pressure-Tolerant Cell | submersible-pressure-cell | 120× | 240 | · | part |
| 6.1.2 | Pod BMS 3 parts + deeper › | submersible-pod-bms | 1× | 2 | 122 | assembly |
| 6.1.3 | Oil Compensator | submersible-oil-compensator | 1× | 2 | · | part |
| 6.1.4 | Pod Housing | submersible-pod-housing | 1× | 2 | · | part |
| 6.2 | Junction Pod 4 parts | submersible-junction-pod | 1× | 1 | 27 | assembly |
| 6.2.1 | Pod Housing | submersible-pod-housing | 1× | 1 | · | part |
| 6.2.2 | Connector | connector | 24× | 24 | · | part |
| 6.2.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 6.2.4 | Oil Compensator | submersible-oil-compensator | 1× | 1 | · | part |
| 6.3 | DC Distribution Board 5 parts | submersible-dc-distribution | 1× | 1 | 102 | assembly |
| 6.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.3.3 | Relay | relay | 12× | 12 | · | part |
| 6.3.4 | DC Breaker | submersible-dc-breaker | 8× | 8 | · | part |
| 6.3.5 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 7 | Manipulator Arm 4 parts | submersible-manipulator | 1× | 1 | 290 | assembly |
| 7.1 | Arm Joint 6 parts | submersible-arm-joint | 5× | 5 | 31 | assembly |
| 7.1.1 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 5 | 24 | assembly |
| 7.1.2 | Gearbox Housing | gearbox-housing | 1× | 5 | · | part |
| 7.1.3 | Helical Gear Pair | gear-pair | 1× | 5 | · | part |
| 7.1.4 | Ball Bearing | ball-bearing | 2× | 10 | · | part |
| 7.1.5 | Oil Seal | oil-seal | 2× | 10 | · | part |
| 7.1.6 | Oil Compensator | submersible-oil-compensator | 1× | 5 | · | part |
| 7.2 | Arm Link | submersible-arm-link | 4× | 4 | · | part |
| 7.3 | Gripper 4 parts | submersible-gripper | 1× | 1 | 29 | assembly |
| 7.3.1 | Gripper Jaw | submersible-gripper-jaw | 2× | 2 | · | part |
| 7.3.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 7.3.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 7.3.4 | Linear Guide Rail | linear-guide | 2× | 2 | · | part |
| 7.4 | Arm Controller 3 parts | submersible-arm-controller | 1× | 1 | 102 | assembly |
| 7.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.4.3 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 8 | Navigation & Sonar 5 parts | submersible-nav-sonar | 1× | 1 | 297 | assembly |
| 8.1 | Sonar Transducer 3 parts | submersible-sonar-transducer | 1× | 1 | 139 | assembly |
| 8.1.1 | Piezo Element Stack | submersible-piezo-stack | 16× | 16 | · | part |
| 8.1.2 | Acoustic Window | submersible-acoustic-window | 1× | 1 | · | part |
| 8.1.3 | Sonar Driver Board 3 parts + deeper › | submersible-sonar-board | 1× | 1 | 122 | assembly |
| 8.2 | Depth Sensor 3 parts | submersible-depth-sensor | 1× | 1 | 3 | assembly |
| 8.2.1 | Pressure Sensor | pressure-sensor | 1× | 1 | · | part |
| 8.2.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.2.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3 | Compass & IMU 4 parts | submersible-compass-imu | 1× | 1 | 83 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3.3 | Fluxgate Magnetometer | submersible-fluxgate | 1× | 1 | · | part |
| 8.3.4 | SMD Passive (R/C/L) | smd-passives | 80× | 80 | · | part |
| 8.4 | Acoustic Transponder 3 parts | submersible-transponder | 1× | 1 | 6 | assembly |
| 8.4.1 | Piezo Element Stack | submersible-piezo-stack | 4× | 4 | · | part |
| 8.4.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.4.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.5 | Doppler Velocity Log 4 parts | submersible-doppler-log | 1× | 1 | 66 | assembly |
| 8.5.1 | Piezo Element Stack | submersible-piezo-stack | 4× | 4 | · | part |
| 8.5.2 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.5.3 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.5.4 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 9 | Lighting & Imaging 4 parts | submersible-lighting-imaging | 1× | 1 | 392 | assembly |
| 9.1 | LED Light Array 4 parts | submersible-led-array | 4× | 4 | 70 | assembly |
| 9.1.1 | LED Module | submersible-led-module | 12× | 48 | · | part |
| 9.1.2 | LED Driver 4 parts + deeper › | submersible-led-driver | 1× | 4 | 56 | assembly |
| 9.1.3 | Oil Compensator | submersible-oil-compensator | 1× | 4 | · | part |
| 9.1.4 | Light Housing | submersible-light-housing | 1× | 4 | · | part |
| 9.2 | Camera 4 parts | submersible-camera | 2× | 2 | 4 | assembly |
| 9.2.1 | Image Sensor | submersible-image-sensor | 1× | 2 | · | part |
| 9.2.2 | Camera Lens | submersible-camera-lens | 1× | 2 | · | part |
| 9.2.3 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 9.2.4 | Camera Housing | submersible-camera-housing | 1× | 2 | · | part |
| 9.3 | Dome Port | submersible-dome-port | 2× | 2 | · | part |
| 9.4 | Video Recorder 3 parts | submersible-video-recorder | 1× | 1 | 102 | assembly |
| 9.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 9.4.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 9.4.3 | SMD Passive (R/C/L) | smd-passives | 100× | 100 | · | part |
| 10 | Command Console 4 parts | submersible-command-console | 1× | 1 | 263 | assembly |
| 10.1 | Hand Controller 4 parts | submersible-hand-controller | 2× | 2 | 5 | assembly |
| 10.1.1 | Joystick Gimbal | submersible-joystick-gimbal | 1× | 2 | · | part |
| 10.1.2 | Bare PCB | pcb-bare | 1× | 2 | · | part |
| 10.1.3 | Microcontroller | mcu | 1× | 2 | · | part |
| 10.1.4 | Coil Spring | coil-spring | 2× | 4 | · | part |
| 10.2 | Console Display 3 parts | submersible-display | 3× | 3 | 3 | assembly |
| 10.2.1 | LCD Panel | lcd-panel | 1× | 3 | · | part |
| 10.2.2 | Bare PCB | pcb-bare | 1× | 3 | · | part |
| 10.2.3 | Microcontroller | mcu | 1× | 3 | · | part |
| 10.3 | Switch Panel 4 parts | submersible-switch-panel | 1× | 1 | 40 | assembly |
| 10.3.1 | Sheet Metal Panel | sheet-panel | 1× | 1 | · | part |
| 10.3.2 | Relay | relay | 8× | 8 | · | part |
| 10.3.3 | Connector | connector | 30× | 30 | · | part |
| 10.3.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 10.4 | Console Computer 4 parts | submersible-console-computer | 1× | 1 | 204 | assembly |
| 10.4.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 10.4.2 | Microcontroller | mcu | 2× | 2 | · | part |
| 10.4.3 | Power Supply | power-supply | 1× | 1 | · | part |
| 10.4.4 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
Related products
same domain, ranked by shared parts Anchor Handling Tug
1,196 parts · shares 25 with this page
 Factory Ship
2,311 parts · shares 25 with this page
 Catamaran Ferry
4,765 parts · shares 24 with this page
 Research Vessel
2,194 parts · shares 23 with this page
Roll-On Roll-Off Ship
264,134 parts · shares 22 with this page
 Container Feeder Ship
2,496 parts · shares 24 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $2k–$500M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| hd.com ↗ | Ulsan, KR | Shipbuilder | made to order | 52–104 wks |
| fincantieri.com ↗ | Trieste, IT | Shipbuilder | made to order | 52–104 wks |
| damen.com ↗ | Gorinchem, NL | Shipbuilder | made to order | 52–104 wks |
| brunswick.com ↗ | Mettawa, US | Marine & boats | made to order | 52–104 wks |
|
🇨🇳CSSC
cssc.net.cn ↗
|
Shanghai, CN | Shipbuilding conglomerate | made to order | 52–104 wks |
1,146-word article