Automated Liquid Handler
ProductOverview
An automated liquid handler is a pipetting robot. It does by machine what a scientist does by hand with a pipette: pick up a tip, draw a measured volume of liquid from one well, move it, and dispense it into another. The difference is scale and consistency. A handler runs an entire 96- or 384-well plate the same way every time, unattended, hundreds of transfers per minute, which is what makes assay development, drug screening, genomics sample prep and NGS library construction practical at volume.
The work surface is a flat deck of fixed positions. Plates, reagent reservoirs and boxes of disposable tips sit in kinematic nests at known coordinates, so the robot addresses each one blind from its method file. A run is a list of aspirate-and-dispense steps the software walks through, and the deck layout tells it where everything is.
How it works
Every position is reachable because the pipettor rides a three-axis robot, the X-Y-Z Gantry. A bridge moves in Y, a carriage in X and the head plunges in Z, each a servo motor turning a ball-screw under encoder feedback, so the tips arrive over any well to a fraction of a millimeter. The labware it works on sits on the Labware Deck, whose nests register each plate and tip rack in a repeatable spot.
The transfers themselves come from the Pipetting Head, a row of independent air-displacement channels that pick up tips, aspirate and dispense, then eject the tips to waste. Each channel is fed by its own pump in the Syringe Pump Bank bank, where a glass syringe driven by a ball-screw displaces an exact volume and solenoid valves route between aspirate, dispense and wash.
Accuracy depends on knowing the liquid is really there. The Liquid Sensing module uses a capacitive sensor on each tip to find the surface so the tip dips just below it, and a pressure transducer watches each draw to catch a clot or an empty well. Between samples the head visits the Wash Station to flush carryover. Coordinating all of it, the Control Electronics pair a single-board computer running the method with a motion controller that drives the gantry servos and syringe pumps in lockstep.
Automated Liquid Handler parts and their functions
11 top-level parts · 817 parts in total · full bill of materials below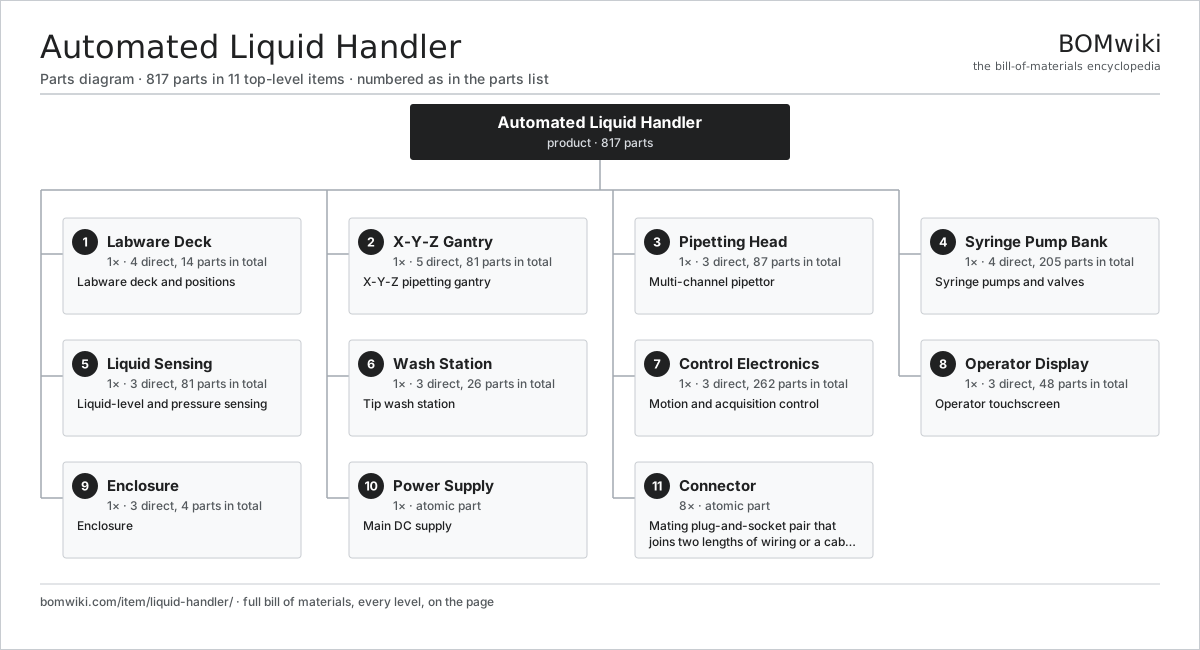
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Labware Deck 4 parts | 1× | Labware deck and positions |
| 2 | X-Y-Z Gantry 5 parts | 1× | X-Y-Z pipetting gantry |
| 3 | Pipetting Head 3 parts | 1× | Multi-channel pipettor |
| 4 | Syringe Pump Bank 4 parts | 1× | Syringe pumps and valves |
| 5 | Liquid Sensing 3 parts | 1× | Liquid-level and pressure sensing |
| 6 | Wash Station 3 parts | 1× | Tip wash station |
| 7 | Control Electronics 3 parts | 1× | Motion and acquisition control |
| 8 | Operator Display 3 parts | 1× | Operator touchscreen |
| 9 | Enclosure 3 parts | 1× | Enclosure |
| 10 | Power Supply | 1× | Main DC supply |
| 11 | Connector | 8× | Mating plug-and-socket pair that joins two lengths of wiring or a cable to a board so a circuit can be assembled, serviced, and separated without soldering. |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Automated Liquid Handler
11 top-level lines · 80 rows shown · 817 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Labware Deck 4 parts | lh-deck | 1× | 1 | 14 | assembly |
| 1.1 | Deck Plate | lh-deck-plate | 1× | 1 | · | part |
| 1.2 | Labware Nest | lh-labware-nest | 8× | 8 | · | part |
| 1.3 | Tip Rack | lh-tip-rack | 4× | 4 | · | part |
| 1.4 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | X-Y-Z Gantry 5 parts | lh-gantry | 1× | 1 | 81 | assembly |
| 2.1 | X-Axis Drive 4 parts | lh-x-axis | 1× | 1 | 24 | assembly |
| 2.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.1.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 2.1.4 | Rotary Encoder | lh-encoder | 1× | 1 | · | part |
| 2.2 | Y-Axis Drive 4 parts | lh-y-axis | 1× | 1 | 24 | assembly |
| 2.2.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.2.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.2.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 2.2.4 | Rotary Encoder | lh-encoder | 1× | 1 | · | part |
| 2.3 | Z-Axis Drive 4 parts | lh-z-axis | 1× | 1 | 24 | assembly |
| 2.3.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 2.3.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 2.3.3 | Ball Screw | ball-screw | 1× | 1 | · | part |
| 2.3.4 | Rotary Encoder | lh-encoder | 1× | 1 | · | part |
| 2.4 | Linear Guide Rail | lh-linear-guide | 3× | 3 | · | part |
| 2.5 | Ball Bearing | ball-bearing | 6× | 6 | · | part |
| 3 | Pipetting Head 3 parts | lh-pipetting-head | 1× | 1 | 87 | assembly |
| 3.1 | Pipette Channel | lh-pipette-channel | 8× | 8 | · | part |
| 3.2 | Tip Ejector | lh-tip-ejector | 1× | 1 | · | part |
| 3.3 | Head Control Board 4 parts | lh-head-board | 1× | 1 | 78 | assembly |
| 3.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.3.3 | SMD Passive (R/C/L) | smd-passives | 70× | 70 | · | part |
| 3.3.4 | Connector | connector | 6× | 6 | · | part |
| 4 | Syringe Pump Bank 4 parts | lh-fluidics | 1× | 1 | 205 | assembly |
| 4.1 | Syringe Pump 4 parts | lh-syringe-pump | 8× | 8 | 24 | assembly |
| 4.1.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 8 | 3 | assembly |
| 4.1.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 8 | 19 | assembly |
| 4.1.3 | Ball Screw | ball-screw | 1× | 8 | · | part |
| 4.1.4 | Glass Syringe | lh-syringe | 1× | 8 | · | part |
| 4.2 | Distribution Valve | lh-valve | 8× | 8 | · | part |
| 4.3 | Relay | relay | 4× | 4 | · | part |
| 4.4 | System Tubing | lh-tubing | 1× | 1 | · | part |
| 5 | Liquid Sensing 3 parts | lh-sensing | 1× | 1 | 81 | assembly |
| 5.1 | Liquid-Level Sensor | lh-level-sensor | 8× | 8 | · | part |
| 5.2 | Pressure Transducer | lh-pressure-sensor | 8× | 8 | · | part |
| 5.3 | Sense Board 3 parts | lh-sense-board | 1× | 1 | 65 | assembly |
| 5.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.3.2 | SMD Passive (R/C/L) | smd-passives | 60× | 60 | · | part |
| 5.3.3 | Connector | connector | 4× | 4 | · | part |
| 6 | Wash Station 3 parts | lh-wash-station | 1× | 1 | 26 | assembly |
| 6.1 | Wash Basin | lh-wash-basin | 1× | 1 | · | part |
| 6.2 | Wash Pump 3 parts | lh-wash-pump | 1× | 1 | 23 | assembly |
| 6.2.1 | Stator Assembly 3 parts + deeper › | stator-assembly | 1× | 1 | 3 | assembly |
| 6.2.2 | Rotor Assembly 4 parts + deeper › | rotor-assembly | 1× | 1 | 19 | assembly |
| 6.2.3 | Helical Gear Pair | gear-pair | 1× | 1 | · | part |
| 6.3 | Distribution Valve | lh-valve | 2× | 2 | · | part |
| 7 | Control Electronics 3 parts | lh-electronics | 1× | 1 | 262 | assembly |
| 7.1 | Main Board 4 parts | lh-main-board | 1× | 1 | 154 | assembly |
| 7.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 7.1.3 | SMD Passive (R/C/L) | smd-passives | 140× | 140 | · | part |
| 7.1.4 | Connector | connector | 12× | 12 | · | part |
| 7.2 | Motion Controller 4 parts | lh-motion-board | 1× | 1 | 107 | assembly |
| 7.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 7.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 7.2.3 | SMD Passive (R/C/L) | smd-passives | 95× | 95 | · | part |
| 7.2.4 | Connector | connector | 10× | 10 | · | part |
| 7.3 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 8 | Operator Display 3 parts | lh-display | 1× | 1 | 48 | assembly |
| 8.1 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 8.2 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 8.3 | Display Board 4 parts | lh-display-board | 1× | 1 | 46 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 8.3.3 | SMD Passive (R/C/L) | smd-passives | 40× | 40 | · | part |
| 8.3.4 | Connector | connector | 4× | 4 | · | part |
| 9 | Enclosure 3 parts | lh-housing | 1× | 1 | 4 | assembly |
| 9.1 | Frame | lh-frame | 1× | 1 | · | part |
| 9.2 | Front Shield | lh-front-shield | 1× | 1 | · | part |
| 9.3 | Fastener Set | fastener-set | 2× | 2 | · | part |
| 10 | Power Supply | power-supply | 1× | 1 | · | part |
| 11 | Connector | connector | 8× | 8 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Thermogravimetric Analyzer (TGA)
661 parts · shares 17 with this page
 Fraction Collector
269 parts · shares 16 with this page
Superconductor Materials Lab
1,846 parts · shares 16 with this page
 X-Ray Diffractometer
705 parts · shares 16 with this page
 Atomic Absorption Spectrometer
648 parts · shares 16 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $1k–$500k. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| thermofisher.com ↗ | Waltham, US | Lab instruments | 100 units | 10–18 wks |
|
🇺🇸Agilent
agilent.com ↗
|
Santa Clara, US | Analytical instruments | 100 units | 10–18 wks |
|
🇺🇸Bruker
bruker.com ↗
|
Billerica, US | Scientific instruments | 100 units | 10–18 wks |
|
🇯🇵Shimadzu
shimadzu.com ↗
|
Kyoto, JP | Analytical instruments | 100 units | 10–18 wks |
|
🇺🇸Waters
waters.com ↗
|
Milford, US | Chromatography & MS | 100 units | 10–18 wks |
376-word article