Surgical Robot
ProductOverview
A surgical robot lets a surgeon perform minimally invasive operations through small ports with greater dexterity and precision than handheld laparoscopic tools allow. The surgeon sits at a console and manipulates master controls; the system scales and filters those motions and reproduces them with wristed instruments held by robotic arms over the patient, viewing the field in magnified stereo 3D. The surgeon is always in command, the robot never acts autonomously.
The instruments and camera are carried by the Patient Cart, whose multiple robotic arms position through the body-wall ports. Each arm pivots about a remote center of motion at the port so the instrument shaft does not lever against tissue, and a cable-driven wrist near the instrument tip gives the articulation, the seven degrees of freedom, that restores the dexterity lost with rigid laparoscopic tools.
How it works
The surgeon works at the Surgeon Console, looking into a stereo viewer fed by the endoscope and gripping master tele-manipulators whose motion is scaled down and tremor-filtered before being sent to the arms. A real-time master-slave servo loop ties hand motion to instrument motion with low latency, and a redundant safety board enforces force and position limits and halts motion on fault.
Imaging and energy are managed by the Vision Cart, which houses the image-processing computer for the stereo endoscope, the LED light source, and the electrosurgical generator for cutting and coagulation. Together the three units form the system: the patient cart acts in the body, the console captures the surgeon's intent, and the vision cart provides sight and energy.
Surgical Robot parts and their functions
3 top-level parts · 2,740 parts in total · full bill of materials below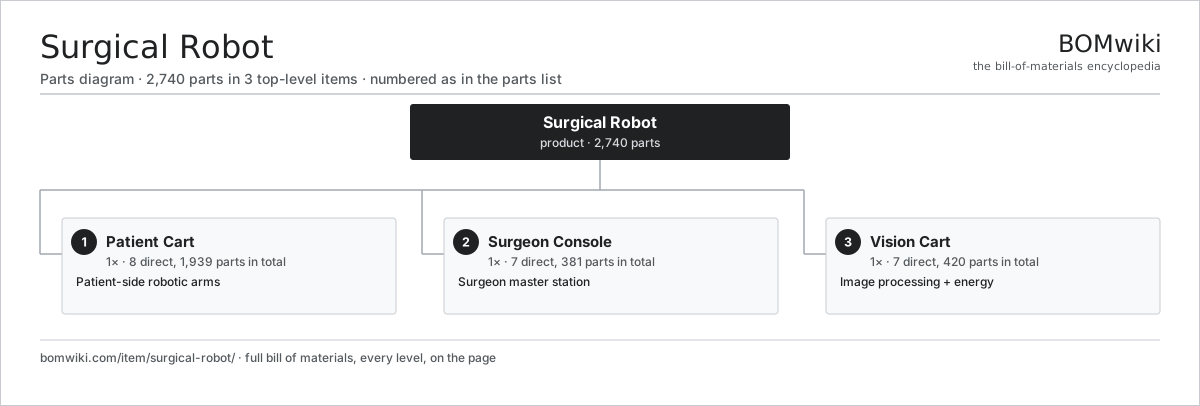
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Patient Cart 8 parts | 1× | Patient-side robotic arms |
| 2 | Surgeon Console 7 parts | 1× | Surgeon master station |
| 3 | Vision Cart 7 parts | 1× | Image processing + energy |
Diagrams & photos


3D model
No 3D model yet. Have a CAD file of this? Add a 3D model. STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Surgical Robot
3 top-level lines · 71 rows shown · 2,740 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Patient Cart 8 parts | surgical-robot-patient-cart | 1× | 1 | 1,939 | assembly |
| 1.1 | Cart Base 3 parts | surgical-robot-cart-base | 1× | 1 | 6 | assembly |
| 1.1.1 | Base Frame | surgical-robot-base-frame | 1× | 1 | · | part |
| 1.1.2 | Locking Caster | surgical-robot-caster | 4× | 4 | · | part |
| 1.1.3 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 1.2 | Central Column Lift 4 parts | surgical-robot-central-column | 1× | 1 | 28 | assembly |
| 1.2.1 | Lift Column Structure | surgical-robot-lift-screw | 1× | 1 | · | part |
| 1.2.2 | Servo Motor 4 parts + deeper › | servo-motor | 1× | 1 | 24 | assembly |
| 1.2.3 | Encoder | encoder | 1× | 1 | · | part |
| 1.2.4 | Ball Bearing | ball-bearing | 2× | 2 | · | part |
| 1.3 | Robotic Arm 6 parts | surgical-robot-robotic-arm | 4× | 4 | 205 | assembly |
| 1.3.1 | Arm Joint 5 parts + deeper › | surgical-robot-arm-joint | 4× | 16 | 29 | assembly |
| 1.3.2 | Arm Link | surgical-robot-arm-link | 4× | 16 | · | part |
| 1.3.3 | Sterile Adapter | surgical-robot-sterile-adapter | 1× | 4 | · | part |
| 1.3.4 | Cannula Mount | surgical-robot-cannula-mount | 1× | 4 | · | part |
| 1.3.5 | Arm I/O Board 3 parts + deeper › | surgical-robot-arm-pcb | 1× | 4 | 82 | assembly |
| 1.3.6 | Wire Bundle | wire-bundle | 1× | 4 | · | part |
| 1.4 | Wristed Instrument 4 parts | surgical-robot-instrument | 3× | 3 | 12 | assembly |
| 1.4.1 | Instrument Shaft | surgical-robot-instrument-shaft | 1× | 3 | · | part |
| 1.4.2 | Cable-Driven Wrist 3 parts + deeper › | surgical-robot-wrist | 1× | 3 | 6 | assembly |
| 1.4.3 | Drive Disk Pack | surgical-robot-drive-disks | 1× | 3 | · | part |
| 1.4.4 | Drive Cable | surgical-robot-drive-cable | 4× | 12 | · | part |
| 1.5 | Stereo Endoscope 4 parts | surgical-robot-endoscope | 1× | 1 | 219 | assembly |
| 1.5.1 | Camera Module 3 parts + deeper › | camera-module | 2× | 2 | 3 | assembly |
| 1.5.2 | CMOS Image Sensor | image-sensor | 2× | 2 | · | part |
| 1.5.3 | Light Fiber Bundle | surgical-robot-light-fiber | 1× | 1 | · | part |
| 1.5.4 | Camera Control Unit Board 4 parts + deeper › | surgical-robot-ccu-board | 1× | 1 | 210 | assembly |
| 1.6 | Arm Control Box 4 parts | surgical-robot-arm-control-box | 1× | 1 | 828 | assembly |
| 1.6.1 | Motor Controller 5 parts + deeper › | surgical-robot-motor-controller | 4× | 4 | 134 | assembly |
| 1.6.2 | Safety Board 4 parts + deeper › | surgical-robot-safety-board | 1× | 1 | 99 | assembly |
| 1.6.3 | Real-Time Computer 4 parts + deeper › | surgical-robot-rt-computer | 1× | 1 | 192 | assembly |
| 1.6.4 | Power Supply | power-supply | 1× | 1 | · | part |
| 1.7 | Power Supply | power-supply | 1× | 1 | · | part |
| 1.8 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 2 | Surgeon Console 7 parts | surgical-robot-surgeon-console | 1× | 1 | 381 | assembly |
| 2.1 | Ergonomic Frame | surgical-robot-console-frame | 1× | 1 | · | part |
| 2.2 | Stereo Viewer 2 parts | surgical-robot-stereo-viewer | 1× | 1 | 3 | assembly |
| 2.2.1 | Micro-Display | surgical-robot-micro-display | 2× | 2 | · | part |
| 2.2.2 | Viewer Optics | surgical-robot-viewer-optics | 1× | 1 | · | part |
| 2.3 | Master Tele-Manipulator 5 parts | surgical-robot-master-controller | 2× | 2 | 81 | assembly |
| 2.3.1 | Hand Gimbal | surgical-robot-gimbal | 1× | 2 | · | part |
| 2.3.2 | Servo Motor 4 parts + deeper › | servo-motor | 3× | 6 | 24 | assembly |
| 2.3.3 | Encoder | encoder | 3× | 6 | · | part |
| 2.3.4 | Pinch Grip | surgical-robot-pinch-grip | 1× | 2 | · | part |
| 2.3.5 | Ball Bearing | ball-bearing | 4× | 8 | · | part |
| 2.4 | Foot Pedal Tray | surgical-robot-foot-pedals | 1× | 1 | · | part |
| 2.5 | Armrest | surgical-robot-armrest | 1× | 1 | · | part |
| 2.6 | Console Computer 4 parts | surgical-robot-console-computer | 1× | 1 | 212 | assembly |
| 2.6.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 2.6.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 2.6.3 | SMD Passive (R/C/L) | smd-passives | 200× | 200 | · | part |
| 2.6.4 | Connector | connector | 10× | 10 | · | part |
| 2.7 | Power Supply | power-supply | 1× | 1 | · | part |
| 3 | Vision Cart 7 parts | surgical-robot-vision-cart | 1× | 1 | 420 | assembly |
| 3.1 | Image Processing Computer 4 parts | surgical-robot-image-computer | 1× | 1 | 254 | assembly |
| 3.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.1.2 | Compute SoC Module | soc-module | 1× | 1 | · | part |
| 3.1.3 | SMD Passive (R/C/L) | smd-passives | 240× | 240 | · | part |
| 3.1.4 | Connector | connector | 12× | 12 | · | part |
| 3.2 | Light Source 2 parts | surgical-robot-light-source | 1× | 1 | 2 | assembly |
| 3.2.1 | High-Power LED Emitter | surgical-robot-led-emitter | 1× | 1 | · | part |
| 3.2.2 | Power Supply | power-supply | 1× | 1 | · | part |
| 3.3 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 3.4 | Touch Digitizer | touch-digitizer | 1× | 1 | · | part |
| 3.5 | Electrosurgical Generator 4 parts | surgical-robot-electrosurgical-generator | 1× | 1 | 160 | assembly |
| 3.5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.5.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.5.3 | Power MOSFET | mosfet | 8× | 8 | · | part |
| 3.5.4 | SMD Passive (R/C/L) | smd-passives | 150× | 150 | · | part |
| 3.6 | Power Supply | power-supply | 1× | 1 | · | part |
| 3.7 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
Something wrong in this list? Report a problem with this BOM.
Related products
same domain, ranked by shared parts Powered Wheelchair
150 parts · shares 13 with this page
 Ophthalmic Tonometer
505 parts · shares 20 with this page
 Autorefractor
513 parts · shares 19 with this page
Heart-Lung Machine
298 parts · shares 18 with this page
Rehabilitation Robot Arm
467 parts · shares 18 with this page
Bladder Scanner
483 parts · shares 17 with this page
Sourcing: possible vendors
Browse the supplier directory → Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $500–$3M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| gehealthcare.com ↗ | Chicago, US | Medical imaging & devices | 100 units | 12–20 wks |
| siemens-healthineers.com ↗ | Erlangen, DE | Medical systems | 100 units | 12–20 wks |
|
🇳🇱Philips
philips.com ↗
|
Amsterdam, NL | Health technology | 100 units | 12–20 wks |
| medtronic.com ↗ | Minneapolis, US | Medical devices | 100 units | 12–20 wks |
|
🇨🇳Mindray
mindray.com ↗
|
Shenzhen, CN | Medical devices | 100 units | 12–20 wks |
274-word article