Pavement Profiler
ProductOverview
A pavement profiler is a survey vehicle that measures the shape of a road surface as it drives over it, fast enough to keep up with traffic. Road agencies use the numbers it produces to decide which roads to resurface, to check that new paving meets a smoothness specification, and to track how a network ages year over year. The core trick is that a moving vehicle bounces on its own suspension, so a laser pointed at the road would measure both the road and the car. The profiler measures the cars motion separately and subtracts it, leaving the true profile of the pavement.
The vehicle carries a Laser Sensor Bar across the front that reads surface height, a Inertial Reference Package that tracks how the body moves, a Distance Measuring Instrument that measures distance, and a GNSS Unit that records where each reading was taken. The Data Acquisition Computer gathers all of this in step and computes the result, while a Pavement Imaging camera records the surface itself. The whole rig runs on a conditioned Power and Conditioning feed off the vehicle.
Measuring height with lasers
The Laser Sensor Bar carries several Laser Triangulation Head units spaced across the lane. Each head works by triangulation: a Line Laser Diode sends a stripe of light onto the road through a Line Generator Lens that spreads it into an even line, and a CMOS Line Camera viewing from a known angle images that line. When the road rises or falls, the stripe shifts position in the camera, and that shift converts directly to a height with resolution near five hundredths of a millimetre. The heads bolt to a stiff Bar Extrusion so they all share one straight reference line. Because road grit and spray would blind the optics, each head has a hard Laser Window kept clear by an Air Knife that sheets compressed air across the glass.
Cancelling the vehicle motion
A laser alone measures height relative to the vehicle, which is useless on a bouncing car. The Inertial Reference Package fixes this. A Servo Accelerometer sits above each wheelpath and measures the vertical acceleration of the body; integrating that acceleration twice gives how far the body moved up or down. A Rate Gyro tracks pitch and roll so the reference stays level when the road grade changes. The IMU Fusion Board fuses these signals into a clean inertial reference, all held rigid by the IMU Housing. Subtracting the body motion from the laser height leaves the genuine road profile, which is what makes the instrument an inertial profiler rather than a simple ranging device.
Distance, position, and sampling
Roughness indices are defined along distance, not time, so the profiler must sample at fixed spacing on the ground. The Distance Measuring Instrument handles this with a high-count Wheel Encoder on a non-driven wheel, held by the DMI Bracket. The Pulse Board counts its pulses and triggers a measurement every twenty-five millimetres regardless of speed, so a slow crawl and a highway pass produce the same sampling. The GNSS Unit adds location: a roof GNSS Antenna feeds the GNSS Receiver, which tags every reading so a flagged defect can be found and re-surveyed.
Acquisition and surface imaging
The Data Acquisition Computer is a rugged computer in a vibration-rated Rugged Enclosure. Its Acquisition Board samples the laser, inertial, and distance channels together so they line up exactly, and the result is written to a Solid-State Storage sized for a full day of work. A Operator Display shows live roughness so the crew can tell at once if a run is good. Alongside the profile, the Pavement Imaging subsystem records the surface for crack and texture rating. A downward Area-Scan Camera captures the lane while two LED Array strobes freeze the image at speed, all aimed by the Camera Mount. Recording the image alongside the profile means a single pass produces both the smoothness numbers and a visual record that raters use later to classify cracking type and severity without going back to the road.
Power and field use
The sensors and computer cannot tolerate the voltage dips of a vehicle electrical system, so the Power and Conditioning subsystem cleans it up. A Power Supply produces regulated rails, a Ride-Through Battery battery rides through engine restarts, and a Distribution Board fuses and switches power to each subsystem. In service the vehicle drives a lane at near traffic speed, the profiler logs IRI and full transverse rut profiles continuously, and the data feeds a pavement management system. The same vehicle is run with a calibrated rod-and-level check against a reference surface so its output qualifies as a Class 1 profiler under the relevant standards.
Pavement Profiler parts and their functions
8 top-level parts · 98 parts in total · full bill of materials below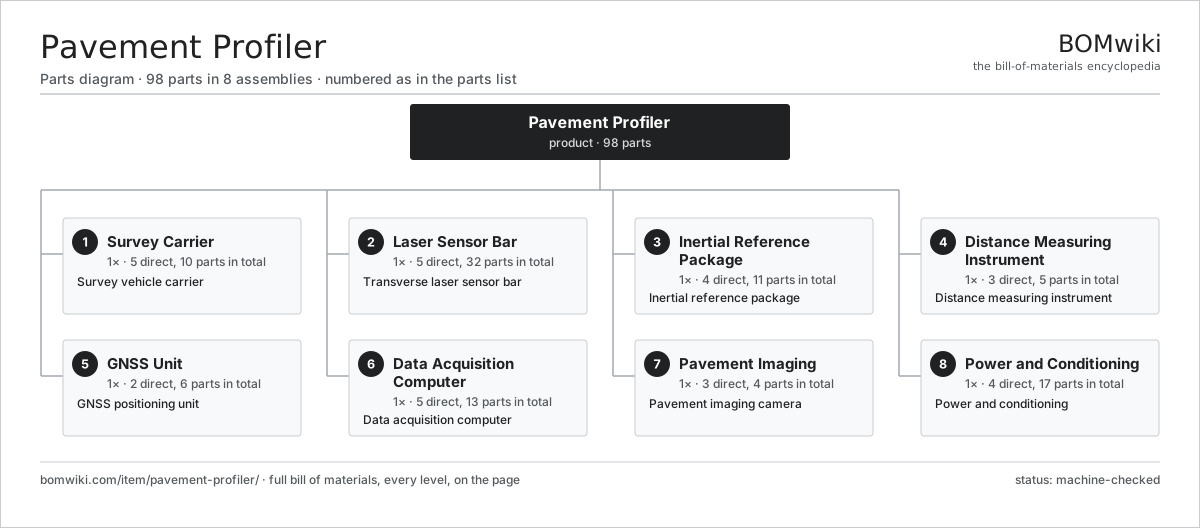
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Survey Carrier 5 parts | 1× | Survey vehicle carrier |
| 2 | Laser Sensor Bar 5 parts | 1× | Transverse laser sensor bar |
| 3 | Inertial Reference Package 4 parts | 1× | Inertial reference package |
| 4 | Distance Measuring Instrument 3 parts | 1× | Distance measuring instrument |
| 5 | GNSS Unit 2 parts | 1× | GNSS positioning unit |
| 6 | Data Acquisition Computer 5 parts | 1× | Data acquisition computer |
| 7 | Pavement Imaging 3 parts | 1× | Pavement imaging camera |
| 8 | Power and Conditioning 4 parts | 1× | Power and conditioning |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labourTap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Pavement Profiler
8 top-level lines · 62 rows shown · 98 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Survey Carrier 5 parts | pavement-profiler-carrier | 1× | 1 | 10 | assembly |
| 1.1 | Front Sensor Frame | pavement-profiler-front-frame | 1× | 1 | · | part |
| 1.2 | Sensor Mount Arm | pavement-profiler-mount-arm | 2× | 2 | · | part |
| 1.3 | Vibration Isolator | pavement-profiler-vibration-isolator | 4× | 4 | · | part |
| 1.4 | Sheet Metal Panel | sheet-panel | 2× | 2 | · | part |
| 1.5 | Fastener Set | fastener-set | 1× | 1 | · | part |
| 2 | Laser Sensor Bar 5 parts | pavement-profiler-laser-bar | 1× | 1 | 32 | assembly |
| 2.1 | Laser Triangulation Head 4 parts | pavement-profiler-laser-head | 5× | 5 | 4 | assembly |
| 2.1.1 | Line Laser Diode | pavement-profiler-laser-diode | 1× | 5 | · | part |
| 2.1.2 | Line Generator Lens | pavement-profiler-line-optic | 1× | 5 | · | part |
| 2.1.3 | CMOS Line Camera | pavement-profiler-cmos-sensor | 1× | 5 | · | part |
| 2.1.4 | Head Housing | pavement-profiler-head-housing | 1× | 5 | · | part |
| 2.2 | Bar Extrusion | pavement-profiler-bar-extrusion | 1× | 1 | · | part |
| 2.3 | Laser Window | pavement-profiler-laser-window | 5× | 5 | · | part |
| 2.4 | Air Knife | pavement-profiler-air-knife | 5× | 5 | · | part |
| 2.5 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
| 3 | Inertial Reference Package 4 parts | pavement-profiler-accel-pack | 1× | 1 | 11 | assembly |
| 3.1 | Servo Accelerometer | pavement-profiler-accelerometer | 3× | 3 | · | part |
| 3.2 | Rate Gyro | pavement-profiler-gyro | 1× | 1 | · | part |
| 3.3 | IMU Fusion Board 4 parts | pavement-profiler-imu-board | 1× | 1 | 6 | assembly |
| 3.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 3.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 3.3.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 3.3.4 | Connector | connector | 3× | 3 | · | part |
| 3.4 | IMU Housing | pavement-profiler-imu-housing | 1× | 1 | · | part |
| 4 | Distance Measuring Instrument 3 parts | pavement-profiler-dmi | 1× | 1 | 5 | assembly |
| 4.1 | Wheel Encoder | pavement-profiler-encoder | 1× | 1 | · | part |
| 4.2 | DMI Bracket | pavement-profiler-dmi-bracket | 1× | 1 | · | part |
| 4.3 | Pulse Board 3 parts | pavement-profiler-pulse-board | 1× | 1 | 3 | assembly |
| 4.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 4.3.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 4.3.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 5 | GNSS Unit 2 parts | pavement-profiler-gnss | 1× | 1 | 6 | assembly |
| 5.1 | GNSS Antenna | pavement-profiler-gnss-antenna | 1× | 1 | · | part |
| 5.2 | GNSS Receiver 4 parts | pavement-profiler-gnss-receiver | 1× | 1 | 5 | assembly |
| 5.2.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.2.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.2.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 5.2.4 | Connector | connector | 2× | 2 | · | part |
| 6 | Data Acquisition Computer 5 parts | pavement-profiler-daq | 1× | 1 | 13 | assembly |
| 6.1 | Acquisition Board 4 parts | pavement-profiler-daq-board | 1× | 1 | 9 | assembly |
| 6.1.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 6.1.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 6.1.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 6.1.4 | Connector | connector | 6× | 6 | · | part |
| 6.2 | Solid-State Storage | pavement-profiler-ssd | 1× | 1 | · | part |
| 6.3 | Operator Display | pavement-profiler-display | 1× | 1 | · | part |
| 6.4 | Rugged Enclosure | pavement-profiler-enclosure | 1× | 1 | · | part |
| 6.5 | LCD Panel | lcd-panel | 1× | 1 | · | part |
| 7 | Pavement Imaging 3 parts | pavement-profiler-imaging | 1× | 1 | 4 | assembly |
| 7.1 | Area-Scan Camera | pavement-profiler-area-camera | 1× | 1 | · | part |
| 7.2 | LED Array | pavement-profiler-led-array | 2× | 2 | · | part |
| 7.3 | Camera Mount | pavement-profiler-cam-mount | 1× | 1 | · | part |
| 8 | Power and Conditioning 4 parts | pavement-profiler-power | 1× | 1 | 17 | assembly |
| 8.1 | Power Supply | power-supply | 1× | 1 | · | part |
| 8.2 | Ride-Through Battery | pavement-profiler-ups | 1× | 1 | · | part |
| 8.3 | Distribution Board 4 parts | pavement-profiler-dist-board | 1× | 1 | 14 | assembly |
| 8.3.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 8.3.2 | Relay | relay | 4× | 4 | · | part |
| 8.3.3 | SMD Passive (R/C/L) | smd-passives | 1× | 1 | · | part |
| 8.3.4 | Connector | connector | 8× | 8 | · | part |
| 8.4 | Wire Bundle | wire-bundle | 1× | 1 | · | part |
Related products
same domain, ranked by shared parts Bridge Girder Launching Gantry
1,542 parts · shares 9 with this page
 Drilling Rig Truck
310 parts · shares 9 with this page
 Flat-Top Tower Crane
358 parts · shares 9 with this page
 Luffing Jib Tower Crane
1,807 parts · shares 9 with this page
 Mobile Concrete Plant
1,245 parts · shares 9 with this page
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $15k–$2M. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
| caterpillar.com ↗ | Irving, US | Construction & mining equipment | made to order | 16–28 wks |
|
🇯🇵Komatsu
komatsu.com ↗
|
Tokyo, JP | Construction & mining equipment | made to order | 16–28 wks |
|
🇸🇪Volvo CE
volvoce.com ↗
|
Gothenburg, SE | Construction equipment | made to order | 16–28 wks |
|
🇨🇭Liebherr
liebherr.com ↗
|
Bulle, CH | Cranes & heavy equipment | made to order | 16–28 wks |
|
🇨🇳XCMG
xcmg.com ↗
|
Xuzhou, CN | Construction machinery | made to order | 16–28 wks |
834-word article