Handling Robot
AssemblyThe six-axis robot that grips the casting and presses it against the fixed grinding head along the programmed path. A full specification article for this item is being written. Meanwhile its bill of materials and connections are below.
Handling Robot parts and their functions
5 top-level parts · 699 parts in total · full bill of materials below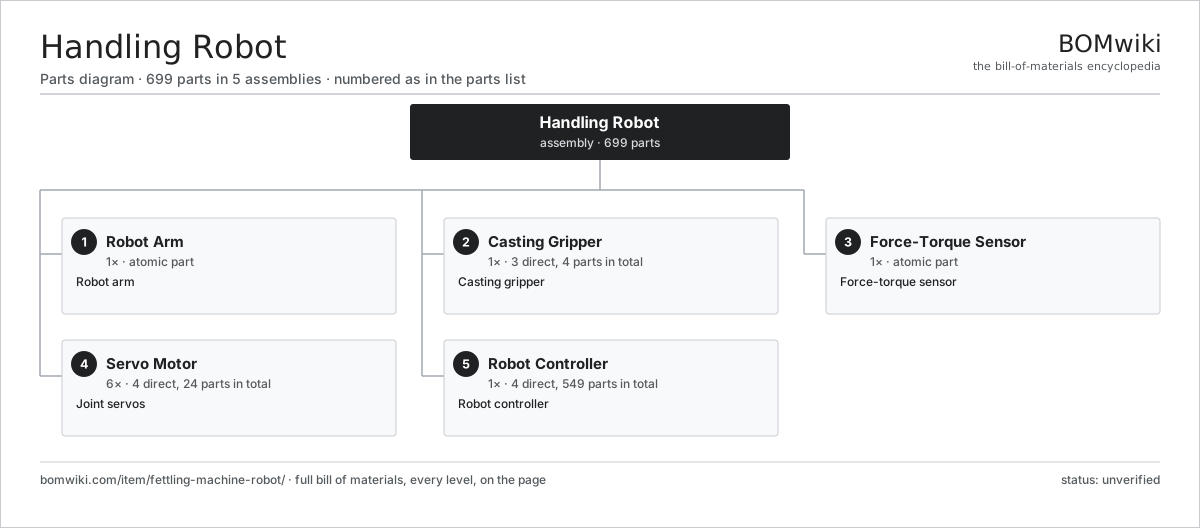
| # | Part | Qty | What it does |
|---|---|---|---|
| 1 | Robot Arm | 1× | Robot arm |
| 2 | Casting Gripper 3 parts | 1× | Casting gripper |
| 3 | Force-Torque Sensor | 1× | Force-torque sensor |
| 4 | Servo Motor 4 parts | 6× | Joint servos |
| 5 | Robot Controller 4 parts | 1× | Robot controller |
3D model
No 3D model yet. Have a CAD file of this? Add a 3D model — STL renders right on this page; STEP, FreeCAD, and OpenSCAD sources are welcome too (openly licensed, like all 3D models on BOMwiki).
Build & assembly graph
expand / collapse · shared sub-assemblies converge · links to related products · est. labour
product / assembly
shared across products
atomic part
related product
Tap an assembly to expand/collapse · tap a part to open it · use “Open page” for any node · drag to pan, scroll to zoom.
Bill of materials for Handling Robot
5 top-level lines · 27 rows shown · 699 parts total · indented to 3 levels| # | Item / sub-assembly | Part no. | Qty/assy | Ext. qty | Parts | Type |
|---|---|---|---|---|---|---|
| 1 | Robot Arm | fettling-machine-robot-arm | 1× | 1 | · | part |
| 2 | Casting Gripper 3 parts | fettling-machine-gripper | 1× | 1 | 4 | assembly |
| 2.1 | Gripper Jaw | fettling-machine-gripper-jaw | 2× | 2 | · | part |
| 2.2 | Gripper Cylinder | fettling-machine-gripper-cylinder | 1× | 1 | · | part |
| 2.3 | O-Ring Set | oring-set | 1× | 1 | · | part |
| 3 | Force-Torque Sensor | fettling-machine-force-sensor | 1× | 1 | · | part |
| 4 | Servo Motor 4 parts | servo-motor | 6× | 6 | 24 | assembly |
| 4.1 | Stator Assembly 3 parts | stator-assembly | 1× | 6 | 3 | assembly |
| 4.1.1 | Stator Core (laminations) | stator-core | 1× | 6 | · | part |
| 4.1.2 | Copper Winding | copper-winding | 1× | 6 | · | part |
| 4.1.3 | Slot Insulation | stator-insulation | 1× | 6 | · | part |
| 4.2 | Rotor Assembly 4 parts | rotor-assembly | 1× | 6 | 19 | assembly |
| 4.2.1 | Rotor Shaft | rotor-shaft | 1× | 6 | · | part |
| 4.2.2 | Rotor Core | rotor-core | 1× | 6 | · | part |
| 4.2.3 | Neodymium Magnet | neodymium-magnet | 16× | 96 | · | part |
| 4.2.4 | Ball Bearing | ball-bearing | 1× | 6 | · | part |
| 4.3 | Encoder | encoder | 1× | 6 | · | part |
| 4.4 | Motor Housing | motor-housing | 1× | 6 | · | part |
| 5 | Robot Controller 4 parts | fettling-machine-robot-controller | 1× | 1 | 549 | assembly |
| 5.1 | Bare PCB | pcb-bare | 1× | 1 | · | part |
| 5.2 | Microcontroller | mcu | 1× | 1 | · | part |
| 5.3 | Servo Drive 4 parts | servo-drive | 6× | 6 | 91 | assembly |
| 5.3.1 | Bare PCB | pcb-bare | 1× | 6 | · | part |
| 5.3.2 | IGBT Power Module | igbt-module | 1× | 6 | · | part |
| 5.3.3 | Gate Driver Board 3 parts + deeper › | gate-driver-board | 1× | 6 | 87 | assembly |
| 5.3.4 | DC-Link Capacitor | dc-link-cap | 2× | 12 | · | part |
| 5.4 | Power Supply | power-supply | 1× | 1 | · | part |
Where the handling robot is used
1 product across 1 domain contain it, directly or inside a sub-assemblyUsed in 1 assembly
Sourcing: possible vendors
Prices, MOQ, and lead times are algorithmic estimates, not quotes, and not claims about these companies. Company mappings are curated by keyword; est. price band $0.50–$100. How estimates work| Vendor | HQ | Specialty | MOQ | Lead time |
|---|---|---|---|---|
|
🇨🇳Foxconn
foxconn.com ↗
|
Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| flex.com ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| dixoninfo.com ↗ | Noida, IN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| bydelectronic.com ↗ | Shenzhen, CN | Electronics contract mfg | 1,000 pcs | 6–10 wks |
| venture.com.sg ↗ | Singapore | Electronics contract mfg | 1,000 pcs | 6–10 wks |